

The DOI matches its Crossref record; 12 of the 13 references it cites were found in a registry or an index.
AVSS: Airborne Video Surveillance System
Open accessAbstract
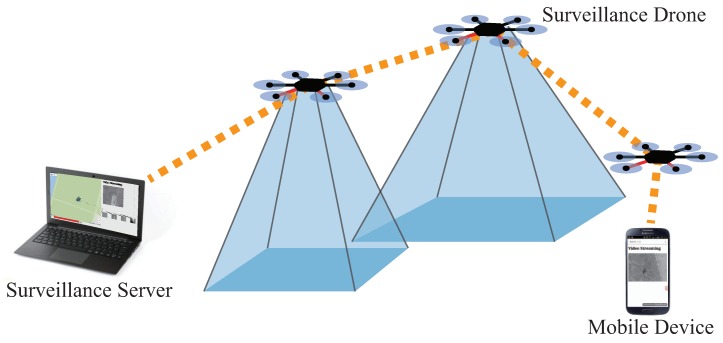
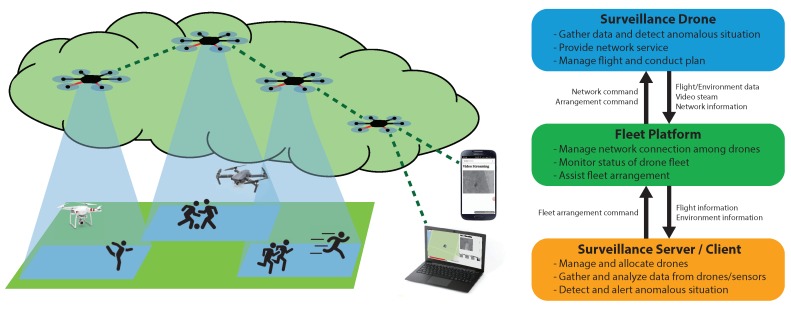
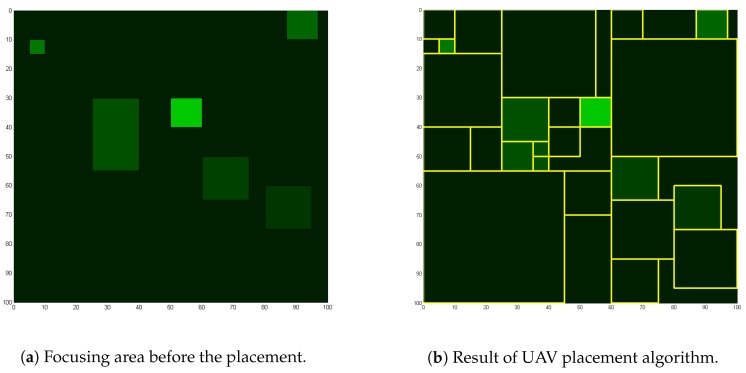
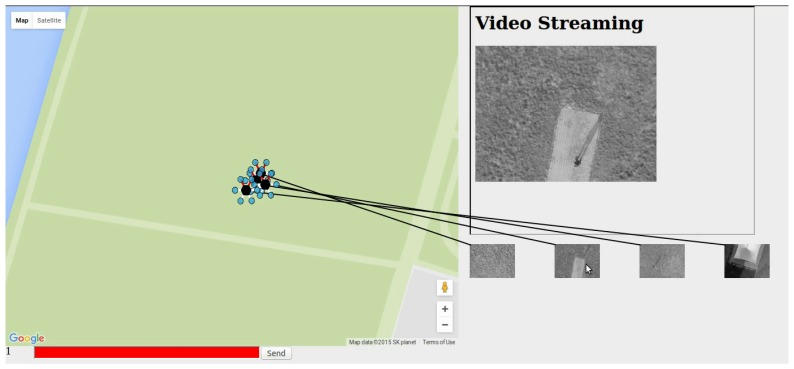
Most surveillance systems only contain CCTVs. CCTVs, however, provide only limited maneuverability against dynamic targets and are inefficient for short term surveillance. Such limitations do not raise much concern in some cases, but for the scenario in which traditional surveillance systems do not suffice, adopting a fleet of UAVs can help overcoming the limitations. In this paper, we present a surveillance system implemented with a fleet of unmanned aerial vehicles (UAVs). A surveillance system implemented with a fleet of UAVs is easy to deploy and maintain. A UAV fleet requires little time to deploy and set up, and removing the surveillance is also virtually instant. The system we propose deploys UAVs to the target area for installation and perform surveillance operations. The camera mounted UAVs act as surveillance probes, the server provides overall control of the surveillance system, and the fleet platform provides fleet-wise control of the UAVs. In the proposed system, the UAVs establish a network and enable multi-hop communication, which allows the system to widen its coverage area. The operator of the system can control the fleet of UAVs via the fleet platform and receive surveillance information gathered by the UAVs. The proposed system is described in detail along with the algorithm for effective placement of the UAVs. The prototype of the system is presented, and the experiment carried out shows that the system can successfully perform surveillance over an area set by the system.
Overview
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Integrity signals
Registry
Cites
Statistics
Figures
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Drones provide an aerial view; their real-time data and mobility make them valuable tools for enhancing security and improving various aspects of urban management, which are used popularly for purposes such as object and people detection, data collection, general traffic and wildlife monitoring, radio surveillance, and search and rescue operations during disasters [15][16][17][18].”
From A Survey of Video Surveillance Systems in Smart City (2023) · cites this paper as [15]
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Flying Ad-Hoc Networks (FANETs): A survey
Bekmezci, İ., Şahingöz, Ö. K., & Temel, Ş. (2013) · Ad Hoc Networks · doi:10.1016/j.adhoc.2012.12.004 · Cited by 1,525
Networking Models in Flying Ad-Hoc Networks (FANETs): Concepts and Challenges
Şahingöz, Ö. K. (2013) · Journal of Intelligent & Robotic Systems · doi:10.1007/s10846-013-9959-7 · Cited by 398
Autonomous UAV Surveillance in Complex Urban Environments
Semsch, E., Jakob, M., Pavlíček, D., & Pěchouček, M. (2009) · IEEE/WIC/ACM International Conference on Web Intelligence and Intelligent Agent Technology (WI-IAT) · doi:10.1109/wi-iat.2009.132 · Cited by 317
The Design and Implementation of a Wireless Video Surveillance System
Zhang, T., Chowdhery, A., Bahl, P., Jamieson, K., & Banerjee, S. (2015) · ACM Annual International Conference on Mobile Computing and Networking (MobiCom) · doi:10.1145/2789168.2790123 · Cited by 275
Rate adaptation, Congestion Control and Fairness: A Tutorial
Boudec, J. L. (2000) · Cited by 224
The Multiple Unmanned Air Vehicle Persistent Surveillance Problem: A Review
Nigam, N. (2014) · Machines · doi:10.3390/machines2010013 · Cited by 93
Streaming video over HTTP with consistent quality
Li, Z., Begen, A. C., Gahm, J., Shan, Y., Osler, B., & Oran, D. (2014) · ACM Multimedia Systems Conference (MMSys) · doi:10.1145/2557642.2557658 · Cited by 88
Constructing a reliable and fast recoverable network for drones
Lee, J., Kim, K., Yoo, S., Chung, A. Y., Lee, J. Y., Park, S., & Kim, H. (2016) · International Conference on Communications · doi:10.1109/icc.2016.7511317 · Cited by 35
Self-citationUAV surveillance mission planning with gimbaled sensors
Geng, L., Zhang, Y., Wang, P. F., Wang, J., Fuh, J. Y. H., & Teo, S. H. (2014) · International Conference on Control and Automation · doi:10.1109/icca.2014.6870939 · Cited by 25
CCTV Coverage Index Based on Surveillance Resolution and Its Evaluation Using 3D Spatial Analysis
Choi, K., & Lee, I. (2015) · Sensors · doi:10.3390/s150923341 · Cited by 16
Research works printed but not linked: 1
- Stutzman, W.L., and Thiele, G.A. (2012). Antenna Theory and Design, John Wiley & Sons.
Cited by
Sorted by citations
Survey on Anti-Drone Systems: Components, Designs, and Challenges
Park, S., Kim, H. T., Lee, S., Joo, H., & Kim, H. (2021) · IEEE Access · doi:10.1109/access.2021.3065926 · Cited by 332
Self-citationSwarm of UAVs for Network Management in 6G: A Technical Review
Khan, M. A., Kumar, N., Mohsan, S. A. H., Khan, W. U., Nasralla, M. M., Alsharif, M. H., Żywiołek, J., & Ullah, I. (2022) · IEEE Transactions on Network and Service Management · doi:10.1109/tnsm.2022.3213370 · Cited by 264
A Survey of Video Surveillance Systems in Smart City
Myagmar-Ochir, Y., & Kim, W. (2023) · Electronics · doi:10.3390/electronics12173567 · Cited by 134
“…popularly for such as object and people detection, data collection, general traffic and wildlife Crowd-sourcing based on smartphone cameras is not common, but it is a very innovative approach to monitoring the smart city. radio surveillance, and search and rescue operations during disasters [15–18].”
BackgroundDrone Detection and Identification System using Artificial Intelligence
Lee, D., La, W. G., & Kim, H. (2018) · International Conference on Information and Communication Technology Convergence (ICTC) · doi:10.1109/ictc.2018.8539442 · Cited by 120
Self-citationDRONET: Multi-Tasking Framework for Real-Time Industrial Facility Aerial Surveillance and Safety
Ajakwe, S. O., Ihekoronye, V. U., Kim, D., & Lee, J. (2022) · Drones · doi:10.3390/drones6020046 · Cited by 51
UAV Flight and Landing Guidance System for Emergency Situations †
Lee, J. Y., Chung, A. Y., Shim, H., Joe, C., Park, S., & Kim, H. (2019) · Sensors · doi:10.3390/s19204468 · Cited by 36
Self-citationFormation Control Algorithm of Multi-UAV-Based Network Infrastructure
Park, S., Kim, K., Kim, H., & Kim, H. (2018) · Applied Sciences · doi:10.3390/app8101740 · Cited by 31
Self-citationGround Control System Based Routing for Reliable and Efficient Multi-Drone Control System
Lee, W., Lee, J. Y., Lee, J., Kim, K., Yoo, S., Park, S., & Kim, H. (2018) · Applied Sciences · doi:10.3390/app8112027 · Cited by 25
Self-citationAdaptive Drone Identification and Neutralization Scheme for Real-Time Military Tactical Operations
Ajakwe, S. O., Ihekoronye, V. U., Akter, R., Kim, D., & Lee, J. M. (2022) · International Conference on Information Networking · doi:10.1109/icoin53446.2022.9687268 · Cited by 22
Drone Positioning System Using UWB Sensing and Out-of-Band Control
Lee, S., Yoo, S., Lee, J. Y., Park, S., & Kim, H. (2021) · IEEE Sensors Journal · doi:10.1109/jsen.2021.3127233 · Cited by 20
Self-citationAn MPTCP-Based Transmission Scheme for Improving the Control Stability of Unmanned Aerial Vehicles
Lee, W., Lee, J. Y., Joo, H., & Kim, H. (2021) · Sensors · doi:10.3390/s21082791 · Cited by 17
Self-citationEnergy-Efficient Topology Control for UAV Networks
Park, S., Kim, H. T., & Kim, H. (2019) · Energies · doi:10.3390/en12234523 · Cited by 16
Self-citationNaveed, M., Qazi, S., Khawaja, B. A., & Mustaqim, M. (2019) · International Conference on Information and Communication Technologies · doi:10.1109/icict47744.2019.9001975 · Cited by 10
Remote Estimation of Target Height from Unmanned Aerial Vehicle (UAV) Images
Tonini, A., Redweik, P., Paìnho, M., & Castelli, M. (2020) · Remote Sensing · doi:10.3390/rs12213602 · Cited by 9
Naveed, M., Qazi, S., Atif, S. M., Khawaja, B. A., & Mustaqim, M. (2019) · Electronics · doi:10.3390/electronics8080910 · Cited by 8
Adaptive TCP Transmission Adjustment for UAV Network Infrastructure
Lee, J. Y., Lee, W., Kim, H., & Kim, H. (2020) · Applied Sciences · doi:10.3390/app10031161 · Cited by 7
Self-citationVMCS: Elaborating APF-Based Swarm Intelligence for Mission-Oriented Multi-UV Control
Park, S., Kim, H. T., & Kim, H. (2020) · IEEE Access · doi:10.1109/access.2020.3044055 · Cited by 6
Self-citationA review of UAV Visual Detection and Tracking MethodsPreprint
Zitar, R. A., Al-Betar, M. A., Ryalat, M., & Kassaymeh, S. (2023) · arXiv (Cornell University) · doi:10.48550/arxiv.2306.05089 · Cited by 10
Leonov, A. V., & Litvinov, G. A. (2018) · Dynamics of Systems Mechanisms and Machines · doi:10.1109/dynamics.2018.8601494 · Cited by 5
Secure Automated Video Assistance in Vehicular Networks using Unmanned Aerial Vehicles
Salman, A., Oracevic, A., & Ogburn, L. (2022) · IEEE Global Conference on Artificial Intelligence and Internet of Things (GCAIoT) · doi:10.1109/gcaiot57150.2022.10019234 · Cited by 4
Mobile device-centric approach for identifying problem spot in network using deep learning
Lee, W., Lee, J. Y., & Kim, H. (2020) · Journal of Communications and Networks · doi:10.1109/jcn.2020.000008 · Cited by 2
Self-citationEnhancing gas detection-based swarming through deep reinforcement learning
Lee, S., Park, S., & Kim, H. (2022) · The Journal of Supercomputing · doi:10.1007/s11227-022-04478-4 · Cited by 2
Self-citationQoE Analysis of Real-Time Video Streaming over 4G-LTE for UAV-Based Surveillance Applications
Naveed, M., & Qazi, S. (2020) · Communications in computer and information science · doi:10.1007/978-981-15-5232-8_38 · Cited by 2
3D Path Planning Based on Probabilistic Foam for UAV Indoor Applications
Nascimento, L. B. P., dos Santos, V. G., Pereira, D. S., & Alsina, P. J. (2021) · Anais do ... Simpósio Brasileiro de Automação Inteligente/Simpósio Brasileiro de Automação Inteligente · doi:10.20906/sbai.v1i1.2628 · Cited by 1
A Study on High-Efficiency Anti Drone Jammer by Time-Division of Continuous Wave Signal
Shin, S., & Choi, S.-Y. (2020) · The Journal of Korean Institute of Information Technology · doi:10.14801/jkiit.2020.18.12.69
Analyzing the methods of protection against First-Person View drone
(2021) · European Scientific e-Journal · doi:10.47451/inn2024-05-04
Ganganath, G., Thenahandi, P. S., Kankanamge, S. P. K., Hettihewa, D. P. G., Edussooriya, C. U. S., Rodrigo, R., & Thanthrigee, U. S. K. P. M. (2026) · Moratuwa Engineering Research Conference (MERCon) · doi:10.1109/mercon71835.2026.11691413
Rizk, M., Taleb, H., Rhayem, A., Chaaya, J. A., Zaki, C., & Nasser, A. (2026) · Research Square · doi:10.21203/rs.3.rs-8815873/v1
FUS-DETR: a robust algorithm for drone detection from a cluttered background in airborne images
Duan, S., Zhang, G., Li, X., Wang, S., Mao, Z., Hu, B., & Liu, X. (2026) · Applied Intelligence · doi:10.1007/s10489-026-07448-y
Metadata
- Authors
- Jung, J., Yoo, S., La, W. G., Lee, D. R., Bae, M., & Kim, H.
- Affiliations
- Korea University (KR)
- Corresponding author
- Kim, Hwangnam
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2018-06-14
- Volume
- 18
- Issue
- 6
- Pages
- 1939
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC6021840
- OpenAlex
- W2808172345
- Cited by
- 30
- References
- 13
- Citations by year
- 2026: 3 · 2023: 2 · 2022: 5 · 2021: 5 · 2020: 6 · 2019: 4 · 2018: 5
- FWCI
- 4.07
- Type
- journal article
- Language
- en
- Open access
- gold
- dx.doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- Europe PMC (PubMed Central) (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Funders
- Unmanned Vehicles Advanced Core Technology Research and Development Program (NRF-2016M1B3A1A01937599)
- Topics
- Physical Sciences › Engineering › Aerospace Engineering › UAV Applications and Optimization
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Video Surveillance and Tracking Methods
- Physical Sciences › Computer Science › Computer Networks and Communications › Mobile Ad Hoc Networks
- Keywords
- UAV fleet, unmanned aerial vehicles, UAV deployment, multi-hop communication, surveillance coverage
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
