

Underwater Optical-Sonar Image Fusion Systems
Open accessThe DOI matches its Crossref record; 27 of the 30 references it cites were found in a registry or an index; 5 of the 17 sources its claims cite were checked for support.
Abstract
Unmanned underwater operations using remotely operated vehicles or unmanned surface vehicles are increasing in recent times, and this guarantees human safety and work efficiency. Optical cameras and multi-beam sonars are generally used as imaging sensors in underwater environments. However, the obtained underwater images are difficult to understand intuitively, owing to noise and distortion. In this study, we developed an optical and sonar image fusion system that integrates the color and distance information from two different images. The enhanced optical and sonar images were fused using calibrated transformation matrices, and the underwater image quality measure (UIQM) and underwater color image quality evaluation (UCIQE) were used as metrics to evaluate the performance of the proposed system. Compared with the original underwater image, image fusion increased the mean UIQM and UCIQE by 94% and 27%, respectively. The contrast-to-noise ratio was increased six times after applying the median filter and gamma correction. The fused image in sonar image coordinates showed qualitatively good spatial agreement and the average IoU was 75% between the optical and sonar pixels in the fused images. The optical-sonar fusion system will help to visualize and understand well underwater situations with color and distance information for unmanned works.
Overview
CoChat Summary
## TL;DR
The paper develops an underwater optical-sonar fusion system that simultaneously enhances optical and multi-beam sonar images and then merges RGB color with distance information using geometric calibration. On 28 calibration image pairs, fusion improved mean UIQM by 94%, mean UCIQE by 27%, and achieved an average IoU of 75% between optical and sonar pixels in the fused images.
## Key findings
- On 28 calibration image pairs, image fusion increased mean UIQM from 0.56 ± 0.13 to 1.1 ± 0.17, a 94% increase.
- Mean UCIQE increased from 19.96 ± 1.15 to 25.53 ± 2.35, a 27% increase.
- For sonar enhancement, contrast-to-noise ratio increased from 0.33 ± 0.05 to 2.03 ± 0.12 after median filtering and gamma correction, described as a sixfold increase.
- Spatial alignment of fused optical-sonar images was quantified by IoU; average IoU was 75%, with 69% at 5 m and 81% at 6 m.
## Methods
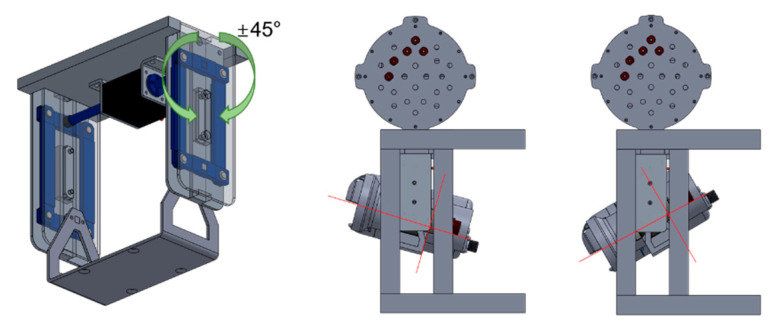
- Built an underwater optical-sonar fusion system with two underwater cameras, a multi-beam sonar, LED lights, a communication case, and a movable bracket with servo motor control.
- Used an RGB phantom in a water tank to collect 28 simultaneous optical and sonar calibration image pairs at multiple distances, depths, and orientations.
- Enhanced optical images with white balancing, CLAHE, and unsharp masking; enhanced sonar images with a median filter and gamma correction; then estimated transformation matrices from paired corner points to fuse the modalities.
## Limitations
- The paper does not report a formal limitation section; this is not stated in the paper.
- Evidence from the text suggests the evaluation was limited to an RGB phantom in a controlled water-tank setup, so generalization to natural underwater scenes is not established; this is inferred from the text.
- Evidence from the text suggests the calibration and fusion results were based on a small number of calibration pairs (28), so robustness beyond the tested conditions is not established; this is inferred from the text.
Model-written summary. Check it against the paper before relying on it.
Integrity signals
Registry
Cites
Statistics
Figures




Verification
Claims the paper makes
3 Valid · 1 Not valid · 5 Not checked · 24 Own results and interpretations
The cited sources support only part of this claim — read each source’s verdict below.
In the paper
“However, these algorithms do not consider the spatial variance of the degradation over the field of view [3,4,5,6].”
§ Underwater Optical-Sonar Image Fusion Systems > 1. Introduction
What the sources say
- Not checked — no full text of the sourcecites [3] 2012, Visual enhancement of underwater images using empirical mode decomposition, Expert Syst. Appl. source
- Not checked — no full text of the sourcecites [4] Hitam, M.S., Awalludin, E.A., Yussof, W.N.J.H.W., and Bachok, Z. (2013, January 20–22). Mixture contrast limited adaptive histogram equalization for underwater image enhancement. Proceedings of the 2013 International conference on computer applications technology (ICCAT), Sousse, Tunisia. source
- Not checked — no full text of the sourcecites [5] Ancuti, 2017, Color balance and fusion for underwater image enhancement, IEEE Trans. Image Process. source
- Partly supportedcites [6] Luo, 2019, An effective underwater image enhancement method based on CLAHE-HF, J. Phys. Conf. Ser. sourceExperimental — accuracy not yet measured
Section 2.1 (page not specified) says global histogram equalization handles areas with different illumination poorly, which supports a narrower point about spatially uneven illumination. It does not establish that conventional underwater-image algorithms generally ignore spatial variation in degradation across the field of view; the same section describes adaptive histogram equalization as using local histograms. (LLM, conf=0.83)
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The image after median filter and gamma correction showed more clear distinction of RGB phantom to the background than the original sonar image.”
§ Underwater Optical-Sonar Image Fusion Systems > 3. Results
plainstates a causeSingle case- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The mean and SD of UIQM and UCIQE of 56 underwater images were 0.56 ± 0.13 and 19.96 ± 1.15, respectively.”
§ Underwater Optical-Sonar Image Fusion Systems > 3. Results
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The CNR for 28 original sonar images was 0.33 ± 0.05 (mean ± SD)”
§ Underwater Optical-Sonar Image Fusion Systems > 3. Results
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“After image fusion enhancement, the increased UIQM and UCIQE were 1.1 ± 0.17 and 25.53 ± 2.35, respectively.”
§ Underwater Optical-Sonar Image Fusion Systems > 3. Results
plainstates a cause- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
18 more claims
Create a free account to see all 33 claims and to verify the 1 reference still open.
- Probably not a substantial claim. 6
- It may state two separate claims as one. 6
Citations
Cites
Human-Visual-System-Inspired Underwater Image Quality Measures
Panetta, K., Gao, C., & Agaian, S. (2016) · IEEE Journal of Oceanic Engineering · doi:10.1109/joe.2015.2469915 · Cited by 1,718 · cited 1×
“In addition, the underwater image quality measure (UIQM) and underwater color image quality evaluation (UCIQE) were computed to quantitatively evaluate the optical color image quality [25,26].”
MethodFast Underwater Image Enhancement for Improved Visual Perception
Islam, M. J., Xia, Y., & Sattar, J. (2020) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2020.2974710 · Cited by 1,675 · cited 1×
“FUnIE-GAN [12] Train fast underwater image enhancement GAN (FUnIE-GAN) to learn global content, color, texture, and style information of underwater images”
BackgroundAn Underwater Color Image Quality Evaluation Metric
Yang, M., & Sowmya, A. (2015) · IEEE Transactions on Image Processing · doi:10.1109/tip.2015.2491020 · Cited by 1,569 · cited 1×
“In addition, the underwater image quality measure (UIQM) and underwater color image quality evaluation (UCIQE) were computed to quantitatively evaluate the optical color image quality [25,26].”
MethodColor balance and fusion for underwater image enhancement
Ancuti, C. O., Ancuti, C., De Vleeschouwer, C., & Bekaert, P. (2018) · IEEE Transactions on Image Processing · doi:10.1109/tip.2017.2759252 · Cited by 1,357 · cited 3×
“Image fusion [5] Apply three successive steps of white balancing, contrast and edge enhancing, and fusing”
BackgroundMethodInfluentialEnhancing Underwater Imagery Using Generative Adversarial Networks
Fabbri, C., Islam, M. J., & Sattar, J. (2018) · 2018 IEEE International Conference on Robotics and Automation (ICRA) · doi:10.1109/icra.2018.8460552 · Cited by 1,071 · cited 1×
“UGAN [10] Train underwater GAN (UGAN) from the paired clean and underwater images to learn the difference between the paired images, and generate enhanced underwater images using the trained UGAN”
MethodAutomatic Red-Channel underwater image restoration
Galdran, A., Pardo, D., Picón, A., & Alvarez-Gila, A. (2015) · Journal of Visual Communication and Image Representation · doi:10.1016/j.jvcir.2014.11.006 · Cited by 995 · cited 1×
“Red channel restoration model [7] Apply a red channel model, which is a variation of DCP, to improve the most attenuated red channel signal of the underwater image”
MethodMixture contrast limited adaptive histogram equalization for underwater image enhancement
Hitam, M. S., Yussof, W. N. J. H. W., Awalludin, E. A., & Bachok, Z. (2013) · 2013 International Conference on Computer Applications Technology (ICCAT) · doi:10.1109/iccat.2013.6522017 · Cited by 484 · cited 1×
“CLAHE-mix [4] Apply CLAHE on the image in RGB and HSV color models and combine two contrast-enhanced images by Euclidean norm”
MethodThe Handbook of Sidescan Sonar
Blondel, P. (2009) · doi:10.1007/978-3-540-49886-5 · Cited by 322
Imaging sonar-aided navigation for autonomous underwater harbor surveillance
Johannsson, H., Kaess, M., Englot, B., Hover, F., & Leonard, J. (2010) · 2010 IEEE/RSJ International Conference on Intelligent Robots and Systems · doi:10.1109/iros.2010.5650831 · Cited by 193 · cited 3×
“Sonar image Median filter [13] Reduce noise in sonar images by median filter”
BackgroundInfluentialContrast-to-noise ratio difference in small field of view cone beam computed tomography machines
Bechara, B., McMahan, C. A., Moore, W. S., Noujeim, M. E., Geha, H., & Teixeira, F. B. (2012) · Journal of Oral Science · doi:10.2334/josnusd.54.227 · Cited by 106 · cited 2×
“In a dition, we calculated the contrast-to-noise ratio (CNR) to evaluate the quality of sonar images using Equation (11) [27].”
Method
Research works printed but not linked: 2
- Mobley, C.D., and Mobley, C.D. (1994). Light and Water: Radiative Transfer in Natural Waters, Academic Press.
- Hartley, R., and Zisserman, A. (2013). Multiple View Geometry in Computer Vision, Cambridge University Press.
Cited by
Deep learning in food category recognition
Zhang, Y., Deng, L., Zhu, H., Wang, W., Ren, Z., Zhou, Q., Lu, S., Sun, S., Zhu, Z., Gorriz, J. M., et al. (2023) · Information Fusion · doi:10.1016/j.inffus.2023.101859 · Cited by 357
Review of intelligent detection and health assessment of underwater structures
Teng, S., Liu, A., Ye, X., Wang, J., Fu, J., Wu, Z., Chen, B., Liu, C., Zhou, H., Zeng, Y., et al. (2024) · Engineering Structures · doi:10.1016/j.engstruct.2024.117958 · Cited by 99
Liu, C., Wen, J., Huang, J., Lin, W., Wu, B., Xie, N., & Zou, T. (2024) · Journal of Marine Science and Engineering · doi:10.3390/jmse12030506 · Cited by 25
Zhang, Y., Jiang, Y. L., Qi, H., Zhao, M., Wang, Y., Wang, K., & Wei, F. (2022) · Sensors · doi:10.3390/s23010197 · Cited by 23
Cai, W., Zhu, J., & Zhang, M. (2025) · Expert Systems with Applications · doi:10.1016/j.eswa.2025.128021 · Cited by 29
A Real-Time Fish Target Detection Algorithm Based on Improved YOLOv5
Li, W., Zhang, Z., Jin, B., et al. (2023) · Journal of Marine Science and Engineering · doi:10.3390/jmse11030572 · Cited by 18
“The operation of unmanned underwater vehicles [2,3], such as autonomous underwater vehicles (AUVs) and remotely operated vehicles (ROVs), can not only reduce the cost of missions, but also provide data support for scientific research [4–7].”
BackgroundZhang, Q., Wang, S., Zhang, T., Ren, G., Zhang, L., Wang, Y., Zheng, B., Li, J., & Zheng, H. (2025) · Computers and Electronics in Agriculture · doi:10.1016/j.compag.2025.111227 · Cited by 21
Dual-Modal Vision–Sonar Object Detection for Underwater Robots Based on Deep Learning
Wang, X., Wang, Z., & Bi, D. (2026) · Journal of Marine Science and Engineering · doi:10.3390/jmse14040338 · Cited by 7
Zhang, Z., Li, H., Li, H., et al. (2026) · Ocean Engineering · doi:10.1016/j.oceaneng.2026.124679 · Cited by 5
Underwater Target Tracking Based on Acoustic-Optical Fusion for Multi-AUV Systems
Yang, Y., Li, Y., Yu, W., et al. (2026) · IEEE Transactions on Network Science and Engineering · doi:10.1109/tnse.2026.3667901 · Cited by 4
Zhaohan, L. I. U., & Su, H. (2026) · Measurement · doi:10.1016/j.measurement.2026.120417 · Cited by 5
Semantic Segmentation of Forward-Looking Sonar Images Based on Improved Deeplabv3+
Yin, F., Nie, W., & Su, Y. (2024) · doi:10.1109/oceans51537.2024.10682240 · Cited by 2
“(2) The reflection and scattering characteristics of sound waves are affected by complex hydroacoustic environment, which lead to strong speckle noise and blurred target edge information in FLS image [14].”
BackgroundEstimating fish quantity and distribution in Offshore cage aquaculture using YOLOv8 and fish density
Sun, P., Huang, X., Sun, J., Tao, Q., Yuan, T., Li, G., Pang, G., Liu, H., & Hu, Y. L. (2025) · Smart Agricultural Technology · doi:10.1016/j.atech.2025.101514 · Cited by 4
Lee, J., Park, J., Hwang, J.-H., et al. (2026) · Remote Sensing · doi:10.3390/rs18050793 · Cited by 1
Bach, N. G., Tan, P. X., & Kamioka, E. (2026) · IEEE Access · doi:10.1109/access.2026.3672274 · Cited by 1
SCFusion: Cross-modality underwater object detection via vision guided sonar–camera feature fusion
He, J., Pang, C., He, Z., Xu, H., & Yu, Y. (2026) · Ocean Engineering · doi:10.1016/j.oceaneng.2026.126793 · Cited by 2
Han, Q. J., Sun, M., Zheng, B., & Fu, M. (2024) · Remote Sensing · doi:10.3390/rs16132429 · Cited by 2
Semernik, I. V., Taraseko, A. A., & Владимировна, С. К. (2025) · Computer Optics · doi:10.18287/2412-6179-co-1520
Grid-Prior Acoustic-Optical Extrinsic Calibration via a Co-Centered Bimodal Calibration Board
Zhang, Y., Wang, H. P., & Hu, H. (2026) · IEEE Transactions on Instrumentation and Measurement · doi:10.1109/tim.2026.3693799
“Representative examples include the AcTag-based marker system [26], composite targets combining ArUco or ChArUco patterns with metallic bolts [24], [25], the RGB calibration boards constructed from colored aluminum and acrylic plates [27].”
Peng, C., Pan, Y., Yang, X., Wang, N., Yu, Z., & Li, G. (2026) · IEEE Journal of Oceanic Engineering · doi:10.1109/joe.2026.3695320 · Cited by 1
“Kim et al. [19] further introduced an optical–sonar image fusion system, demonstrating advantages in color restoration and overall visualization quality.”
Lightweight Underwater Sonar Object Detection via RGB-Guided Heterogeneous Distillation
Qiao, Q., Liu, J., Liu, F., Hao, C., & Ren, T. (2026) · Sensors · doi:10.3390/s26144340 · Cited by 1
“…of improving the performance of compact models by enabling performance transfer under the teacher–student paradigm; Ghost networks [25] reduce redundant computation via cheap feature generation; cross-modal distillation meth-ods attempt to transfer optical semantics to the sonar domain [26–29].”
AOPQ-Net Acoustic–Optical Proposal Query Network for Underwater Multimodal Object Detection
Lu, Y., Zhang, Z., Ding, S., et al. (2026) · Remote Sensing · doi:10.3390/rs18162703
Automated underwater dam damage detection using sonar–camera multimodal image fusion
Tang, P., & Kang, F. (2026) · Automation in Construction · doi:10.1016/j.autcon.2026.107216
LLSU: Joint Low-Light Enhancement and 3-D Gaussian Splatting for Underwater Visual Sensing
Zou, S., Wang, K., Xu, H., et al. (2026) · IEEE Sensors Journal · doi:10.1109/jsen.2026.3724206
“D modeling [5].”
Xiang, Y., Wang, Y., Dai, B., Chen, Z., Zhu, Y., Shen, G., Hu, J., & Chen, S. (2026) · Communications Engineering · doi:10.1038/s44172-026-00781-7
Metadata
- Authors
- Kim, H.-G., Seo, J., & Kim, S. M.
- Affiliations
- Korea Institute of Ocean Science and Technology (KR)
- Corresponding author
- Kim, Soo Mee
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2022-11-03
- Volume
- 22
- Issue
- 21
- Pages
- 8445
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC9655726
- OpenAlex
- W4309089949
- Semantic Scholar
- a98e0c9cf8730d7f45b514ee4e7d9534f96c3929
- Cited by
- 29
- References
- 30
- Citations by year
- 2026: 17 · 2025: 5 · 2024: 4 · 2023: 2 · 2022: 1
- FWCI
- 1.17
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Funders
- National Research Foundation of Korea (NRF-2021R1A2C2006682, 20210658, PEA0032)
- Ministry of Oceans and Fisheries (NRF-2021R1A2C2006682, 20210658, PEA0032)
- Korea Institute of Ocean Science and Technology (NRF-2021R1A2C2006682, 20210658, PEA0032)
- Topics
- Physical Sciences › Engineering › Media Technology › Advanced Image Fusion Techniques
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Image Enhancement Techniques
- Physical Sciences › Engineering › Ocean Engineering › Underwater Vehicles and Communication Systems
- Keywords
- underwater imaging, multibeam echosounder, remotely operated vehicle, underwater image quality, image registration, median filter, gamma correction
- MeSH terms
- Humans, Noise, Sound, Optical Devices
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
The claim verdicts this report counts are experimental: their accuracy is not yet measured.
A language model drew the claims from the paper on 2026-10-10, under version 3 of the claim definition (model deepseek-v4.1-flash, prompt extract-v3).
A second model labelled each claim on 2026-10-10 (model jev-1.13-20260917, definition revision gold-guideline-v0.2).
Cited sources are checked with a language model’s help (gpt-6-sol).
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
