

Fuzzy Gain-Scheduling PID for UAV Position and Altitude Controllers
Open accessThe DOI matches its Crossref record; 46 of the 46 references it cites were found in a registry or an index.
Abstract
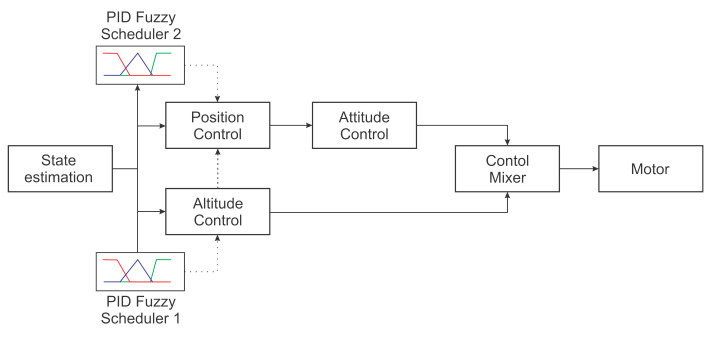
Unmanned aerial vehicle (UAV) applications have evolved to a wide range of fields in the last decade. One of the main challenges in autonomous tasks is the UAV stability during maneuvers. Thus, attitude and position control play a crucial role in stabilizing the vehicle in the desired orientation and path. Many control techniques have been developed for this. However, proportional integral derivative (PID) controllers are often used due their structure and efficiency. Despite PID’s good performance, different requirements may be present at different mission stages. The main contribution of this research work is the development of a novel strategy based on a fuzzy-gain scheduling mechanism to adjust the PID controller to stabilize both position and altitude. This control strategy must be effective, simple, and robust to uncertainties and external disturbances. The Robot Operating System (ROS) integrates the proposed system and the flight control unit. The obtained results showed that the proposed approach was successfully applied to the trajectory tracking and revealed a good performance compared to conventional PID and in the presence of noises. In the tests, the position controller was only affected when the altitude error was higher, with an error of 2% lower.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures






Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Robust Backstepping Sliding Mode Control and Observer-based Fault Estimation for a Quadrotor UAV
Chen, F., Jiang, R., Zhang, K., Jiang, B., & Tao, G. (2016) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2016.2552151 · Cited by 642 · cited 1×
“Most of these works are based on fuzzy logic [15,16], sliding-mode controller (SMC) [17], neural network-based control [18], backstepping-based adaptive control [19], and a linear quadratic regulator (LQR) [20], among others.”
BackgroundIdrissi, M., Salami, M., & Annaz, F. (2022) · Journal of Intelligent & Robotic Systems · doi:10.1007/s10846-021-01527-7 · Cited by 345 · cited 1×
“The quadrotor altitude control design is well researched in many works [47,48].”
BackgroundA Survey on Load Transportation Using Multirotor UAVs
Villa, D. K. D., Brandão, A. S., & Sarcinelli-Filho, M. (2020) · Journal of Intelligent & Robotic Systems · doi:10.1007/s10846-019-01088-w · Cited by 247 · cited 1×
“These aerial systems are being applied in a wide range of practical applications, such as inspection [2,3], surveillance [4,5], search and rescue [6,7], cargo transportation [8], etc.”
BackgroundUAV-Assisted Wireless Localization for Search and Rescue
Atif, M., Ahmad, R., Ahmad, W., Zhao, L., & Rodrigues, J. J. P. C. (2021) · IEEE Systems Journal · doi:10.1109/jsyst.2020.3041573 · Cited by 167 · cited 1×
“These aerial systems are being applied in a wide range of practical applications, such as inspection [2,3], surveillance [4,5], search and rescue [6,7], cargo transportation [8], etc.”
BackgroundDesign and implementation of a hybrid fuzzy logic controller for a quadrotor VTOL vehicle
Erginer, B., & Altuğ, E. (2012) · International Journal of Control Automation and Systems · doi:10.1007/s12555-012-0107-0 · Cited by 126 · cited 1×
“In the work of [38], the authors evaluated the performance between the hybrid fuzzy logic PD controller and classical PD controller.”
MethodSelf-Tuning Neural Network PID With Dynamic Response Control
Rodríguez-Abreo, O., Rodríguez‐Reséndiz, J., Fuentes-Silva, C., Hernández-Alvarado, R., & Falcón, M. D. C. P. T. (2021) · IEEE Access · doi:10.1109/access.2021.3075452 · Cited by 101 · cited 1×
“To improve the UAV flight performance, several researchers proposed advanced approaches for stabilizing the attitude and improving the UAV positions and tracking [13,14].”
MethodAmoozgar, M. H., Chamseddine, A., & Zhang, Y. M. (2012) · IFAC Proceedings Volumes · doi:10.3182/20120328-3-it-3014.00048 · Cited by 99 · cited 1×
“[37] proposed the use of an adaptive PID controller for fault-tolerant control and a fuzzy inference scheme for real-time tuning of PID controller gains.”
MethodComparison of PD, PID and Sliding-Mode Position Controllers for V–Tail Quadcopter Stability
Castillo-Zamora, J. D. J., Camarillo-Gómez, K. A., Perez-Soto, G. I., & Rodríguez‐Reséndiz, J. (2018) · IEEE Access · doi:10.1109/access.2018.2851223 · Cited by 99 · cited 1×
“To improve the UAV flight performance, several researchers proposed advanced approaches for stabilizing the attitude and improving the UAV positions and tracking [13,14].”
MethodNovel Fuzzy PID-Type Iterative Learning Control for Quadrotor UAV
Dong, J., & He, B. (2018) · Sensors · doi:10.3390/s19010024 · Cited by 87
Eltayeb, A., Rahmat, M. F., Basri, M. A. M., Eltoum, M. A. M., & Ferik, S. E. (2020) · IEEE Access · doi:10.1109/access.2020.3037557 · Cited by 83 · cited 2×
“Most of these works are based on fuzzy logic [15,16], sliding-mode controller (SMC) [17], neural network-based control [18], backstepping-based adaptive control [19], and a linear quadratic regulator (LQR) [20], among others.”
Background
Research works printed but not linked: 3
- Biundini, I.Z., Melo, A.G., Pinto, M.F., Marins, G.M., Marcato, A.L., and Honorio, L.M. Coverage Path Planning Optimization for Slopes and Dams Inspection. Proceedings of the Iberian Robotics Conference.
- Fernández, R.A.S., Dominguez, S., and Campoy, P. (2017, January 13–16). L1 adaptive control for wind gust rejection in quad-rotor uav wind turbine inspection. Proceedings of the 2017 International Conference on Unmanned Aircraft Systems (ICUAS), Miami, FL, USA.
- Sharma, 2012, Controlling of quad-rotor uav using pid controller and fuzzy logic controller, Int. J. Electr. Electron. Comput. Eng., 1, 38
Cited by
Yang, C., Zuo, Y., Lu, W., & Wang, T. (2025) · Nonlinear Dynamics · doi:10.1007/s11071-025-11197-x · Cited by 97
“Melo et al. [10] proposed an effective and simple PID controller tuning strategy to make the position and altitude stable using a fuzzy gain scheduling mechanism.”
Berger, G. S., Teixeira, M. A. S., Cantieri, Á. R., Lima, J., Pereira, A. I., Valente, A. L. G., de Castro, G. G. R., & Pinto, M. F. (2023) · Agriculture · doi:10.3390/agriculture13020239 · Cited by 73
Self-citationA Review of Modeling and Control Techniques for Unmanned Aerial Vehicles
Gedefaw, E. A., Abera, N. B., & Abdissa, C. M. (2025) · Engineering Reports · doi:10.1002/eng2.70215 · Cited by 54
Madebo, N. W. (2025) · IEEE Access · doi:10.1109/access.2025.3532743 · Cited by 46
“In reference [29], the authors address the challenges of maintaining UAV stability during autonomous maneuvers, with a focus on attitude and position control.”
Understanding and Securing the Risks of Uncrewed Aerial Vehicle Services
Anagnostis, I., Kotzanikolaou, P., & Douligeris, C. (2025) · IEEE Access · doi:10.1109/access.2025.3549861 · Cited by 42
Metadata
- Authors
- Melo, A. G., Andrade, F. A. A., Guedes, I. P., Carvalho, G. F., Zachi, A. R. L., & Pinto, M. F.
- Affiliations
- Department of Electrical Engineering, Federal University of Juiz de Fora, Juiz de Fora 36036-900, Brazil
- University of South-Eastern Norway (NO)
- Federal Center for Technological Education Celso Suckow da Fonseca (BR)
- Corresponding author
- Andrade, Fabio A. A.
- ORCID
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2022-03-10
- Volume
- 22
- Issue
- 6
- Pages
- 2173
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC8954855
- OpenAlex
- W4220953675
- Cited by
- 52
- References
- 46
- Citations by year
- 2026: 13 · 2025: 13 · 2024: 15 · 2023: 9 · 2022: 2
- FWCI
- 4.34
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- NORA - Norwegian Open Research Archives (submittedVersion, other-oa)
- Funders
- Fundação Carlos Chagas Filho de Amparo à Pesquisa do Estado do Rio de Janeiro (001)
- National Council for Scientific and Technological Development (001)
- Topics
- Physical Sciences › Engineering › Aerospace Engineering › Aerospace Engineering and Control Systems
- Physical Sciences › Engineering › Control and Systems Engineering › Adaptive Control of Nonlinear Systems
- Physical Sciences › Computer Science › Artificial Intelligence › Fuzzy Logic and Control Systems
- Keywords
- fuzzy gain scheduling, PID control, unmanned aerial vehicles, trajectory tracking, attitude control, flight control, Robot Operating System, robustness to disturbances
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
How to cite
Cite CoChat for the checks on this page, and the paper for its own findings.
- This page
- CoChat. (2026). Citation check: Fuzzy Gain-Scheduling PID for UAV Position and Altitude Controllers. https://app.cochat.ai/papers/10.3390/s22062173
- The paper
- Melo, A. G., Andrade, F. A. A., Guedes, I. P., Carvalho, G. F., Zachi, A. R. L., & Pinto, M. F. (2022). Fuzzy Gain-Scheduling PID for UAV Position and Altitude Controllers. Sensors. https://doi.org/10.3390/s22062173
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
