

The DOI matches its Crossref record; 41 of the 41 references it cites were found in a registry or an index.
Spacecraft Homography Pose Estimation with Single-Stage Deep Convolutional Neural Network
Open accessAbstract
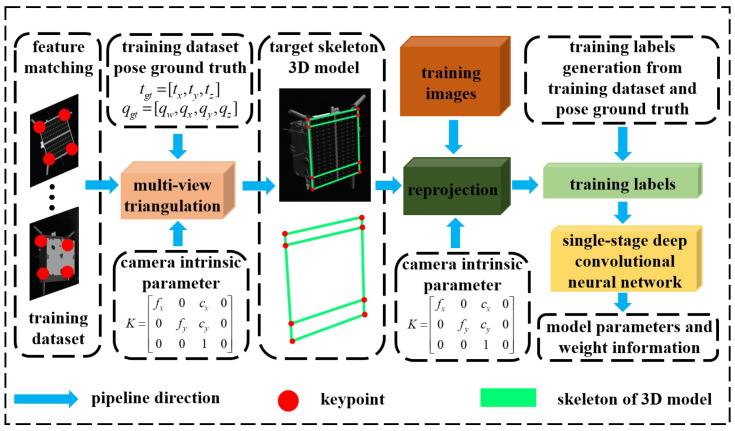
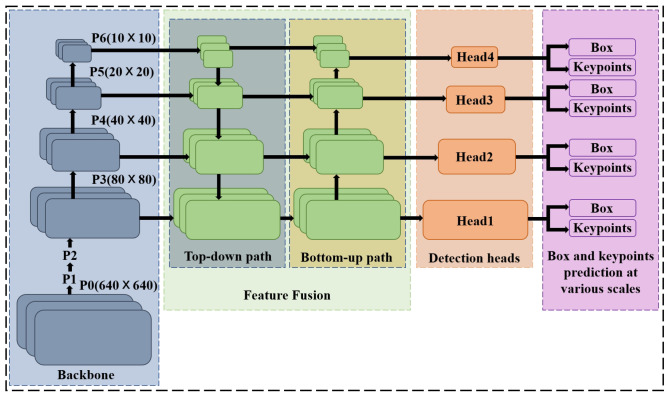
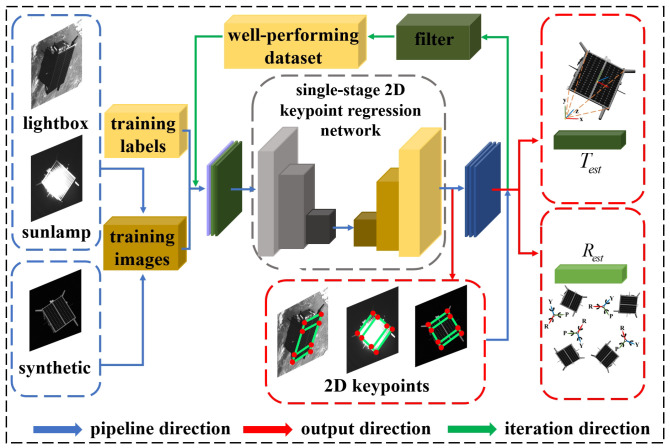
Spacecraft pose estimation using computer vision has garnered increasing attention in research areas such as automation system theory, control theory, sensors and instruments, robot technology, and automation software. Confronted with the extreme environment of space, existing spacecraft pose estimation methods are predominantly multi-stage networks with complex operations. In this study, we propose an approach for spacecraft homography pose estimation with a single-stage deep convolutional neural network for the first time. We formulated a homomorphic geometric constraint equation for spacecraft with planar features. Additionally, we employed a single-stage 2D keypoint regression network to obtain homography 2D keypoint coordinates for spacecraft. After decomposition to obtain the rough spacecraft pose based on the homography matrix constructed according to the geometric constraint equation, a loss function based on pixel errors was employed to refine the spacecraft pose. We conducted extensive experiments using widely used spacecraft pose estimation datasets and compared our method with state-of-the-art techniques in the field to demonstrate its effectiveness.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures

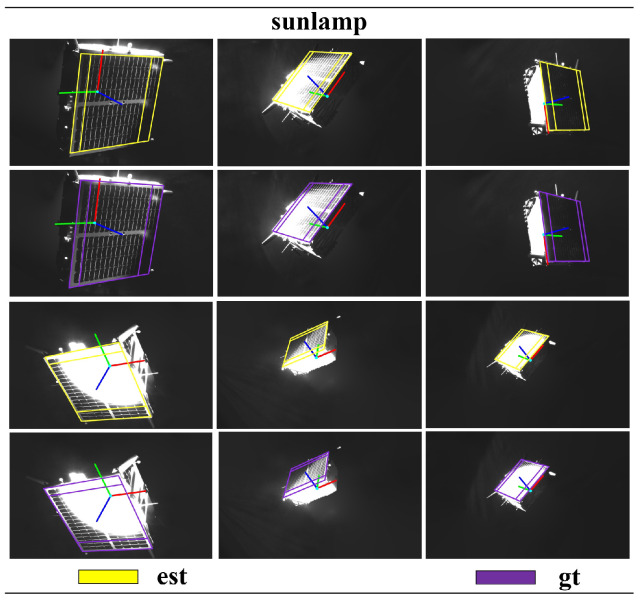
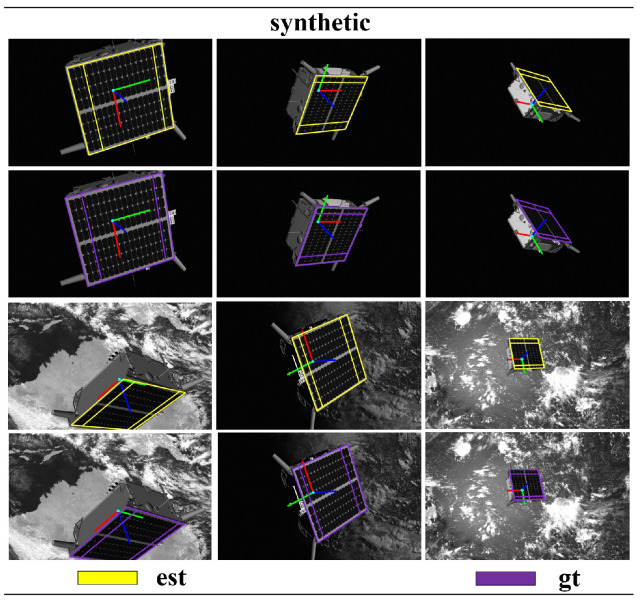
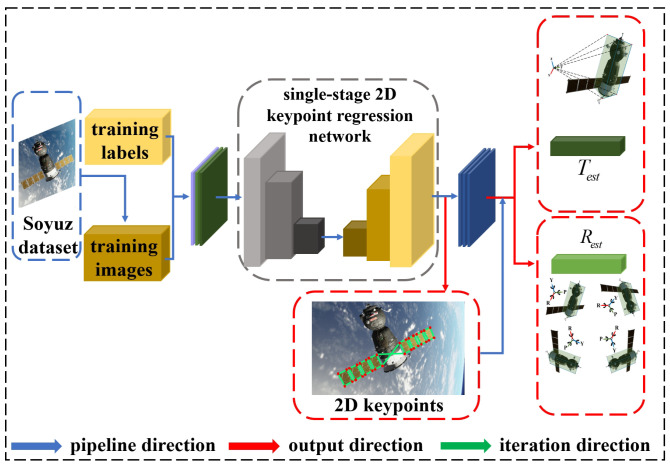
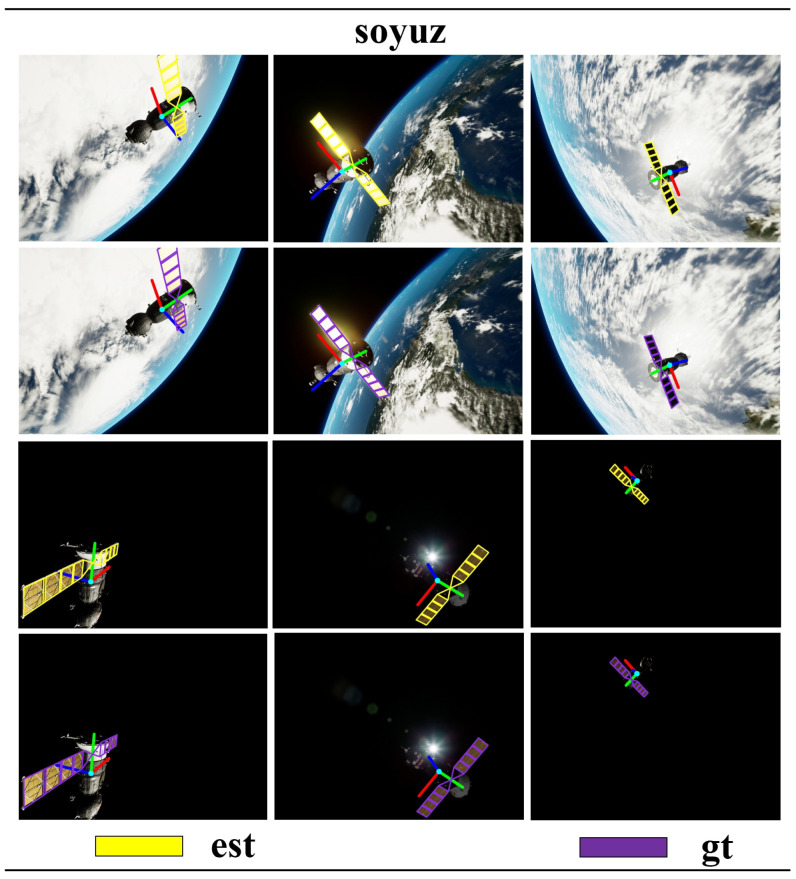

Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Consequently, many researchers [8,9,11,14-16] have adopted approaches that combine keypoints detection with existing Perspective-n-Point (PnP) pose estimation solvers.”
From Pose Estimation for Cross-Domain Non-Cooperative Spacecraft Based on Spatial-Aware Keypoints Regression (2024) · cites this paper as [9]
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Distinctive Image Features from Scale-Invariant Keypoints
Lowe, D. G. (2004) · International Journal of Computer Vision · doi:10.1023/b:visi.0000029664.99615.94 · Cited by 55,589 · cited 1×
“Examples of such feature extraction methods include SIFT [5], FAST [6], SURF [7], ORB [8], FPFH [9], etc.”
MethodMicrosoft COCO: Common Objects in Context
Lin, T.-Y., Maire, M., Belongie, S., Hays, J., Perona, P., Ramanan, D., Dollár, P., & Zitnick, C. L. (2014) · Lecture Notes in Computer Science · doi:10.1007/978-3-319-10602-1_48 · Cited by 45,460
SURF: Speeded Up Robust Features
Bay, H., Tuytelaars, T., & Van Gool, L. (2006) · Lecture Notes in Computer Science · doi:10.1007/11744023_32 · Cited by 14,955 · cited 1×
“Examples of such feature extraction methods include SIFT [5], FAST [6], SURF [7], ORB [8], FPFH [9], etc.”
MethodYOLOv7: Trainable Bag-of-Freebies Sets New State-of-the-Art for Real-Time Object Detectors
Wang, C.-Y., Bochkovskiy, A., & Liao, H.-Y. M. (2023) · 2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr52729.2023.00721 · Cited by 13,198
ORB: An efficient alternative to SIFT or SURF
Rublee, E., Rabaud, V., Konolige, K., & Bradski, G. (2011) · 2011 International Conference on Computer Vision · doi:10.1109/iccv.2011.6126544 · Cited by 11,037
Path Aggregation Network for Instance Segmentation
Liu, S., Qi, L., Qin, H., Shi, J., & Jia, J. (2018) · 2018 IEEE/CVF Conference on Computer Vision and Pattern Recognition · doi:10.1109/cvpr.2018.00913 · Cited by 10,011
Deep High-Resolution Representation Learning for Human Pose Estimation
Sun, K., Xiao, B., Liu, D., & Wang, J. (2019) · 2019 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2019.00584 · Cited by 5,984
Distance-IoU Loss: Faster and Better Learning for Bounding Box Regression
Zheng, Z., Wang, P., Liu, W., Li, J., Ye, R., & Ren, D. (2020) · Proceedings of the AAAI Conference on Artificial Intelligence · doi:10.1609/aaai.v34i07.6999 · Cited by 5,288
CSPNet: A New Backbone that can Enhance Learning Capability of CNN
Wang, C.-Y., Mark Liao, H.-Y., Wu, Y.-H., Chen, P.-Y., Hsieh, J.-W., & Yeh, I.-H. (2020) · 2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops (CVPRW) · doi:10.1109/cvprw50498.2020.00203 · Cited by 5,265
Machine Learning for High-Speed Corner Detection
Rosten, E., & Drummond, T. (2006) · Lecture Notes in Computer Science · doi:10.1007/11744023_34 · Cited by 4,555
Research works printed but not linked: 1
- Sharma, S., and D’Amico, S. (2019). Pose estimation for non-cooperative rendezvous using neural networks. arXiv. · DOI · Paper page
Cited by
Bridging the Domain Gap for Flight-Ready Spaceborne Vision
Park, T. H., & D’Amico, S. (2025) · Journal of Spacecraft and Rockets · doi:10.2514/1.a36130 · Cited by 18
Feng, S., Dong-Yan, J., Cui, W., Wang, T., & Ma, M. (2025) · IEEE Sensors Journal · doi:10.1109/jsen.2025.3615727 · Cited by 8
Online Test-Time Adaptation for On-Orbit Noncooperative Spacecraft Pose Estimation
Feng, S., Wang, T., Guo, Y., & Qiu, J. (2025) · IEEE Transactions on Aerospace and Electronic Systems · doi:10.1109/taes.2025.3623610 · Cited by 13
Wang, Z., Liu, Y., & Zhang, E. (2024) · Aerospace · doi:10.3390/aerospace11110948 · Cited by 5
VIPE: Visible and Infrared Fused Pose Estimation Framework for Space Noncooperative Objects
Zhang, Z., Zhou, D. X., Hu, Y., Ma, W., Sun, G., & Zhang, Y. (2025) · Sensors · doi:10.3390/s25216664 · Cited by 3
Metadata
- Authors
- Chen, S., Yang, W., Wang, W., Mai, J., Liang, J., & Zhang, X.
- Affiliations
- Sun Yat-sen University (CN)
- Corresponding author
- Zhang, Xiaohu
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2024-03-12
- Volume
- 24
- Issue
- 6
- Pages
- 1828
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC10974870
- OpenAlex
- W4392752914
- Cited by
- 12
- References
- 39
- Citations by year
- 2026: 4 · 2025: 7 · 2024: 1
- FWCI
- 2.06
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion)
- Funders
- Sun Yat-sen University
- Topics
- Physical Sciences › Engineering › Aerospace Engineering › Space Satellite Systems and Control
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Advanced Neural Network Applications
- Physical Sciences › Engineering › Aerospace Engineering › Spacecraft Dynamics and Control
- Keywords
- spacecraft pose estimation, homography, planar features
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
How to cite
Cite CoChat for the checks on this page, and the paper for its own findings.
- This page
- CoChat. (2026). Citation check: Spacecraft Homography Pose Estimation with Single-Stage Deep Convolutional Neural Network. https://app.cochat.ai/papers/10.3390/s24061828
- The paper
- Chen, S., Yang, W., Wang, W., Mai, J., Liang, J., & Zhang, X. (2024). Spacecraft Homography Pose Estimation with Single-Stage Deep Convolutional Neural Network. Sensors. https://doi.org/10.3390/s24061828
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
