

The DOI matches its Crossref record; 34 of the 34 references it cites were found in a registry or an index.
Dynamic grasp and trajectory planning for moving objects
Open accessAbstract
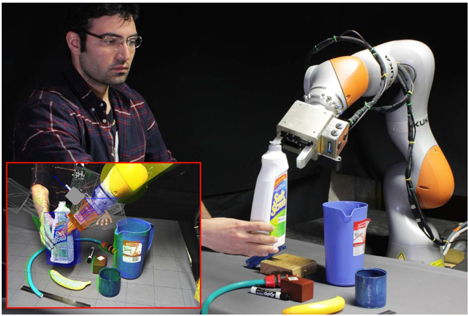
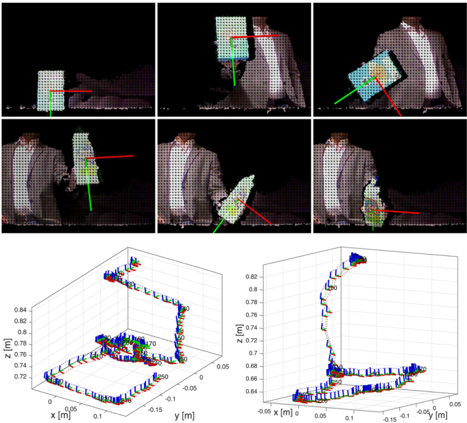
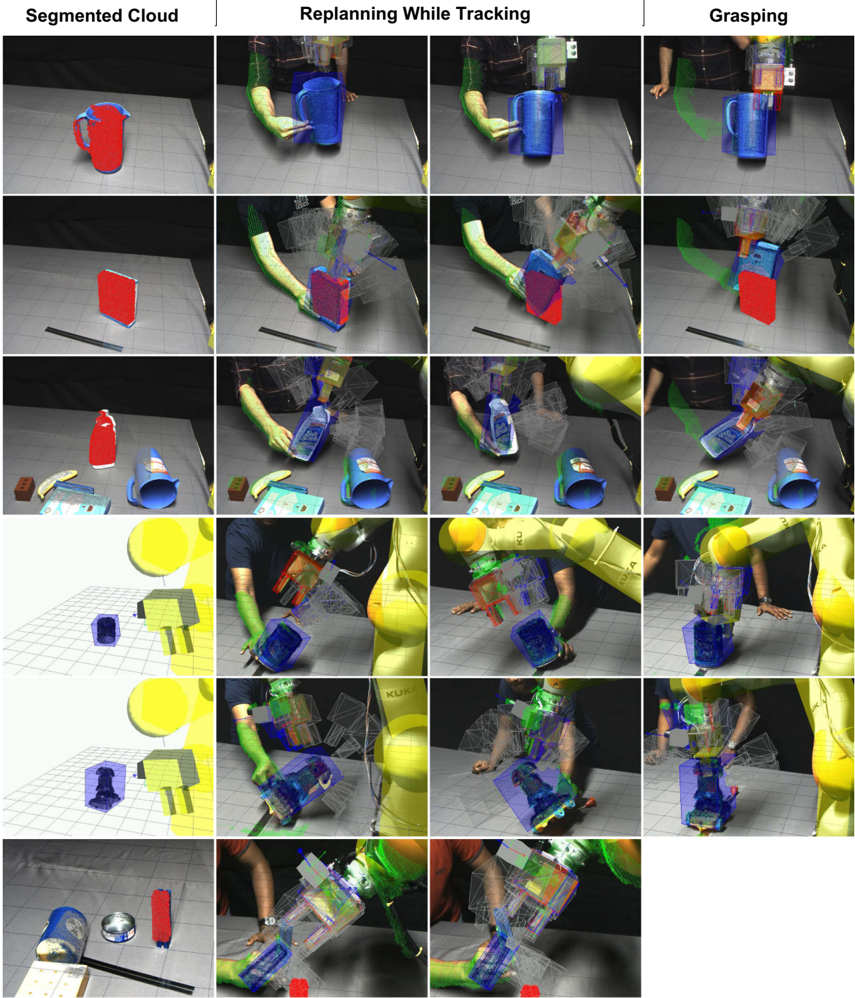
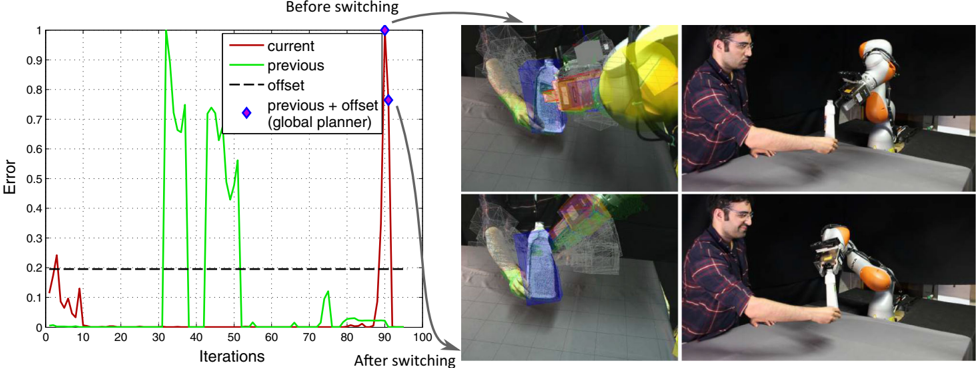
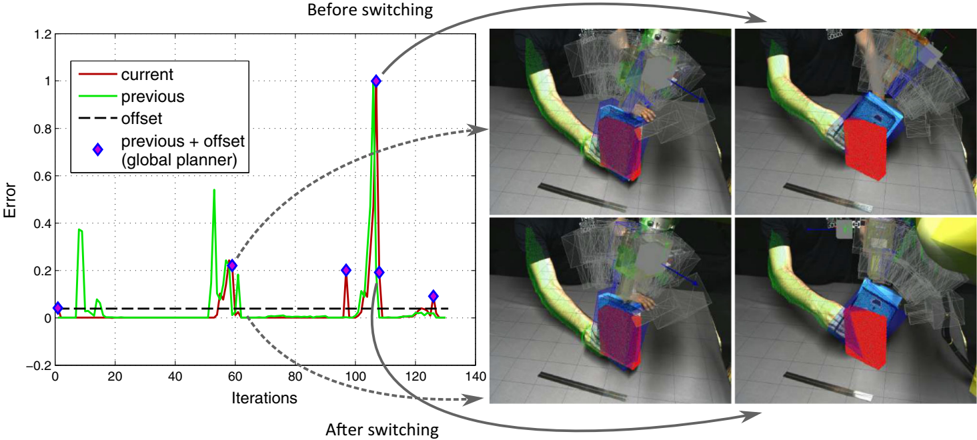
This paper shows how a robot arm can follow and grasp moving objects tracked by a vision system, as is needed when a human hands over an object to the robot during collaborative working. While the object is being arbitrarily moved by the human co-worker, a set of likely grasps, generated by a learned grasp planner, are evaluated online to generate a feasible grasp with respect to both: the current configuration of the robot respecting the target grasp; and the constraints of finding a collision-free trajectory to reach that configuration. A task-based cost function enables relaxation of motion-planning constraints, enabling the robot to continue following the object by maintaining its end-effector near to a likely pre-grasp position throughout the object’s motion. We propose a method of dynamic switching between: a local planner, where the hand smoothly tracks the object, maintaining a steady relative pre-grasp pose; and a global planner, which rapidly moves the hand to a new grasp on a completely different part of the object, if the previous graspable part becomes unreachable. Various experiments are conducted using a real collaborative robot and the obtained results are discussed.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The cited source says what the claim attributes to it.
In the citing paper
“To account for that we have set a hysteresis to the switching strategy, i.e. , we only change the control reference pose if the new grasp ranking has improved at least by a switching threshold δ [7]. This strategy allows to have a smooth and dynamic reachto-grasp trajectory by using the closest best grasp candidate available.”
From Dual Quaternion-Based Visual Servoing for Grasping Moving Objects (2021) · cites this paper as [7]
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Online Object Tracking: A Benchmark
Wu, Y., Lim, J., & Yang, M.-H. (2013) · 2013 IEEE Conference on Computer Vision and Pattern Recognition · doi:10.1109/cvpr.2013.312 · Cited by 4,138 · cited 2×
“Even though this type of visual object tracking is not new, many researchers in the fields of computer vision and robotics have previously proved their robustness and adaptivity in case of solving challenging problems (Fukui et al. 2016; Marturi et al. 2015; Wu et al. 2013).”
BackgroundEfficient variants of the ICP algorithm
Rusinkiewicz, S., & Levoy, M. (2002) · Proceedings Third International Conference on 3-D Digital Imaging and Modeling · doi:10.1109/im.2001.924423 · Cited by 3,945 · cited 2×
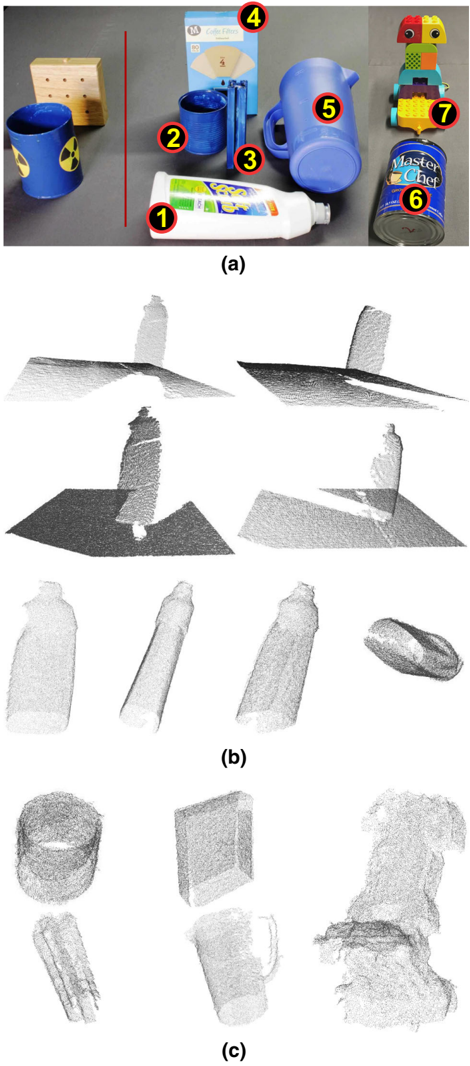
“Alternatively, the stitching accuracy can also be improved using cloud registration algorithms like iterative closest point (ICP) (Rusinkiewicz and Levoy 2001), threedimensionalnormaldistribution(Magnusson2009)etc. Figure 3c shows registered partial point clouds of various test objects.”
BackgroundMethodDeep learning for detecting robotic grasps
Lenz, I., Lee, H., & Saxena, A. (2015) · The International Journal of Robotics Research · doi:10.1177/0278364914549607 · Cited by 1,634
Magnusson, M. (2009) · KTH Publication Database DiVA (KTH Royal Institute of Technology) · Cited by 547
Automated tracking and grasping of a moving object with a robotic hand-eye system
Allen, P. K., Timcenko, A., Yoshimi, B., & Michelman, P. (1993) · IEEE Transactions on Robotics and Automation · doi:10.1109/70.238279 · Cited by 446
Grasp quality measures: review and performance
Roa, M. A., & Suárez, R. (2015) · Autonomous Robots · doi:10.1007/s10514-014-9402-3 · Cited by 445
Human-Inspired Robotic Grasp Control With Tactile Sensing
Romano, J. M., Hsiao, K., Niemeyer, G., Chitta, S., & Kuchenbecker, K. J. (2011) · IEEE Transactions on Robotics · doi:10.1109/tro.2011.2162271 · Cited by 413 · cited 1×
“Alternatively, the stitching accuracy can also be improved using cloud registration algorithms like iterative closest point (ICP) (Rusinkiewicz and Levoy 2001), three dimensional normal distribution (Magnusson 2009) etc. Figure 3c shows registered partial point clouds of various test objects.”
MethodTutorial: Point Cloud Library: Three-Dimensional Object Recognition and 6 DOF Pose Estimation
Aldoma, A., Marton, Z.-C., Tombari, F., Wohlkinger, W., Potthast, C., Zeisl, B., Rusu, R. B., Gedikli, S., & Vincze, M. (2012) · IEEE Robotics & Automation Magazine · doi:10.1109/mra.2012.2206675 · Cited by 345
Learning Hand-Eye Coordination for Robotic Grasping with Large-Scale Data Collection
Levine, S., Pastor, P., Krizhevsky, A., & Quillen, D. (2017) · Springer Proceedings in Advanced Robotics · doi:10.1007/978-3-319-50115-4_16 · Cited by 274 · cited 1×
“…a variety of grasping sub-problems, including: graspsynthesis basedonanalytical or data-drivenapproaches (Kopicki et al. 2016; Lenz et al. 2015; Levine et al. 2016; Roa andSuárez2015);graspcontrolwithtactilesensing(Romano et al. 2011); reactive grasping dealing with uncertainty in object…”
BackgroundKim, S., Shukla, A., & Billard, A. (2014) · IEEE Transactions on Robotics · doi:10.1109/tro.2014.2316022 · Cited by 220
Research works printed but not linked: 1
- Fontanals, J., Dang-Vu, B. A., Porges, O., Rosell, J., & Roa, M. A. (2014b). Integrated grasp and motion planning using independent contact regions. In Proceedings of the IEEE-RAS International Conference on Humanoid Robots, pp. 887–893. https://doi.org/10.1109/HUMANOIDS.2014.7041469 . · DOI
Cited by
Recycling lithium-ion batteries from electric vehicles
Harper, G., Sommerville, R., Kendrick, E., Driscoll, L., Slater, P., Stolkin, R., Walton, A., Christensen, P., Heidrich, O., Lambert, S., et al. (2019) · Nature · doi:10.1038/s41586-019-1682-5 · Cited by 3,890
Self-citationAnyGrasp: Robust and Efficient Grasp Perception in Spatial and Temporal Domains
Fang, H.-S., Wang, C., Fang, H., Gou, M., Liu, J., Yan, H., Liu, W., Xie, Y., & Lu, C. (2023) · IEEE Transactions on Robotics · doi:10.1109/tro.2023.3281153 · Cited by 276
“In order to extend to the dynamic scene, classic methods usually require prior information about the objects [34], [35], [36], or operate on a fixed set of grasp trajectories [37].”
BackgroundObject Handovers: A Review for Robotics
Ortenzi, V., Cosgun, A., Pardi, T., Chan, W. P., Croft, E., & Kulic, D. (2021) · IEEE Transactions on Robotics · doi:10.1109/tro.2021.3075365 · Cited by 198
Reactive Human-to-Robot Handovers of Arbitrary Objects
Yang, W., Paxton, C., Mousavian, A., Chao, Y.-W., Çakmak, M., & Fox, D. (2021) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra48506.2021.9561170 · Cited by 93
A review of recent trend in motion planning of industrial robots
Tamizi, M. G., Yaghoubi, M., & Najjaran, H. (2023) · International Journal of Intelligent Robotics and Applications · doi:10.1007/s41315-023-00274-2 · Cited by 91
Metadata
- Authors
- Marturi, N., Kopicki, M., Rastegarpanah, A., Rajasekaran, V., Adjigble, M., Stolkin, R., Leonardis, A., & Bekiroglu, Y.
- Affiliations
- KUKA (United Kingdom) (GB)
- University of Birmingham (GB)
- Corresponding author
- Marturi, Naresh
- ORCID
- Venue
- Autonomous Robots
- Published
- 2018-08-20
- Volume
- 43
- Issue
- 5
- Pages
- 1241-1256
- ISSN
- 0929-5593 (ISSN-L)
- 1573-7527
- OpenAlex
- W2888704052
- Cited by
- 104
- References
- 34
- Citations by year
- 2026: 9 · 2025: 18 · 2024: 22 · 2023: 18 · 2022: 11 · 2021: 12 · 2020: 8 · 2019: 5 · 2018: 1
- FWCI
- 4.02
- Type
- journal article
- Language
- en
- Open access
- hybrid
- doi.org
- Licence
- cc-by
- creativecommons.org/licenses/by/4.0 (tdm)
- Locations
- Autonomous Robots (publishedVersion, cc-by)
- University of Birmingham Research Portal (University of Birmingham) (submittedVersion, cc-by)
- Chalmers Research (Chalmers University of Technology) (submittedVersion)
- Funders
- Horizon 2020 Framework Programme (645582)
- Innovate UK (GB) (9573)
- Engineering and Physical Sciences Research Council (EP/M026477/1)
- Topics
- Physical Sciences › Engineering › Control and Systems Engineering › Robot Manipulation and Learning
- Physical Sciences › Engineering › Control and Systems Engineering › Robotic Mechanisms and Dynamics
- Physical Sciences › Engineering › Biomedical Engineering › Soft Robotics and Applications
- Keywords
- dynamic grasping, moving object tracking, robot arm trajectory planning, human-robot collaboration, collision-free motion planning, collaborative robots
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
How to cite
Cite CoChat for the checks on this page, and the paper for its own findings.
- This page
- CoChat. (2026). Citation check: Dynamic grasp and trajectory planning for moving objects. https://app.cochat.ai/papers/10.1007/s10514-018-9799-1
- The paper
- Marturi, N., Kopicki, M., Rastegarpanah, A., Rajasekaran, V., Adjigble, M., Stolkin, R., Leonardis, A., & Bekiroglu, Y. (2019). Dynamic grasp and trajectory planning for moving objects. Autonomous Robots. https://doi.org/10.1007/s10514-018-9799-1
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
