

The DOI matches its Crossref record; 59 of the 59 references it cites were found in a registry or an index.
Embodied large language models enable robots to complete complex tasks in unpredictable environments
Open accessPublished version of a preprint
Abstract
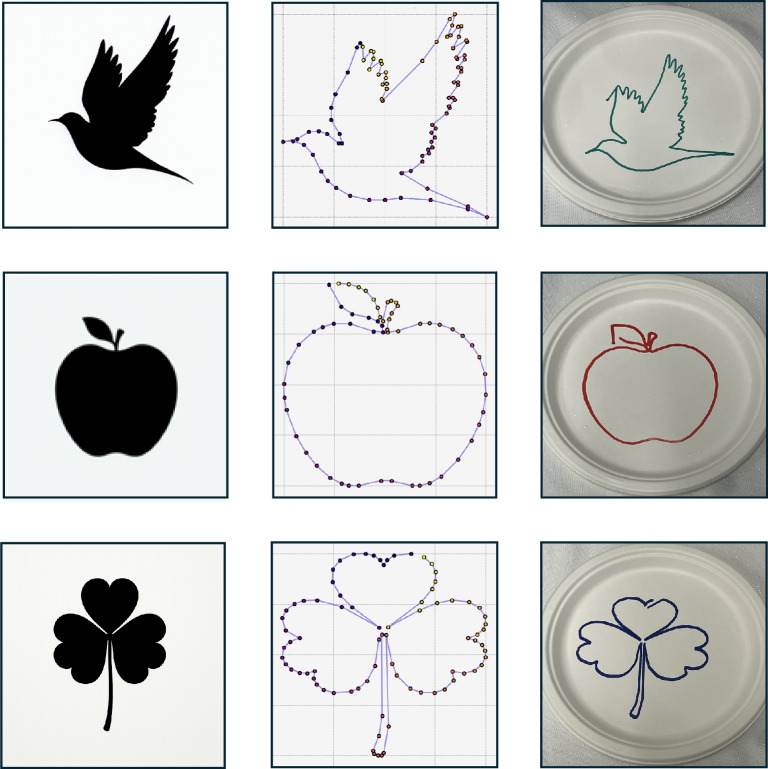
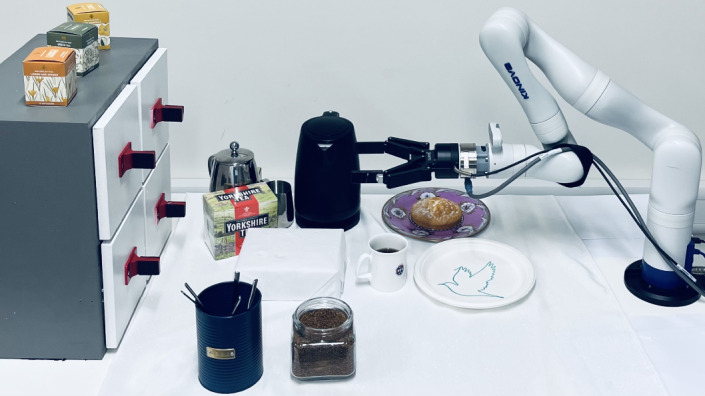
Completing complex tasks in unpredictable settings challenges robotic systems, requiring a step change in machine intelligence. Sensorimotor abilities are considered integral to human intelligence. Thus, biologically inspired machine intelligence might usefully combine artificial intelligence with robotic sensorimotor capabilities. Here we report an embodied large-language-model-enabled robot (ELLMER) framework, utilizing GPT-4 and a retrieval-augmented generation infrastructure, to enable robots to complete long-horizon tasks in unpredictable settings. The method extracts contextually relevant examples from a knowledge base, producing action plans that incorporate force and visual feedback and enabling adaptation to changing conditions. We tested ELLMER on a robot tasked with coffee making and plate decoration; these tasks consist of a sequence of sub-tasks from drawer opening to pouring, each benefiting from distinct feedback types and methods. We show that the ELLMER framework allows the robot to complete the tasks. This demonstration marks progress towards scalable, efficient and ‘intelligent robots’ able to complete complex tasks in uncertain environments.
Overview
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Integrity signals
Registry
Cites
Statistics
Figures
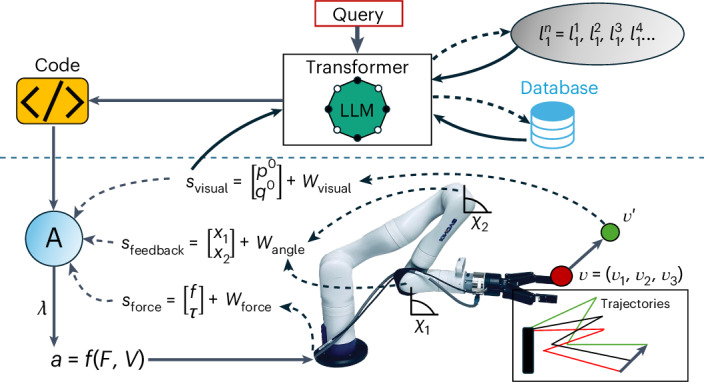
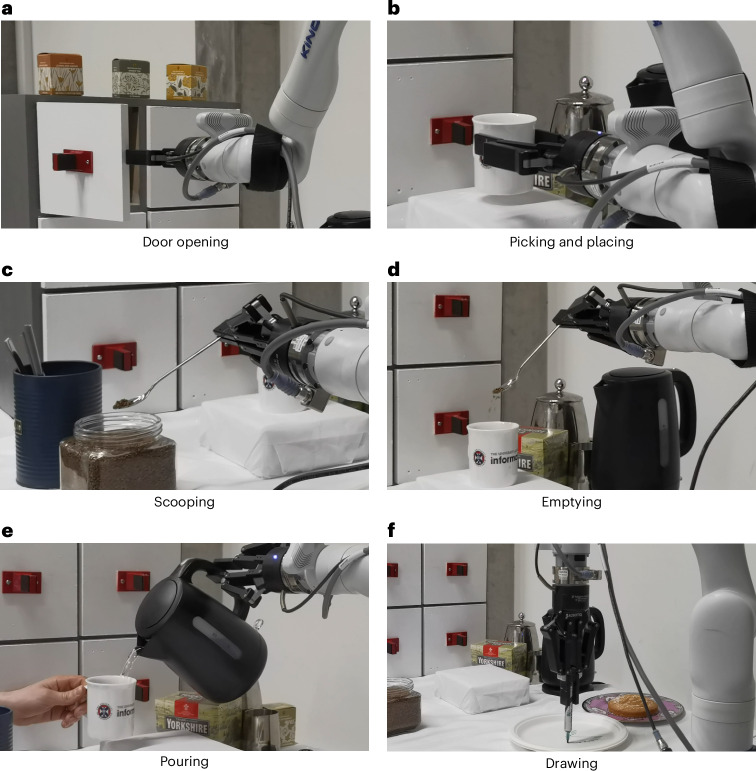
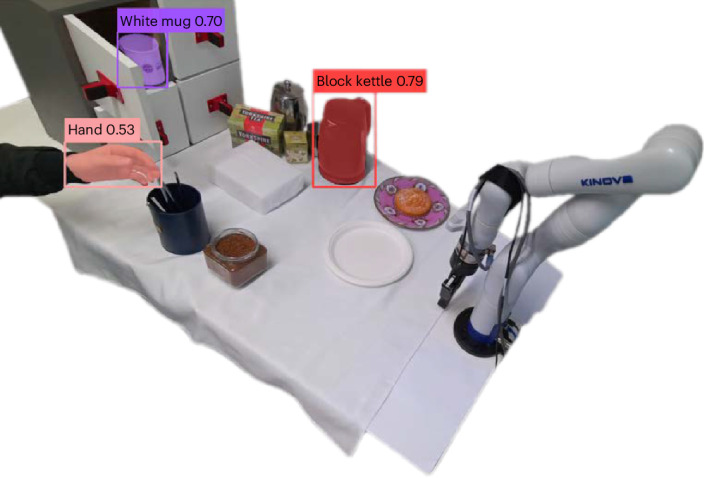
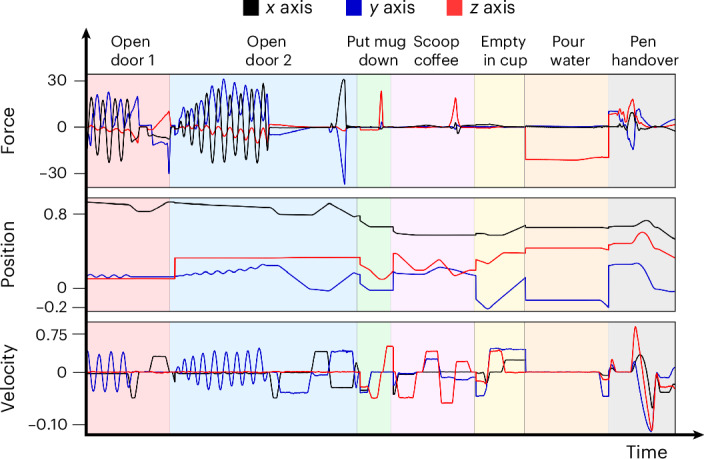
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“In such environments, agents must process continuous, high-bandwidth sensory streams, such as video frames, audio signals, and proprioception, under real-time and memory constraints (Black et al., 2025; Bjorck et al., 2025; Mon-Williams et al., 2025).”
From A Survey of Agent Memory in the Second Half: Towards Self-Evolving and Long-Horizon Agents (2026) · cites this paper as Mon-Williams et al., 2025
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Kirillov, A., Mintun, E., Ravi, N., Mao, H., Rolland, C., Gustafson, L., Xiao, T., Whitehead, S., Berg, A. C., Lo, W.-Y., et al. (2023) · 2023 IEEE/CVF International Conference on Computer Vision (ICCV) · doi:10.1109/iccv51070.2023.00371 · Cited by 11,953
US Environmental Protection Agency
Liu, X. (1998) · Choice Reviews Online · doi:10.5860/choice.35-4455 · Cited by 5,887
Six views of embodied cognition
Wilson, M. (2002) · Psychonomic Bulletin & Review · doi:10.3758/bf03196322 · Cited by 4,782
Retrieval-Augmented Generation for Knowledge-Intensive NLP Tasks
Lewis, P., Perez, E., Piktus, A., Petroni, F., Karpukhin, V., Goyal, N., Küttler, H., Lewis, M., Yih, W.-T., Rocktäschel, T., et al. (2020) · arXiv · doi:10.48550/arxiv.2005.11401 · Cited by 3,101
Zero-shot text-to-image generation
Ramesh, A., Pavlov, M., Goh, G., Gray, S., Voss, C., Radford, A., Chen, M., & Sutskever, I. (2021) · arXiv · doi:10.48550/arxiv.2102.12092 · Cited by 2,417
Grounding DINO: Marrying DINO with Grounded Pre-training for Open-Set Object Detection
Liu, S., Zeng, Z., Ren, T., Li, F., Zhang, H., Yang, J., Jiang, Q., Li, C., Yang, J., Su, H., et al. (2025) · Lecture Notes in Computer Science · doi:10.1007/978-3-031-72970-6_3 · Cited by 2,074
The grand challenges of Science Robotics
Yang, G.-Z., Bellingham, J., Dupont, P. E., Fischer, P., Floridi, L., Full, R., Jacobstein, N., Kumar, V., McNutt, M., Merrifield, R., et al. (2018) · Science Robotics · doi:10.1126/scirobotics.aar7650 · Cited by 1,177
Trends and challenges in robot manipulation
Billard, A., & Kragić, D. (2019) · Science · doi:10.1126/science.aat8414 · Cited by 1,007
An embodied cognitive science?
Clark, A. (1999) · Trends in Cognitive Sciences · doi:10.1016/s1364-6613(99)01361-3 · Cited by 781
Research works printed but not linked: 8
- Hussein, A., Gaber, M. M., Elyan, E. & Jayne, C. Imitation learning: a survey of learning methods. ACM Comput. Surv. 50, 21:1–21:35 (2017).
- Shridhar, M., Manuelli, L. & Fox, D. Perceiver-Actor: a multi-task transformer for robotic manipulation. In Proc. 6th Conference on Robot Learning 785–799 (PMLR, 2023).
- Huang, W., Abbeel, P., Pathak, D. & Mordatch, I. Language models as zero-shot planners: extracting actionable knowledge for embodied agents. In Proc. 39th International Conference on Machine Learning 9118–9147 (PMLR, 2022).
- Belkhale, S., Cui, Y. & Sadigh, D. Data quality in imitation learning. In Advances in Neural Information Processing Systems (NeurIPS) 80375–80395 (Curran Associates, 2024).
- Chang, J., Uehara, M., Sreenivas, D., Kidambi, R. & Sun, W. Mitigating covariate shift in imitation learning via offline data with partial coverage. In Advances in Neural Information Processing Systems 965–979 (Curran Associates, 2021).
- Nair, S., Rajeswaran, A., Kumar, V., Finn, C. & Gupta, A. R3M: a universal visual representation for robot manipulation. In Proc. 6th Conference on Robot Learning Vol. 205, 892–909 (PMLR, 2022).
- Hong, J., Levine, S. & Dragan, A. Learning to influence human behavior with offline reinforcement learning. In Advances in Neural Information Processing Systems (NeurIPS) 36094–36105 (Curran Associates, 2024).
- OpenAI. GPT-4 technical report. Preprint at http://arxiv.org/abs/2303.08774 (2024). · arXiv
Cited by
Sorted by citations
Zheng, X., Jiang, Y., Mete, M., Li, J., Watanabe, I., Yamada, T., & Paik, J. K. (2025) · Science Robotics · doi:10.1126/scirobotics.adx1519 · Cited by 38
Big Data and AI‐Powered Modeling: A Pathway to Sustainable Precision Animal Nutrition
Zhang, S., Lai, C., Zhao, J.-B., & Wang, J.-J. (2025) · Advancement of science · doi:10.1002/advs.202507564 · Cited by 20
Tong, X., Li, K., & Bao, J. (2025) · Robotics and Computer-Integrated Manufacturing · doi:10.1016/j.rcim.2025.103169 · Cited by 14
Roumeliotis, K. I., Sapkota, R., Karkee, M., & Tselikas, N. D. (2026) · IEEE Access · doi:10.1109/access.2026.3662282 · Cited by 13
Intelligent generation of 3D disassembly processes driven by multimodal large language models
Zhao, Y., Chen, L., Yu, H., & Zheng, Y. (2026) · Journal of Manufacturing Systems · doi:10.1016/j.jmsy.2026.04.032 · Cited by 13
Shahin, M., Hosseinzadeh, A., & Chen, F. F. (2025) · The International Journal of Advanced Manufacturing Technology · doi:10.1007/s00170-025-16667-5 · Cited by 17
Farkh, R., Oudinet, G., & Deleruyelle, T. (2025) · AI · doi:10.3390/ai6060115 · Cited by 12
Intelligent bionics: Concepts, research and applications
Huang, J., Chang, Z., Qi, J., Jakobi, T., Zhang, Z., & Ren, L. (2025) · Advanced bionics. · doi:10.1016/j.abs.2025.07.002 · Cited by 12
Orchestrating mechanics, perception and control: Enabling embodied intelligence in humanoid robots
Huang, J., Gao, J., & Yu, Z. (2025) · Information Processing & Management · doi:10.1016/j.ipm.2025.104363 · Cited by 14
Kadri, I., Selouani, S., Ghribi, M., Ghali, R., & Mekhoukh, S. (2025) · Results in Engineering · doi:10.1016/j.rineng.2025.106660 · Cited by 11
Bridging language and action: A survey of language-conditioned robot manipulation
Yao, X., Zhou, H., Mees, O., Meng, Y., Xiao, T. G., Bisk, Y., Oh, J., Johns, E., Shridhar, M., Shah, D., et al. (2026) · The International Journal of Robotics Research · doi:10.1177/02783649261468360 · Cited by 56
Gao, S., Huang, X., Li, Z., Zhang, X., Yuan, Z., El‐Mesery, H. S., Shi, J., & Zou, X. (2025) · Computers and Electronics in Agriculture · doi:10.1016/j.compag.2025.110998 · Cited by 8
González-Santamarta, M. Á., Rodríguez-Lera, F. J., & Olivera, V. M. (2025) · IEEE Access · doi:10.1109/access.2025.3630344 · Cited by 8
Toward the next frontier of embodied AI
Fan, R., Sun, M., & Giakos, G. (2025) · Intelligence & Robotics · doi:10.20517/ir.2025.44 · Cited by 8
Embodied intelligence: Recent advances and future perspectives
An, Z., Yu, X., Wang, C., Zhang, Y., & Song, C. (2025) · The Innovation Informatics · doi:10.59717/j.xinn-inform.2025.100008 · Cited by 7
MechRAG: a multimodal large language model for mechanical engineering
Li, S., & Corney, J. (2025) · Communications Engineering · doi:10.1038/s44172-025-00517-z · Cited by 8
Large language models in human-robot collaboration: A systematic review, trends, and challenges
Yuan, G., Liu, X., Xiao, M., Xiao, J., & Wang, L. (2026) · Journal of Manufacturing Systems · doi:10.1016/j.jmsy.2026.01.011 · Cited by 9
Robotic prefab 3D printing buildings in extreme environments toward Martian habitats
Cai, G., Sun, L., Xu, H., Jiang, Q. M., Yang, Y., Lam, P. M., Lu, F., Yao, Y., Guo, Z., Ma, D., et al. (2026) · npj Space Exploration · doi:10.1038/s44453-025-00025-6 · Cited by 7
Zhai, M., Zeng, A., Qiu, R., Li, J., Zhu, Q., Waite, T. D., Ni, B., & Duan, H. (2026) · Environmental Science & Technology · doi:10.1021/acs.est.5c15806 · Cited by 9
Sun, Y., Li, D., Yang, R., Zhou, Z., Ji, T., Lu, B., Sun, L., & Liu, H. (2025) · Soft Science · doi:10.20517/ss.2025.68 · Cited by 6
Learning Precise Affordances From Egocentric Videos for Robotic Manipulation
Li, G., Tsagkas, N., Song, J., Mon-Williams, R., Vijayakumar, S., Shao, K., & Sevilla-Lara, L. (2025) · IEEE/CVF International Conference on Computer Vision (ICCV) · doi:10.1109/iccv51701.2025.00985 · Cited by 21
Self-citationLiu, C., Tang, D., Zhu, H., Zhang, Z., Wang, L., & Zhang, Y. (2025) · Journal of Industrial Information Integration · doi:10.1016/j.jii.2025.100943 · Cited by 5
Wang, S., Tan, Z., Wang, Y., Zhou, Z., & Zhu, D. (2025) · Robotics and Computer-Integrated Manufacturing · doi:10.1016/j.rcim.2025.103184 · Cited by 4
When control meets large language models: From words to dynamics
Nosrati, K., Tepljakov, A., Belikov, J., & Petlenkov, E. (2026) · Engineering Applications of Artificial Intelligence · doi:10.1016/j.engappai.2026.115119 · Cited by 8
DK-SMF: Domain Knowledge-Driven Semantic Modeling Framework for Service Robots
Joo, K., Jeong, Y., Kwon, S., Jeong, M., Kim, H., & Kuc, T. (2025) · Electronics · doi:10.3390/electronics14163197 · Cited by 4
Li, W., Tang, F., Zhao, M., Omachi, M., & Kato, N. (2025) · IEEE Transactions on Network Science and Engineering · doi:10.1109/tnse.2025.3644352 · Cited by 3
Large Language Models in Sensor-Driven Control Systems: Architectures, Challenges, and Opportunities
Aghaee, F., & Shaker, H. R. (2026) · Sensors · doi:10.3390/s26144350 · Cited by 3
An AI Agent for cell-type specific brain computer interfacesPreprint
Marin‐Llobet, A., Lin, Z., Baek, J., Aljović, A., Zhang, X., Lee, A. J., Wang, W., Lee, J. Y., Shen, H., He, Y., et al. (2025) · bioRxiv (Cold Spring Harbor Laboratory) · doi:10.1101/2025.09.11.675660 · Cited by 4
DeepResearch Bench: A Comprehensive Benchmark for Deep Research Agents
Du, M., Xu, B., Zhu, C., Wang, X., & Mao, Z. (2025) · arXiv · doi:10.48550/arxiv.2506.11763 · Cited by 2
“[18, 27], promising to significantly alter many aspects of daily life and professional work.”
Healthcare reimagined: Carebots from hospital to home
Kaliya-Perumal, A.-K., & Sidarta, A. (2025) · Public Health · doi:10.1016/j.puhe.2025.105920 · Cited by 2
Karaali, O., Farag, H. M., Dosen, S. S., & Stefanović, Č. (2025) · International Conference on Information, Communication and Automation Technologies (ICAT) · doi:10.1109/icat66432.2025.11189268 · Cited by 2
Ma, F., Li, D., Chen, Y., Xing, J., Liu, Y., Lan, D., Shao, J., & Pang, Z. (2025) · Research · doi:10.34133/research.1047 · Cited by 4
Physics-Aware Multichannel Vector Quantization for Hybrid Digital Twin Modeling of UAV Systems
Tu, J., Nian, X., & Dai, X. (2025) · IEEE Transactions on Aerospace and Electronic Systems · doi:10.1109/taes.2025.3639005 · Cited by 2
AI-native robotic vision systems enabled by in-sensor computing
Kim, D., Kwon, J. I., Kim, Y., Kim, D., & Choi, C. (2026) · npj Unconventional Computing · doi:10.1038/s44335-025-00047-z · Cited by 2
Olukanni, E. O., Akanmu, A. A., & Jebelli, H. (2026) · ASCE OPEN Multidisciplinary Journal of Civil Engineering · doi:10.1061/aomjah.aoeng-0102 · Cited by 2
Gadekallu, T. R., Zhao, Y., Wen, Z., Bhattacharya, P., Xia, Y., Cai, J., Zeydan, E., Fang, K., & Feng, H. (2026) · IEEE Internet of Things Journal · doi:10.1109/jiot.2026.3703862 · Cited by 3
Sun, H., Gao, X., Niu, W., Li, L., Song, Y., Liu, L., Zhou, H., Liu, H., Wang, Z. L., Pu, X., et al. (2026) · Nature Sensors · doi:10.1038/s44460-026-00108-1 · Cited by 2
Sorour, S. S., & Sahbel, A. (2026) · Journal of Intelligent Manufacturing · doi:10.1007/s10845-026-02927-y · Cited by 2
AI for science: Progress, challenges, and perspectives
Xu, Y., Shao, Z., Liu, X., Li, Y., An, Z., Fu, C., Huang, C., Zhang, L., Gao, F., Li, J., et al. (2026) · The Innovation · doi:10.1016/j.xinn.2026.101530 · Cited by 6
Hinst: Human‐Like Interactive Instinct Enables Robots to Robustly Accomplish Universal Tasks
Liao, Z., Mao, Q., Qin, Y., Yuan, J., & Zhu, R. (2025) · Advanced Science · doi:10.1002/advs.202509483 · Cited by 2
Khan, A. T., Cao, X., Li, S., Yi, C., & Moshayedi, A. J. (2026) · Expert Systems with Applications · doi:10.1016/j.eswa.2026.132474 · Cited by 1
Extended Abstract: Will Embodied AI Become Sentient?
Lee, E. A. (2025) · Lecture notes in computer science · doi:10.1007/978-3-032-07132-3_1 · Cited by 1
Challenging issues in empowering smart agriculture develop- ment with control science
Hongyi, L. I., Xing, H. E., Xin, W. A. N. G., Huaqing, L. I., Shouyong, X. I. E., & JinJun, W. A. N. G. (2025) · Scientia Sinica Informationis · doi:10.1360/ssi-2025-0350 · Cited by 1
Ren, B. S., & Shi, D. (2025) · Sensors · doi:10.3390/s26010165 · Cited by 1
LanPerAct: A Framework for Language-Driven Perception and Robotic Manipulation
Wu, Z., Wu, S., Tu, Y., Zhou, H., Drew, S., & Niu, X. (2025) · IEEE Smart World Congress (SWC) · doi:10.1109/swc65939.2025.00095 · Cited by 1
A framework for VLM-knowledge graph integration in complex long-horizon tasks
Yin, L., Cheng, Y., Du, X., Tong, N., Xu, F., & Li, F. (2026) · Knowledge-Based Systems · doi:10.1016/j.knosys.2026.115588 · Cited by 1
Oracle-grasp: zero-shot affordance-aligned robotic grasping using large multimodal models
Giuili, A., Atari, R., & Sintov, A. (2026) · Intelligent Service Robotics · doi:10.1007/s11370-026-00707-4 · Cited by 1
Dai, W., Zhou, X., Wu, P., Zhou, J., Shang, Y., & Fan, Y. (2026) · Cognitive Robotics · doi:10.1016/j.cogr.2026.03.002 · Cited by 1
Wang, Z., Zhang, F., Lin, Q., Gao, Y., Sun, B., Ke, H., Liu, N., Tian, B., Zhao, L., & Jiang, Z. (2026) · Chemical Engineering Journal · doi:10.1016/j.cej.2026.176909 · Cited by 1
Proactive collaboration via autonomous interaction
Li, P., Zhang, X., Yang, W., Hu, Y., Wang, Y., Wang, D., Li, H., Guo, D., & Liu, H. (2026) · Nature Communications · doi:10.1038/s41467-026-72797-8 · Cited by 2
Wang, X., Feng, T., Liu, H., & Zhu, W. (2026) · Springer eBooks · doi:10.1007/978-981-95-7750-7_2 · Cited by 1
Liu, C., Tang, D., Zhu, H., Wang, L. N., Cai, Q., & Shi, H. (2026) · Journal of Manufacturing Systems · doi:10.1016/j.jmsy.2026.06.021 · Cited by 1
Ding, W., Chen, J., Chen, M., Xie, F., Wang, J., Yang, S. X., & Dames, P. (2026) · Frontiers in Robotics and AI · doi:10.3389/frobt.2026.1905578 · Cited by 2
Socially Aware Robot Navigation With Meta Reinforcement Learning: A Field-Theory Perspective
Lu, S., Chen, B., Zhong, P., Zou, T., Yang, H., Liu, R., & Sheng, Y. (2025) · IEEE Transactions on Cognitive and Developmental Systems · doi:10.1109/tcds.2025.3616393 · Cited by 1
A Survey of Agent Memory in the Second Half: Towards Self-Evolving and Long-Horizon Agents
Huang, W.-C., Zhang, W., Liang, Y., Bei, Y., Chen, Y., Feng, T., Pan, X., Tan, Z., Wang, Y., Wei, T., et al. (2026) · arXiv · doi:10.48550/arxiv.2602.06052 · Cited by 70
Data Driven Interface Regulated Wearable 3d Motion Communicator for Human Finger ElectronicsPreprint
Tai, Y., Wang, Q., Xiang, Z., Qi, B., Guo, H., Xiao, C., Zhou, X., Yang, Z., Deng, X., Li, G., et al. (2025) · SSRN Electronic Journal · doi:10.2139/ssrn.5353979
Self-citationIntegración modular de herramientas gestionadas por LLMs en el robot TIAGo++
Menéndez, E., García-Haro, J. M., Martínez, S., & Balaguer, C. (2025) · Jornadas de Automática · doi:10.17979/ja-cea.2025.46.12229 · Cited by 1
A Dharmakīrtian Model of Relevance Realization in Cognitive Agents
Amir, N., & Dunne, J. D. (2025) · Contemporary Buddhism · doi:10.1080/14639947.2025.2564476 · Cited by 1
Design and Implementation of a Delivery Robot System for Natural Language Interaction
Feng, Q., Zhang, G., & Chen, K. (2025) · International Conference on Internet of Things, Automation and Artificial Intelligence (IoTAAI) · doi:10.1109/iotaai66837.2025.11213046
Extracting Commonsense Knowledge for Robotic Agents from LLMs
Adamik, M., Tiddi, I., & Stefan Schlobach, A. (2025) · International Conference on Knowledge Capture · doi:10.1145/3731443.3771358
Context-Aware Small Language Models for Real Time Strategy Prediction in Strategy Game
Admajindra, C. H., & Haryanto, H. (2025) · International Conference on Informatics, Multimedia, Cyber and Information System (ICIMCIS) · doi:10.1109/icimcis68501.2025.11327013
Research on Interactive Command Generation Methods for Virtual Masonry by Robots
Xu, J., Li, Y., Zhong, J., Jiang, Y., & Ma, J. (2025) · International Conference on Robotics and Automation Engineering (ICRAE) · doi:10.1109/icrae67496.2025.00020
An Effective 6DoF Grasp Detection Framework for Human–Robot Interaction With LLMs
Yu, S. W., Zhai, D., & Xia, Y. (2026) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2026.3656994
BACON: A Body-Aware Framework for Parameterized Collision Detection Acceleration
Xing, Y., Feng, D., Li, H., Ji, X., & Zhao, R. J. (2026) · IEEE Transactions on Computer-Aided Design of Integrated Circuits and Systems · doi:10.1109/tcad.2026.3664290
Ivanov, R. D., Менисов, А. Б., Mishukov, O. A., & Sabirov, T. R. (2026) · Scientific and technical journal of information technologies mechanics and optics · doi:10.17586/2226-1494-2026-26-1-69-76
Jia, L., Ye, Y., Styler, B. K., & Du, N. (2026) · ACM/IEEE International Conference on Human-Robot Interaction (HRI) · doi:10.1145/3757279.3788662
Look2React: Making VR NPCs Come Alive with Dynamic Vision-Guided Reactions
Vatsal, R., Huang, X., & Xiao, R. (2026) · IEEE Transactions on Visualization and Computer Graphics · doi:10.1109/tvcg.2026.3679121
Zero-Shot Task Automation with Foundation Language Models
Divesh Kumar, S., I, D. A. A., Maharasi, M., & Pavithra, S. (2025) · International Conference on Smart Electronics and Communication (ICOSEC) · doi:10.1109/icosec67334.2025.11459707
Future of Robotics and Integration of Artificial Intelligence
Giménez, M., Innocenzi, C., Espínola, F., Forgione, A., & Marescaux, J. (2026) · Surgical Oncology Clinics of North America · doi:10.1016/j.soc.2025.12.003
Mapping the Wizards' Path: A Systematic Review of Wizard-of-Oz in HCI
Yang, R., Du, Y., Du, H., & Huang, K. (2026) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3772318.3791174 · Cited by 1
Task planning for dual dexterous hand collaboration via scene understanding and semantic information
Li, B., Li, B., Gao, T., Wang, H., & Zou, S. (2026) · Engineering Research Express · doi:10.1088/2631-8695/ae602b
A retrieval-augmented framework enabling VLM spatial awareness for object-centric robot manipulation
Chen, K., Li, C., Tu, C., Pan, J., Ma, Y., Chen, W., Zhou, Z., Xu, X., James, S., Fu, C., et al. (2026) · Science Robotics · doi:10.1126/scirobotics.aea2092 · Cited by 2
Lou, J., Shi, R., Wang, H.-P., Yu, M.-M., Wang, Y.-S., Wang, Q., & Wu, W.-J. (2026) · IEEE Transactions on Automation Science and Engineering · doi:10.1109/tase.2026.3689345 · Cited by 5
Behavior-Driven Marine Larval Dispersal and Settlement with AI Agent-Based ModelingPreprint
Zhou, X., Wang, G., Wu, R., & Bracco, A. (2026) · bioRxiv (Cold Spring Harbor Laboratory) · doi:10.64898/2026.04.29.721765
On the Availability Risks of Production LLM Services Under Unbounded Inference
Li, Y., Wang, J., Zhu, H., Lin, J., Chang, S., & Guo, M. (2026) · IEEE Transactions on Dependable and Secure Computing · doi:10.1109/tdsc.2026.3689535
Ethics of Social Robotics: Co-evolution or the Extended Mind?
Damiano, L., & Dumouchel, P. (2026) · Springer eBooks · doi:10.1007/978-3-032-15112-4_52 · Cited by 1
Jiang, S., Wang, Y., & Yuan, X. (2026) · Expert Systems with Applications · doi:10.1016/j.eswa.2026.132623
Basic Research on Physical Intelligent System for Extreme Environment
Wang, S., Du, X., Duan, H., Yu, H., Da, L., Pan, F., Liu, H., Liu, H., Cao, H., & Wu, F. (2026) · 中国科学基金 · doi:10.3724/bnsfc-2025-0154
Milou, A. C. (2026) · SSRN Electronic Journal · doi:10.2139/ssrn.6679558
Wang, A., Wang, K., Wang, Y., Yue, X., Li, H., & Yao, Y. (2026) · Journal of Advanced Computational Intelligence and Intelligent Informatics · doi:10.20965/jaciii.2026.p0781
Xin, G., Xu, J., Deghat, M., Wan, C., Liu, J., Hu, Y., & Hu, Z. (2026) · SSRN Electronic Journal · doi:10.2139/ssrn.6799077
A Review of Active Collaborative Perception and Planning for Heterogeneous UAV-UGV Systems
Sun, W. (2026) · International Conference on Advanced Electronic Materials, Computers and Software Engineering (AEMCSE) · doi:10.1109/aetcse69203.2026.11504015
LaViCoN: Language and Vision Cooperative Navigation for Assistive Mobile Robots
Yang, T. Y., Zhong, R., & Shi, W. (2026) · IEEE International Conference on Mobility, Operations, Services and Technologies (MOST) · doi:10.1109/most69733.2026.00016
Sentinel: Embodied Cooperative Spatial Reasoning and Planning
Lin, X., Zhang, H., Deng, R., Zhou, Q., & Gan, C. (2026) · Lecture notes in computer science · doi:10.1007/978-3-032-37020-4_36
Gate^2-VLA: Regulating Attention Routing for Long-Horizon VisionLanguage-Action ModelPreprint
ZHANG, J., ZHANG, Y., Sun, H., & Hashimoto, K. (2026) · SSRN Electronic Journal · doi:10.2139/ssrn.6842461
Real-Time Edge Semantics for Drone Swarms via FPGA Perception and On-Device LLMs
Wang, Z., Fortney, W. A., Forcha, P., Feng, Y., Bendix, G., & Bobda, C. (2026) · International Symposium on Quality Electronic Design (ISQED) · doi:10.1109/isqed69900.2026.11534722
Peng, Y. K. M., & Gómez-Bravo, F. (2026) · Machines · doi:10.3390/machines14060650
Li, J., Zhang, X., Si, J., & Bao, J. (2026) · Symmetry · doi:10.3390/sym18060981
How can reasoning capability empower the AI copilot robot in endoscopic surgery
Wang, G.-K., Bai, L., & Ren, H. (2026) · npj Digital Medicine · doi:10.1038/s41746-026-02827-8 · Cited by 1
Integrating Unconventional Approaches for Intelligent and Adaptive Soft Robotic Systems
Jeong, H., & Paik, J. K. (2026) · Springer eBooks · doi:10.1007/978-3-032-22453-8_12
Embodied AI for kitchen scene rearrangement: a deep spatio-temporal approach
Esfahani, A. N., Hosseini, H. M., Masouleh, M. T., & Kalhor, A. (2026) · Intelligent Service Robotics · doi:10.1007/s11370-026-00723-4
LLMs as Research Instruments for Problems in Engineering Management: A Context Modeling Framework
Qin, R., Mansouri, A., Zhen, D., Erfani, A., & Cui, Q. (2026) · Journal of Management in Engineering · doi:10.1061/jmenea.meeng-7519
Robust MLLM-Based Decision Making for Swarm Confrontation Under Uncertain Constraints
WANG, L. C., & Chen, L. (2026) · Chinese Control and Decision Conference (CCDC) · doi:10.1109/ccdc69976.2026.11560248
Brain-Inspired Generative AI Revives Legacy Industrial Robots Toward Sustainable Automation
Liu, Z., Wang, T., Zhong, R., Wang, X. V., Li, M., & Wang, L. (2026) · Engineering · doi:10.1016/j.eng.2026.05.020
Indoor Lighting Intelligent Control Using Context-Aware-Based LLM Agent and Domain Knowledge Base
Wang, Y. C., Sun, F., & Fang, Q. (2026) · Light & Engineering · doi:10.33383/2025-068
Verification-gated agentic mission-state governance for intelligent industrial multi-robot systems
Tang, G., Jia, Q., Tan, Y., Huang, Z., Ji, N., & Chen, G. (2026) · Engineering Applications of Artificial Intelligence · doi:10.1016/j.engappai.2026.116216
Lee, Y., Choi, S., & Lee, S. W. (2026) · SSRN Electronic Journal · doi:10.2139/ssrn.7079738
Agentic mobile AI systems: From post-hoc optimization to runtime-elastic realization
Liu, S., Wu, W., Xu, X., Li, T., Pang, B., Zhou, W., Guo, B., & Yu, Z. (2026) · Information Fusion · doi:10.1016/j.inffus.2026.104630
Yılmaz, T., & Aydoğmuş, Ö. (2026) · Robotics and Autonomous Systems · doi:10.1016/j.robot.2026.105628
Fourastier, Y., & Chaouchi, H. (2026) · Springer proceedings in complexity · doi:10.1007/978-3-032-21524-6_41
Metadata
- Authors
- Mon-Williams, R., Li, G., Long, R., Du, W., & Lucas, C. G.
- Affiliations
- Princeton University (US)
- University of Edinburgh (GB)
- The Alan Turing Institute (GB)
- Corresponding author
- Mon-Williams, Ruaridh
- Li, Gen
- Venue
- Nature Machine Intelligence
- Published
- 2025-03-19
- Volume
- 7
- Issue
- 4
- Pages
- 592-601
- ISSN
- 2522-5839 (ISSN-L)
- PMC
- PMC12088599
- OpenAlex
- W4408555470
- Cited by
- 132
- References
- 58
- Citations by year
- 2026: 94 · 2025: 38
- FWCI
- 48.49
- Type
- journal article
- Language
- en
- Open access
- hybrid
- doi.org
- Locations
- Nature Machine Intelligence (publishedVersion, cc-by)
- Research Square (acceptedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- Edinburgh Research Explorer (University of Edinburgh) (submittedVersion, cc-by)
- Funders
- RCUK | Engineering and Physical Sciences Research Council (EP/L016834/1, EP/S023208/1)
- Topics
- Physical Sciences › Engineering › Control and Systems Engineering › Robot Manipulation and Learning
- Physical Sciences › Computer Science › Artificial Intelligence › AI-based Problem Solving and Planning
- Physical Sciences › Computer Science › Artificial Intelligence › Reinforcement Learning in Robotics
- Keywords
- unpredictable environments, GPT-4, retrieval-augmented generation, sensorimotor feedback, force feedback, visual feedback, action planning, long-horizon tasks, intelligent robots
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
