

The DOI matches its Crossref record; 36 of the 36 references it cites were found in a registry or an index.
Walking Faster and Farther With a Soft Robotic Exosuit: Implications for Post-Stroke Gait Assistance and Rehabilitation
Open accessAbstract
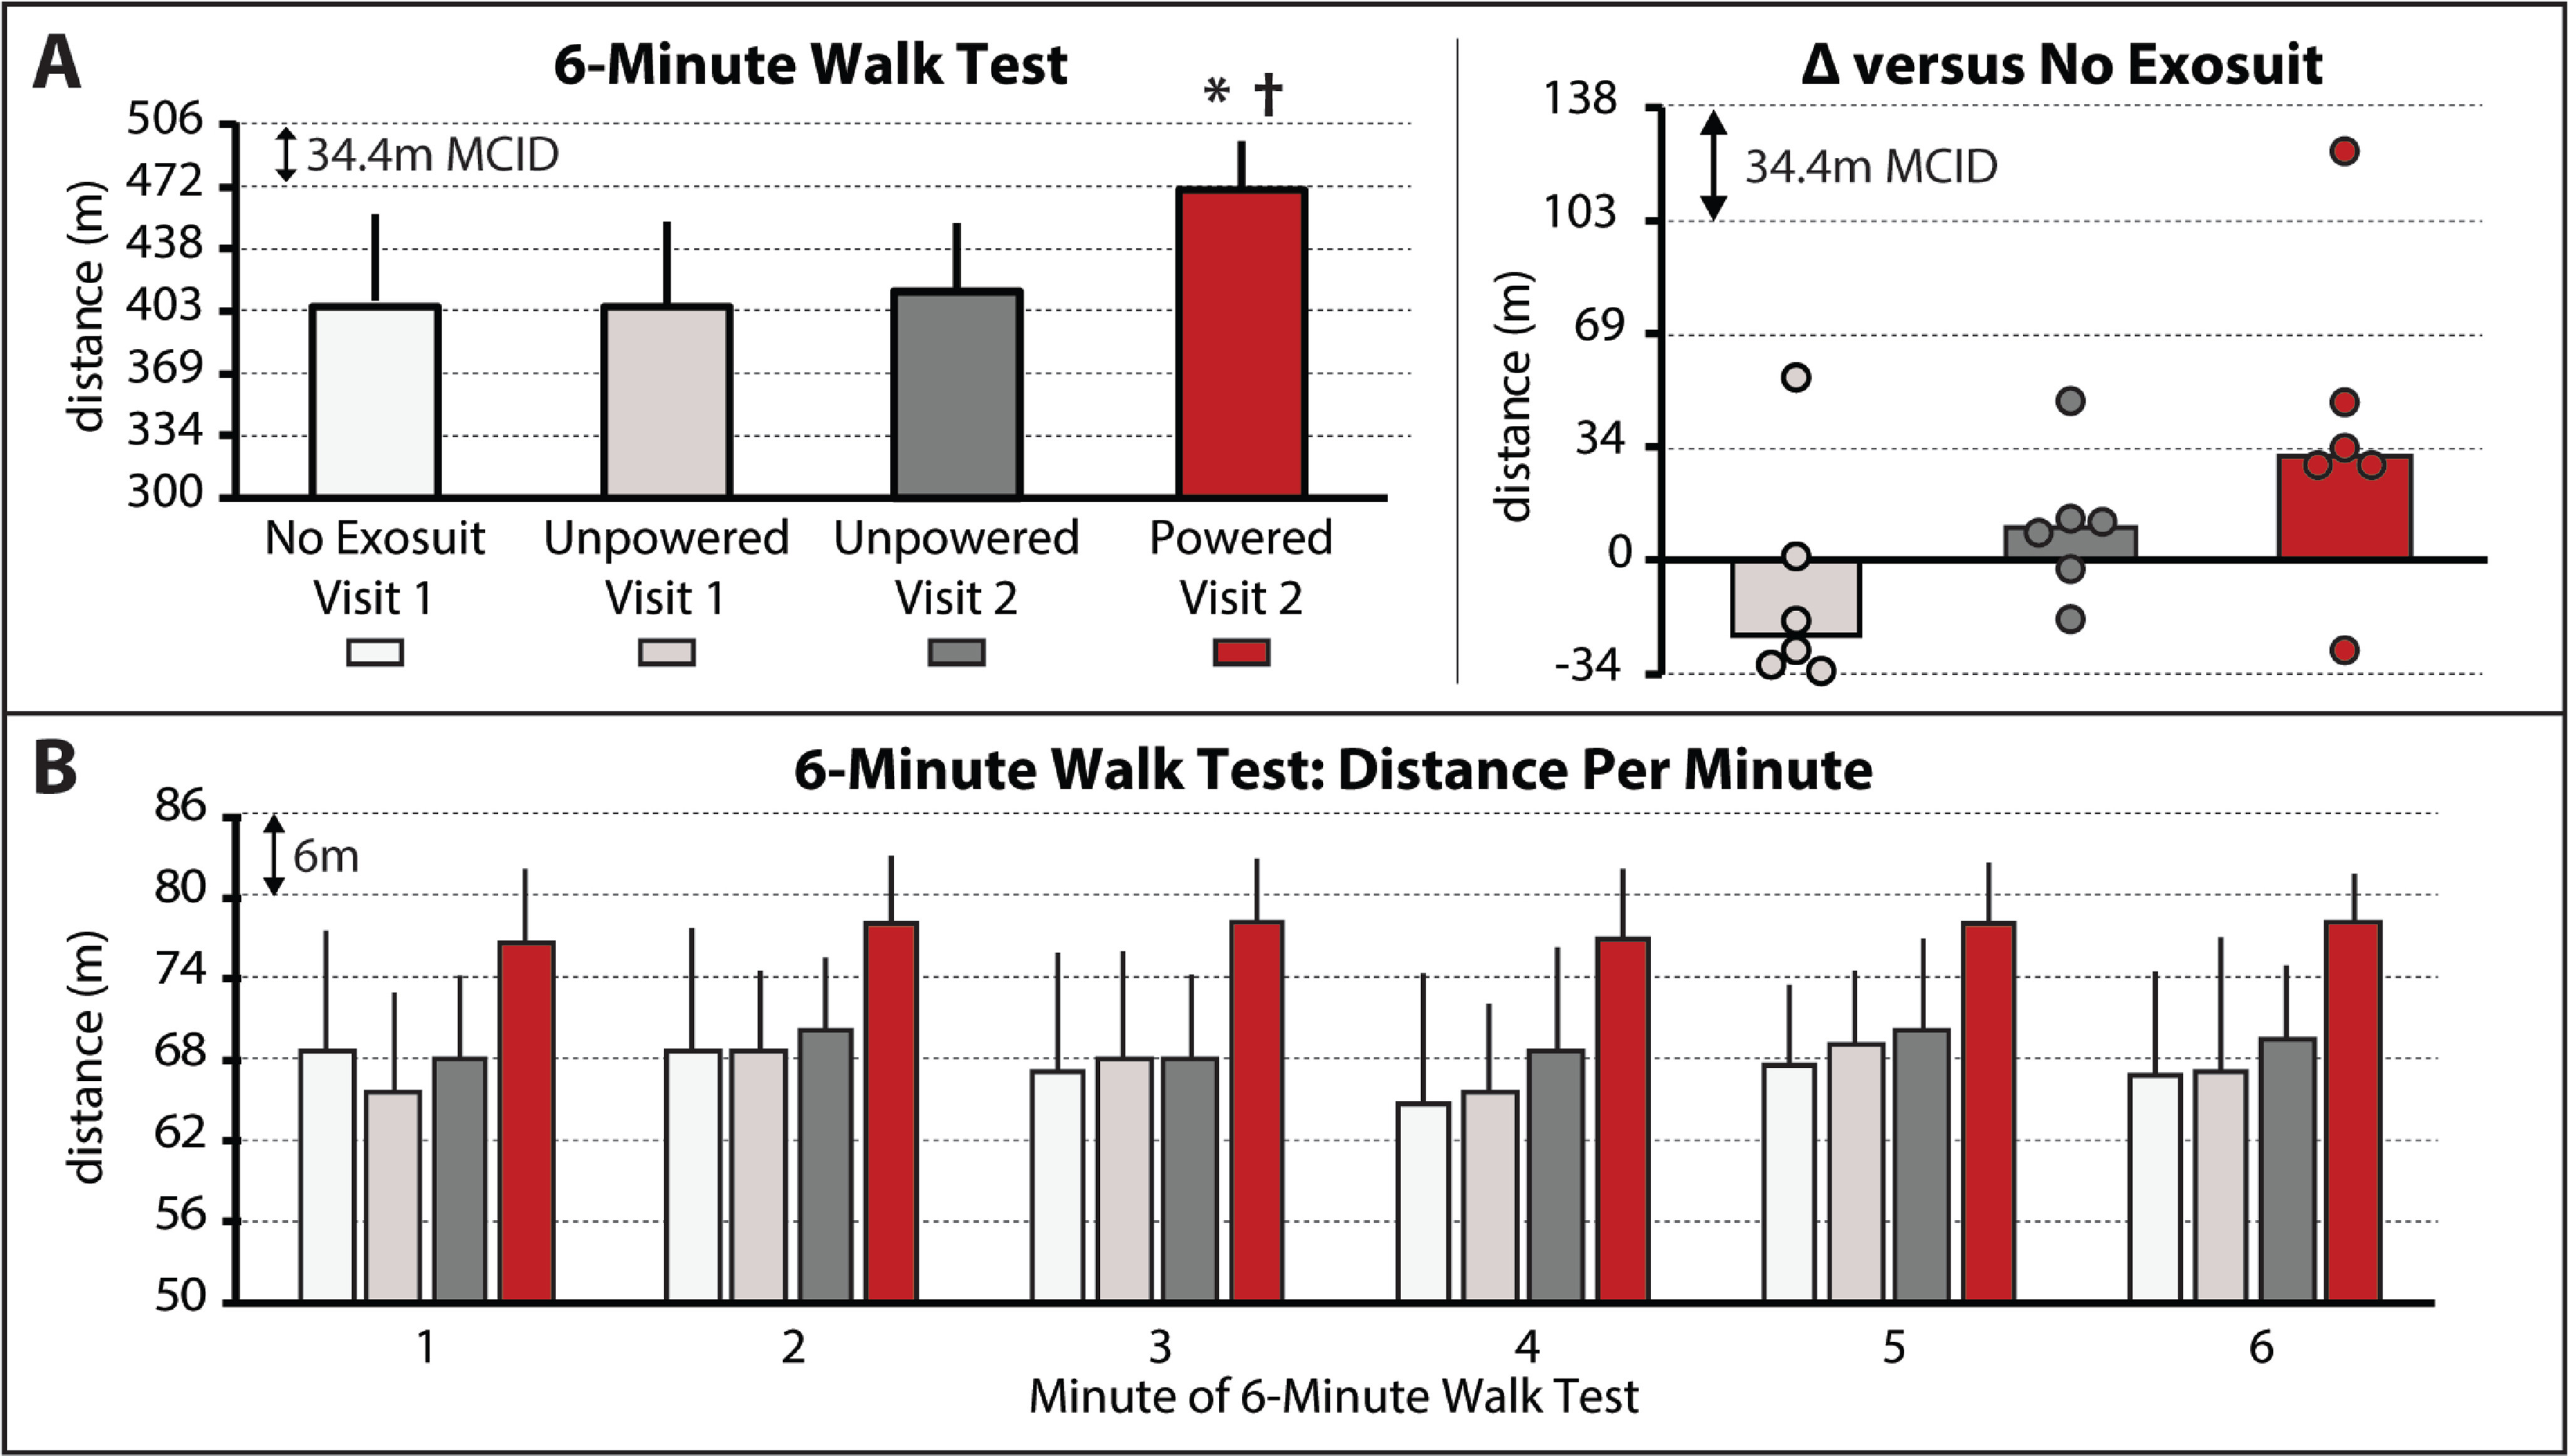
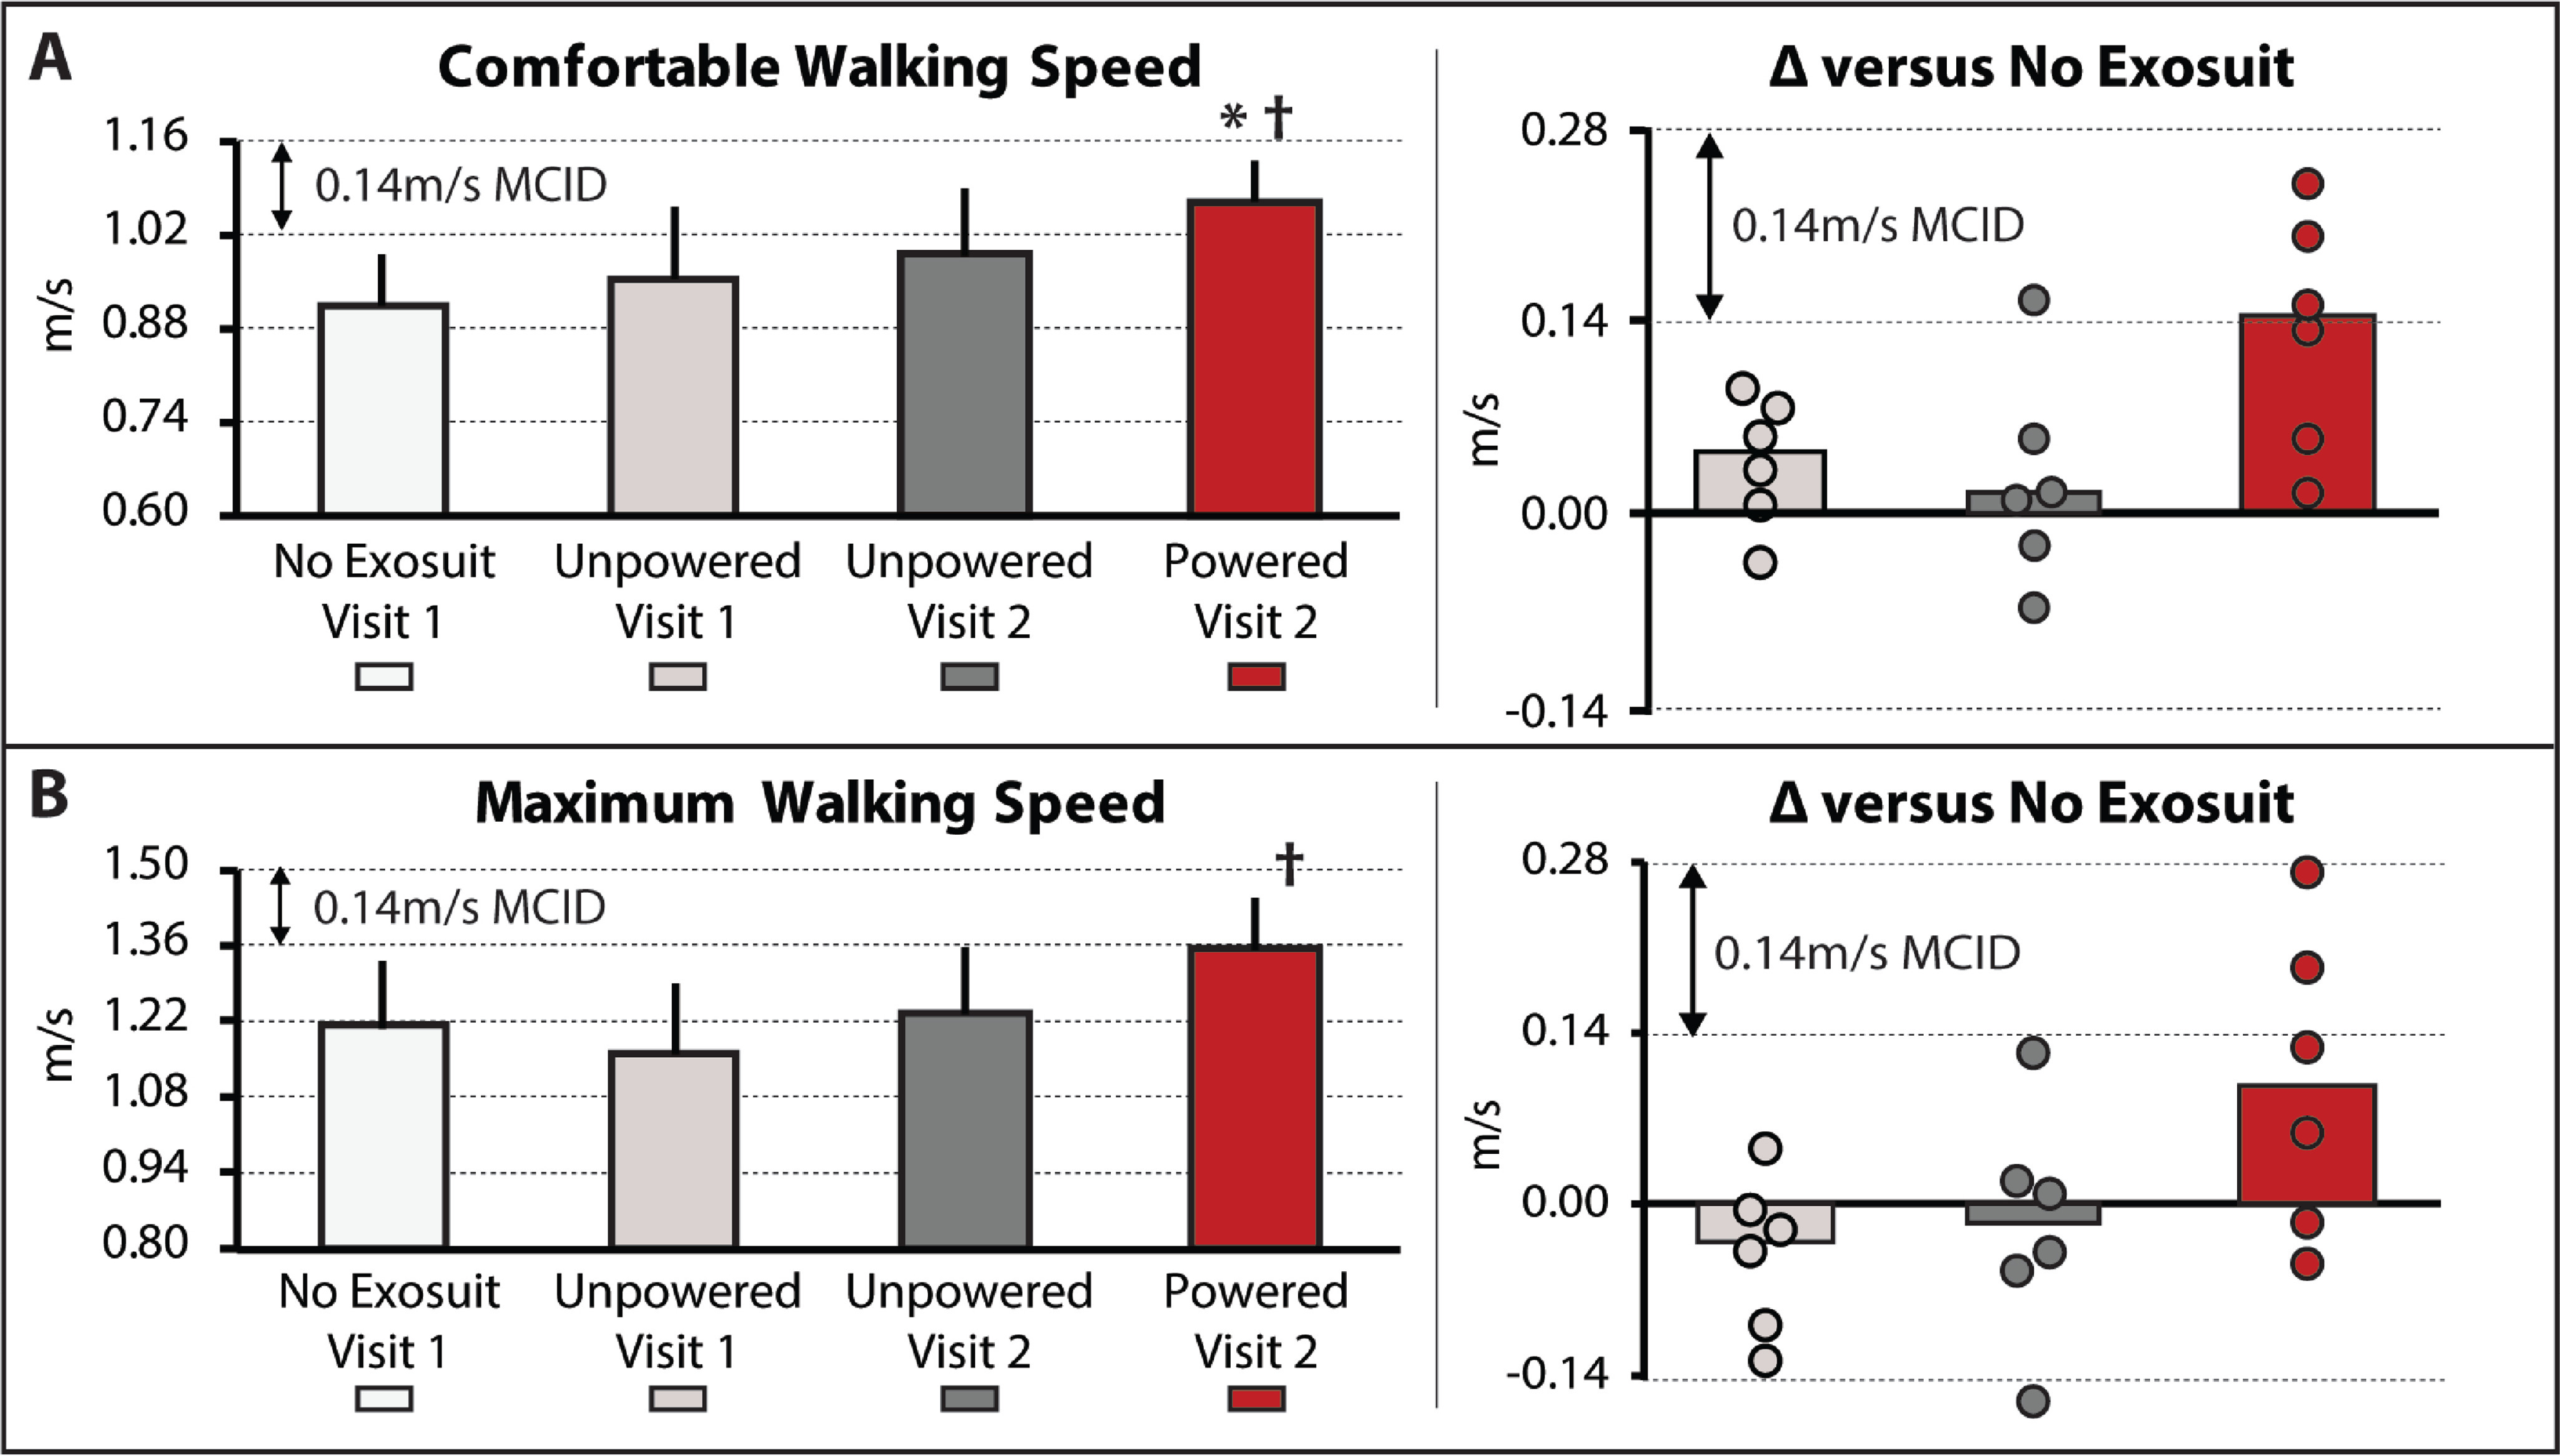
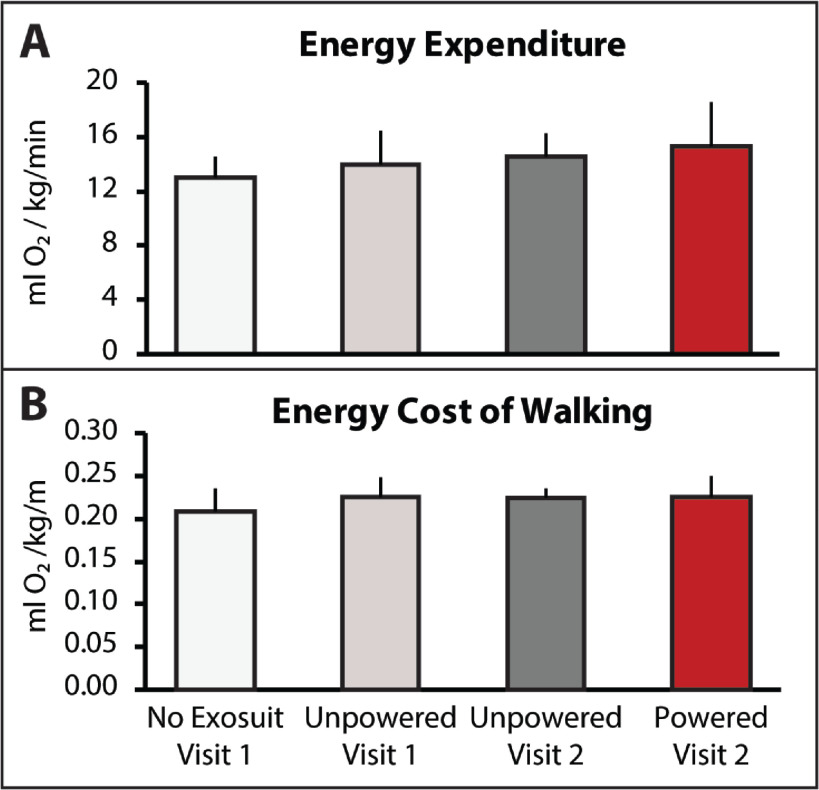
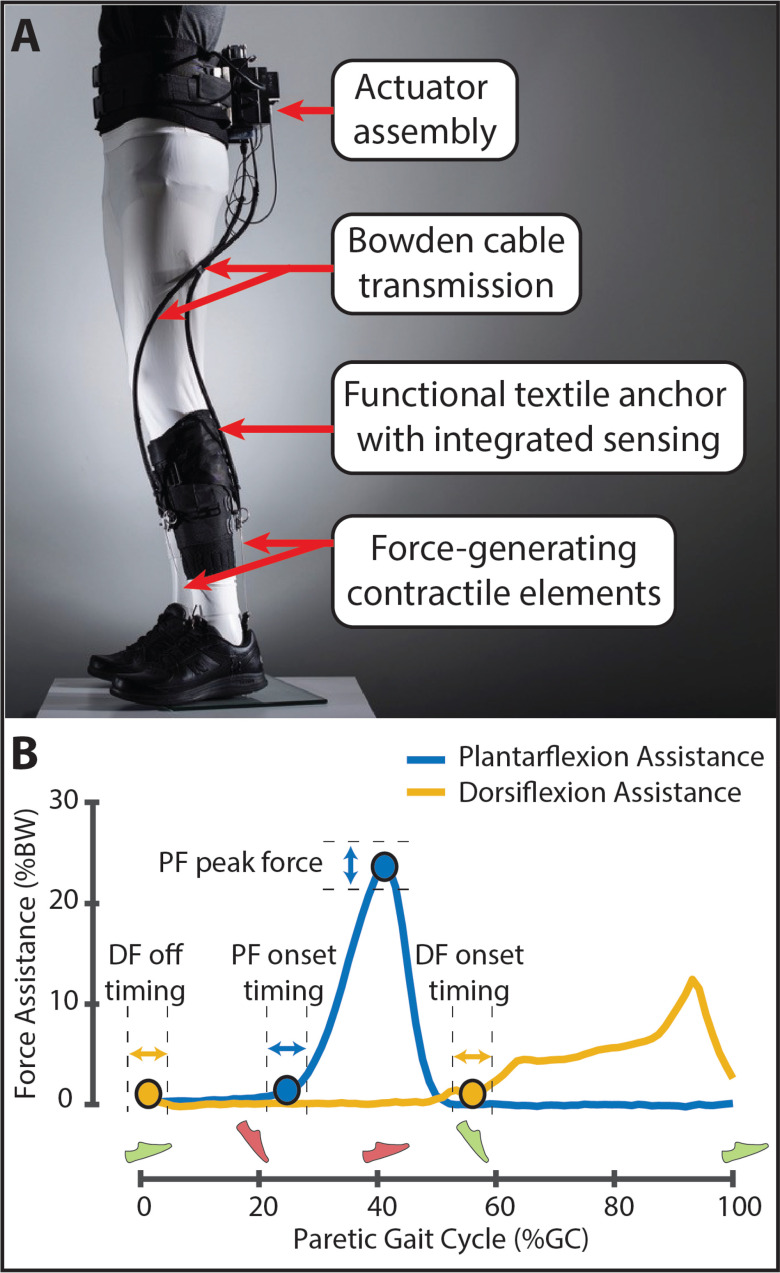
OBJECTIVE: Soft robotic exosuits can improve the mechanics and energetics of walking after stroke. Building on this prior work, we evaluated the effects of the first prototype of a portable soft robotic exosuit. METHODS: Exosuit-induced changes in the overground walking speed, distance, and energy expenditure of individuals post-stroke were evaluated statistically with alpha set to 0.05 and compared to minimal clinically important difference scores. RESULTS: 5kg exosuit did not substantially modify walking speed, distance, or energy expenditure when worn unpowered. In contrast, when the exosuit was powered on to provide an average 22.87±0.58 %bodyweight of plantarflexor force assistance during the paretic limb's stance phase and assist the paretic dorsiflexors during swing phase to reduce drop-foot, study participants walked a median 0.14±0.06 m/s faster during the 10-meter walk test and traveled 32±8 m farther during the six minute walk test. CONCLUSIONS: Individuals post-stroke can leverage the paretic plantarflexor and dorsiflexor assistance provided by soft robotic exosuits to achieve clinically-meaningful increases in speed and distance.
Overview
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Integrity signals
Registry
Cites
Statistics
Figures
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
In the citing paper
“The incorporation of plantarflexor and dorsiflexor assistance within the soft exosuit exhibited promising outcomes in terms of enhancing walking speed and distance for post-stroke patients.”
From Artificial intelligence enhanced sensors - enabling technologies to next-generation healthcare and biomedical platform (2023) · cites this paper as Awad et al. 2020
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
1 retracted
Jayaraman, A., O’Brien, M. K., Madhavan, S., Oikawa, K., Endo, Y., Kantak, S. S., Stinear, J. W., Hornby, T. G., & Rymer, W. Z. (2019) · Archives of Physical Medicine and Rehabilitation · doi:10.1016/j.apmr.2019.08.473 · Cited by 5
RetractedMeaningful change and responsiveness in common physical performance measures in older adults.
Perera, S., Mody, S. H., Woodman, R. C., & Studenski, S. A. (2006) · Journal of the American Geriatrics Society · doi:10.1111/j.1532-5415.2006.00701.x · Cited by 2,513
Motor recovery after stroke: A systematic review of the literature
Hendricks, H. T., van Limbeek, J., Geurts, A. C. H., & Zwarts, M. J. (2002) · Archives of Physical Medicine and Rehabilitation · doi:10.1053/apmr.2002.35473 · Cited by 782
A soft robotic exosuit improves walking in patients after stroke
Awad, L. N., Bae, J., O’Donnell, K., De Rossi, S. M. M., Hendron, K., Sloot, L. H., Kudzia, P., Allen, S., Holt, K. G., Ellis, T. D., et al. (2017) · Science Translational Medicine · doi:10.1126/scitranslmed.aai9084 · Cited by 672
Self-citationMulticenter Randomized Clinical Trial Evaluating the Effectiveness of the Lokomat in Subacute Stroke
Hidler, J., Nichols, D., Pelliccio, M., Brady, K., Campbell, D. D., Kahn, J. H., & Hornby, T. G. (2009) · Neurorehabilitation and Neural Repair · doi:10.1177/1545968308326632 · Cited by 652
Tilson, J. K., Sullivan, K. J., Cen, S., Rose, D. K., Koradia, C. H., Azen, S. P., Duncan, P. W., & for the Locomotor Experience Applied Post Stroke (LEAPS) Investigative Team (2009) · Physical Therapy · doi:10.2522/ptj.20090079 · Cited by 501
Hornby, T. G., Reisman, D. S., Ward, I., Scheets, P. L., Miller, A. E., Haddad, D., Fox, E. J., Fritz, N. E., Hawkins, K. A., Henderson, C. E., et al. (2019) · Neurology Report · doi:10.1097/npt.0000000000000303 · Cited by 416
Powered robotic exoskeletons in post-stroke rehabilitation of gait: a scoping review
Louie, D. R., & Eng, J. J. (2016) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-016-0162-5 · Cited by 352
Predicting Home and Community Walking Activity Poststroke
Fulk, G. D., He, Y., Boyne, P., & Dunning, K. K. (2017) · Stroke · doi:10.1161/strokeaha.116.015309 · Cited by 308
Hornby, T. G., Straube, D., Kinnaird, C. R., Holleran, C. L., Echauz, A. J., Rodriguez, K. S., Wagner, E. J., & Narducci, E. (2011) · Topics in Stroke Rehabilitation · doi:10.1310/tsr1804-293 · Cited by 209
Research works printed but not linked: 1
- mcdonald, 2014, Multiple Comparisons - Handbook of Biological Statistics
Cited by
Sorted by citations
Personalizing exoskeleton assistance while walking in the real world
Slade, P., Kochenderfer, M. J., Delp, S. L., & Collins, S. H. (2022) · Nature · doi:10.1038/s41586-022-05191-1 · Cited by 339
Wang, C., He, T., Zhou, H., Zhang, Z., & Lee, C. (2023) · Bioelectronic Medicine · doi:10.1186/s42234-023-00118-1 · Cited by 295
How adaptation, training, and customization contribute to benefits from exoskeleton assistance
Poggensee, K. L., & Collins, S. H. (2021) · Science Robotics · doi:10.1126/scirobotics.abf1078 · Cited by 230
Awad, L. N., Esquenazi, A., Francisco, G. E., Nolan, K. J., & Jayaraman, A. (2020) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-020-00702-5 · Cited by 160
Self-citationOptimizing Exoskeleton Assistance for Faster Self-Selected Walking
Song, S., & Collins, S. H. (2021) · IEEE Transactions on Neural Systems and Rehabilitation Engineering · doi:10.1109/tnsre.2021.3074154 · Cited by 112
Awad, L. N., Lewek, M. D., Kesar, T. M., Franz, J. R., & Bowden, M. G. (2020) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-020-00747-6 · Cited by 116
Self-citationHe, T., & Lee, C. (2021) · IEEE Open Journal of Circuits and Systems · doi:10.1109/ojcas.2021.3123272 · Cited by 100
A survey on soft lower limb cable-driven wearable robots without rigid links and joints
Mahmoudi, A., & Najafi, F. (2021) · Robotics and Autonomous Systems · doi:10.1016/j.robot.2021.103846 · Cited by 60
Soft Wearable Robots: Development Status and Technical Challenges
Shi, Y., Dong, W., Lin, W., & Gao, Y. (2022) · Sensors · doi:10.3390/s22197584 · Cited by 58
Pioneering healthcare with soft robotic devices: A review
Wang, Y., Xie, Z., Huang, H., & Liang, X. (2024) · Smart Medicine · doi:10.1002/smmd.20230045 · Cited by 57
Paternò, L., & Lorenzon, L. (2023) · Frontiers in Robotics and AI · doi:10.3389/frobt.2023.1075634 · Cited by 56
Continuous Prediction of Lower-Limb Kinematics From Multi-Modal Biomedical Signals
Yi, C., Jiang, F., Zhang, S., Guo, H. Y., Yang, C., Ding, Z., Wei, B., Lan, X., & Zhou, H. (2021) · IEEE Transactions on Circuits and Systems for Video Technology · doi:10.1109/tcsvt.2021.3071461 · Cited by 51
Soft robotic exosuit augmented high intensity gait training on stroke survivors: a pilot study
Shin, S. Y., Hohl, K., Giffhorn, M., Awad, L. N., Walsh, C. J., & Jayaraman, A. (2022) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-022-01034-2 · Cited by 45
Self-citationNassour, J., Hamker, F. H., & Cheng, G. (2020) · IEEE Transactions on Medical Robotics and Bionics · doi:10.1109/tmrb.2020.3012131 · Cited by 40
Human Assistance and Augmentation with Wearable Soft Robotics: a Literature Review and Perspectives
Yumbla, E. Q., Qiao, Z., Tao, W., & Zhang, W. (2021) · Current Robotics Reports · doi:10.1007/s43154-021-00067-0 · Cited by 41
Arens, P., Siviy, C., Bae, J., Choe, D. K., Karavas, N. C., Baker, T. C., Ellis, T. D., Awad, L. N., & Walsh, C. J. (2021) · Wearable Technologies · doi:10.1017/wtc.2020.11 · Cited by 38
Self-citationSloot, L. H., Baker, L. M., Bae, J., Porciuncula, F., Clément, B., Siviy, C., Nuckols, R. W., Baker, T. C., Sloutsky, R., Choe, D. K., et al. (2023) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-023-01231-7 · Cited by 37
Self-citationMa, L., Leng, Y., Jiang, W., Qian, Y., & Fu, C. (2021) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2021.3124081 · Cited by 35
Khan, M. A., Saibene, M., Das, R., Brunner, I. C., & Puthusserypady, S. K. (2021) · Journal of Neural Engineering · doi:10.1088/1741-2552/ac36aa · Cited by 35
Gait Pattern Recognition Based on Plantar Pressure Signals and Acceleration Signals
Zhang, M., Liu, D., Wang, Q., Zhao, B., Bai, O., & Sun, J. (2022) · IEEE Transactions on Instrumentation and Measurement · doi:10.1109/tim.2022.3204088 · Cited by 33
Lower-Limb Exosuits for Rehabilitation or Assistance of Human Movement: A Systematic Review
Koch, M. A., & Font-Llagunes, J. M. (2021) · Applied Sciences · doi:10.3390/app11188743 · Cited by 33
Walking on Real-World Terrain With an Ankle Exoskeleton in Cerebral Palsy
Tagoe, E. A., Fang, Y., Williams, J. R., & Lerner, Z. F. (2023) · IEEE Transactions on Medical Robotics and Bionics · doi:10.1109/tmrb.2023.3328649 · Cited by 32
Porciuncula, F., Baker, T. C., Revi, D. A., Bae, J., Sloutsky, R., Ellis, T. D., Walsh, C. J., & Awad, L. N. (2021) · Frontiers in Neurorobotics · doi:10.3389/fnbot.2021.689577 · Cited by 29
Self-citationSoft Magneto‐Responsive Shape Memory Foam Composite Actuators
Dezaki, M. L., & Bodaghi, M. (2022) · Macromolecular Materials and Engineering · doi:10.1002/mame.202200490 · Cited by 30
de Miguel-Fernández, J., Pescatore, C., Mesa-Garrido, A., Rikhof, C. J. H., Prinsen, E. C., Font-Llagunes, J. M., & Lobo-Prat, J. (2022) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2022.3183799 · Cited by 29
Lin, W., Dong, H., Gao, Y., Wang, W., Long, Y., He, L., Mao, X., Wu, D., & Dong, W. (2025) · Technologies · doi:10.3390/technologies13020069 · Cited by 28
Soft Exosuit Based on Fabric Muscle for Upper Limb Assistance
Park, S. J., Choi, K., Rodrigue, H., & Park, C. H. (2022) · IEEE/ASME Transactions on Mechatronics · doi:10.1109/tmech.2022.3194975 · Cited by 28
Chen, K., LOU, V. W. Q., & Cheng, C. Y. M. (2022) · Computers in Human Behavior · doi:10.1016/j.chb.2022.107610 · Cited by 29
Xie, R., Zhang, Y., Jin, H., Yang, F., Feng, Y., & Pan, Y. (2023) · Frontiers in Neurology · doi:10.3389/fneur.2023.1296102 · Cited by 26
George, J. A., Gunnell, A. J., Archangeli, D., Hunt, G. R., Ishmael, M. K., Foreman, K. B., & Lenzi, T. (2021) · Frontiers in Neurorobotics · doi:10.3389/fnbot.2021.700823 · Cited by 25
AI in therapeutic and assistive exoskeletons and exosuits: Influences on performance and autonomy
van der Kooij, H., van Asseldonk, E. H. F., Sartori, M., Basla, C., Esser, A., & Riener, R. (2025) · Science Robotics · doi:10.1126/scirobotics.adt7329 · Cited by 22
Hardware Circuits Design and Performance Evaluation of a Soft Lower Limb Exoskeleton
Cao, W., Ma, Y., Chen, C., Zhang, J., & Wu, X. (2022) · IEEE Transactions on Biomedical Circuits and Systems · doi:10.1109/tbcas.2022.3173965 · Cited by 21
Autonomous Control of Music to Retrain Walking After Stroke
Collimore, A. N., Cataldo, A. V. R., Aiello, A. J., Sloutsky, R., Hutchinson, K. J., Harris, B., Ellis, T. D., & Awad, L. N. (2023) · Neurorehabilitation and neural repair · doi:10.1177/15459683231174223 · Cited by 21
Self-citationPoggensee, K. L., & Collins, S. H. (2024) · Frontiers in Robotics and AI · doi:10.3389/frobt.2024.1283080 · Cited by 21
Morris, L., Cramp, M., & Turton, A. (2022) · Journal of Rehabilitation and Assistive Technologies Engineering · doi:10.1177/20556683221114790 · Cited by 20
Framework for Personalizing Wearable Devices Using Real-Time Physiological Measures
Kantharaju, P., Vakacherla, S. S., Jacobson, M., Jeong, H., Mevada, M. N., Zhou, X., Major, M. J., & Kim, M. (2023) · IEEE Access · doi:10.1109/access.2023.3299873 · Cited by 18
Gunnell, A. J., Sarkisian, S. V., Hayes, H., Foreman, K. B., Gabert, L., & Lenzi, T. (2025) · Communications Engineering · doi:10.1038/s44172-025-00440-3 · Cited by 17
Ankle Exoskeleton Assistance Increases Six-Minute Walk Test Performance in Cerebral Palsy
Conner, B. C., Orekhov, G., & Lerner, Z. F. (2021) · IEEE Open Journal of Engineering in Medicine and Biology · doi:10.1109/ojemb.2021.3135826 · Cited by 16
Ghobadi, N., Sepehri, N., Kinsner, W., & Szturm, T. J. (2024) · Actuators · doi:10.3390/act13120507 · Cited by 17
de Seta, V., & Romeni, S. (2025) · Frontiers in Neuroscience · doi:10.3389/fnins.2025.1569148 · Cited by 18
Heo, Y., Choi, H., Lee, J.-W., Cho, H., & Kim, G. (2023) · Applied Sciences · doi:10.3390/app14010301 · Cited by 15
Archangeli, D., Ortolano, B. M., Murray, R. C., Gabert, L., & Lenzi, T. (2025) · IEEE Transactions on Robotics · doi:10.1109/tro.2025.3539172 · Cited by 15
Porciuncula, F., Revi, D. A., Baker, T. C., Sloutsky, R., Walsh, C. J., Ellis, T. D., & Awad, L. N. (2023) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-023-01267-9 · Cited by 13
Self-citationKóra, S., Bíró, A., Prontvai, N., Androsics, M., Drotár, I., Prukner, P., Haidegger, T. P., Széphelyi, K., & Tollár, J. (2024) · Robotics · doi:10.3390/robotics13030044 · Cited by 15
Technologies and Applications of Soft Robotics: A Review
Joshi, J., Manral, A. R., & Kumar, P. (2023) · Journal of Graphic Era University · doi:10.13052/jgeu0975-1416.1128 · Cited by 12
The role of lower limb exoskeletons in rehabilitation: a scoping review
Abery, P., Canetti, E. F. D., & Hing, W. A. (2025) · Physical Therapy Reviews · doi:10.1080/10833196.2025.2465937 · Cited by 15
Lower-Limb Robotic Assistance Devices for Drop Foot: A Review
Al-Rahmani, N., Mohan, D. M., Awad, M. I., Wasti, S. A., Hussain, I., & Khalaf, K. A. (2022) · IEEE Access · doi:10.1109/access.2022.3174686 · Cited by 12
Model predictive control of an active ankle-foot orthosis with non-linear actuation constraints
DeBoer, B., Hosseini, A., & Rossa, C. (2023) · Control Engineering Practice · doi:10.1016/j.conengprac.2023.105538 · Cited by 11
Mohammadi, V., Ghalehney, S. M., Tajdani, M., Lee, S., & Behboodi, A. (2024) · Actuators · doi:10.3390/act13100381 · Cited by 11
Pruyn, K., Murray, R. C., Gabert, L., & Lenzi, T. (2024) · IEEE Transactions on Medical Robotics and Bionics · doi:10.1109/tmrb.2024.3503893 · Cited by 12
Kaymazlar, E., Dikbas, C., Matar, G. H., Andaç, Ö., & Andaç, M. (2024) · Polymer Bulletin · doi:10.1007/s00289-023-05122-8 · Cited by 11
Ankle Exoskeleton Assistance Can Affect Step Regulation During Self-Paced Walking
Canete, S., Wilson, E. B., & Jacobs, D. A. (2022) · IEEE Transactions on Neural Systems and Rehabilitation Engineering · doi:10.1109/tnsre.2022.3226766 · Cited by 11
The neuromuscular control for lower limb exoskeleton- a 50-year perspective
Chen, Y.-N., Wu, Y., & Yang, B.-S. (2023) · Journal of Biomechanics · doi:10.1016/j.jbiomech.2023.111738 · Cited by 10
Human-centered design of a novel soft exosuit for post-stroke gait rehabilitation
Krishnan, C., Adeeko, O. P., Washabaugh, E. P., Augenstein, T. E., Brudzinski, M., Portelli, A., & Kalpakjian, C. Z. (2024) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-024-01356-3 · Cited by 10
Medical & healthcare robotics: a roadmap for enhanced precision, safety, and efficacy
Iakovidis, D. K., Vartholomeos, P., Gall, A. L., Cianchetti, M., Ozioko, O., Dahiya, R., Mazomenos, E. B., Vasconcelos, F., Stoyanov, D. V., Philpott, J., et al. (2025) · Measurement Science and Technology · doi:10.1088/1361-6501/ae09bf · Cited by 10
A continuous statistical-geometric framework for normative and impaired gaits
Swaminathan, K., Tolkova, I., Baker, L. M., Revi, D. A., Awad, L. N., Walsh, C. J., & Mahadevan, L. (2022) · Journal of The Royal Society Interface · doi:10.1098/rsif.2022.0402 · Cited by 8
Self-citationWang, Y., Li, J., Liang, P., & Ye, R. (2025) · Journal of Mechanisms and Robotics · doi:10.1115/1.4067874 · Cited by 8
Archangeli, D., Ishmael, M. K., & Lenzi, T. (2022) · International Conference on Rehabilitation Robotics · doi:10.1109/icorr55369.2022.9896568 · Cited by 7
Development and Preliminary Evaluation of a Lower Body Exosuit to Support Ankle Dorsiflexion
Schubert, T., Wollesen, B., & Weidner, R. (2021) · Applied Sciences · doi:10.3390/app11115007 · Cited by 8
FleXo—Modular Flexible Back-Support Passive Exoskeleton
Ortiz, J., Fernández, J., Poliero, T., Monica, L., Anastasi, S., Draicchio, F., & Caldwell, D. G. (2021) · Biosystems & biorobotics · doi:10.1007/978-3-030-69547-7_54 · Cited by 7
Recent advances in wearable actuated ankle-foot orthoses: Medical effects, design, and control
Zhou, Y. (2022) · Proceedings of the Institution of Mechanical Engineers Part H Journal of Engineering in Medicine · doi:10.1177/09544119221142335 · Cited by 7
Design Methodology and Experimental Study of a Lower Extremity Soft Exosuit
He, L., Xu, C., & Guan, X. (2023) · Electronics · doi:10.3390/electronics12112502 · Cited by 7
Clinical Challenges in Soft Robotics
Malappuram, K. M., Chatterjee, K., Homer‐Vanniasinkam, S., & Nain, A. (2025) · Advanced Robotics Research · doi:10.1002/adrr.202400018 · Cited by 7
Portable hip exoskeleton improves walking economy for stroke survivors
Pruyn, K., Murray, R. C., Gabert, L., Foreman, K. B., & Lenzi, T. (2026) · Nature Communications · doi:10.1038/s41467-026-69580-0 · Cited by 7
Assessment of wearable robotics performance in patients with neurological conditions
Gerez, L. F., Micera, S., Nuckols, R. W., & Proietti, T. (2024) · Current Opinion in Neurology · doi:10.1097/wco.0000000000001328 · Cited by 6
Cataldo, A. V. R., Collimore, A. N., Spangler, J., Ribeirinha-Braga, L., Hutchinson, K. J., Wang, Q. M., Thompson, L. V., & Awad, L. N. (2023) · IEEE Open Journal of Engineering in Medicine and Biology · doi:10.1109/ojemb.2023.3313396 · Cited by 6
Self-citationKoginov, G., Sternberg, K., Wolf, P., Schmidt, K., Duarte, J. E., & Riener, R. (2022) · Wearable Technologies · doi:10.1017/wtc.2022.29 · Cited by 5
McNamara, M., & Dalton, S. G. (2024) · Journal of Transport & Health · doi:10.1016/j.jth.2024.101820 · Cited by 5
Generation of Gait Events with a FSR Based Cane Handle
Trujillo-León, A., de Guzmán-Manzano, A., Velázquez, R., & Vidal‐Verdú, F. (2021) · Sensors · doi:10.3390/s21165632 · Cited by 5
Zhou, Y., Zhang, D., Ji, Y., Bu, S., Hu, X., Zhao, C., Zhou, L., & Li, L. (2025) · Frontiers in Neuroscience · doi:10.3389/fnins.2025.1493988 · Cited by 4
Comparison of Five Rehabilitation Interventions for Acute Ischemic Stroke: A Randomized Trial
Tollár, J., Kóra, S., Kós, P., Vadászi, Z., Drotár, I., Prukner, P., Wersényi, G., Haidegger, T. P., Větrovský, T., & Hortobágyi, T. (2025) · Journal of Clinical Medicine · doi:10.3390/jcm14051648 · Cited by 5
Toward better assistive lower-limb exoskeletons: Insights from stroke survivors through co-design
Claeys, R., Embrechts, E., Debeuf, R., Firouzi, M., Bourazeri, A., Raedt, S. D., Moeyersons, C., Filtjens, B., Verstraten, T., Beckwée, D., et al. (2025) · Assistive Technology · doi:10.1080/10400435.2025.2541730 · Cited by 4
Xie, R., Sun, J., Yu, J., Zhang, Y., Jin, H., Zhu, X., Feng, Y., Sun, Y., Ji, L., Li, C., et al. (2025) · Journal of NeuroEngineering and Rehabilitation · doi:10.1186/s12984-025-01847-x · Cited by 5
Multi-Gait Recognition for a Soft Ankle Exoskeleton with Limited Sensors
Ma, L., Leng, Y., Zhang, K., Qian, Y., & Fu, C. (2021) · International Conference on Advanced Robotics and Mechatronics (ICARM) · doi:10.1109/icarm52023.2021.9536076 · Cited by 4
Sado, T., Motz, Z. L., Yentes, J. M., & Mukherjee, M. (2022) · Frontiers in Physiology · doi:10.3389/fphys.2022.916185 · Cited by 4
de Miguel-Fernández, J., Mesa-Garrido, A., Pescatore, C., Rikhof, C. J. H., Lobo-Prat, J., Font-Llagunes, J. M., & Prinsen, E. C. (2022) · doi:10.36227/techrxiv.20749789.v1 · Cited by 4
Fu, Z., Lin, Y., Xu, G., & Zhang, M. (2025) · IEEE Journal of Biomedical and Health Informatics · doi:10.1109/jbhi.2025.3623132 · Cited by 3
Tollár, J., Kóra, S., Széphelyi, K., Drotár, I., Prukner, P., Törő, B., Prontvai, N., Csutorás, B., Haidegger, T. P., & Hortobágyi, T. (2025) · Experimental Gerontology · doi:10.1016/j.exger.2025.112882 · Cited by 3
Sloutsky, R., Yücel, M. A., Collimore, A. N., Ottman, E., Ellis, T. D., Walsh, C. J., Boas, D. A., & Awad, L. N. (2021) · International IEEE/EMBS Conference on Neural Engineering · doi:10.1109/ner49283.2021.9441244 · Cited by 3
Self-citationSensing and Control Strategies for a Synergy-Based, Cable-Driven Exosuit via a Modular Test Bench
Jayakumar, A., Jorge, D., Bermejo-García, J., Agujetas, R., & Romero, F. (2023) · Sensors · doi:10.3390/s23104713 · Cited by 3
Design and characterization of a variable-stiffness ankle-foot orthosis
Rong, H., Ramezani, S., Ambro, A., Lei, C. H., & Choi, H. Y. (2024) · Prosthetics and Orthotics International · doi:10.1097/pxr.0000000000000323 · Cited by 3
Cooper, M., Canete, S., Eckert-Erdheim, A. M., Kimberley, A., Siviy, C., Baker, T. C., Ellis, T. D., Slade, P., & Walsh, C. J. (2024) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra57147.2024.10610736 · Cited by 3
Self-citationWang, J., Shu, J., Su, Y., Hu, C., Yeung, L.-F., Li, Z., & Tong, R. K. (2023) · Frontiers in Bioengineering and Biotechnology · doi:10.3389/fbioe.2023.1227327 · Cited by 3
Design and Evaluation of a Powered Hip Exoskeleton for Frontal and Sagittal Plane Assistance
Archangeli, D., Ortolano, B. M., Murray, R. C., Gabert, L., & Lenzi, T. (2024) · IEEE/RAS-EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob) · doi:10.1109/biorob60516.2024.10719876 · Cited by 2
Jayakumar, A., Bermejo-García, J., Jorge, D., Agujetas, R., Romero, F., & Sánchez, F. J. A. (2023) · Actuators · doi:10.3390/act12080309 · Cited by 2
Zhang, X., Fredriksen, A., Palmcrantz, S. M., & Gutierrez-Farewik, E. M. (2025) · International Conference on Rehabilitation Robotics · doi:10.1109/icorr66766.2025.11063163 · Cited by 1
Thurston, M., Piitulainen, H., Vujaklija, I., Avela, J., & Kulmala, J. (2025) · Clinical Biomechanics · doi:10.1016/j.clinbiomech.2025.106665 · Cited by 1
Towards Data-Driven Adaptive Exoskeleton Assistance for Post-stroke Gait
Weigend, F. C., Choe, D. K., Canete, S., & Walsh, C. J. (2025) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros60139.2025.11246935 · Cited by 1
Self-citationXu, Y., Li, Y., Zhang, S., Tan, K., Zhang, Y., Wang, C., Leng, Y., & Wu, X. (2026) · Biomimetic Intelligence and Robotics · doi:10.1016/j.birob.2026.100340 · Cited by 1
Beyond Human or Robot Administered Treadmill Training
Krebs, H. I., Walsh, C. J., Susko, T., Awad, L. N., Michmizos, K. P., Forner‐Cordero, A., & Saitoh, E. (2022) · Springer eBooks · doi:10.1007/978-3-031-08995-4_31 · Cited by 1
Self-citationRubino, N., Manchola, M. D. S., & Duenas, V. H. (2024) · IFAC-PapersOnLine · doi:10.1016/j.ifacol.2025.01.159 · Cited by 1
de Miguel-Fernández, J., Pescatore, C., Mesa-Garrido, A., Rikhof, C. J. H., Prinsen, E. C., Font-Llagunes, J. M., & Lobo-Prat, J. (2023) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros55552.2023.10341864 · Cited by 1
de Miguel-Fernández, J., Mesa-Garrido, A., Pescatore, C., Rikhof, C. J. H., Lobo-Prat, J., Font-Llagunes, J. M., & Prinsen, E. C. (2022) · doi:10.36227/techrxiv.20749789 · Cited by 1
A walk in the wild helps to tailor robotic leg exoskeletons
Rodriguez‐Guerrero, C. (2022) · Nature · doi:10.1038/d41586-022-03175-9
de Miguel-Fernández, J., Pescatore, C., Mesa-Garrido, A., Rikhof, C. J. H., Prinsen, E. C., Font-Llagunes, J. M., & Lobo-Prat, J. (2022) · IEEE/RAS-EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob) · doi:10.1109/biorob52689.2022.9925441
Using Robotic Exoskeletons for Overground Locomotor Training
Jayaraman, A., Rymer, W. Z., Giffhorn, M., & O’Brien, M. K. (2022) · Springer eBooks · doi:10.1007/978-3-031-08995-4_30
Model-Free Based Neural Network Time Delay Estimation Control for a 3-DOF Ankle Exoskeleton
Gu, H., Tian, Y., & Wang, H. (2023) · International Conference Automatics and Informatics (ICAI) · doi:10.1109/icai58806.2023.10339051
Requirements for a chainsaw operator’s exoskeleton
Vasilev, A. S., & Sukhanov, Y. (2024) · BIO Web of Conferences · doi:10.1051/bioconf/202411306002
Feasibility of a new soft ankle exoskeleton on people with dropfoot post-stroke
Zhang, X., Fredriksen, A., Gutierrez-Farewik, E. M., & Palmcrantz, S. M. (2024) · Gait & Posture · doi:10.1016/j.gaitpost.2024.07.286
Tlizamova, F. A., Efimtsev, A. Y., Труфанов, Г. Е., Иванова, Н. Е., Дорохова, Д. Д., & Levchuk, A. G. (2025) · Российский нейрохирургический журнал им профессора А Л Поленова · doi:10.56618/2071-2693_2025_17_3_111
Metadata
- Authors
- Awad, L. N., Kudzia, P., Revi, D. A., Ellis, T. D., & Walsh, C. J.
- Affiliations
- Boston University (US)
- Harvard University (US)
- Corresponding author
- Awad, Louis N.
- Walsh, Conor J.
- Venue
- IEEE Open Journal of Engineering in Medicine and Biology
- Published
- 2020
- Volume
- 1
- Pages
- 108-115
- ISSN
- 2644-1276 (ISSN-L)
- PMC
- PMC7971412
- OpenAlex
- W3014201768
- Cited by
- 111
- References
- 36
- Citations by year
- 2026: 9 · 2025: 19 · 2024: 17 · 2023: 19 · 2022: 23 · 2021: 18 · 2020: 6
- FWCI
- 5.18
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- IEEE Open Journal of Engineering in Medicine and Biology (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Funders
- National Institutes of Health (R01HD088619)
- American Heart Association (18TPA34170171)
- Wyss Institute at Harvard University
- Topics
- Physical Sciences › Engineering › Biomedical Engineering › Prosthetics and Rehabilitation Robotics
- Health Sciences › Medicine › Rehabilitation › Stroke Rehabilitation and Recovery
- Physical Sciences › Engineering › Biomedical Engineering › Soft Robotics and Applications
- Keywords
- stroke rehabilitation, gait assistance, walking speed, walking distance, energy expenditure, foot drop, paretic limb, powered exoskeleton, overground walking
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
