

Haptic-feedback smart glove as a creative human-machine interface (HMI) for virtual/augmented reality applications
Open accessThe DOI matches its Crossref record; 40 of the 40 references it cites were found in a registry or an index.
Abstract
A haptic-feedback glove with triboelectric sensors and piezoelectric stimulators is developed for interaction in virtual space.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures

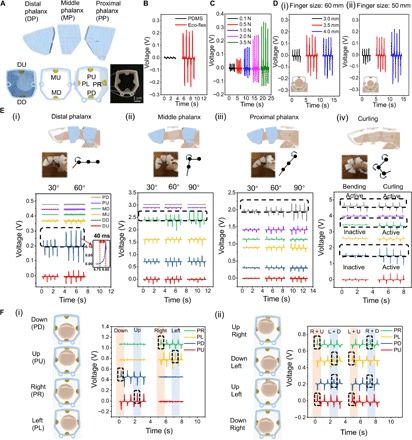
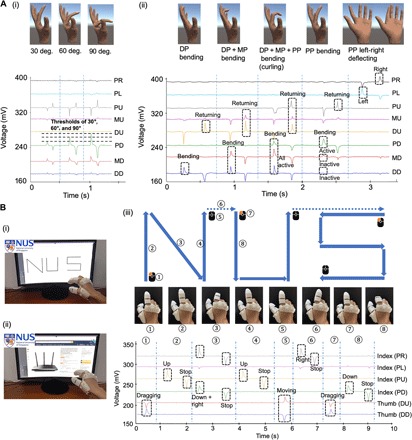


Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The check wasn’t confident either way, so it gives no verdict — never disputed.
In the citing paper
“Compared with the simulated feelings of sight, hearing, and smell, virtual tactile sense is much more difficult to be realized because it requires a fast-response, high-resolution, bio-friendly, and large-sized tactile stimulation technique”
From Self-powered electro-tactile system for virtual tactile experiences (2021) · cites this paper as [4]
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Skin-like pressure and strain sensors based on transparent elastic films of carbon nanotubes
Lipomi, D. J., Vosgueritchian, M., Tee, B. C.-K., Hellstrom, S. L., Lee, J. A., Fox, C. H., & Bao, Z. (2011) · Nature Nanotechnology · doi:10.1038/nnano.2011.184 · Cited by 3,188 · cited 1×
“In addition to conformability, different sensing mechanisms have also been studied widely, such as transistor-based (12), resistive-based (13), and capacitivebased (14) sensors for detecting strain, static force, and dynamic force, or even the slippery motions with high sensitivities (15).”
Skin-inspired highly stretchable and conformable matrix networks for multifunctional sensing
Hua, Q., Sun, J., Liu, H., Bao, R., Yu, R., Zhai, J., Pan, C., & Wang, Z. L. (2018) · Nature Communications · doi:10.1038/s41467-017-02685-9 · Cited by 1,413
Self-citationLearning the signatures of the human grasp using a scalable tactile glove
Sundaram, S., Kellnhofer, P., Li, Y., Zhu, J.-Y., Torralba, A., & Matusik, W. (2019) · Nature · doi:10.1038/s41586-019-1234-z · Cited by 1,162
Skin-integrated wireless haptic interfaces for virtual and augmented reality
Yu, X., Xie, Z., Yu, Y., Lee, J., Vazquez-Guardado, A., Luan, H., Ruban, J., Ning, X., Akhtar, A., Li, D., et al. (2019) · Nature · doi:10.1038/s41586-019-1687-0 · Cited by 1,025
Self-citationBoutry, C. M., Negre, M., Jorda, M., Vardoulis, O., Chortos, A., Khatib, O., & Bao, Z. (2018) · Science Robotics · doi:10.1126/scirobotics.aau6914 · Cited by 921
A transparent bending-insensitive pressure sensor
Lee, S., Reuveny, A., Reeder, J., Lee, S., Jin, H., Liu, Q., Yokota, T., Sekitani, T., Isoyama, T., Abe, Y., et al. (2016) · Nature Nanotechnology · doi:10.1038/nnano.2015.324 · Cited by 833
Noninvasive Brain-Actuated Control of a Mobile Robot by Human EEG
del R. Millan, J., Renkens, F., Mourino, J., & Gerstner, W. (2004) · IEEE Transactions on Biomedical Engineering · doi:10.1109/tbme.2004.827086 · Cited by 740 · cited 1×
“Furthermore, wrist bands containing electromyographic electrodes can record hand gestures ( 3 ), and electroencephalogram (EEG) electrodes are even able to detect human intentions directly, i.e., by detecting brain wave ( 4 ).”
Soft robot perception using embedded soft sensors and recurrent neural networks
Thuruthel, T. G., Shih, B., Laschi, C., & Tolley, M. T. (2019) · Science Robotics · doi:10.1126/scirobotics.aav1488 · Cited by 678 · cited 1×
“By leveraging the proper learning model for specific sensing application, more comprehensive information can be extracted for those simply designed sensors, such as motion sequences, touch forces, and slip-ping ( 30 ).”
Wearable Microfluidic Diaphragm Pressure Sensor for Health and Tactile Touch Monitoring
Gao, Y., Ota, H., Schaler, E. W., Chen, K., Zhao, A., Gao, W., Fahad, H. M., Leng, Y., Zheng, A., Xiong, F., et al. (2017) · Advanced Materials · doi:10.1002/adma.201701985 · Cited by 614
Tee, B. C. ‐., Chortos, A., Dunn, R. R., Schwartz, G., Eason, E., & Bao, Z. (2014) · Advanced Functional Materials · doi:10.1002/adfm.201400712 · Cited by 538
Cited by
Items 701–784 of 784
A shadow enabled non-invasive probe for multi-feature intelligent liquid surveillance system
Lian, L., Zhang, Q., Li, W., Wang, B., & Liang, Q. (2023) · Nanoscale · doi:10.1039/d3nr04983c
Abdulkareem, S. A., Alhayali, R. A. I., & Sultan, A. A. (2022) · International Conference on Current Research in Engineering and Science Applications (ICCRESA) · doi:10.1109/iccresa57091.2022.10352498
“In [17], the authors proposed a system highlighting the technology that stimulates the senses of touch and motion by using a smart glove with haptic feedback and triboelectric-based finger bending sensors, palm sliding sensors, and piezoelectric mechanical stimulators.”
BackgroundQian, Z., Xi, Z., Zhao, C., Wang, Z., Liu, Z., Ren, J., Guo, L., & Xu, M. (2023) · China Automation Congress (CAC) · doi:10.1109/cac59555.2023.10451126
“However, these resistive tactile sensor confronts the challenges such as creep issue and zero shift, greatly affecting their sensing performance [15].”
BackgroundA ST-GCN based Motion recognition scheme for upper limb rehabilitation exoskeleton
Chang, X.-D., Xia, K., Wang, Y., Sun, H., & Zhou, J. (2023) · International Symposium on Artificial Intelligence for Medicine Sciences (ISAIMS) · doi:10.1145/3644116.3644254
Hussain, M. D., Dudem, B., Kutsarov, D. I., & Silva, S. R. P. (2024) · SSRN Electronic Journal · doi:10.2139/ssrn.4869887
Development of Triboelectric Nanoenergy and Nanosystem (Tribo-NENS)
Lee, C., Sun, Z., & Zhang, Z. (2024) · IEEE International Conference on Nanotechnology (IEEE-NANO) · doi:10.1109/nano61778.2024.10628879
“…paper Energy harvesting [63] Screen printing electrode pattern & PET-shoe sole sensor Position sensing, identity recognition, energy harvesting [47],[48], [49] TENG sock sensor Walking pattern recognition, motion tracking [24],[8] Textile array on toilet seat Identification, health care [9] V.”
BackgroundSelf-citationActive Mechanical Haptics Constructed with Curved Origami
Zhang, Z., & Jiang, H. (2024) · Wiley eBooks · doi:10.1002/9783527842308.ch14
Self-citationAdvances in Flexible Electrotactile Devices for Restoration of Biomedical Haptic Sensation
Jin, Y., Wu, Z., Zhang, Y., Qi, J., & Lim, C. T. (2024) · IEEE Transactions on Materials for Electron Devices · doi:10.1109/tmat.2024.3483174 · Cited by 2
Wang, Y. (2024) · Elsevier eBooks · doi:10.1016/b978-0-443-15684-7.00030-0
Mandasari, A. R., Nababan, E. B., & Mawengkang, H. (2024) · International Conference on Technology Innovation and Its Applications (ICTIIA) · doi:10.1109/ictiia61827.2024.10761640
“The innovative concept of Glove lies in its ability to encode global statistical information into representations words by utilizing the frequency of occurrence of words together and the ratio probability of co-occurrence.. [10][13].”
Multistable Soft Actuator for Physical Human-robot Interaction
Long, J., Li, J., Diao, X., Zhou, C., Lu, G., & Feng, Y. (2024) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros58592.2024.10801795 · Cited by 1
Machine Learning Enhanced Smart Sensors for Hand Gesture Recognition
Feng, H. (2024) · International Symposium on Sensor Technology and Control (ISSTC) · doi:10.1109/isstc63573.2024.10824205 · Cited by 3
Yang, C. (2025) · Lecture notes in computer science · doi:10.1007/978-981-96-0795-2_17
Design and Application of a Novel Gesture-Sensing Skeleton Integrated With CNF/CB/Ecoflex Sensors
Zhang, M. Y., Shi, Y., Wei, Y., Mao, X., Li, H., & Wang, G. (2025) · IEEE Sensors Journal · doi:10.1109/jsen.2025.3531387
“The self-powered haptic feedback smart glove proposed by Zhu et al. [6] effectively captured hand motion information, but its intricate and bulky design severely constrained hand movement.”
Study of Fingerprint-Like Tactile Sensors Based on Triboelectric Nanogenerator
Qi, B., Zhao, J., Han, W., Yao, B., Du, T., & Xu, M. (2024) · China Automation Congress (CAC) · doi:10.1109/cac63892.2024.10865456
Hoang, N. N., Han, G. H., & Lee, J. W. (2025) · Ceramist · doi:10.31613/ceramist.2025.00080
Park, S. M., Lee, S. M., Kwon, Y. J., Cho, K. Y., Kim, S., & Lee, E. K. (2025) · Macromolecular Research · doi:10.1007/s13233-025-00401-x
“Recently, with the emergence of new media and interaction methods such as virtual reality (VR) and augmented reality (AR), the importance of various equipment that connects humans and machines has been highlighted [1].”
Enhancing the Precision of a User's Hand When Sliding on Objects in VR
Kozłowska, A., Wójcik, M., Spychała, M. J., Porter-Sobieraj, J., & Ciecierski, J. (2025) · Proceedings of the ACM on Computer Graphics and Interactive Techniques · doi:10.1145/3728307
“They concentrate, for example, on creating cheap and accurate glove systems [Choi et al. 2016; Zhu et al. 2020], reducing feedback latency, something greatly needed in remote surgery solutions [Sim et al. 2021] and on providing information about the texture of an object [Tanaka et al. 2023].”
Supple and Graspable XR Controller for Providing a Realistic Hand-Holding Sensation
Tanizawa, K., Kai, K., Masai, K., Mine, T., Arakawa, Y., Choi, H., & Fukushima, S. (2025) · Lecture notes in computer science · doi:10.1007/978-3-031-93828-3_8
Künstliche Intelligenz und Maschinelles Lernen: Definitionen und Grundlagen
Memmert, D., & Bakhtiar, L. A. (2025) · Springer eBooks · doi:10.1007/978-3-662-68950-9_1
AI and ML: Definitions and Basics
Memmert, D., & Bakhtiar, L. A. (2025) · Springer eBooks · doi:10.1007/978-3-662-70155-3_1
Flexible Devices: Introduction
Long, Y., & Zhai, Z. (2025) · Springer eBooks · doi:10.1007/978-3-031-91080-7_1
Duong, Q. V., Nguyen, V. P., Her, N., Nam, W., & Choi, S. T. (2025) · International Journal of Precision Engineering and Manufacturing · doi:10.1007/s12541-025-01324-4 · Cited by 1
“…in various fields such as robotics [ 1–3], virtual and augmented reality [4–6], wearable healthcare [7, 8], and human–machine interfaces [9–11], as they enable a Several types of mechanoreceptors, such as Meissner’s corpuscles, Merkel cells, Pacinian corpuscles, and Ruffini endings, are…”
Huang, Y., Li, D., Lian, Z., Xu, X., Liang, L., Zhou, X., Zhang, J., Liang, Y., & Li, H. (2025) · IEEE International Conference on Real-time Computing and Robotics (RCAR) · doi:10.1109/rcar65431.2025.11139581
“Although the literature [1, 7] uses 15 to 16 sensors, it still relies on traditional principal component analysis (PCA) or a single CNN model, which fails to fully explore the nonlinear relationship of spatio-temporal features.”
Vision-assisted vibrotactile haptic feedback for guidance in teleoperation
Sirwal, S. A., Ahmad, B., & Koul, M. H. (2025) · Industrial Robot the international journal of robotics research and application · doi:10.1108/ir-03-2025-0101
Wang, H., Zhou, Y., Luo, Y., Shi, W., Li, J., Xiao, M., Xie, R., Zou, B., Chen, H., Wang, Y., et al. (2025) · Research Square · doi:10.21203/rs.3.rs-7611464/v1
Chen, Z., Fu, Y., Deng, C., Zhao, C., Liu, Z., Chen, Y., Yan, H., Chen, Z., Lin, L., & Zheng, G. (2025) · Advanced Functional Materials · doi:10.1002/adfm.202518269
Flexible Electronic Device with Multifunctional Tactile Perception for Enhanced Robotic Interaction
Mao, C., Jin, J., Mei, D., & Wang, Y. (2025) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros60139.2025.11247251
“With the advances of flexible electronics and artificial intelligence, human-machine interactions (HMIs) have been greatly attracted in industry and human daily life [1].”
Lin, S., Sun, C., Huang, Y., Cheng, B., Luo, H., Zhu, M., Chen, T., Wang, F., & Sun, L. (2025) · Advanced Materials Technologies · doi:10.1002/admt.202501844 · Cited by 1
“Zhu et al. proposed a haptic feedback smart glove combining multifunctional sensors and machine learning techniques that can be applied to virtual reality with 96% accuracy [ 34 ].”
Self-citationJiang, Z. (2026) · Lecture notes in computer science · doi:10.1007/978-3-032-12657-3_12
Smart Glove: A Hand Gesture Recognition System and Home Automation
Godase, P. S. K., Shinde, A. H., Patil, A. N., Narayanpethkar, S. V., Kadam, G., & Takale, S. R. (2026) · Lecture notes in networks and systems · doi:10.1007/978-981-95-5079-1_24
Bhowmik, A. K. (2026) · Wiley eBooks · doi:10.1002/9781119615996.ch9
Haptic Acuity During Shared Grasp Experiences in Virtual Reality
Yu, P., Couch, G., Ferris, T. K., Hipwell, M. C., & Friesen, R. F. (2026) · IEEE Transactions on Haptics · doi:10.1109/toh.2026.3654548
“This pursuit of realism is critical, as grasping is a fundamental skill for interacting with virtual objects and is widely applied in fields such as medical palpation [10], [11], [12], VR gaming [13], and education [14], [15].”
Touch and Learn: A Gamified VR-Haptics Framework for Skillfull Palpation Training
Lesquerré-Caudebez, B., & Sanfilippo, F. (2026) · Lecture notes in networks and systems · doi:10.1007/978-3-032-14929-9_2
Abinaya, M., & Vadivu, G. (2026) · Lecture notes of the Institute for Computer Sciences, Social Informatics and Telecommunications Engineering · doi:10.1007/978-3-032-14805-6_8
(2026) · Elsevier eBooks · doi:10.1016/b978-0-44-327410-7.00040-5
Digitalizing olfactory and tactile senses with 6G
Parichenko, A., Sousa, B. G., Nuthalapati, S., Yin, C., Gao, Y., Riemenschneider, L., Rosenkranz, R., Huang, S., Li, S.-C., Altinsoy, M. E., et al. (2026) · Elsevier eBooks · doi:10.1016/b978-0-44-327410-7.00028-4
Robotic arm visual-servoing for AI-driven chess gameplay using LLM-based plannner
Ilgun, A. E., Cadirci, O., Ozkan, B., Akgul, B., & Bayraktar, E. (2026) · Neural Computing and Applications · doi:10.1007/s00521-025-11700-w
“Previous studies have used various types of manipulators, including a 6-axis articulated arm [ 33 , 34], a SCARA robot with a maximum success rate for pick and place after object detection [35], a complex dexterous hand [36], a gripper with eye-in-hand visual servoing [37 – 40], and soft robots…”
Chowdhury, S., Hoque, N. A., Ali, A., Ahammed, T., Bera, A., Sk, M. Y., Chaudhuri, S. S., & Acharya, S. (2026) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.5c22477
Spatiotemporal modulation haptic feedback with high spatial resolution and low perceived frequencies
Li, H., Wu, L., Ding, Y., Xu, C., Zhao, P., & Pei, Y. (2026) · Smart Materials and Structures · doi:10.1088/1361-665x/ae5435
“Haptic feedback is pivotal for enhancing immersion [1], enabling naturalistic social touch [2, 3] and imparting a vivid sense of realism to virtual interactions [4–7], which is fundamental to the development of the metaverse [8, 9].”
Lee, H.-G., Kim, J.-H., Jang, M.-G., Kim, J., & Kim, H. A. (2026) · Virtual Reality · doi:10.1007/s10055-026-01361-y
“Haptic feedback systems in AR environments can be significantly improved by using the reaction forces obtained by solving mechanical problems (Wang et al. 2007; Zhu et al. 2020; Yamamoto et al. 2012 ).”
Estimation of Fingertip Contact Angle from Tactile Pressure Contours
Tian, Q., Liu, J., Hou, F., & Guo, S. (2026) · Applied Sciences · doi:10.3390/app16073172
Gong, H., Ding, S., Qin, S., Wang, X., Meng, Z., Li, X., Zheng, L., Wang, Z. L., & Chen, X. (2026) · Advanced Materials Technologies · doi:10.1002/admt.70964
Xu, W., Wang, Z., & Ji, X. (2026) · Sensors and Actuators A Physical · doi:10.1016/j.sna.2026.117811
Son, J., Kang, J. H., Park, J., Ku, Y.-G., Lee, Y., Kim, J., Kim, M., Lee, J. H., Shin, J., Song, M., et al. (2026) · Advanced Science · doi:10.1002/advs.75103 · Cited by 1
Chenying, 何. H., ZHANG, Y., Zhou, T., Chen, J., Wei, L., Yang, C., & Chen, M. (2026) · Journal of Materials Chemistry C · doi:10.1039/d6tc00121a
Zhou, L., Altmann, A. A., Xu, X., Zhang, T., Wang, Y., Zhukov, S., Ma, X., Kupnik, M., & Zhang, X. (2026) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.6c05630
Kim, H. Y., Roh, J., Ju, H., Ji, W., Mahato, M., Yoo, H., & Oh, I.-K. (2026) · Small Structures · doi:10.1002/sstr.202600017
Gesture Recognition Towards Presentation Control
Mujawar, S., Gudi, V., Gutti, A. B., & Mallibhat, K. (2026) · International Conference on Knowledge Engineering and Communication Systems (ICKECS) · doi:10.1109/ickecs70176.2026.11527778
“…communicate with computer via body movements and gestures,for example, hand gesture controlled systems [4]. haptic interface, it allow users to interact with the systems through touch sensations,by providing force, vibration, or tactile feedback to the user.example ,smartphone vibration [5] [6].”
Designing Full‐Color Holographic Plastic With High Reliability for AR Displays
Guo, H., Xie, Y., 吕登夫, Yonggui, L., Peng, H., & Xie, X. (2026) · Advanced Optical Materials · doi:10.1002/adom.71339
Yuan, Y., Zhao, C., Ronchini, M., Nishio, Y., Zhong, D., Wu, C., Kweon, H., Sun, Z., Mow, R. K., Shi, Y., et al. (2026) · Device · doi:10.1016/j.device.2026.101204
Self-citationMultiaxis Force and Moment Estimation Using Spatially Distributed Optical Sensing on the Finger Back
Honda, Y., Ikejima, R., Himeda, S., Kawaguchi, H., & Izumi, S. (2026) · IEEE Sensors Letters · doi:10.1109/lsens.2026.3705741
“Human tactile sensors for measuring interaction forces are essential in robotics, virtual reality, and healthcare applications [1], [2], [3].”
Triboelectric fabric pressure sensor operating reliably in high-humidity environments
Tao, Q., Zhang, C., Zhang, Y., Wang, R., Hu, J., Madden, J. D. W., & Jiang, J. (2026) · Chemical Engineering Journal · doi:10.1016/j.cej.2026.178926
Zhen, Y., Tu, X., Wang, F., Wang, X., Fang, H., Chen, W., Tong, L., & Zhang, L. (2026) · 中国科学通报:英文版 · doi:10.1016/j.scib.2026.07.010
Ren, H., Li, W., Li, H., Li, J., Ding, Y., Feng, Y., Li, J., Yang, H., Jiang, L., Liu, H. F., et al. (2026) · Advanced Materials · doi:10.1002/adma.73955
Self-citationArtificial structures for human‐machine interfaces with closed‐loop interaction
Hu, T., Pan, T., Chen, S., Zhang, Y., & Lin, Y. (2026) · FlexMat. · doi:10.1002/flm2.70113
Gao, T., Ma, J.-N., Zhang, H., Zhang, J., Zhao, Q., Ma, B., Kong, D., Wang, H., Gao, H., Fu, X., et al. (2026) · Advanced Materials Technologies · doi:10.1002/admt.71155
“…the rapid development of the Internet of Things (IoT) and Artificial Intelligence (AI) [ 1–4 ], flexible wearable electronics are playing an increasingly indispensable role in cutting-edge domains including Human-Machine Interaction (HMI) [ 5–7 ], Virtual Reality (VR) [ 8 ], and telemedicine [ 9 ].”
Time-Series Imaging for Air-Writing Chinese Character Recognition
Yang, R., & Yang, D. (2026) · Communications in computer and information science · doi:10.1007/978-981-92-3560-5_18
Design and testing of a piezoelectric–electromagnetic composite power generator
Tian, X., Chen, Z., Song, J., Miao, B., & Liu, X. (2026) · Engineering Research Express · doi:10.1088/2631-8695/ae8b7a
“…etc, but their batteries need to be recharged frequently and do not have a long lifespan [3–5], and traditional batteries have defects in portability and lightness, so the use of piezoelectric capture technology to power small wearable devices has become a hotspot of the current research [6–8].”
Lai, S., Lin, H.-Y., Wang, Y., & Wu, J. M. (2026) · Nanoscale · doi:10.1039/d6nr00626d
Perception‐Feedback Mapping Strategies for Flexible Human–Machine Interfaces
Yang, R., Xu, S., Pang, W., & Zhang, Y. (2026) · Advanced Materials · doi:10.1002/adma.74589
“In other cases, continuous interaction signals are rendered as stepwise vibrotactile feedback, for example, by mapping pressure magnitude, touch speed, or temperature intervals onto different vibration frequencies or amplitudes [ 95, 187, 188 ].”
InfluentialCoinage-Metal-Based Nanostructures: Multifunctional Nanomaterials for Energy Harvesting
Lah, N. A. C., Azhari, A., & Zhang, Y. (2026) · Transactions of Tianjin University · doi:10.1007/s12209-026-00498-w
Zhou, W., Jian, B., Qiang, F., Yin, Z., & Yan, W. (2026) · IEEE Internet of Things Journal · doi:10.1109/jiot.2026.3725155
“Consequently, RGB-D indoor-scene dense prediction has gained attention, with applications extending to advanced areas, such as robotics, virtual reality, and augmented reality [6].”
On the discoveries of nanogenerators and piezotronics – A reflection at the 20th anniversary
Wang, Z. L. (2026) · Nano Energy · doi:10.1016/j.nanoen.2026.112327 · Cited by 1
Geometry-mediated decoupling of multidimensional forces in flexible anisotropic tactile sensors
Liu, S., Qiu, J., Yu, X., Gao, P., Guo, Y., Yang, L., & Jiang, K. (2026) · Chemical Engineering Journal · doi:10.1016/j.cej.2026.181055
Zhang, Z., & Luan, H. (2026) · FlexTech · doi:10.1002/fle2.70018
“By transforming thermal regulation hardware into high‐fidelity perceptual interfaces, these systems satisfy a growing demand for immersive educational, cultural, and interactive digital environments [185].”
Self-citationFu, H., Zhou, R., Huang, X., Zhang, S., Zhang, W., Wu, D., Huang, Y., Xu, H., & Wan, C. (2026) · Composites Science and Technology · doi:10.1016/j.compscitech.2026.111834
Structural Evolution of Biomedical Microrobots: From Rigid to Soft to Rigid–Soft Integrated Systems
Wang, G., Liang, H., Liu, X., Xiao, W., Wang, D., Bi, J., Aierken, A., Liu, M., Xu, Z., Gao, C., et al. (2026) · Gels · doi:10.3390/gels12090803
Chen, J., Wu, X., Yin, H., Cao, W., Peng, X., Liang, X., Hu, K., Zhao, Y., Chen, J., Li, Y., et al. (2026) · Small · doi:10.1002/smll.75635
Rolling-mode triboelectric nanogenerators from energy harvesting to self-powered sensing and beyond
Wang, Y., Xi, Z., Li, Y., Zhao, H., Zhang, Y., Zheng, Y., Du, H., Yu, H., Wu, M., Du, T., et al. (2026) · Cell Reports Physical Science · doi:10.1016/j.xcrp.2026.103525
Ren, C., Zhao, Y., Teng, J., Dong, K., Xu, J., Cao, Z., & Ye, X. (2026) · Advanced Functional Materials · doi:10.1002/adfm.78285
Sima, Z., Wang, J., Sun, X., Huang, D., Lei, H., Zhang, L., Wei, Y., Wei, W., Liu, Y., Wen, Z., et al. (2026) · Nano Energy · doi:10.1016/j.nanoen.2026.112396
Galanos, A., Bousoulas, P., Tsioustas, C., & Tsoukalas, D. (2026) · Sensors and Actuators A Physical · doi:10.1016/j.sna.2026.118506
Abbas, R., Umair, M., Fu, Z. Q., Luo, J., Yu, S., & Wei, J. (2026) · Small Methods · doi:10.1002/smtd.71040
Jingyan, D., Jun, L., Liu, L., Wu, H., Hu, D., Chen, X., & Ou‐Yang, W. (2026) · Small · doi:10.1002/smll.75850
A state-evolving self-powered Interface for continuous contactless-to-contact coupled perception
Liu, S., Huang, Y., Mao, B., Wanyan, B., Lu, H., Weng, C., Lou, Z., & Liu, M. (2026) · Chemical Engineering Journal · doi:10.1016/j.cej.2026.182277
Tian, Z., Lin, C., Zhang, D., & Ding, L. (2026) · Chemical Engineering Journal · doi:10.1016/j.cej.2026.182286
Surface Feature Detection Using a Finger-Back Optical Tactile Sensor
Honda, Y., Ando, K., Ikejima, R., Kushihashi, M., Kawaguchi, H., & Izumi, S. (2026) · IEEE International Instrumentation and Measurement Technology Conference · doi:10.1109/i2mtc66907.2026.11694580
“Technologies that quantitatively evaluate human tactile perception hold promise in a wide range of applications, including affective sensing, robotics, and assistive systems for individuals with disabilities [1], [2].”
Zhao, J., Lv, J., Cheng, Z., Yang, J., Wu, W., & Fan, Z. (2026) · Journal of Electrostatics · doi:10.1016/j.elstat.2026.104384
Electrotactile interface enabled by EMG-based perception decoding for information delivery
Guo, J., Du, Y., Ning, H., 张忠强, Wang, Z. L., & Wei, D. (2026) · Chemical Engineering Journal · doi:10.1016/j.cej.2026.182738
Exploring 4-5-year-olds’ learning experience with the augmented reality (AR) smart glasses
Geng, G. H., Disney, L., Green, K., & Zhu, Y. (2026) · International Journal of Child-Computer Interaction · doi:10.1016/j.ijcci.2026.100859 · Cited by 1
A Data-Driven High-Sensitivity Biomimetic Whisker SensorPreprint
Hou, Y., 褚慶澎, Li, J., Cao, A., Wu, J., Deng, Y., He, J., & Chou, X. (2026) · Research Square · doi:10.21203/rs.3.rs-10878484/v1
Liu, L., Ouyang, Z., Zhang, M., Yao, J., Jia, X., Zhang, P., Han, B., Gu, Y., & Xu, Y. (2026) · Advanced Functional Materials · doi:10.1002/adfm.79109
Shi, Y., Feng, C., Xu, Z., Liang, Y., Liu, X., Yuan, X., Luo, J., Zhang, J., Qin, Y., & Shen, G. (2026) · Advanced Functional Materials · doi:10.1002/adfm.79266
Metadata
- Authors
- Zhu, M., Sun, Z., Zhang, Z., Shi, Q., He, T., Liu, H., Chen, T., & Lee, C.
- Affiliations
- National University of Singapore (SG)
- Soochow University (CN)
- Corresponding author
- Chen, Tao
- Lee, Chengkuo
- ORCID
- Venue
- Science Advances
- Published
- 2020-05-08
- Volume
- 6
- Issue
- 19
- Pages
- eaaz8693-eaaz8693
- ISSN
- 2375-2548 (ISSN-L)
- PMC
- PMC7209995
- OpenAlex
- W3022965290
- Cited by
- 784
- References
- 40
- Citations by year
- 2026: 96 · 2025: 132 · 2024: 154 · 2023: 144 · 2022: 136 · 2021: 99 · 2020: 23
- FWCI
- 31.58
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- cc-by-nc
- Locations
- Science Advances (publishedVersion, cc-by-nc)
- PubMed Central (publishedVersion, cc-by-nc)
- PubMed (publishedVersion)
- National University of Singapore (submittedVersion)
- Funders
- HIFES Seed Funding (R-263-501-012-133)
- Agency for Science, Technology and Research (A*STAR), Singapore and Narodowe Centrum Badańi Rozwoju (NCBR), Poland Joint Grant (R-263-000-C91-305)
- National Research Funding - Competitive Research Programme (R-719-000-001-281)
- Topics
- Physical Sciences › Engineering › Biomedical Engineering › Advanced Sensor and Energy Harvesting Materials
- Life Sciences › Neuroscience › Cognitive Neuroscience › Tactile and Sensory Interactions
- Physical Sciences › Computer Science › Human-Computer Interaction › Hand Gesture Recognition Systems
- Keywords
- haptic feedback, smart glove, human-machine interaction, triboelectric sensors, finger bending detection, piezoelectric actuators, haptic stimulation, object recognition, virtual reality, augmented reality, low-cost wearable sensing, hand gesture recognition
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
