

Self-contained soft electrofluidic actuators
Open accessThe DOI matches its Crossref record; 51 of the 51 references it cites were found in a registry or an index.
Abstract
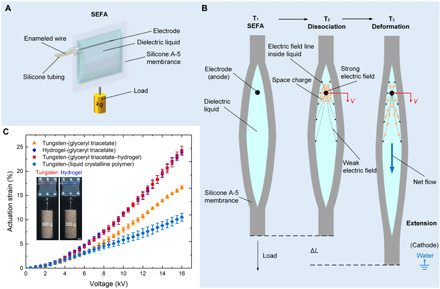
Self-contained soft electrofluidic actuators display excellent performance in portability, rapid response, and actuation.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures

Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“In contrast to soft pneumatic actuators that demand gas supplements and tendon driven actuators that require motors, EAP actuators are activated directly through electrical signals.[488,489]”
From Flexible Electronics and Devices as Human–Machine Interfaces for Medical Robotics (2022) · cites this paper as [489]
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Design, fabrication and control of soft robots
Rus, D., & Tolley, M. T. (2015) · Nature · doi:10.1038/nature14543 · Cited by 5,825 · cited 1×
“The versatility of a SEFA can be easily realized by adjusting the stiffness of the membrane shell, resembling a commonly used approach for conventional fluidic actuators (2).”
A review of shape memory alloy research, applications and opportunities
Mohd Jani, J., Leary, M., Subic, A., & Gibson, M. A. (2014) · Materials & Design (1980-2015) · doi:10.1016/j.matdes.2013.11.084 · Cited by 4,078 · cited 1×
“For example, shape memory alloy actuators can provide large actuation force and high-power density (20), but the lack of controllability limits their applications because of poor control of thermal energy (21).”
BackgroundHigh-Speed Electrically Actuated Elastomers with Strain Greater Than 100%
Pelrine, R., Kornbluh, R., Pei, Q., & Joseph, J. (2000) · Science · doi:10.1126/science.287.5454.836 · Cited by 3,283
Shepherd, R. F., Ilievski, F., Choi, W., Morin, S. A., Stokes, A. A., Mazzeo, A. D., Chen, X., Wang, M., & Whitesides, G. M. (2011) · Proceedings of the National Academy of Sciences · doi:10.1073/pnas.1116564108 · Cited by 2,111
Wireless Power Transfer—An Overview
Zhang, Z., Pang, H., Georgiadis, A., & Cecati, C. (2019) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2018.2835378 · Cited by 1,723
Biomedical applications of soft robotics
Cianchetti, M., Laschi, C., Menciassi, A., & Dario, P. (2018) · Nature Reviews Materials · doi:10.1038/s41578-018-0022-y · Cited by 1,435
Advances in Dielectric Elastomers for Actuators and Artificial Muscles
Brochu, P., & Pei, Q. (2010) · Macromolecular Rapid Communications · doi:10.1002/marc.200900425 · Cited by 1,387
Soft Actuators for Small-Scale Robotics
Hines, L., Petersen, K., Lum, G. Z., & Sitti, M. (2017) · Advanced Materials · doi:10.1002/adma.201603483 · Cited by 1,337
Ferromagnetic soft continuum robots
Kim, Y., Parada, G. A., Liu, S., & Zhao, X. (2019) · Science Robotics · doi:10.1126/scirobotics.aax7329 · Cited by 1,312
Deviations from Ohm's Law in Weak Electrolytes
Onsager, L. (1934) · The Journal of Chemical Physics · doi:10.1063/1.1749541 · Cited by 1,254
Cited by
Flexible Electronics and Devices as Human–Machine Interfaces for Medical Robotics
Heng, W., Solomon, S., & Gao, W. (2022) · Advanced Materials · doi:10.1002/adma.202107902 · Cited by 609
A versatile jellyfish-like robotic platform for effective underwater propulsion and manipulation
Wang, T., Joo, H.-J., Song, S., Hu, W., Keplinger, C., & Sitti, M. (2023) · Science Advances · doi:10.1126/sciadv.adg0292 · Cited by 177
Untethered soft actuators for soft standalone robotics
Jung, Y., Kwon, K., Lee, J., & Ko, S. H. (2024) · Nature Communications · doi:10.1038/s41467-024-47639-0 · Cited by 176
Self-protection soft fluidic robots with rapid large-area self-healing capabilities
Tang, W., Zhong, Y., Xu, H., Qin, K., Guo, X., Hu, Y. H., Zhu, P., Qu, Y., Yan, D., Li, Z., et al. (2023) · Nature Communications · doi:10.1038/s41467-023-42214-5 · Cited by 106
“…15 – 17 , and some are easy to be customized 17 ; however, when embedded into fl uidic robots, their actuation performances are poor, resulting in slow actuation speed 15 – 18 , tiny output force 15 – 18 , limited actuation stroke 18,19 , or dif fi - cult to achieve diversi fi ed design 19 .”
Self-citationPowerful UAV manipulation via bioinspired self-adaptive soft self-contained gripper
Guo, X., Tang, W., Qin, K., Zhong, Y., Xu, H., Qu, Y., Li, Z., Sheng, Q., Gao, Y., Yang, H., et al. (2024) · Science Advances · doi:10.1126/sciadv.adn6642 · Cited by 87
Self-citationShao, Y., Long, F., Zhao, Z., Fang, M., Jing, H., Guo, J., Shi, X., Sun, A., Xu, G., & Cheng, Y. (2022) · Chemical Engineering Journal · doi:10.1016/j.cej.2022.140271 · Cited by 66
“Given its outstanding human-robot interaction and environmental adaptability [10], soft robotics have huge advantages and broad application prospects in wearable and implantable devices [11,12], medical care [13], complex terrain exploration [14], etc.”
Fast Large‐Stroke Sheath‐Driven Electrothermal Artificial Muscles with High Power Densities
Hu, X., Jia, J., Wang, Y., Tang, X., Fang, S., Wang, Y., Wang, J., Baughman, R. H., & Ding, J.-N. (2022) · Advanced Functional Materials · doi:10.1002/adfm.202200591 · Cited by 58
Zhong, Y., Tang, W., Zhang, C., Jiao, Z., Wu, D., Liu, W., Yang, H., & Zou, J. T. (2022) · Nano Energy · doi:10.1016/j.nanoen.2022.107741 · Cited by 57
Self-citationOrganic Flexible Electronics for Innovative Applications in Electronic Skin
Liu, X., Li, H., Tao, M., Yu, Y., Zhu, Z., Wu, D., Hu, X., & Chen, Y. (2024) · Advanced Materials Technologies · doi:10.1002/admt.202400661 · Cited by 61
Bioinspired Self-Resettable Hydrogel Actuators Powered by a Chemical Fuel
Xu, H., Bai, S., Gu, G., Gao, Y., Sun, X., Guo, X., Xuan, F., & Wang, Y. (2022) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.2c13368 · Cited by 47
Underwater fluid-driven soft dock for dynamic recovery of AUVs with improved pose tolerance
Lin, M., Yi, A., Lin, R., Wu, X., He, B., Zhang, B., & Yang, C. (2024) · Ocean Engineering · doi:10.1016/j.oceaneng.2024.118466 · Cited by 46
SoJel –A 3D printed jellyfish-like robot using soft materials for underwater applications
Matharu, P. S., Wang, Z. L., Costello, J. H., Colin, S. P., Baughman, R. H., & Tadesse, Y. T. (2023) · Ocean Engineering · doi:10.1016/j.oceaneng.2023.114427 · Cited by 43
Chen, N., Zhou, Y., Liu, Y., Mi, Y., Zhao, S., Yang, W., Che, S., Liu, H., Chen, F., Xu, C., et al. (2022) · Nano Research · doi:10.1007/s12274-022-4394-3 · Cited by 39
Course Control of a Manta Robot Based on Amplitude and Phase Differences
Hao, Y., Cao, Y., Cao, Y., Huang, Q., & Pan, G. (2022) · Journal of Marine Science and Engineering · doi:10.3390/jmse10020285 · Cited by 37
Photoelectric Synergistic Response Properties of the Ti3c2tx Mxene-Cnt/Pdms Bilayer Actuator
Li, H., Wu, Z. W., Xing, Y., Li, B., & Liu, L. (2022) · Nano Energy · doi:10.1016/j.nanoen.2022.107821 · Cited by 38
A self-powered soft triboelectric-electrohydrodynamic pump
Li, F., Sun, S., Wan, X., Sun, M., Zhang, S. L., & Xu, M. (2025) · Nature Communications · doi:10.1038/s41467-025-56679-z · Cited by 43
Yu, Z., Shang, J., Shi, Q., Xia, Y., Zhai, D., Wang, H., Huang, Q., & Fukuda, T. (2022) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.2c01838 · Cited by 30
Sun, H., Zhang, C., Pan, C., Hu, Z., Huang, Y., Tang, D., Xie, J., Dai, H., Hu, H., Li, T., et al. (2024) · Additive manufacturing · doi:10.1016/j.addma.2024.103979 · Cited by 25
Self-citationFluid‐Driven High‐Performance Bionic Artificial Muscle with Adjustable Muscle Architecture
Xie, D., Su, Y., Li, X., Chen, J., Shi, X., Liang, D., Yip, J. Y. W., Liu, J., Li, Z., & Tong, R. K. (2023) · Advanced Intelligent Systems · doi:10.1002/aisy.202200370 · Cited by 23
Lin, H., Qian, Y., Zhou, P., Lin, J., Luo, Z., Zhang, W., & Chen, L. (2024) · Small · doi:10.1002/smll.202400906 · Cited by 22
Xu, Y., Zhu, J., Chen, H., Yong, H., & Wu, Z. (2023) · Advanced Science · doi:10.1002/advs.202300935 · Cited by 24
Flexible pump for small-scale soft robotics: actuation, design and prospects
Sun, H., Zhao, J., Zhang, Y., & Xu, M. Z. (2024) · Measurement · doi:10.1016/j.measurement.2024.115299 · Cited by 24
Sustainable and untethered soft robots created using printable and recyclable ferromagnetic fibers
Tang, W., Gao, Y., Dong, Z., Han, D., Gorodov, V. V., Kramarenko, E. Y., & Zou, J. T. (2024) · Bio-Design and Manufacturing · doi:10.1007/s42242-024-00303-4 · Cited by 20
Self-citationOcyropsis‐Inspired Fast‐Swimming Transparent Soft Robots
Ye, Z., Yang, G., Dai, H., Gan, Y., Jian, Y., Xu, K., Deen, M. J., Xia, J., Tian, N., Yang, Y., et al. (2025) · Advanced Functional Materials · doi:10.1002/adfm.202421522 · Cited by 20
Self-citationPeng, J., Zhuo, J., Qiu, H., Normahmedov, O., Shi, M., Dong, H., Wang, L., Jiang, S., Zou, J., Gu, G., et al. (2026) · Science Robotics · doi:10.1126/scirobotics.ady9635 · Cited by 21
Self-citationHigh-performance liquid metal electromagnetic actuator fabricated by femtosecond laser
Chen, Y., Wu, H., Li, R., Jiang, S., Zhou, S., Cui, Z., Tao, Y., Zheng, X., Zhang, Q., Li, J., et al. (2024) · International Journal of Extreme Manufacturing · doi:10.1088/2631-7990/ad23ee · Cited by 24
“…methods (e.g. 3D printing [7, 8], mold shaping, and continuous spinning [9]), which successfully convert different energy sources (including magnetism [10–16], heat [17–21], electricity [22–26], light [27–30], pH [31–34], and humidity [35–38]) into the kinetic energy of small-scale soft actuators.”
MethodProgrammable Chemical Reactions Enable Ultrastrong Soft Pneumatic Actuation
Qu, Y., Tang, W., Zhong, Y., Sheng, Q., Xu, H., Qin, K., Li, Z., Guo, X., Gao, Y., Yang, H., et al. (2024) · Advanced Materials · doi:10.1002/adma.202403954 · Cited by 19
Self-citationChen, Y., Wu, H., Wang, X., Qiu, P., Wan, H., Jiao, J., Wang, D., & Zhang, Z. (2024) · Chemical Engineering Journal · doi:10.1016/j.cej.2024.156612 · Cited by 21
Advancing soft robotics: recent progress in dielectric elastomer and fluid actuators
Molla, M. H. O. R., Chen, J., & Xu, C. (2026) · npj Robotics · doi:10.1038/s44182-026-00074-3 · Cited by 25
Ji, H., Yu, L., Nie, S., Huo, L., Yin, F., & Hong, R. (2023) · Soft Robotics · doi:10.1089/soro.2022.0215 · Cited by 17
Origami‐Inspired Reconfigurable Soft Actuators for Soft Robotic Applications
Feng, Y., Yan, W., Song, J., Hong, Z., Qiu, H. N., Cui, K., Song, X., & Tan, J. (2024) · Advanced Materials Technologies · doi:10.1002/admt.202301924 · Cited by 17
Gao, Y., Tang, W., Zhong, Y., Guo, X., Qin, K., Wang, Y., Kramarenko, E. Y., & Zou, J. T. (2024) · Advanced Science · doi:10.1002/advs.202410167 · Cited by 17
Self-citationLiquid Manipulator with Printed Electrode Patterns for Soft Robotic Systems
Zhu, P., Tang, W., Jiao, Z., Xu, H., Hu, Y. H., Qu, Y., Yang, H., & Zou, J. T. (2023) · Advanced Materials Technologies · doi:10.1002/admt.202300308 · Cited by 18
Self-citationA Review of Somatic Design for Soft Robotic Grippers: From Parts Integration to Functional Synergy
Xu, Z., Shi, P., Yan, J., & Zhao, J. (2024) · Advanced Intelligent Systems · doi:10.1002/aisy.202300788 · Cited by 17
Human camouflage and expression via soft mask from reprogrammable chemical fluid skin
Zhong, Y., Tang, W., Gui, H., Sheng, Q., Xu, H., Qin, K., Guo, X., Yang, H., & Zou, J. T. (2025) · Science Advances · doi:10.1126/sciadv.adq6141 · Cited by 16
Self-citationA temperature-sensitive actuator based on AG/NIPAM delignification wood-based hydrogel
Xiong, J., Wu, R., Hu, Y., Guo, Z., Wang, S., & Mao, J. (2024) · Composite Structures · doi:10.1016/j.compstruct.2024.118580 · Cited by 12
Flexible electro-hydraulic power chips
Zhang, C., Chen, J., Xu, C., He, T., Zhang, X., Zhang, J., Sun, X., Xu, B., Zhu, Y., & Yang, H. (2025) · Nature Communications · doi:10.1038/s41467-025-56636-w · Cited by 20
Self-citationWang, J., Zhang, Y., Gu, Y., Jing, Z., Pan, L., Ju, J., Neogi, A., & Wang, Z. (2025) · Chemical Engineering Journal · doi:10.1016/j.cej.2025.160270 · Cited by 11
Self-citationPlanar Modeling and Sim-to-Real of a Tethered Multimaterial Soft Swimmer Driven by Peano-HASELs
Gravert, S.-D., Michelis, M. Y., Rogler, S., Tscholl, D., Buchner, T., & Katzschmann, R. K. (2022) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros47612.2022.9981192 · Cited by 16
“Multiple swimmers using electrostatic type actuators have also been shown before [27], [28].”
BackgroundOptimized design and performance testing of hydraulic electrostatic actuator
Ye, Y., He, Q., Yang, C., Xu, X., Xie, L., Liu, D., Zeng, B., & Leng, Z. (2024) · International Journal of Smart and Nano Materials · doi:10.1080/19475411.2024.2415972 · Cited by 10
“According to reference [49], initially, 12.612 g of ammonium formate was dissolved in 1000 mL of deionized water and vigorously stirred for 5 minutes, followed by the addition of formic acid to adjust the pH to 4.6.”
InfluentialYuan, Q., Du, H., Liang, Y., Li, H., Qu, R., & Ma, Z. (2023) · Sensors and Actuators A Physical · doi:10.1016/j.sna.2023.114918 · Cited by 9
Self-citationZheng, H., Fang, M., Long, F., Jing, H., Wang, B., Fan, X., Guo, J., Cheng, Y., & Sun, A. (2025) · Journal of Materials Chemistry A · doi:10.1039/d5ta01299f · Cited by 9
Ultrarobust and Lightweight Electro-Pneumatic Actuators for Soft Robotics
Yuan, Z., Li, J., Liu, L., Zhu, X., Wang, W., Dickey, M. D., Lum, G. Z., Chirarattananon, P., Luo, J., & Chen, R. (2025) · IEEE Transactions on Robotics · doi:10.1109/tro.2025.3559430 · Cited by 9
“It is worth noting that since EPAs can produce greater strain at the same voltage, these robots only require a voltage of 6 kV to function properly, which is lower than the operating voltage required by most EHA-based robots [27], [28], [29], [30], [31], [32], [33], [34].”
Self-citationMultifunctional robotic electrofluid for soft fluidic actuation
Tang, W., Zhu, P., Hu, Y. H., Guo, X., Wang, Y., Qin, K., Zhong, Y., Sheng, Q., Xu, H., Li, Z., et al. (2025) · eScience · doi:10.1016/j.esci.2025.100448 · Cited by 11
Self-citationSoft Electrohydraulic Bending Actuators for Untethered Underwater Robots
Lin, H., Chen, Y., & Tang, W. (2024) · Actuators · doi:10.3390/act13060214 · Cited by 7
“The swimming process of the underwater robot was captured by the camera at a fixed It can be found that under the excitation of the 16 kV, 1 Hz square wave signal, the motion path of the underwater robot showed a certain de fl ection.”
BackgroundMethodSelf-citationWu, S., Fang, J., Gao, X., Liu, R., Pei, F., Li, C., & Chen, C. (2025) · Small · doi:10.1002/smll.202411029 · Cited by 7
Zhang, C., Liu, F., Zhao, J., Hu, Y., Zhu, Y. C., Li, F., Sheng, S., Liu, H., Xu, Z., Cao, K., et al. (2025) · Nano Letters · doi:10.1021/acs.nanolett.5c02126 · Cited by 7
Self-citationHighly Dynamic Soft Electrohydraulic Origami Actuators for Agile and Multimodal Robotic Locomotion
Li, W., Zhang, Y., Li, G., Li, H., Tao, K., Zhang, W., & Xu, J. (2026) · SmartBot · doi:10.1002/smb2.70018 · Cited by 7
Young, O. M., Chen, C., Xu, X., Bentley, W. E., Fuge, M., Krieger, A., Mass, P. N., Kanter, J. P., Olivieri, L., & Sochol, R. D. (2022) · Solid-State Sensors, Actuators, and Microsystems Workshop (Hilton Head Workshop) · doi:10.31438/trf.hh2022.83 · Cited by 7
Zhao, Y. H., Xiang, R., Li, H., Wang, C., Zhang, J., Liu, X., & Hao, Y. (2024) · Biomimetics · doi:10.3390/biomimetics10010010 · Cited by 6
“In addition, the study in [35] provides insights for our gripper, particularly in enhancing response speed and energy conversion efficiency.”
Dynamic Tuning of Plasmonic Hot‐Spot Generation through Cilia‐Inspired Magnetic Actuators
Liman, G., Ergene, E., Yıldız, E., Hüküm, K. Ö., Huri, P. Y., Çetin, A. E., Usta, H., & Demirel, G. (2023) · Advanced Intelligent Systems · doi:10.1002/aisy.202200420 · Cited by 6
Mechanisms of electrostatic field-driven efficient spreading of biolubricant droplets
Xu, W., Zhao, X. F., Chang, X., Liu, T., Zhang, Y., Li, B., Yang, M., Liu, M., Cui, X., ZHANG, X., et al. (2026) · Tribology International · doi:10.1016/j.triboint.2026.111890 · Cited by 4
Single-Electrode Electrostatic Repulsion Phenomenon for Remote Actuation and Manipulation
Tang, W., Yan, D., Qin, K., Guo, X., Zhong, Y., Xu, H., Yang, H., & Zou, J. T. (2024) · Research · doi:10.34133/research.0393 · Cited by 4
Self-citationAn Integrated Electrohydraulic Soft Robotic Fish With 3D Maneuverability and Autonomous Control
Zhang, Z., Gao, Y., Liang, Y., Li, X., Qiu, H., Wang, Z., Zhou, F., & Li, T. (2026) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2026.3671540 · Cited by 5
“The proposed robotic fish employs a propulsion strategy based on median and/or paired fin (MPF) motion, a widely adopted swimming mode in bio-inspired robotic fish designs [9], [20], [21], [22].”
Self-citationWang, H., Cheng, X., Huang, P., Yu, M., Ma, J., Peng, S., Cheng, Y., Yu, Y., Yang, W., Wang, P., et al. (2022) · Actuators · doi:10.3390/act11030074 · Cited by 6
Winding printed electrode patterns to customize soft fiber pumps
Qi, Y., Jin, T., Wang, J., Yi, S., Wang, Y., Zhong, S., Yue, T., Zhang, Q., Tian, Y., Li, L., et al. (2025) · npj Flexible Electronics · doi:10.1038/s41528-025-00461-0 · Cited by 3
Self-citationSelf-contained hybrid electrostatic-pneumatic actuator for portable haptic applications
Choi, E., Sun, H., Choi, S., Lee, S., Yun, Y., Hwang, K., & Lee, S. (2025) · Sensors and Actuators A Physical · doi:10.1016/j.sna.2025.117202 · Cited by 3
Lymphatic‐Inspired and TENG‐Powered Soft Fiber Pumps for Soft Robots
Zhu, P., Tang, W., Guo, X., Jiao, Z., Sheng, Q., Wang, Y., Qin, K., Xu, H., Zhong, Y., Yang, H., et al. (2025) · SmartBot · doi:10.1002/smb2.70006 · Cited by 5
Self-citationMa, Z., Liu, J., Liu, H., & Huang, T. (2025) · Bio-Design and Manufacturing · doi:10.1631/bdm.2400389 · Cited by 3
Biomimetic Foxtail Grass Actuator Based on Liquid‐Gas Phase Transition
Mu, W., Li, B., Zhao, C., Du, J., Liu, Y., & Yin, R. (2025) · Advanced Materials Technologies · doi:10.1002/admt.202500487 · Cited by 3
Bio‐Inspired Rapid‐Responsive and Self‐Sensing Electrohydraulic Soft Actuator
Gan, Y., Tian, N., Ye, Z., Zhu, Z., Li, T., & Yang, G. (2026) · Advanced Materials Technologies · doi:10.1002/admt.202502394 · Cited by 1
“A significant challenge in soft robotics is designing actuators that combine large deformations, rapid response, and inherent sensing capabilities, all of which are essential for practical applications [ 5–10 ].”
Soft Electrohydraulic Actuators
Li, Y., Li, P. L., Shen, Y., Li, L., Jiao, W., Xu, J., & Li, W. (2026) · Advanced Functional Materials · doi:10.1002/adfm.76609 · Cited by 2
“…of integration into textiles, as shown in Figure 5C. Self-contained EHD actuators constitute a needle-plate planar EHD pump by forming an electrode pair with an internal cylindrical positive electrode and an external grounded electrode (Figure 5D) [124].”
InfluentialLi, W., Zhang, Y., Li, G., Li, H., Tao, K., Zhang, W., & Xu, J. (2024) · Research Square · doi:10.21203/rs.3.rs-5165216/v1 · Cited by 1
Tunable Lens Driven by Electrohydrodynamic Pumping
Liu, X., Chen, C., Zhang, C., Pei, Y. T., Cao, Y., & Li, B. (2024) · Advanced Engineering Materials · doi:10.1002/adem.202400898
Self-citationDesign and Performance Testing of Electro-fluidic Soft Actuator
Ye, Y., He, Q., Xie, L., Yang, C., & Ni, S. (2025) · Lecture notes in computer science · doi:10.1007/978-981-96-0795-2_22
Mimosa-inspired Electrohydraulic Soft Actuator with Fast Response
Gan, Y., Tian, N., Ye, Z., Dai, H., Dong, N., Chen, L., & Yang, G. (2024) · Annual Conference of the IEEE Industrial Electronics Society (IECON) · doi:10.1109/iecon55916.2024.10905541
Electro-conjugate Fluids in Smart Technologies
Hossain, F., & Hoque, M. E. (2025) · Springer eBooks · doi:10.1007/978-3-031-90406-6_6
Fan, S., Jia, F. L., Guo, J., & Liu, Y. (2025) · International Journal of Solids and Structures · doi:10.1016/j.ijsolstr.2025.113667
Ma, H., Yang, Y., He, Z., Ren, H., & Jiao, P. (2025) · Advanced Science · doi:10.1002/advs.202519885
“At the functionality level, achieving effective object interaction within microsecond-scale temporal windows presents a critical challenge [ 21, 22 ].”
Two‐Dimensionalizing and Light Programming of Soft Actuators Enable Adaptive Robots
Wang, Y., Tang, W., Guo, X., Qin, K., Zhu, P., Xu, H., Zhong, Y., Gao, Y., Sheng, Q., & Zou, J. (2026) · Advanced Functional Materials · doi:10.1002/adfm.202600067
“Although existing sheet-like actuators fabricated via lamination, coating, or printing offer simple structures and low cost [25–27], and some have even achieved locomotion via dielectric elastomer mechanisms [28] or electrothermal actuation [29], current planar strategies still face significant…”
Self-citationPlanar integrated electro-pneumatic actuator for amplified vertical protrusion
Choi, E., Sul, O., Sun, H., Lee, S., Choi, S., Lim, H., & Lee, S.-B. (2026) · Sensors and Actuators A Physical · doi:10.1016/j.sna.2026.118023
Microfabrication of Soft Millirobots Propelled by Low Voltage Electrohydraulic Actuators
Shmulevich, S., Hartmann, F., & Shea, H. R. (2026) · Advanced Materials Technologies · doi:10.1002/admt.71249 · Cited by 1
“At centimeter length scales, soft electrohydraulic actuators, of which the most widely used are HASEL actuators, have enabled large electrically controlled deformation by displacing an encapsulated dielectric liquid through electrostatic zipping of compliant electrodes [ 18–23 ].”
Fu, Y., Fan, Y., Wan, Z., Liu, C., & Wei, R. (2026) · Small · doi:10.1002/smll.75538
Spider-inspired bidirectional robotic joints driven by electrohydraulic multiaxial strain
Yuan, Z., Huang, S., Zhou, L., Zhu, X., Luo, J., Lum, G. Z., & Chen, R. (2026) · Science Advances · doi:10.1126/sciadv.aei2880
Metadata
- Authors
- Tang, W., Lin, Y., Zhang, C., Liang, Y., Wang, J., Wang, W., Ji, C., Zhou, M., Yang, H., & Zou, J.
- Affiliations
- State Key Laboratory Fluid Power and Mechatronic Systems (CN)
- Shandong University (CN)
- Hangzhou Dianzi University (CN)
- Corresponding author
- Zhang, Chao
- Zou, Jun
- ORCID
- Venue
- Science Advances
- Published
- 2021-08-20
- Volume
- 7
- Issue
- 34
- ISSN
- 2375-2548 (ISSN-L)
- PMC
- PMC8378814
- OpenAlex
- W3194817846
- Cited by
- 74
- References
- 51
- Citations by year
- 2026: 12 · 2025: 19 · 2024: 22 · 2023: 9 · 2022: 11 · 2021: 1
- FWCI
- 3.27
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Science Advances (publishedVersion, cc-by-nc)
- PubMed Central (publishedVersion, cc-by-nc)
- PubMed (publishedVersion)
- Funders
- National Natural Science Foundation of China (51875507, 51890885)
- the Fundamental Research Funds for the Central Universities (2020QNA4003)
- Topics
- Physical Sciences › Engineering › Biomedical Engineering › Soft Robotics and Applications
- Physical Sciences › Materials Science › Electronic, Optical and Magnetic Materials › Dielectric materials and actuators
- Physical Sciences › Engineering › Mechanical Engineering › Advanced Materials and Mechanics
- Keywords
- soft robotics, liquid dielectrics, elastomer deformation, artificial muscles, wearable assistive device, actuation performance
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
