

Edge YOLO: Real-Time Intelligent Object Detection System Based on Edge-Cloud Cooperation in Autonomous Vehicles
Open accessThe DOI matches its Crossref record; 58 of the 64 references it cites were found in a registry or an index; 3 of the 4 sources its claims cite were checked for support.
Abstract
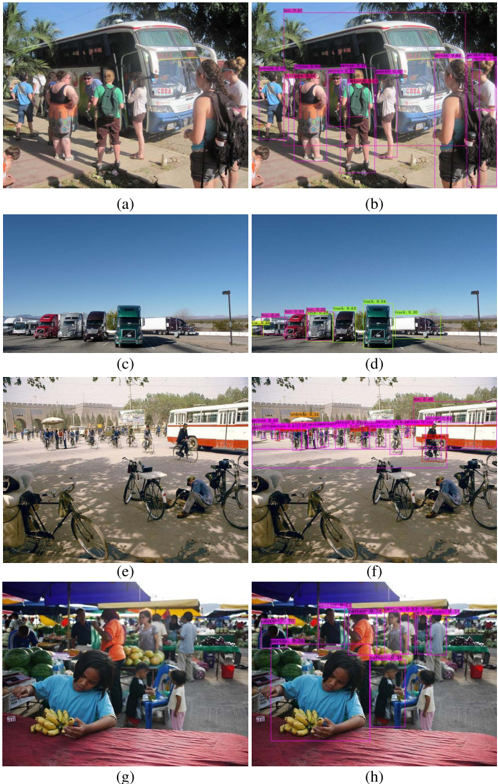
Driven by the ever-increasing requirements of autonomous vehicles, such as traffic monitoring and driving assistant, deep learning-based object detection (DL-OD) has been increasingly attractive in intelligent transportation systems. However, it is difficult for the existing DL-OD schemes to realize the responsible, cost-saving, and energy-efficient autonomous vehicle systems due to low their inherent defects of low timeliness and high energy consumption. In this paper, we propose an object detection (OD) system based on edge-cloud cooperation and reconstructive convolutional neural networks, which is called Edge YOLO. This system can effectively avoid the excessive dependence on computing power and uneven distribution of cloud computing resources. Specifically, it is a lightweight OD framework realized by combining pruning feature extraction network and compression feature fusion network to enhance the efficiency of multi-scale prediction to the largest extent. In addition, we developed an autonomous driving platform equipped with NVIDIA Jetson for system-level verification. We experimentally demonstrate the reliability and efficiency of Edge YOLO on COCO2017 and KITTI data sets, respectively. According to COCO2017 standard datasets with a speed of 26.6 frames per second (FPS), the results show that the number of parameters in the entire network is only 25.67 MB, while the accuracy (mAP) is up to 47.3%.
Overview
CoChat Summary
## TL;DR
Edge YOLO is a lightweight edge-cloud object detection system for autonomous vehicles that keeps real-time inference on Jetson edge devices while using the cloud for training and weight updates. The paper reports 47.3% mAP on COCO2017 at 26.6 FPS, with 25.27 MB model size and 8 million parameters.
## Key findings
- On COCO2017, Edge YOLO reached 47.3% mAP at 26.6 FPS with a model size of 25.27 MB; the paper also states the network has 8 million parameters and about 10.2% of the original YOLOv4 structure.
- On the KITTI 2D object dataset, Edge YOLO achieved 0.8212 mAP with 40.6 FPS on Jetson Xavier and 9.7 FPS on Jetson Nano, according to the comparison table.
- Compared with YOLOV3, YOLOV4, MobileNetV3 SSD, and YOLOV3-Tiny, Edge YOLO is presented as a balance between speed and accuracy; on COCO2017 it is reported at 26.6 FPS versus 11.8, 5.2, 11.4, and 62.7 FPS for those baselines, respectively, with the corresponding mAP values listed in Table V.
- The paper states average power consumption is 16.8 W and claims the edge-cloud cooperation scheme improves real-time performance while reducing dependence on cloud resources.
## Methods
- The system is an edge-cloud cooperation (E-CC) design: the edge device performs real-time inference, while the cloud handles data upload, labeling, retraining, and weight updates.
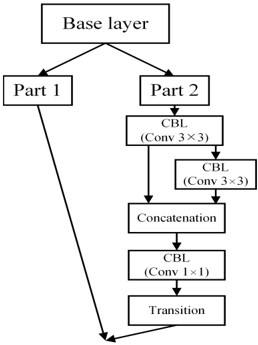
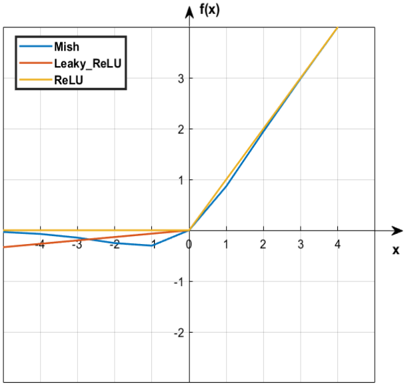
- The model is built by modifying YOLOv4: the paper says it trims the Backbone using channel pruning, simplifies the Neck by retaining SPP + FPN and removing PANet parts, and uses Leaky_ReLU plus TensorRT for acceleration.
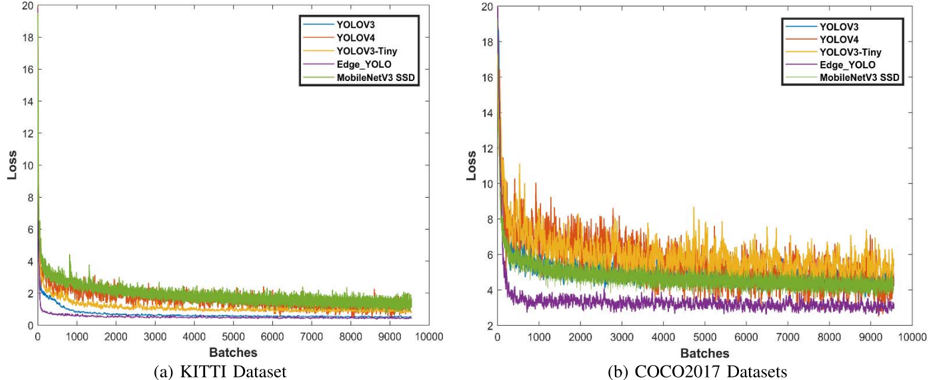
- Experiments use COCO2017 and KITTI 2D Object Dataset, with training in Ubuntu 18.04 using PyTorch 1.6 for MobileNetV3 SSD and Darknet for YOLO-based networks; evaluation uses mAP, FPS, BFLOPS, size, and IoU = 0.5.
## Limitations
- The paper itself notes that in super multi-target detection, Edge YOLO is slightly inferior to YOLOV4 because of the limited number of network layers and parameters.
- The text makes evident that reported performance depends on specific hardware and inference settings, including Jetson Xavier/Nano, TensorRT FP16, and the stated network environment; this limits direct generalization beyond the tested setup.
- The paper states that mAP drops to a certain extent during FP16 accelerated inference on the large COCO2017 dataset.
Model-written summary. Check it against the paper before relying on it.
Integrity signals
Registry
Cites
Statistics
Figures








Verification
Claims the paper makes
3 Valid · 4 Not valid · 1 Not checked · 51 Own results and interpretations
Every source the paper cites for this claim was checked and supports it.
In the paper
“Based on the latest object detection network YOLOV4 [19] in the YOLO series, the proposed Edge YOLO is more suitable for edge computing scenarios based on 5G for traffic safety monitoring and driving assistance.”
What the sources say
- Supportedcites [19] [19] A. Bochkovskiy, C.-Y. Wang, and H.-Y. M. Liao, 'YOLOv4: Optimal speed and accuracy of object detection,' 2020, arXiv:2004.10934 . - source
The citation is attached to YOLOv4 as the network on which the citing authors base their proposed Edge YOLO. The source identifies and describes YOLOv4 in §3.4 (p. 7); the statement about Edge YOLO’s suitability for 5G edge computing is the citing authors’ own claim, not one attributed to this source. (LLM, conf=0.91)
plainstates a cause- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
- Rests on an assumption not shown here.
- Supported
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Edge YOLO | 25.27 | 0.473 | 26.6 | 11.4 | 10.250G | 0.325 | 49.5 | 26.6 |”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
The paper states this without a source or data behind it here, so there is nothing to check it against. The quote shows it is in the paper.
In the paper
“The parameter quantity is only about 10% of the original network.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: unclear — It is unclear why the paper says it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, its mAP is up to 47.3%.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“According to COCO2017 standard datasets with a speed of 26.6 frames per second (FPS), the results show that the number of parameters in the entire network is only 25.67 MB, while the accuracy (mAP) is up to 47.3%.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
15 more claims
Create a free account to see all 59 claims and every source verdict.
- It may state two separate claims as one. 29
- Probably not a substantial claim. 14
- The quote only partly states this claim. 4
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Relying solely on edge devices may not handle all complex or rare defects, affecting overall inspection results, whereas relying entirely on cloud computing may encounter bottlenecks in network latency and data transmission [6].”
From Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning (2024) · cites this paper as [6]
Experimental — accuracy not yet measuredThe cited source says what the claim attributes to it.
In the citing paper
“Relying solely on edge devices may not handle all complex or rare defects, affecting overall inspection results, whereas relying entirely on cloud computing may encounter bottlenecks in network latency and data transmission [6].”
From Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning (2024) · cites this paper as [6]
Citations
Cites
Deep Residual Learning for Image Recognition
He, K., Zhang, X., Ren, S., & Sun, J. (2016) · 2016 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2016.90 · Cited by 235,474
ImageNet classification with deep convolutional neural networks
Krizhevsky, A., Sutskever, I., & Hinton, G. E. (2017) · Communications of the ACM · doi:10.1145/3065386 · Cited by 112,155
Faster R-CNN: Towards Real-Time Object Detection with Region Proposal Networks
Ren, S., He, K., Girshick, R., & Sun, J. (2017) · IEEE Transactions on Pattern Analysis and Machine Intelligence · doi:10.1109/tpami.2016.2577031 · Cited by 73,472
Densely Connected Convolutional Networks
Huang, G., Liu, Z., van der Maaten, L., & Weinberger, K. Q. (2016) · arXiv · doi:10.48550/arxiv.1608.06993 · Cited by 48,960
Densely Connected Convolutional Networks
Huang, G., Liu, Z., Van Der Maaten, L., & Weinberger, K. Q. (2017) · 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2017.243 · Cited by 48,566
Microsoft COCO: Common Objects in Context
Lin, T.-Y., Maire, M., Belongie, S., Hays, J., Perona, P., Ramanan, D., Dollár, P., & Zitnick, C. L. (2014) · Lecture Notes in Computer Science · doi:10.1007/978-3-319-10602-1_48 · Cited by 45,460
Rich Feature Hierarchies for Accurate Object Detection and Semantic Segmentation
Girshick, R., Donahue, J., Darrell, T., & Malik, J. (2014) · 2014 IEEE Conference on Computer Vision and Pattern Recognition · doi:10.1109/cvpr.2014.81 · Cited by 32,684
(2016) · Cited by 31,590
Feature Pyramid Networks for Object Detection
Lin, T.-Y., Dollar, P., Girshick, R., He, K., Hariharan, B., & Belongie, S. (2017) · 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2017.106 · Cited by 30,939
Girshick, R. (2015) · 2015 IEEE International Conference on Computer Vision (ICCV) · doi:10.1109/iccv.2015.169 · Cited by 28,105
Research works printed but not linked: 2
- [35] A. Howard et al. , 'Searching for MobileNetV3,' in Proc. IEEE/CVF Int. Conf. Comput. Vis. (ICCV) , Oct. 2019, pp. 1314-1324. -
- [27] R. Girshick, 'Fast R-CNN,' in Proc. IEEE Int. Conf. Comput. Vis. (ICCV) , Dec. 2015, pp. 1440-1448. -
Cited by
A Comprehensive Review of YOLO Architectures in Computer Vision: From YOLOv1 to YOLOv8 and YOLO-NAS
Terven, J., Córdova-Esparza, D.-M., & Romero-González, J.-A. (2023) · Machine Learning and Knowledge Extraction · doi:10.3390/make5040083 · Cited by 3,052
Liu, C., Wang, K., Li, Q., Zhao, F., Zhao, K., & Ma, H. (2024) · Neural Networks · doi:10.1016/j.neunet.2023.11.041 · Cited by 251
Sadaf, M., Iqbal, Z., Javed, A. R., Saba, I., Krichen, M., Majeed, S., & Raza, A. (2023) · Technologies · doi:10.3390/technologies11050117 · Cited by 205
Empowering Edge Intelligence: A Comprehensive Survey on On-Device AI Models
Wang, X., Tang, Z., Guo, J., Meng, T., Wang, C., Wang, T., & Jia, W. (2025) · ACM Computing Surveys · doi:10.1145/3724420 · Cited by 202
An Improved YOLOv8 to Detect Moving Objects
Safaldin, M., Zaghden, N., & Mejdoub, M. (2024) · IEEE Access · doi:10.1109/access.2024.3393835 · Cited by 171
Fast and accurate object detector for autonomous driving based on improved YOLOv5
Jia, X., Tong, Y., Qiao, H., Li, M., Tong, J., & Liang, B. (2023) · Scientific Reports · doi:10.1038/s41598-023-36868-w · Cited by 123
Advanced Learning Technologies for Intelligent Transportation Systems: Prospects and Challenges
Khalil, R. A., Safelnasr, Z., Yemane, N., Kedir, M., Shafiqurrahman, A., & Saeed, N. (2024) · IEEE Open Journal of Vehicular Technology · doi:10.1109/ojvt.2024.3369691 · Cited by 168
Object Detection in Traffic Videos: A Survey
Ghahremannezhad, H., Shi, H., & Liu, C. (2023) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2023.3258683 · Cited by 141
Mao, M., & Hong, M. (2025) · Sensors · doi:10.3390/s25072270 · Cited by 163
Bakırcı, M. (2024) · Digital Signal Processing · doi:10.1016/j.dsp.2024.104594 · Cited by 126
Qu, J., Liu, R. W., Gao, Y., Guo, Y., Zhu, F., & Wang, F. (2024) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2024.3359755 · Cited by 99
A multi-scale small object detection algorithm SMA-YOLO for UAV remote sensing images
Zhou, S., Zhou, H., & Qian, L. (2025) · Scientific Reports · doi:10.1038/s41598-025-92344-7 · Cited by 115
Rai, N., Zhang, Y., Villamil, M., Howatt, K., Ostlie, M. H., & Sun, X. (2023) · Computers and Electronics in Agriculture · doi:10.1016/j.compag.2023.108442 · Cited by 94
Rey, L., Bernardos, A. M., Dobrzycki, A. D., Carramiñana, D., Bergesio, L., Besada, J. A., & Casar, J. R. (2025) · Electronics · doi:10.3390/electronics14030638 · Cited by 72
Remote Sensing Micro-Object Detection under Global and Local Attention Mechanism
Li, Y., Zhou, Z., Qi, G., Hu, G., Zhu, Z., & Huang, X. (2024) · Remote Sensing · doi:10.3390/rs16040644 · Cited by 82
Analyzing Real-Time Object Detection with YOLO Algorithm in Automotive Applications: A Review
Gheorghe, C., Duguleană, M., Boboc, R. G., & Postelnicu, C. (2024) · Computer Modeling in Engineering & Sciences · doi:10.32604/cmes.2024.054735 · Cited by 116
Edge-Cloud Collaborative Computing on Distributed Intelligence and Model Optimization: A Survey
Liu, J., Du, Y., Yang, K., Wu, J., Wang, Y., Hu, X., Wang, Z., Liu, Y., Sun, P., Boukerche, A., et al. (2026) · IEEE Communications Surveys & Tutorials · doi:10.1109/comst.2026.3669216 · Cited by 152
M2FNet: Multi-modal fusion network for object detection from visible and thermal infrared images
Jiang, C., Ren, H., Yang, H. W., Huo, H., Zhu, P., Yao, Z., Li, J., Sun, M., & Yang, S. (2024) · International Journal of Applied Earth Observation and Geoinformation · doi:10.1016/j.jag.2024.103918 · Cited by 111
Avan, A., Azim, A., & Mahmoud, Q. H. (2023) · Electronics · doi:10.3390/electronics12122599 · Cited by 84
POSEIDON: A Data Augmentation Tool for Small Object Detection Datasets in Maritime Environments
Ruiz-Ponce, P., Ortiz-Pérez, D., García‐Rodríguez, J., & Kiefer, B. (2023) · Sensors · doi:10.3390/s23073691 · Cited by 67
Rose-Mamba-YOLO: an enhanced framework for efficient and accurate greenhouse rose monitoring
You, S., Li, B., Chen, Y., Ren, Z., Liu, Y., Wu, Q., Tao, J., Zhang, Z., Zhang, C., Xue, F., et al. (2025) · Frontiers in Plant Science · doi:10.3389/fpls.2025.1607582 · Cited by 65
A Low-Latency FPGA Accelerator for YOLOv3-Tiny With Flexible Layerwise Mapping and Dataflow
Kim, M., Oh, K., Cho, Y., Seo, H. S., Nguyen, X. T., & Lee, H. (2023) · IEEE Transactions on Circuits and Systems I Regular Papers · doi:10.1109/tcsi.2023.3335949 · Cited by 65
Liu, C., & Chou, J. (2022) · Automation in Construction · doi:10.1016/j.autcon.2022.104666 · Cited by 51
Bu, Y., Ye, H., Tie, Z., Chen, Y., & Zhang, D. (2024) · Sensors · doi:10.3390/s24113596 · Cited by 52
Kang, F., Huang, B., & Wan, G. (2025) · Automation in Construction · doi:10.1016/j.autcon.2025.105971 · Cited by 56
A Review of YOLO Algorithm and Its Applications in Autonomous Driving Object Detection
Wei, J., As’arry, A., Rezali, K. A. M., Yusoff, M. Z. M., Ma, H., & Zhang, K.-L. (2025) · IEEE Access · doi:10.1109/access.2025.3573376 · Cited by 88
Optimizing Edge AI: A Comprehensive Survey on Data, Model, and System StrategiesPreprint
Wang, X., & Jia, W. (2025) · Qeios · doi:10.32388/izohch · Cited by 56
Key Considerations for Real-Time Object Recognition on Edge Computing Devices
Surantha, N., & Sutisna, N. (2025) · Applied Sciences · doi:10.3390/app15137533 · Cited by 64
LoLTV: A Low Light Two-Wheeler Violation Dataset With Anomaly Detection Technique
Bose, S., Kolekar, M. H., Nawale, S., & Khut, D. (2023) · IEEE Access · doi:10.1109/access.2023.3329737 · Cited by 41
FDI-YOLO: Feature disentanglement and interaction network based on YOLO for SAR object detection
Wang, P., Luo, Y., & Zhu, Z. (2024) · Expert Systems with Applications · doi:10.1016/j.eswa.2024.125442 · Cited by 43
Improved YOLOv7 Algorithm for Small Object Detection in Unmanned Aerial Vehicle Image Scenarios
Li, X., Wei, Y., Li, J., Duan, W., Zhang, X., & Huang, Y. (2024) · Applied Sciences · doi:10.3390/app14041664 · Cited by 49
Monitoring activity index and behaviors of cage-free hens with advanced deep learning technologies
Yang, X. Y., Bist, R. B., Paneru, B., & Chai, L. (2024) · Poultry Science · doi:10.1016/j.psj.2024.104193 · Cited by 48
Near-Edge Computing Aware Object Detection: A Review
Setyanto, A., Sasongko, T. B., Fikri, M. A., & Kim, I. K. (2023) · IEEE Access · doi:10.1109/access.2023.3347548 · Cited by 49
Kutlimuratov, A., Khamzaev, J., Ataxonovich, K. T., Anwar, M. S., & Choi, A. (2023) · Sensors · doi:10.3390/s23115007 · Cited by 41
Vision-Based Anti-UAV Detection Based on YOLOv7-GS in Complex Backgrounds
Bo, C., Wei, Y., Wang, X., Shi, Z., & Xiao, Y. (2024) · Drones · doi:10.3390/drones8070331 · Cited by 47
EMG-YOLO: road crack detection algorithm for edge computing devices
Xing, Y., Han, X., Pan, X., et al. (2024) · Frontiers in Neurorobotics · doi:10.3389/fnbot.2024.1423738 · Cited by 29
Luo, S. X., Chen, W., Tian, W., Liu, R., Hou, L., Zhang, X., Shen, H., Wu, R., Geng, S., Zhou, Y., et al. (2024) · IEEE Transactions on Intelligent Vehicles · doi:10.1109/tiv.2024.3406372 · Cited by 63
Li, H., Li, X., Fan, Q., Xiong, Q., Wang, X., & Leung, V. C. M. (2023) · IEEE Transactions on Network and Service Management · doi:10.1109/tnsm.2023.3301718 · Cited by 31
GD-PAN: a multiscale fusion architecture applied to object detection in UAV aerial images
Sun, F., He, N., Li, R., Wang, X., & Xu, S. (2024) · Multimedia Systems · doi:10.1007/s00530-024-01342-8 · Cited by 28
Dodia, A., Kumar, S., Rani, R., Pippal, S. K., & Meduri, P. (2023) · IET Smart Cities · doi:10.1049/smc2.12068 · Cited by 30
Li, J., Zheng, H., Cui, Z., Huang, Z., Liang, Y., Li, P., & Liu, P. (2024) · Applied Energy · doi:10.1016/j.apenergy.2024.123983 · Cited by 23
Nandal, P., Pahal, S., Malik, S., Sehrawat, N., & Mamta, M. (2024) · International Journal of Information Technology · doi:10.1007/s41870-024-02296-w · Cited by 24
Air-to-air Micro Air Vehicle interceptor with an embedded mechanism and deep learning
Lee, Z. W., Chin, W. H., & Ho, H. W. (2023) · Aerospace Science and Technology · doi:10.1016/j.ast.2023.108192 · Cited by 26
Quantization-Aware NN Layers with High-throughput FPGA Implementation for Edge AI
Pistellato, M., Bergamasco, F., Bigaglia, G., Gasparetto, A., Albarelli, A., Boschetti, M., & Passerone, R. (2023) · Sensors · doi:10.3390/s23104667 · Cited by 28
Aljami, H. M., Alrowais, N. A., AlAwajy, A. M., Alhrgan, S. O., Aldwaani, R. A., Alsawadi, M. S., Saqib, N. U., Alam, S. S., & Alsubaie, R. (2026) · Computers · doi:10.3390/computers15020074 · Cited by 24
Edge Deployment of Deep Networks for Visual Detection: A Review
Zhai, H., Du, J., Ai, Y., & Hu, T. (2024) · IEEE Sensors Journal · doi:10.1109/jsen.2024.3502539 · Cited by 35
Wang, N., Pang, S., Ji, X., Wang, M., Qiao, S., & Yu, S. (2024) · IEEE Transactions on Network and Service Management · doi:10.1109/tnsm.2024.3409557 · Cited by 24
Real-Time Pothole Detection With Edge Intelligence and Digital Twin in Internet of Vehicles
Saleh, S., Jolfaei, A., & Tariq, M. H. (2024) · IEEE Internet of Things Journal · doi:10.1109/jiot.2024.3517342 · Cited by 27
Overload: Latency Attacks on Object Detection for Edge Devices
Chen, E., Chen, P., Chung, I., & Lee, C. (2024) · IEEE Computer Society Conference on Computer Vision and Pattern Recognition/Proceedings - IEEE Computer Society Conference on Computer Vision and Pattern Recognition/Proceedings · doi:10.1109/cvpr52733.2024.02334 · Cited by 41
GS-LinYOLOv10: A drone-based model for real-time construction site safety monitoring
Yang, S. S., Chen, Z., Yang, H., & Liao, J. (2025) · Alexandria Engineering Journal · doi:10.1016/j.aej.2025.01.021 · Cited by 22
Delving into YOLO Object Detection Models: Insights into Adversarial Robustness
Apostolidis, K. D., & Papakostas, G. A. (2025) · Electronics · doi:10.3390/electronics14081624 · Cited by 33
Ahmed, I., Ahmad, M., Siddiqi, M. U. R., Chehri, A., & Jeon, G. (2025) · IEEE Internet of Things Journal · doi:10.1109/jiot.2025.3534737 · Cited by 22
Qian, Y., Rao, L., Ma, C., Wei, K., Ding, M., & Shi, L. X. (2024) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2024.3389212 · Cited by 20
DRBD-YOLOv8: A Lightweight and Efficient Anti-UAV Detection Model
Jiang, P., Yang, X., Wan, Y., Zeng, T., Nie, M., & Liu, Z. (2024) · Sensors · doi:10.3390/s24227148 · Cited by 27
Multimodal Siamese Framework for Accurate Grade and Measure Estimation of Tropical Fruits
Sharafudeen, M., & S, V. C. S. (2023) · IEEE Transactions on Industrial Informatics · doi:10.1109/tii.2023.3316182 · Cited by 20
A Lightweight Real-Time Infrared Object Detection Model Based on YOLOv8 for Unmanned Aerial Vehicles
Ding, B., Zhang, Y., & Ma, S. (2024) · Drones · doi:10.3390/drones8090479 · Cited by 22
Human Fall Detection Based on Posture Estimation and Infrared Thermography
Fu, H., & Gao, J. (2023) · IEEE Sensors Journal · doi:10.1109/jsen.2023.3307160 · Cited by 19
Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning
Lei, Z., Zhang, Y., Wang, J., & Zhou, M. (2024) · Sensors · doi:10.3390/s24185921 · Cited by 16
Wang, Z., Yan, F., Wang, L., Yin, Y., & Lin, J. (2025) · Neural Networks · doi:10.1016/j.neunet.2025.107782 · Cited by 23
A Survey of the Yolo Series of Object Detection Algorithms
Xu, J., Li, J., Zhou, Z.-R., et al. (2024) · International Computer Conference on Wavelet Active Media Technology and Information Processing (ICCWAMTIP) · doi:10.1109/iccwamtip64812.2024.10873779 · Cited by 15
Greening Edge AI: Optimizing Inference Accuracy and Reducing Carbon Emissions With Renewable Energy
Ma, H., Huang, Z., Lu, G., Fu, D., & Shi, C. (2025) · IEEE Internet of Things Journal · doi:10.1109/jiot.2025.3554791 · Cited by 22
Attention to Task-Aligned Object Detection for End–Edge–Cloud Video Surveillance
Liu, Y. Y., Yu, Z., Zong, D., & Zhu, L. (2023) · IEEE Internet of Things Journal · doi:10.1109/jiot.2023.3340151 · Cited by 15
Kabir, R., Watanobe, Y., Ding, D., Islam, M. R., & Naruse, K. (2025) · IEEE Access · doi:10.1109/access.2025.3619776 · Cited by 24
Raza, M., Kazmi, M., Kidwai, H. M., Khan, H. R., Qazi, S. A., Arshad, K., & Assaleh, K. T. (2025) · IEEE Access · doi:10.1109/access.2025.3602844 · Cited by 33
Mustafa, A. S., Yussof, S., & Radzi, N. A. M. (2025) · IEEE Access · doi:10.1109/access.2025.3538676 · Cited by 17
DetailCaptureYOLO: Accurately Detecting Small Targets in UAV Aerial Images
Sun, F., He, N., Li, R., Liu, H., & Zou, Y. (2024) · Journal of Visual Communication and Image Representation · doi:10.1016/j.jvcir.2024.104349 · Cited by 17
Survey on Image-Based Vehicle Detection Methods
Adam, M. A. A., & Tapamo, J. (2025) · World Electric Vehicle Journal · doi:10.3390/wevj16060303 · Cited by 18
Mohankumar, C. E., & Manikandan, A. (2025) · Discover Applied Sciences · doi:10.1007/s42452-025-07383-6 · Cited by 16
Mao, G., Liang, H., Yao, Y., Wang, L., & Zhang, N. (2025) · IEEE Transactions on Automation Science and Engineering · doi:10.1109/tase.2025.3558929 · Cited by 18
A lightweight smoke detection network incorporated with the edge cue
Wang, J., Zhang, X., & Zhang, C. (2023) · Expert Systems with Applications · doi:10.1016/j.eswa.2023.122583 · Cited by 15
Nahata, D., & Othman, K. (2023) · AIMS Electronics and Electrical Engineering · doi:10.3934/electreng.2023016 · Cited by 16
Peng, R., Liao, C., Pan, W., Gou, X., Zhang, J., & Lin, Y. (2025) · Neurocomputing · doi:10.1016/j.neucom.2025.129844 · Cited by 17
Zeinaty, C. E., Hamidouche, W., Herrou, G., & Ménard, D. (2025) · ACM Computing Surveys · doi:10.1145/3744339 · Cited by 37
Benchmarking YOLOv8 to YOLOv13 for robust hand gesture recognition in human–robot interaction
Gao, Y., Luo, W. P., Zhang, S., Ahmad, N. S., Wang, X., & Goh, P. (2025) · Scientific Reports · doi:10.1038/s41598-025-23925-9 · Cited by 18
The IMU Augment SLAM on Unmanned Vehicle for Detection of Protective Measures in COVID-19
Liang, S., Zhu, W., Chakraborty, C., Du, J., & Yu, K. (2022) · IEEE Sensors Journal · doi:10.1109/jsen.2022.3189033 · Cited by 11
Self-citationZhang, X., Razavi‐Far, R., Isah, H., David, A., Higgins, G., & Zhang, M. Q. (2025) · Knowledge-Based Systems · doi:10.1016/j.knosys.2025.112965 · Cited by 22
A comprehensive review of lightweight deep learning models for edge computing with future directions
Lai, N., Dewi, D. A., Maidin, S. S., Xiao, W., Zhao, S., & Hu, Q. (2026) · Discover Computing · doi:10.1007/s10791-026-10021-3 · Cited by 33
DSP-Based Traffic Target Detection for Intelligent Transportation
Zhang, J., Wang, R., Liu, R., Guo, D., Li, B., & Chen, S. (2022) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2022.3225709 · Cited by 15
YOLO-Fast: a lightweight object detection model for edge devices
Song, Z., Zhang, X., & Tan, P. (2025) · The Journal of Supercomputing · doi:10.1007/s11227-025-07172-3 · Cited by 25
2D Convolutional Neural Networks for Alzheimer’s Disease Classification from Brain MRI
Tuba, E., Tallón‐Ballesteros, A. J., & Tuba, M. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-77738-7_47 · Cited by 11
Hu, X., Kong, D., Liu, X., Zhang, J., & Zhang, D. (2023) · Electronics · doi:10.3390/electronics12081829 · Cited by 12
Yolo Versions Architecture: Review
Hasan, R. H., Hassoon, R. M., & Aboud, I. S. (2023) · International Journal of Advances in Scientific Research and Engineering · doi:10.31695/ijasre.2023.9.11.7 · Cited by 22
Enhancing Real-time Inference Performance for Time-Critical Software-Defined Vehicles
Sumaiya, Jafarpourmarzouni, R., Lu, S., & Dong, Z. (2024) · IEEE International Conference on Mobility, Operations, Services and Technologies (MOST) · doi:10.1109/most60774.2024.00019 · Cited by 15
Navardi, M., Humes, E., Manjunath, T., & Mohsenin, T. (2023) · IEEE Micro · doi:10.1109/mm.2023.3318200 · Cited by 12
Li, G., Ouyang, D., Chen, X., Chu, W., Lu, B., Zhang, C., Tang, X., & Guo, G. (2023) · IEEE Sensors Journal · doi:10.1109/jsen.2023.3293519 · Cited by 12
Overview of deep learning YOLO algorithm
Pan, Y., Wang, G., & Yu, J. (2025) · International Conference on Computer Vision, Application, and Algorithm (CVAA) · doi:10.1117/12.3055712 · Cited by 14
Real-Time Physical Threat Detection on Edge Data Using Online Learning
Khakurel, U. B., & Rawat, D. B. (2023) · IEEE Consumer Electronics Magazine · doi:10.1109/mce.2023.3256641 · Cited by 12
RB-XAI: Relevance-Based Explainable AI for Traffic Detection in Autonomous Systems
Adom, I. T., & Mahmoud, M. N. (2024) · IEEE SoutheastCon · doi:10.1109/southeastcon52093.2024.10500215 · Cited by 9
Real-time traffic object detection algorithm with deep stochastic configuration networks
Wang, Y., Liu, Y., Yi, R., & Jiang, Y. (2025) · Information Sciences · doi:10.1016/j.ins.2024.121848 · Cited by 10
Task Offloading for CAVs Edge Computing Environment: Taxonomy, Critical Review, and Future Road Map
Kumar, B., Bhardwaj, A., & Sahu, D. P. (2025) · ACM Computing Surveys · doi:10.1145/3783984 · Cited by 13
Adaptive Attention Module for Image Recognition Systems in Autonomous Driving
Ma, X., Hu, K., Sun, X., & Chen, S. (2024) · International Journal of Intelligent Systems · doi:10.1155/2024/3934270 · Cited by 10
MFF-YOLO: An Improved YOLO Algorithm Based on Multi-Scale Semantic Feature Fusion
Zhang, J., Xu, C., Shen, S., Zhu, J., & Zhang, P. (2025) · Tsinghua Science & Technology · doi:10.26599/tst.2024.9010097 · Cited by 17
Wu, J. (2023) · Procedia Computer Science · doi:10.1016/j.procs.2023.11.117 · Cited by 8
Edge–Cloud Collaborative Real-Time Video Object Detection for Industrial Surveillance Systems
Guo, S., Zhao, C., Yang, S., Liang, Y., Wang, Y., & Han, Q. (2025) · IEEE Intelligent Systems · doi:10.1109/mis.2025.3539221 · Cited by 14
Metadata
- Authors
- Liang, S., Wu, H., Zhen, L., Hua, Q., Garg, S., Kaddoum, G., Hassan, M. M., & Yu, K.
- Affiliations
- Xi’an University of Posts and Telecommunications (CN)
- Hubei University of Arts and Science (CN)
- École de Technologie Supérieure (CA)
- King Saud University (SA)
- Waseda University (JP)
- ORCID
- Venue
- IEEE Transactions on Intelligent Transportation Systems
- Published
- 2022-12
- Volume
- 23
- Issue
- 12
- Pages
- 25345-25360
- ISSN
- 1524-9050 (ISSN-L)
- 1558-0016
- OpenAlex
- W4220827132
- Cited by
- 367
- References
- 64
- Citations by year
- 2026: 88 · 2025: 148 · 2024: 75 · 2023: 51 · 2022: 5
- FWCI
- 22.83
- Type
- journal article
- Language
- en
- Open access
- green
- arxiv.org
- Licence
- Locations
- IEEE Transactions on Intelligent Transportation Systems (publishedVersion)
- arXiv (Cornell University) (submittedVersion)
- Espace ÉTS (ETS) (submittedVersion)
- arXiv (Cornell University) (cc-by)
- Funders
- King Saud University, Riyadh, Saudi Arabia, through the Researchers Supporting Project (RSP 2022/18)
- Topics
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Advanced Neural Network Applications
- Physical Sciences › Computer Science › Computer Networks and Communications › IoT and Edge/Fog Computing
- Physical Sciences › Engineering › Automotive Engineering › Autonomous Vehicle Technology and Safety
- Keywords
- object detection, autonomous vehicles, lightweight neural networks, network pruning, feature fusion, multi-scale prediction, real-time detection, energy efficiency, NVIDIA Jetson, traffic monitoring, driving assistance
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
The claim verdicts this report counts are experimental: their accuracy is not yet measured.
A language model drew the claims from the paper on 2026-09-28, under version 3 of the claim definition (model deepseek-v4.1-flash, prompt extract-v3).
A second model labelled each claim on 2026-09-28 (model jev-1.13-20260917, definition revision gold-guideline-v0.2).
Cited sources are checked with a language model’s help (gpt-6-sol).
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
