

The DOI matches its Crossref record; 58 of the 64 references it cites were found in a registry or an index; 3 of the 4 sources its claims cite were checked for support.
Edge YOLO: Real-Time Intelligent Object Detection System Based on Edge-Cloud Cooperation in Autonomous Vehicles
Open accessAbstract
Driven by the ever-increasing requirements of autonomous vehicles, such as traffic monitoring and driving assistant, deep learning-based object detection (DL-OD) has been increasingly attractive in intelligent transportation systems. However, it is difficult for the existing DL-OD schemes to realize the responsible, cost-saving, and energy-efficient autonomous vehicle systems due to low their inherent defects of low timeliness and high energy consumption. In this paper, we propose an object detection (OD) system based on edge-cloud cooperation and reconstructive convolutional neural networks, which is called Edge YOLO. This system can effectively avoid the excessive dependence on computing power and uneven distribution of cloud computing resources. Specifically, it is a lightweight OD framework realized by combining pruning feature extraction network and compression feature fusion network to enhance the efficiency of multi-scale prediction to the largest extent. In addition, we developed an autonomous driving platform equipped with NVIDIA Jetson for system-level verification. We experimentally demonstrate the reliability and efficiency of Edge YOLO on COCO2017 and KITTI data sets, respectively. According to COCO2017 standard datasets with a speed of 26.6 frames per second (FPS), the results show that the number of parameters in the entire network is only 25.67 MB, while the accuracy (mAP) is up to 47.3%.
Overview
CoChat Summary
## TL;DR
Edge YOLO is a lightweight edge-cloud object detection system for autonomous vehicles that keeps real-time inference on Jetson edge devices while using the cloud for training and weight updates. The paper reports 47.3% mAP on COCO2017 at 26.6 FPS, with 25.27 MB model size and 8 million parameters.
## Key findings
- On COCO2017, Edge YOLO reached 47.3% mAP at 26.6 FPS with a model size of 25.27 MB; the paper also states the network has 8 million parameters and about 10.2% of the original YOLOv4 structure.
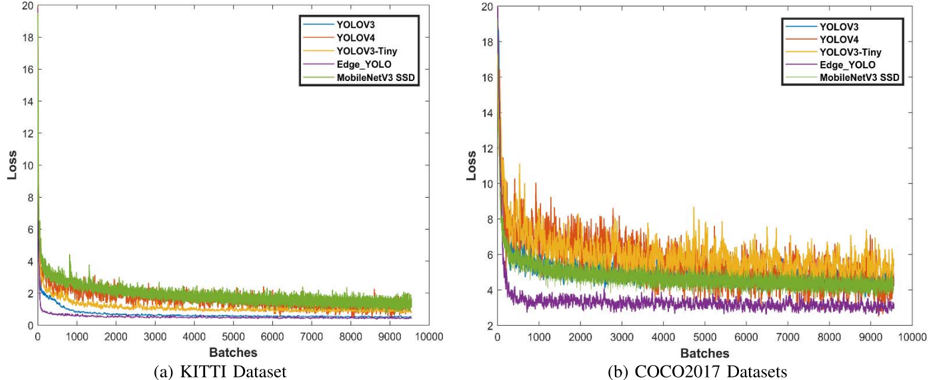
- On the KITTI 2D object dataset, Edge YOLO achieved 0.8212 mAP with 40.6 FPS on Jetson Xavier and 9.7 FPS on Jetson Nano, according to the comparison table.
- Compared with YOLOV3, YOLOV4, MobileNetV3 SSD, and YOLOV3-Tiny, Edge YOLO is presented as a balance between speed and accuracy; on COCO2017 it is reported at 26.6 FPS versus 11.8, 5.2, 11.4, and 62.7 FPS for those baselines, respectively, with the corresponding mAP values listed in Table V.
- The paper states average power consumption is 16.8 W and claims the edge-cloud cooperation scheme improves real-time performance while reducing dependence on cloud resources.
## Methods
- The system is an edge-cloud cooperation (E-CC) design: the edge device performs real-time inference, while the cloud handles data upload, labeling, retraining, and weight updates.
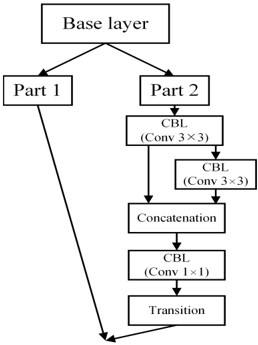
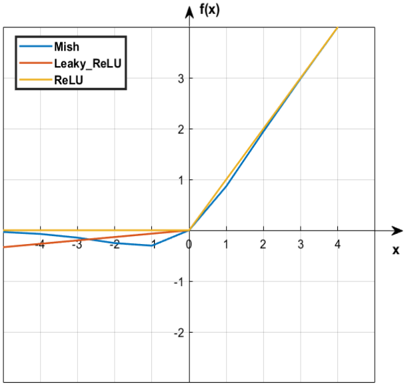
- The model is built by modifying YOLOv4: the paper says it trims the Backbone using channel pruning, simplifies the Neck by retaining SPP + FPN and removing PANet parts, and uses Leaky_ReLU plus TensorRT for acceleration.
- Experiments use COCO2017 and KITTI 2D Object Dataset, with training in Ubuntu 18.04 using PyTorch 1.6 for MobileNetV3 SSD and Darknet for YOLO-based networks; evaluation uses mAP, FPS, BFLOPS, size, and IoU = 0.5.
## Limitations
- The paper itself notes that in super multi-target detection, Edge YOLO is slightly inferior to YOLOV4 because of the limited number of network layers and parameters.
- The text makes evident that reported performance depends on specific hardware and inference settings, including Jetson Xavier/Nano, TensorRT FP16, and the stated network environment; this limits direct generalization beyond the tested setup.
- The paper states that mAP drops to a certain extent during FP16 accelerated inference on the large COCO2017 dataset.
Model-written summary. Check it against the paper before relying on it.
Integrity signals
Registry
Cites
Statistics
Figures








Verification
Claims the paper makes
3 Valid · 4 Not valid · 1 Not checked · 51 Own results and interpretations
Every source the paper cites for this claim was checked and supports it.
In the paper
“Based on the latest object detection network YOLOV4 [19] in the YOLO series, the proposed Edge YOLO is more suitable for edge computing scenarios based on 5G for traffic safety monitoring and driving assistance.”
What the sources say
- Supportedcites [19] [19] A. Bochkovskiy, C.-Y. Wang, and H.-Y. M. Liao, 'YOLOv4: Optimal speed and accuracy of object detection,' 2020, arXiv:2004.10934 . - source
The citation is attached to YOLOv4 as the network on which the citing authors base their proposed Edge YOLO. The source identifies and describes YOLOv4 in §3.4 (p. 7); the statement about Edge YOLO’s suitability for 5G edge computing is the citing authors’ own claim, not one attributed to this source. (LLM, conf=0.91)
plainstates a cause- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
- Rests on an assumption not shown here.
- Supported
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Edge YOLO | 25.27 | 0.473 | 26.6 | 11.4 | 10.250G | 0.325 | 49.5 | 26.6 |”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
The paper states this without a source or data behind it here, so there is nothing to check it against. The quote shows it is in the paper.
In the paper
“The parameter quantity is only about 10% of the original network.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: unclear — It is unclear why the paper says it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, its mAP is up to 47.3%.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“According to COCO2017 standard datasets with a speed of 26.6 frames per second (FPS), the results show that the number of parameters in the entire network is only 25.67 MB, while the accuracy (mAP) is up to 47.3%.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
15 more claims
Create a free account to see all 59 claims and every source verdict.
- It may state two separate claims as one. 29
- Probably not a substantial claim. 14
- The quote only partly states this claim. 4
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Relying solely on edge devices may not handle all complex or rare defects, affecting overall inspection results, whereas relying entirely on cloud computing may encounter bottlenecks in network latency and data transmission [6].”
From Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning (2024) · cites this paper as [6]
Experimental — accuracy not yet measuredThe cited source says what the claim attributes to it.
In the citing paper
“Relying solely on edge devices may not handle all complex or rare defects, affecting overall inspection results, whereas relying entirely on cloud computing may encounter bottlenecks in network latency and data transmission [6].”
From Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning (2024) · cites this paper as [6]
Citations
Cites
Deep Residual Learning for Image Recognition
He, K., Zhang, X., Ren, S., & Sun, J. (2016) · 2016 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2016.90 · Cited by 235,474
ImageNet classification with deep convolutional neural networks
Krizhevsky, A., Sutskever, I., & Hinton, G. E. (2017) · Communications of the ACM · doi:10.1145/3065386 · Cited by 112,155
Faster R-CNN: Towards Real-Time Object Detection with Region Proposal Networks
Ren, S., He, K., Girshick, R., & Sun, J. (2017) · IEEE Transactions on Pattern Analysis and Machine Intelligence · doi:10.1109/tpami.2016.2577031 · Cited by 73,472
Densely Connected Convolutional Networks
Huang, G., Liu, Z., van der Maaten, L., & Weinberger, K. Q. (2016) · arXiv · doi:10.48550/arxiv.1608.06993 · Cited by 48,960
Densely Connected Convolutional Networks
Huang, G., Liu, Z., Van Der Maaten, L., & Weinberger, K. Q. (2017) · 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2017.243 · Cited by 48,566
Microsoft COCO: Common Objects in Context
Lin, T.-Y., Maire, M., Belongie, S., Hays, J., Perona, P., Ramanan, D., Dollár, P., & Zitnick, C. L. (2014) · Lecture Notes in Computer Science · doi:10.1007/978-3-319-10602-1_48 · Cited by 45,460
Rich Feature Hierarchies for Accurate Object Detection and Semantic Segmentation
Girshick, R., Donahue, J., Darrell, T., & Malik, J. (2014) · 2014 IEEE Conference on Computer Vision and Pattern Recognition · doi:10.1109/cvpr.2014.81 · Cited by 32,684
(2016) · Cited by 31,590
Feature Pyramid Networks for Object Detection
Lin, T.-Y., Dollar, P., Girshick, R., He, K., Hariharan, B., & Belongie, S. (2017) · 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2017.106 · Cited by 30,939
Girshick, R. (2015) · 2015 IEEE International Conference on Computer Vision (ICCV) · doi:10.1109/iccv.2015.169 · Cited by 28,105
Cited by
Items 101–200 of 360
Object Detectors in Autonomous Vehicles: Analysis of Deep Learning Techniques
Du, L. (2023) · International Journal of Advanced Computer Science and Applications · doi:10.14569/ijacsa.2023.0141024 · Cited by 9
Xavier Vision: Pioneering Autonomous Vehicle Perception with YOLO v8 on Jetson Xavier NX
Wasule, S., Khadatkar, G., Pendke, V., & Rane, P. (2023) · IEEE Pune Section International Conference (PuneCon) · doi:10.1109/punecon58714.2023.10450077 · Cited by 8
Gated image-adaptive network for driving-scene object detection under nighttime conditions
Wang, Y., Lu, Y., & Qiu, Y. (2024) · Multimedia Systems · doi:10.1007/s00530-024-01589-1 · Cited by 10
Rethinking the mobile edge for vehicular services
Parastar, P., Caso, G., Iglesias, J. O., Lutu, A., & Alay, Ö. (2024) · Computer Networks · doi:10.1016/j.comnet.2024.110687 · Cited by 7
Dhatrika, S. K., Reddy, D. R., & Reddy, N. K. (2025) · Procedia Computer Science · doi:10.1016/j.procs.2024.12.004 · Cited by 7
Yahya, M., Reddy, R. A., Al-Attabi, K., Mohammed, I. H., & Arunasree, B. (2023) · International Conference on Integrated Intelligence and Communication Systems (ICIICS) · doi:10.1109/iciics59993.2023.10421358 · Cited by 8
YOLOv7-PE: A Precise and Efficient Enhancement of YOLOv7 for Underwater Target Detection
Li, Z., Xie, H., Feng, J., et al. (2024) · IEEE Access · doi:10.1109/access.2024.3417322 · Cited by 8
RSWD-YOLO: A Walnut Detection Method Based on UAV Remote Sensing Images
Wang, Y., Yang, X., Wang, H., et al. (2025) · Horticulturae · doi:10.3390/horticulturae11040419 · Cited by 7
Optimal path planning based on ACO in intelligent transportation
Zhu, W., Cai, W., & Kong, H. (2025) · International Journal of Cognitive Computing in Engineering · doi:10.1016/j.ijcce.2025.02.006 · Cited by 8
Transport Object Detection in Street View Imagery Using Decomposed Convolutional Neural Networks
Bai, Y., Shang, C., Li, Y., Shen, L., Jin, S., & Shen, Q. (2023) · Mathematics · doi:10.3390/math11183839 · Cited by 9
Application of YOLO Algorithm for Intelligent Transportation Systems: A Survey and New Perspectives
Lv, X., Chen, T., Song, C., Yang, C., & Ping, T. (2025) · International Journal of Distributed Sensor Networks · doi:10.1155/dsn/2859040 · Cited by 15
Namana, M. S. K., & Kumar, B. U. (2025) · Engineering Technology & Applied Science Research · doi:10.48084/etasr.9926 · Cited by 9
Genghuan, 刘. L., Xiangjin, 曾. Z., Dou, J., Zhenbo, 任. R., Liyun, 钟. Z., Jianglei, 邸. D., & Yuwen, 秦. Q. (2024) · Infrared and Laser Engineering · doi:10.3788/irla20240253 · Cited by 8
Chen, X., Xie, F., Li, Q., Zhu, F., Feng, A., & Witold Pedrycz, C. (2026) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2025.3649539 · Cited by 10
DD-YOLO: A dual-channel dual-path YOLO network for target detection of blurred vehicles
Duan, C., Guo, Y., Duan, X., Li, G., & Sheng, B. (2025) · Digital Signal Processing · doi:10.1016/j.dsp.2025.105565 · Cited by 9
An Effective YOLO-Based Proactive Blind Spot Warning System for Motorcycles
Chang, I.-C., Yen, C.-E., Song, Y.-J., Chen, W., Kuo, X.-M., Liao, P.-H., Kuo, C., & Huang, Y. (2023) · Electronics · doi:10.3390/electronics12153310 · Cited by 8
Toward Real-Time and Efficient Perception Workflows in Software-Defined Vehicles
Sumaiya, Jafarpourmarzouni, R., Luo, Y., Lu, S., & Dong, Z. (2024) · IEEE Internet of Things Journal · doi:10.1109/jiot.2024.3492801 · Cited by 6
Enhancing Real-Time Human Tracking using YOLONAS-DeepSort Fusion Models
Athilakshmi, R., Sainagakrishna, P. S. C., Kota, S. S. C. C., Teja, M. C. K., Venkatesh, T., & Prasad, V. J. (2023) · International Conference on Electronics, Communication and Aerospace Technology (ICECA) · doi:10.1109/iceca58529.2023.10394864 · Cited by 10
ADMNet: Anti-Drone Real-Time Detection and Monitoring
Zhou, X., Yang, G., Chen, Y., Gao, C., Zhao, B., Li, L., & Chen, B. M. (2023) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros55552.2023.10341901 · Cited by 9
LWU-YOLO: A lightweight algorithm for small object detection in UAV applications
Li, Y., Li, Y., Wang, T., et al. (2026) · Journal of Visual Communication and Image Representation · doi:10.1016/j.jvcir.2026.104791 · Cited by 6
Artificial intelligence-based model for efficient object detection in autonomous vehicles
Zhang, Z., Zhang, Q., Liu, H., Gao, Y., & Wang, L. (2025) · Journal of Intelligent Transportation Systems · doi:10.1080/15472450.2025.2499591 · Cited by 5
Li, D., Zhang, H., Cheng, J., & Liu, B. (2024) · Journal of Cloud Computing Advances Systems and Applications · doi:10.1186/s13677-024-00592-1 · Cited by 5
Hybrid Cross-Feature Interaction Attention Module for Object Detection in Intelligent Mobile Scenes
Tian, D., Han, Y., Liu, Y., Li, J., Zhang, P., & Liu, M. (2023) · Remote Sensing · doi:10.3390/rs15204991 · Cited by 5
Zone-YOLO: Vision-Language Object Detection Using Zone Prompt
Yang, J., Jia, N., Liu, X., Fan, R., Sun, Y., & Zhao, W. (2024) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2024.3510117 · Cited by 11
YoloGA: An Evolutionary Computation Based YOLO Algorithm to Detect Personal Protective Equipment
Majumder, A., & Chatterjee, S. (2025) · Journal of Intelligent & Fuzzy Systems · doi:10.1177/18758967251338695 · Cited by 10
Deep Learning on RISC-V Platforms at the Edge: A Perspective on the Hardware and Software Support
Agosta, G., Galimberti, A., & Zoni, D. (2025) · ACM Computing Surveys · doi:10.1145/3772277 · Cited by 10
Small object detection in remote sensing images through multi-scale feature fusion
Li, S., Lin, J., Gang, Y., & Pan, X. (2025) · The Computer Journal · doi:10.1093/comjnl/bxaf040 · Cited by 8
Scale-Disentangled and Uncertainty-Guided Alignment for Domain-Adaptive Object Detection
Zhang, H., Luo, G., Cao, Y., Wang, X., Li, Y., & Wang, F. (2024) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2024.3447052 · Cited by 5
YOLOX-LS: Strong Gravitational Lenses Detection in the DECaLS with Deep Learning
Liu, Y. T., Tu, L., Li, J., Miao, J., Lin, G., & Zhao, C. (2025) · The Astrophysical Journal · doi:10.3847/1538-4357/ad97ba · Cited by 6
Li, Z., & Fan, H. (2025) · Electronics · doi:10.3390/electronics14051014 · Cited by 7
Xu, Z., Han, J., Qin, H., Gao, K., Xie, K., & He, J. (2025) · Scientific Reports · doi:10.1038/s41598-025-28116-0 · Cited by 5
The evolution of object detection from CNNs to transformers and multi-modal fusion
Wang, Z., Chen, Y. Y., Gu, Y., Liu, J., Zhu, X., & He, M. (2026) · Scientific Reports · doi:10.1038/s41598-026-37052-6 · Cited by 19
Satellite–Terrestrial Collaborative Object Detection via Task-Inspired Framework
Lu, A., Cheng, Y., Hu, Y., Cao, Z., Chen, Y., & Li, Z. (2023) · IEEE Internet of Things Journal · doi:10.1109/jiot.2023.3287973 · Cited by 7
Exploring GPU sharing techniques for edge AI smart city applications
Woo, S., Yeo, J., Kim, J.-H., & Lee, K. (2025) · ETRI Journal · doi:10.4218/etrij.2025-0065 · Cited by 5
Enhancing YOLOv5 for Autonomous Driving: Efficient Attention-Based Object Detection on Edge Devices
Adam, M. A. A., & Tapamo, J. (2025) · Journal of Imaging · doi:10.3390/jimaging11080263 · Cited by 11
DA-YOLO: a dynamic adaptive network for SAR ship detection
Yan, C., & Peng, X. (2025) · Earth Science Informatics · doi:10.1007/s12145-025-02044-z · Cited by 5
Metareasoning for Edge-Cloud Collaborative LLM Planning for Efficient Autonomous Navigation
Navardi, M., Gao, S., Walczak, M., Camacho, F., & Mohsenin, T. (2025) · ACM Transactions on Embedded Computing Systems · doi:10.1145/3765750 · Cited by 7
Differential Image-Based Scalable YOLOv7-Tiny Implementation for Clustered Embedded Systems
Hong, S., & Park, D. (2024) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2024.3419095 · Cited by 4
Chu, S., & Bao, W. (2025) · Discover Computing · doi:10.1007/s10791-025-09612-3 · Cited by 7
A Novel Foreign Object Detection Method in Transmission Lines Based on Improved YOLOv8n
Liu, Y., Jiang, X., Xu, R., et al. (2024) · Computers, materials & continua/Computers, materials & continua (Print) · doi:10.32604/cmc.2024.048864 · Cited by 4
Saiveena, K., & Praveen, P. (2026) · Computers & Electrical Engineering · doi:10.1016/j.compeleceng.2026.111086 · Cited by 5
Lei, Y., Chen, S., Wan-cheng, G., et al. (2025) · IEEE Access · doi:10.1109/access.2025.3549298 · Cited by 3
Object Detection in Traffic Videos: A Survey
(2022) · doi:10.36227/techrxiv.20477685.v1 · Cited by 3
Lightweight target detection algorithm based on partial convolution
Chen, B., & Liu, Z. (2024) · Journal of Electronic Imaging · doi:10.1117/1.jei.33.2.023049 · Cited by 3
Performance analysis of microVMs and containers for edge computing: A focus on file and network I/O
Lee, K., Choi, Y., & Tak, B. (2025) · Future Generation Computer Systems · doi:10.1016/j.future.2025.108176 · Cited by 5
MDCFVit-YOLO: A model for nighttime infrared small target vehicle and pedestrian detection
Zhang, H., Zhang, Q., Gong, Y., Yao, F., & Pan, X. (2025) · PLoS ONE · doi:10.1371/journal.pone.0324700 · Cited by 4
Wang, Y. (2023) · Advanced Control for Applications · doi:10.1002/adc2.164 · Cited by 3
YOLO-SOD: Improved YOLO Small Object Detection
Xu, Y., Lu, J., & Wang, C. (2024) · Lecture notes in computer science · doi:10.1007/978-981-96-0125-7_14 · Cited by 3
TIE-LR: A multi-module deep learning framework for traffic monitoring on low-resolution videos
Liu, D., Gu, Y., Zhang, H., Khojastehpour, M., & Han, L. D. (2025) · Engineering Applications of Artificial Intelligence · doi:10.1016/j.engappai.2025.113112 · Cited by 3
Feature Compression for Cloud-Edge Multimodal 3D Object Detection
Tian, C., Li, Z., Yuan, H., Hamzaoui, R., Shen, L., & Kwong, S. (2026) · IEEE Transactions on Pattern Analysis and Machine Intelligence · doi:10.1109/tpami.2026.3669471 · Cited by 8
Wang, K., He, G., & Li, X. (2025) · Sensors · doi:10.3390/s25123800 · Cited by 5
LLM-Driven Offloading Decisions for Edge Object Detection in Smart City Deployments
Yuan, X., & Li, H. (2025) · Smart Cities · doi:10.3390/smartcities8050169 · Cited by 5
Urban Road Autonomous Driving Vehicle Target Detection Algorithm Based on Improved YOLOv8
Gu, Y., Zheng, Y., Ding, T., Song, X., & Zhang, X. (2024) · International Conference on Intelligent Computing and Signal Processing (ICSP) · doi:10.1109/icsp62122.2024.10743822 · Cited by 3
On Efficient Object-Detection NAS for ADAS on Edge devices
Gupta, D., Lee, R. D., & Wynter, L. (2024) · IEEE Conference on Artificial Intelligence (CAI) · doi:10.1109/cai59869.2024.00183 · Cited by 5
Wu, J., Zhang, S., Chen, S., Wang, L., Wang, Z., Chen, W., He, F., Tian, Z., Yu, F. R., & Leung, V. C. M. (2025) · IEEE Transactions on Mobile Computing · doi:10.1109/tmc.2025.3612469 · Cited by 7
Twin-AI: Intelligent Barrier Eddy Current Separator with Digital Twin and AI Integration
Kia, S., Mayer, J. B., Westphal, E., et al. (2025) · Sensors · doi:10.3390/s25154731 · Cited by 3
Doe, D. M., Chen, D., Han, K., Xie, J. L., & Han, Z. (2024) · IEEE Intelligent Vehicles Symposium · doi:10.1109/iv55156.2024.10588561 · Cited by 3
RGB-FIR Multimodal Pedestrian Detection with Cross-Modality Context Attentional Model
Wang, H., Jin, L., Wang, G., Liu, W., Shi, Q., Hou, Y., & Liu, J. (2025) · Sensors · doi:10.3390/s25133854 · Cited by 7
Cyber Security for Intelligent Transportation Systems Protecting Critical Infrastructure
Maranco, M., Murugaiyan, S., Krishnaraj, N., Savaridassan, P., AbhiramIvaturi, K., & Logeshwari, R. (2025) · IGI Global eBooks · doi:10.4018/979-8-3693-7984-4.ch022 · Cited by 4
Improving Real-Time Data Streams Performance on Autonomous Surface Vehicles using DataX
Mellone, G., Vita, C. G. D., Coviello, G., Aucelli, P. P. C., Ciaramella, A., & Montella, R. (2024) · Euromicro International Conference on Parallel, Distributed and Network-Based Processing (PDP) · doi:10.1109/pdp62718.2024.00038 · Cited by 3
Liu, Z., Kwan, M., Jiang, W., Liu, Y., & Cui, B. (2026) · IEEE Transactions on Geoscience and Remote Sensing · doi:10.1109/tgrs.2026.3713370 · Cited by 12
SRDrone: LLM-Driven Self-Refinement for Embodied Drone Task Planning
Zhang, D., Zhang, X., Zhang, J., Li, J., Long, T., Dai, X., Fu, Y., Ren, J., & Zhang, Y. (2026) · IEEE Transactions on Mobile Computing · doi:10.1109/tmc.2026.3664806 · Cited by 6
Interactive Transformer for Small Object Detection
Wei, J. W., Wang, Q., & Zhao, Z. (2023) · Computers, materials & continua/Computers, materials & continua (Print) · doi:10.32604/cmc.2023.044284 · Cited by 3
Prospective study on challenges faced in a perception system
Rolen, L. R., Bhat, S. J., & Santhosh, K. V. (2024) · Cogent Engineering · doi:10.1080/23311916.2024.2353498 · Cited by 5
Online Multiple Object Tracking Using Min-Cost Flow on Temporal Window for Autonomous Driving
Wei, H., Huang, Y., Zhang, Q., & Guo, Z. (2023) · World Electric Vehicle Journal · doi:10.3390/wevj14090243 · Cited by 2
Zhang, K. (2025) · Journal of Computational Methods in Sciences and Engineering · doi:10.1177/14727978251346034 · Cited by 2
Traffic Scene Object Detection Based on YOLO Algorithm
(2024) · doi:10.1145/3687488.3687543 · Cited by 2
Enhancing YOLOv5 for Autonomous Driving: Efficient Attention-Based Object Detection on Edge DevicesPreprint
Adam, M. A. A., & Tapamo, J. (2025) · Preprints.org · doi:10.20944/preprints202506.2076.v1 · Cited by 2
Feng, Z. Y., Wu, Q., Zhao, K., Lv, Z., Guo, D., & Chen, X. (2025) · IEEE Transactions on Network Science and Engineering · doi:10.1109/tnse.2025.3631382 · Cited by 3
Collision Avoidance System using YOLO-based Object Detection and Distance Estimation
Raj, S. A. D., Singh, A., Shekhawat, T. S., Manav Muthanna, M., & Sivasankaran, K. (2025) · International Conference on Intelligent Data Communication Technologies and Internet of Things (IDCIoT) · doi:10.1109/idciot64235.2025.10915167 · Cited by 3
Byenkya, N. L., Rose, N., & Nixson, O. (2026) · Discover Artificial Intelligence · doi:10.1007/s44163-025-00828-2 · Cited by 2
Xie, Y., Shi, Y., Xie, C., Hu, Q. X., Liu, Y., & Lin, C. (2025) · Neurocomputing · doi:10.1016/j.neucom.2025.131501 · Cited by 2
Edge Computing-Based Vehicle Detection in Intelligent Transportation Systems
Pan, H., Guan, S., Zhao, X., & Xue, Y. (2023) · Computing and Informatics · doi:10.31577/cai_2023_6_1339 · Cited by 2
Wang, J., Bai, Z., Zhang, X., Qiu, Y., Bu, F., & Shao, Y. (2025) · Remote Sensing · doi:10.3390/rs17132195 · Cited by 2
SD-YOLOv5: Implementation of Real-Time Staircase Detection on Jetson Nano Board
Fataniya, B. D., Mecwan, A., Shah, D., Chauhan, M. M., & Dave, J. M. (2025) · SN Computer Science · doi:10.1007/s42979-025-03890-w · Cited by 2
Chen, Y. F., Liu, Y., & Wang, Z. (2023) · IEEE Joint International Information Technology and Artificial Intelligence Conference (ITAIC) · doi:10.1109/itaic58329.2023.10408937 · Cited by 2
Wang, N., Pang, S., Ji, X. B., Wang, M., He, X., Gui, H., & Lu, X. (2025) · IEEE Internet of Things Journal · doi:10.1109/jiot.2025.3555275 · Cited by 2
Wang, Q., Ye, G., Li, F., Chen, Q., Jiang, J., Zhang, S., & Ullah, F. (2026) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2026.3665257 · Cited by 2
Sensor-free, Camera-only: Low-cost multi-angle CPR skill assessments method based on computer vision
Liu, L., Wu, C., Liu, J., Yu, J. J., Bi, M., & Yu, H. Z. (2025) · Journal of King Saud University - Computer and Information Sciences · doi:10.1007/s44443-025-00223-y · Cited by 5
Yang, H., Zhang, Z., Chen, Z., Ge, S., & Yu, X. (2026) · Image and Vision Computing · doi:10.1016/j.imavis.2026.105958 · Cited by 2
Transformer-based aerial robot tracking system in environments with wind disturbances
Wang, P., Kim, J., Ghergherehchi, M., Zhang, M., Montero, E., Liao, L., Yang, Z., & Xu, H. (2025) · Robotics and Autonomous Systems · doi:10.1016/j.robot.2025.105104 · Cited by 4
Xu, X., Wang, Z., Chen, W., Tang, W., Ren, N., & Zhu, C. (2025) · Remote Sensing · doi:10.3390/rs17142379 · Cited by 3
Song, C., Ding, S., & Chen, Y. J. (2023) · Asia-Pacific Conference on Image Processing, Electronics and Computers (IPEC) · doi:10.1109/ipec57296.2023.00018 · Cited by 2
Optimization techniques for real-time optical image processing using edge computing
Yuan, H., Niu, Z., & Liu, J. (2025) · International Conference on Big Data, Computational Intelligence, and Applications (BDCIA) · doi:10.1117/12.3059702 · Cited by 2
Autonomous Driving Road Environment Recognition with Multiscale Object Detection
Jeny, J. R. V., Divya, P., Varsha, K., Mrunalini, A., & Irfan, S. K. M. (2025) · E3S Web of Conferences · doi:10.1051/e3sconf/202561903017 · Cited by 3
Latency and Bandwidth Benefits of Edge Computing for Scientific Applications
Rouf, A., Arslan, E., & Charyyev, B. (2024) · IEEE Conference on Computer Communications Workshops (INFOCOM WKSHPS) · doi:10.1109/infocomwkshps61880.2024.10620811 · Cited by 4
Design and Simulation of a Four‐Legged Mobile Robot for Autonomous Navigation on a Spacecraft Hull
Hassan, M., Dremann, K., Orosa, A., Metzger, E., Doty, N., Patek, J., Farhad, S., & Mahajan, A. (2025) · Journal of Robotics · doi:10.1155/joro/2542899 · Cited by 4
Self-citationA Lightweight Cross-Layer Smoke-Aware Network
Wang, J., Zhang, X., & Zhang, C. (2024) · Sensors · doi:10.3390/s24134374 · Cited by 2
Detection of Vehicle Density Based on YoloV7 with Images from Cusco, Peru
Mamani-Coaquira, Y., Palacios, S., Guzmán-Monteza, Y., et al. (2023) · International Conference on Electrical, Computer, Communications and Mechatronics Engineering (ICECCME) · doi:10.1109/iceccme57830.2023.10253099 · Cited by 1
Ride Recall: An Aftermarket Item-Reminder System for Shared & Rented Cars
Müller, H. M., Valsangkar, N. S., Rashid, W., Bhanderi, S., Berghegger, L. P., Kolhe, R. R., Malik, M., Sukani, M., Volkan, B., & Riener, A. (2025) · International Conference on Automotive User Interfaces and Interactive Vehicular Applications (AutomotiveUI) · doi:10.1145/3744335.3756858
Mobile AI-Powered Impurity Removal System for Decentralized Potato Harvesting
Kim, J., TOKUDA, K., Miho, Y., Kim, G., Yoshitoshi, R., Tsuchiya, S., Deguchi, N., & FUNABIKI, K. (2026) · Agronomy · doi:10.3390/agronomy16030383 · Cited by 1
Metadata
- Authors
- Liang, S., Wu, H., Zhen, L., Hua, Q., Garg, S., Kaddoum, G., Hassan, M. M., & Yu, K.
- Affiliations
- Xi’an University of Posts and Telecommunications (CN)
- Hubei University of Arts and Science (CN)
- École de Technologie Supérieure (CA)
- King Saud University (SA)
- Waseda University (JP)
- ORCID
- Venue
- IEEE Transactions on Intelligent Transportation Systems
- Published
- 2022-12
- Volume
- 23
- Issue
- 12
- Pages
- 25345-25360
- ISSN
- 1524-9050 (ISSN-L)
- 1558-0016
- OpenAlex
- W4220827132
- Cited by
- 367
- References
- 64
- Citations by year
- 2026: 88 · 2025: 148 · 2024: 75 · 2023: 51 · 2022: 5
- FWCI
- 22.83
- Type
- journal article
- Language
- en
- Open access
- green
- arxiv.org
- Licence
- Locations
- IEEE Transactions on Intelligent Transportation Systems (publishedVersion)
- arXiv (Cornell University) (submittedVersion)
- Espace ÉTS (ETS) (submittedVersion)
- arXiv (Cornell University) (cc-by)
- Funders
- King Saud University, Riyadh, Saudi Arabia, through the Researchers Supporting Project (RSP 2022/18)
- Topics
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Advanced Neural Network Applications
- Physical Sciences › Computer Science › Computer Networks and Communications › IoT and Edge/Fog Computing
- Physical Sciences › Engineering › Automotive Engineering › Autonomous Vehicle Technology and Safety
- Keywords
- object detection, autonomous vehicles, lightweight neural networks, network pruning, feature fusion, multi-scale prediction, real-time detection, energy efficiency, NVIDIA Jetson, traffic monitoring, driving assistance
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
The claim verdicts this report counts are experimental: their accuracy is not yet measured.
A language model drew the claims from the paper on 2026-09-28, under version 3 of the claim definition (model deepseek-v4.1-flash, prompt extract-v3).
A second model labelled each claim on 2026-09-28 (model jev-1.13-20260917, definition revision gold-guideline-v0.2).
Cited sources are checked with a language model’s help (gpt-6-sol).
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
