

Edge YOLO: Real-Time Intelligent Object Detection System Based on Edge-Cloud Cooperation in Autonomous Vehicles
Open accessThe DOI matches its Crossref record; 58 of the 64 references it cites were found in a registry or an index; 3 of the 4 sources its claims cite were checked for support.
Abstract
Driven by the ever-increasing requirements of autonomous vehicles, such as traffic monitoring and driving assistant, deep learning-based object detection (DL-OD) has been increasingly attractive in intelligent transportation systems. However, it is difficult for the existing DL-OD schemes to realize the responsible, cost-saving, and energy-efficient autonomous vehicle systems due to low their inherent defects of low timeliness and high energy consumption. In this paper, we propose an object detection (OD) system based on edge-cloud cooperation and reconstructive convolutional neural networks, which is called Edge YOLO. This system can effectively avoid the excessive dependence on computing power and uneven distribution of cloud computing resources. Specifically, it is a lightweight OD framework realized by combining pruning feature extraction network and compression feature fusion network to enhance the efficiency of multi-scale prediction to the largest extent. In addition, we developed an autonomous driving platform equipped with NVIDIA Jetson for system-level verification. We experimentally demonstrate the reliability and efficiency of Edge YOLO on COCO2017 and KITTI data sets, respectively. According to COCO2017 standard datasets with a speed of 26.6 frames per second (FPS), the results show that the number of parameters in the entire network is only 25.67 MB, while the accuracy (mAP) is up to 47.3%.
Overview
CoChat Summary
## TL;DR
Edge YOLO is a lightweight edge-cloud object detection system for autonomous vehicles that keeps real-time inference on Jetson edge devices while using the cloud for training and weight updates. The paper reports 47.3% mAP on COCO2017 at 26.6 FPS, with 25.27 MB model size and 8 million parameters.
## Key findings
- On COCO2017, Edge YOLO reached 47.3% mAP at 26.6 FPS with a model size of 25.27 MB; the paper also states the network has 8 million parameters and about 10.2% of the original YOLOv4 structure.
- On the KITTI 2D object dataset, Edge YOLO achieved 0.8212 mAP with 40.6 FPS on Jetson Xavier and 9.7 FPS on Jetson Nano, according to the comparison table.
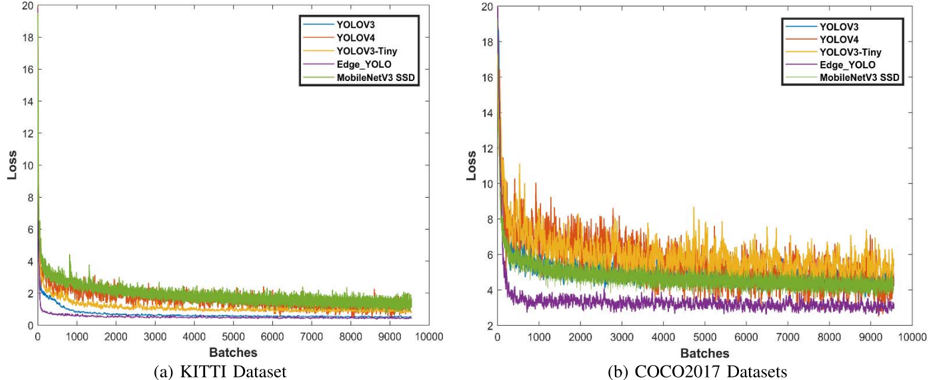
- Compared with YOLOV3, YOLOV4, MobileNetV3 SSD, and YOLOV3-Tiny, Edge YOLO is presented as a balance between speed and accuracy; on COCO2017 it is reported at 26.6 FPS versus 11.8, 5.2, 11.4, and 62.7 FPS for those baselines, respectively, with the corresponding mAP values listed in Table V.
- The paper states average power consumption is 16.8 W and claims the edge-cloud cooperation scheme improves real-time performance while reducing dependence on cloud resources.
## Methods
- The system is an edge-cloud cooperation (E-CC) design: the edge device performs real-time inference, while the cloud handles data upload, labeling, retraining, and weight updates.
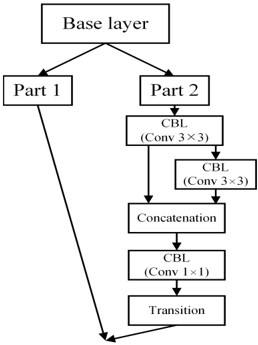
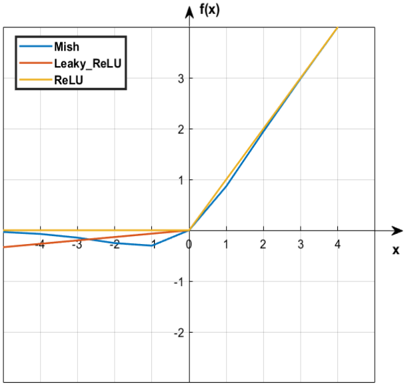
- The model is built by modifying YOLOv4: the paper says it trims the Backbone using channel pruning, simplifies the Neck by retaining SPP + FPN and removing PANet parts, and uses Leaky_ReLU plus TensorRT for acceleration.
- Experiments use COCO2017 and KITTI 2D Object Dataset, with training in Ubuntu 18.04 using PyTorch 1.6 for MobileNetV3 SSD and Darknet for YOLO-based networks; evaluation uses mAP, FPS, BFLOPS, size, and IoU = 0.5.
## Limitations
- The paper itself notes that in super multi-target detection, Edge YOLO is slightly inferior to YOLOV4 because of the limited number of network layers and parameters.
- The text makes evident that reported performance depends on specific hardware and inference settings, including Jetson Xavier/Nano, TensorRT FP16, and the stated network environment; this limits direct generalization beyond the tested setup.
- The paper states that mAP drops to a certain extent during FP16 accelerated inference on the large COCO2017 dataset.
Model-written summary. Check it against the paper before relying on it.
Integrity signals
Registry
Cites
Statistics
Figures




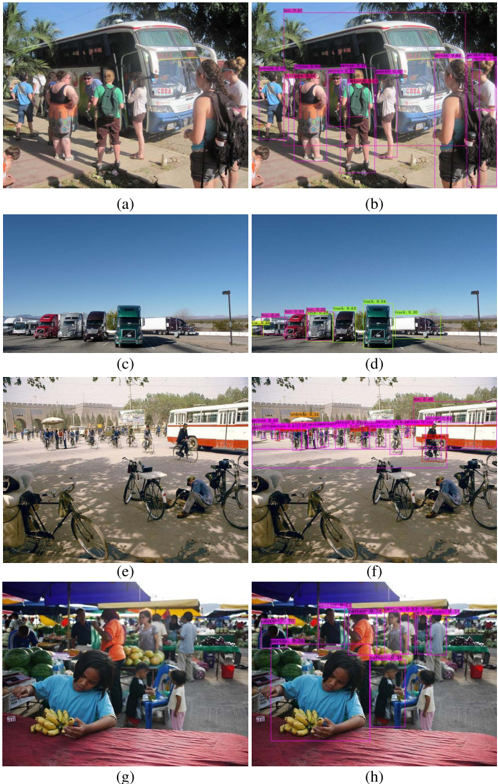




Verification
Claims the paper makes
3 Valid · 4 Not valid · 1 Not checked · 51 Own results and interpretations
Every source the paper cites for this claim was checked and supports it.
In the paper
“Based on the latest object detection network YOLOV4 [19] in the YOLO series, the proposed Edge YOLO is more suitable for edge computing scenarios based on 5G for traffic safety monitoring and driving assistance.”
What the sources say
- Supportedcites [19] [19] A. Bochkovskiy, C.-Y. Wang, and H.-Y. M. Liao, 'YOLOv4: Optimal speed and accuracy of object detection,' 2020, arXiv:2004.10934 . - source
The citation is attached to YOLOv4 as the network on which the citing authors base their proposed Edge YOLO. The source identifies and describes YOLOv4 in §3.4 (p. 7); the statement about Edge YOLO’s suitability for 5G edge computing is the citing authors’ own claim, not one attributed to this source. (LLM, conf=0.91)
plainstates a cause- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
- Rests on an assumption not shown here.
- Supported
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Edge YOLO | 25.27 | 0.473 | 26.6 | 11.4 | 10.250G | 0.325 | 49.5 | 26.6 |”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
The paper states this without a source or data behind it here, so there is nothing to check it against. The quote shows it is in the paper.
In the paper
“The parameter quantity is only about 10% of the original network.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: unclear — It is unclear why the paper says it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, its mAP is up to 47.3%.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“According to COCO2017 standard datasets with a speed of 26.6 frames per second (FPS), the results show that the number of parameters in the entire network is only 25.67 MB, while the accuracy (mAP) is up to 47.3%.”
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
15 more claims
Create a free account to see all 59 claims and every source verdict.
- It may state two separate claims as one. 29
- Probably not a substantial claim. 14
- The quote only partly states this claim. 4
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Relying solely on edge devices may not handle all complex or rare defects, affecting overall inspection results, whereas relying entirely on cloud computing may encounter bottlenecks in network latency and data transmission [6].”
From Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning (2024) · cites this paper as [6]
Experimental — accuracy not yet measuredThe cited source says what the claim attributes to it.
In the citing paper
“Relying solely on edge devices may not handle all complex or rare defects, affecting overall inspection results, whereas relying entirely on cloud computing may encounter bottlenecks in network latency and data transmission [6].”
From Cloud-Edge Collaborative Defect Detection Based on Efficient Yolo Networks and Incremental Learning (2024) · cites this paper as [6]
Citations
Cites
Deep Residual Learning for Image Recognition
He, K., Zhang, X., Ren, S., & Sun, J. (2016) · 2016 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2016.90 · Cited by 235,474
ImageNet classification with deep convolutional neural networks
Krizhevsky, A., Sutskever, I., & Hinton, G. E. (2017) · Communications of the ACM · doi:10.1145/3065386 · Cited by 112,155
Faster R-CNN: Towards Real-Time Object Detection with Region Proposal Networks
Ren, S., He, K., Girshick, R., & Sun, J. (2017) · IEEE Transactions on Pattern Analysis and Machine Intelligence · doi:10.1109/tpami.2016.2577031 · Cited by 73,472
Densely Connected Convolutional Networks
Huang, G., Liu, Z., van der Maaten, L., & Weinberger, K. Q. (2016) · arXiv · doi:10.48550/arxiv.1608.06993 · Cited by 48,960
Densely Connected Convolutional Networks
Huang, G., Liu, Z., Van Der Maaten, L., & Weinberger, K. Q. (2017) · 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2017.243 · Cited by 48,566
Microsoft COCO: Common Objects in Context
Lin, T.-Y., Maire, M., Belongie, S., Hays, J., Perona, P., Ramanan, D., Dollár, P., & Zitnick, C. L. (2014) · Lecture Notes in Computer Science · doi:10.1007/978-3-319-10602-1_48 · Cited by 45,460
Rich Feature Hierarchies for Accurate Object Detection and Semantic Segmentation
Girshick, R., Donahue, J., Darrell, T., & Malik, J. (2014) · 2014 IEEE Conference on Computer Vision and Pattern Recognition · doi:10.1109/cvpr.2014.81 · Cited by 32,684
(2016) · Cited by 31,590
Feature Pyramid Networks for Object Detection
Lin, T.-Y., Dollar, P., Girshick, R., He, K., Hariharan, B., & Belongie, S. (2017) · 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR) · doi:10.1109/cvpr.2017.106 · Cited by 30,939
Girshick, R. (2015) · 2015 IEEE International Conference on Computer Vision (ICCV) · doi:10.1109/iccv.2015.169 · Cited by 28,105
Research works printed but not linked: 2
- [35] A. Howard et al. , 'Searching for MobileNetV3,' in Proc. IEEE/CVF Int. Conf. Comput. Vis. (ICCV) , Oct. 2019, pp. 1314-1324. -
- [27] R. Girshick, 'Fast R-CNN,' in Proc. IEEE Int. Conf. Comput. Vis. (ICCV) , Dec. 2015, pp. 1440-1448. -
Cited by
Items 301–360 of 360
A Comprehensive Assessment of Optimized YOLO Architectures for Edge and Real-Time Applications
Pessoa, L. D. S., Valadão, M. D. M., Pantoja, M. S., Cavalcante, V. R. M., Corrêa, A. J. P., Melo, D. S., de Mattos, E. U., Bessa, A. R. R., Cabral, I. A., Amoedo, D., et al. (2026) · IEEE International Conference on Consumer Technology (ICCT-Pacific) · doi:10.1109/icct-pacific69083.2026.11518725
Secuyolo: Secure Object Detection Framework With Darknet‐53 and CBAM in Edge Devices
Lakshmiramana, P., & Vadivel, A. (2025) · Concurrency and Computation Practice and Experience · doi:10.1002/cpe.70118 · Cited by 2
Automatic defect detection in radiographic images of casting components: a comprehensive review
Kumar, S., & Rani, B. S. (2026) · Insight - Non-Destructive Testing and Condition Monitoring · doi:10.1784/insi.2026.68.6.389
VLM-Based Advanced Rider Assistance System for Motorcycle Safety
Elnoor, M., Baldini, F., Trivedi, A., Tariq, F. M., D’sa, J., Isele, D., Bae, S., Manocha, D., & Sakamoto, Y. (2026) · IEEE Intelligent Vehicles Symposium · doi:10.1109/iv66570.2026.11624132
Hall, C. O., Kauffman, S. J., & Sarkar, S. (2026) · International Conference on Artificial Intelligence, Computer, Data Sciences and Applications (ACDSA) · doi:10.1109/acdsa67686.2026.11467943
Du, W., Xiao, Y., xin, T., lin, Y., & feng, X. (2026) · SSRN Electronic Journal · doi:10.2139/ssrn.7467114
Exploring the Capability of Deep Neural Network on Ship Sub-Assembly Weld Seam Recognition
Yin, X., Kang, S., Zhang, R., Wei, N., & Jiang, J. (2024) · International Conference on Automation, Robotics and Computer Engineering (ICARCE) · doi:10.1109/icarce63054.2024.00008 · Cited by 1
Multi-Agent System for Orchestrating Retrieval and Multimodal Reasoning in Cloud Environments
Yang, S., Zheng, X.-R., Xu, J.-F., Li, J.-Z., Liu, Z.-W., & Ngai, E. (2026) · IEEE Conference on Computer Communications · doi:10.1109/infocom59046.2026.11571499
A small object detection method based on CSF-YOLO for UAV images
Li, J., Guo, X., Lv, S., Su, J., & Tang, F. (2025) · Neural Computing and Applications · doi:10.1007/s00521-025-11687-4
The Role of Speech Processing in the Metaverse
Anwar, N., Yuhefizar, Y., Faisal, M., Iswahyudi, R. T., Mariyanti, S., Heryati, E., Asrowardi, I., Hastuti, L., & Chairunnisa, D. (2025) · IGI Global eBooks · doi:10.4018/979-8-3373-3048-8.ch008
Improved Vehicle Pedestrian Recognition Algorithm for YOLOv5
Ma, C., & Liu, B. (2024) · International Conference on Communications, Information System and Computer Engineering (CISCE) · doi:10.1109/cisce62493.2024.10653385
Soylu, T., & Soylu, E. (2025) · Celal Bayar Üniversitesi Fen Bilimleri Dergisi · doi:10.18466/cbayarfbe.1669378
Bansal, V., Joshi, A., Aarsha, V. S., Shivali, & Talwandi, N. S. (2025) · Lecture notes in networks and systems · doi:10.1007/978-981-96-6297-5_15 · Cited by 1
Fair Battery Degradation-Aware Edge Admission for Mobile Systems
Chavan, A. S., Atik, S. T., & Brocanelli, M. (2026) · IEEE International Conference on Edge Computing and Communications (EDGE) · doi:10.1109/edge72783.2026.00015
Palacios-Morocho, E., Inca, S., & Monserrat, J. F. (2024) · Mobile Information Systems · doi:10.1155/2024/9280848 · Cited by 3
Improved YOLO v5 with principal component analysis for river object detection
Zhai, Y. (2025) · Journal of Computational Methods in Sciences and Engineering · doi:10.1177/14727978251361843
Tackling Device Data Distribution Real-time Shift via Prototype-based Parameter Editing
Lv, Z., Zhang, W., Fu, K., Tian, Q., Zhang, S., Su, J., Chen, J., Kuang, K., & Wu, F. Q. (2025) · ACM International Conference on Multimedia (ACM MM) · doi:10.1145/3746027.3754895 · Cited by 1
Bhosale, M. M., & Angal, Y. (2024) · Research Square · doi:10.21203/rs.3.rs-4448610/v1
RetractedGejji, S., Rashmi, S., Thanuj Kumar, M., Vekariya, D., Natrayan, L., & SriRagavi, S. (2025) · International Conference on Evolutionary Computing and Mobile Sustainable Networks (ICECMSN) · doi:10.1109/icecmsn68058.2025.11383389
A Study on Image Recognition Technologies for Lightweight Autonomous Robots
Zhou, Y. (2026) · International Conference on Electronic Information Technology and Computer Engineering (EITCE) · doi:10.1109/eitce70137.2026.11634300
HSAR-DETR: Hierarchical Spatial–Frequency Attention Network for UAV Small Object Detection
Zhang, C., & Guo, Z. (2026) · Remote Sensing · doi:10.3390/rs18172861 · Cited by 1
From Single-modal to Multimodal Perception in Intelligent Robotic Manipulators: A Review
Weng, T., Gao, J., Gong, M., Yang, H., Sui, X., Feng, L., Yang, D., & Xiaohu, B. A. I. (2026) · Journal of Bionic Engineering · doi:10.1007/s42235-026-01000-x
DEOF: Discerning and Elastic Offloading for Accuracy-Efficient Video Analytics
Pan, H., Chen, N., Wang, X., Xing, Y., Zhang, S., & Wu, J. (2025) · IEEE International Conference on Parallel and Distributed Systems (ICPADS) · doi:10.1109/icpads67057.2025.11323028
Capturing captivating moments: a multi-model approach for identifying baseball strikeout highlights
Zhang, Q., Chang, C., Shang, C., Chang, H.-C., & Roy, D. S. (2025) · Signal Image and Video Processing · doi:10.1007/s11760-024-03805-x
Real-Time Object Detection in Intelligent Surveillance Videos Based on Improved YOLOv8
Peng, D. (2025) · International Conference on Computer Vision, Application, and Algorithm (CVAA) · doi:10.1109/cvaa66438.2025.11193190
Hybrid Patchcore–YOLOv8 Framework for Anomaly Detection in Chicken Egg Embryos
Thios, R. H., & Zainuddin, Z. (2025) · International Conference on Informatics, Multimedia, Cyber and Information System (ICIMCIS) · doi:10.1109/icimcis68501.2025.11327433
Santos, J. B. A., & Rêgo, P. A. L. (2026) · Anais do Workshop de Computação Urbana (CoUrb) · doi:10.5753/courb.2026.24093
A Lightweight Traffic Signal Video Stream Detection Model Based on Depth-Wise Separable Convolution
Shi, P. J., & Zhang, Z. (2025) · Electronics · doi:10.3390/electronics14224396 · Cited by 1
An AI-Enabled Framework for Object Detection in Autonomous Vehicles Using Deep Learning and OpenCV
Bisen, A. S., Khatik, D. J. K., Dhillon, Y., Bhansali, A., Jain, I., & Rathore, R. (2026) · IEEE International Conference on Interdisciplinary Approaches in Technology and Management for Social Innovation (IATMSI) · doi:10.1109/iatmsi68868.2026.11465959
An Improved YOLOv8 Object Detection Method for Images Recognition for Wearable AR Smart Maintenance
Wang, Y., Wang, J., Ye, C., et al. (2025) · Communications in computer and information science · doi:10.1007/978-981-95-1334-5_12
Teboulbi, S., Messaoud, S., Hajjaji, M. A., Atri, M., & Mtibaa, A. (2025) · International Multi-Conference on Systems, Signals & Devices (SSD) · doi:10.1109/ssd64182.2025.10989869 · Cited by 1
Deployment and Design of AI-Powered Edge Systems for Wildlife Monitoring: A Survey
Martinský, M., Papán, J., & Tatarka, S. (2025) · International Conference on Emerging eLearning Technologies and Applications (ICETA) · doi:10.1109/iceta67772.2025.11280041 · Cited by 1
Mannaperumal, M., & Venkatesan, D. (2026) · Innovations in Systems and Software Engineering · doi:10.1007/s11334-026-00634-8
Turaev, D., Ravikumar, R. N., Aarthi, S., Ashirova, A. I., Urozboev, K., & S., S. K. (2026) · IGI Global eBooks · doi:10.4018/979-8-3373-7785-8.ch002
Dual-Path Attention Network for Small Object Detection in Road Traffic Scenarios
Wang, P., Xu, J., & Du, B. (2026) · Lecture notes in networks and systems · doi:10.1007/978-3-032-31236-5_36
Real-Time Vehicle Detection and Counting Using YOLOv8: Techniques, Challenges, and Evaluation
Ajagalla, M., Choudhary, S., & Arya, R. (2025) · 2025 IEEE DELCON - International Conference on Recent Smart Technologies in Engineering for Sustainable Development · doi:10.1109/delcon68055.2025.11400321
FRCP-YOLO: Road object detection algorithm based on improved YOLOv8n
Liu, D., Wang, C., Xuejun, L., Zhao, X., Yin, C. L., Liu, Y., Li, S., & Li, X. (2026) · PLoS ONE · doi:10.1371/journal.pone.0342084 · Cited by 3
FDA-YOLO: A Lightweight Crack Detection Approach in Rainy Weather via Fourier Domain Adaptation
Qu, Z. (2026) · International Conference on Computer Vision and Data Mining (ICCVDM) · doi:10.1109/iccvdm71812.2026.11709194
Face mask management system for the control of supplies of medical personnel in the private sector
Meneses-Claudio, B., Gutierrez-Rodriguez, S., Perez-Siguas, R. E., Huamaní, E. L., & Yauri-Machaca, M. (2023) · International Journal of ADVANCED AND APPLIED SCIENCES · doi:10.21833/ijaas.2023.05.007
Compress YOLOv5 via Convolution Filters Reconstruction for the Application in Smart City Governance
Wang, S., Wang, Y., Lan, W., Yang, Y., Xin, C., Yu, Y., & Ma, C. (2025) · International Conference on Computer Research and Development · doi:10.1109/iccrd64588.2025.10962968 · Cited by 1
Wang, Z., Liu, Z., Wu, S., et al. (2025) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc60802.2025.11423641
Yang, F., Wu, Z., & Lin, G. (2025) · Engineering Research Express · doi:10.1088/2631-8695/ae2784
Passenger Counting System Using YOLO on Edge AI Devices for Smart Public Transportation
Okano, M. T., Lopes, W. A. C., & Ruggero, S. M. (2025) · International Conference on Electrical and Computer Engineering Researches (ICECER) · doi:10.1109/icecer65523.2025.11401155
Carlos GarciaPreprint
García, C., & Mela, J. L. (2026) · SSRN Electronic Journal · doi:10.2139/ssrn.5999717
PASTA-YOLO: An Enhanced Detector for Small Object Detection in UAV Imagery
Xiao, Y., Guo, B., Wei, Y., et al. (2026) · IEEE International Conference on Acoustics Speech and Signal Processing · doi:10.1109/icassp55912.2026.11462661
Low-Latency Architectures for Real-Time Multi-Stream Object Detection
Umer, M. S., Kazmi, S. M. K. A., Raza, M. U., & Maan, F. (2025) · International Conference on Digital Futures and Transformative Technologies (ICoDT2) · doi:10.1109/icodt269104.2025.11360736 · Cited by 1
DACC: Discerning and adaptive offloading for coarse-grained content-aware video analytics
Pan, H., Chen, N., Huang, H., Sun, Y.-E., Wang, X., Xing, Y., Zhang, S., & Wu, J. (2026) · Computer Networks · doi:10.1016/j.comnet.2026.112130 · Cited by 1
Metadata
- Authors
- Liang, S., Wu, H., Zhen, L., Hua, Q., Garg, S., Kaddoum, G., Hassan, M. M., & Yu, K.
- Affiliations
- Xi’an University of Posts and Telecommunications (CN)
- Hubei University of Arts and Science (CN)
- École de Technologie Supérieure (CA)
- King Saud University (SA)
- Waseda University (JP)
- ORCID
- Venue
- IEEE Transactions on Intelligent Transportation Systems
- Published
- 2022-12
- Volume
- 23
- Issue
- 12
- Pages
- 25345-25360
- ISSN
- 1524-9050 (ISSN-L)
- 1558-0016
- OpenAlex
- W4220827132
- Cited by
- 367
- References
- 64
- Citations by year
- 2026: 88 · 2025: 148 · 2024: 75 · 2023: 51 · 2022: 5
- FWCI
- 22.83
- Type
- journal article
- Language
- en
- Open access
- green
- arxiv.org
- Licence
- Locations
- IEEE Transactions on Intelligent Transportation Systems (publishedVersion)
- arXiv (Cornell University) (submittedVersion)
- Espace ÉTS (ETS) (submittedVersion)
- arXiv (Cornell University) (cc-by)
- Funders
- King Saud University, Riyadh, Saudi Arabia, through the Researchers Supporting Project (RSP 2022/18)
- Topics
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Advanced Neural Network Applications
- Physical Sciences › Computer Science › Computer Networks and Communications › IoT and Edge/Fog Computing
- Physical Sciences › Engineering › Automotive Engineering › Autonomous Vehicle Technology and Safety
- Keywords
- object detection, autonomous vehicles, lightweight neural networks, network pruning, feature fusion, multi-scale prediction, real-time detection, energy efficiency, NVIDIA Jetson, traffic monitoring, driving assistance
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
The claim verdicts this report counts are experimental: their accuracy is not yet measured.
A language model drew the claims from the paper on 2026-09-28, under version 3 of the claim definition (model deepseek-v4.1-flash, prompt extract-v3).
A second model labelled each claim on 2026-09-28 (model jev-1.13-20260917, definition revision gold-guideline-v0.2).
Cited sources are checked with a language model’s help (gpt-6-sol).
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
