

The DOI matches its Crossref record; 51 of the 51 references it cites were found in a registry or an index.
Self-contained soft electrofluidic actuators
Open accessAbstract
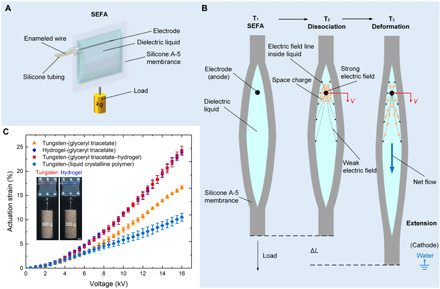
Self-contained soft electrofluidic actuators display excellent performance in portability, rapid response, and actuation.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures

Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“In contrast to soft pneumatic actuators that demand gas supplements and tendon driven actuators that require motors, EAP actuators are activated directly through electrical signals.[488,489]”
From Flexible Electronics and Devices as Human–Machine Interfaces for Medical Robotics (2022) · cites this paper as [489]
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Design, fabrication and control of soft robots
Rus, D., & Tolley, M. T. (2015) · Nature · doi:10.1038/nature14543 · Cited by 5,825 · cited 1×
“The versatility of a SEFA can be easily realized by adjusting the stiffness of the membrane shell, resembling a commonly used approach for conventional fluidic actuators (2).”
A review of shape memory alloy research, applications and opportunities
Mohd Jani, J., Leary, M., Subic, A., & Gibson, M. A. (2014) · Materials & Design (1980-2015) · doi:10.1016/j.matdes.2013.11.084 · Cited by 4,078 · cited 1×
“For example, shape memory alloy actuators can provide large actuation force and high-power density (20), but the lack of controllability limits their applications because of poor control of thermal energy (21).”
BackgroundHigh-Speed Electrically Actuated Elastomers with Strain Greater Than 100%
Pelrine, R., Kornbluh, R., Pei, Q., & Joseph, J. (2000) · Science · doi:10.1126/science.287.5454.836 · Cited by 3,283
Shepherd, R. F., Ilievski, F., Choi, W., Morin, S. A., Stokes, A. A., Mazzeo, A. D., Chen, X., Wang, M., & Whitesides, G. M. (2011) · Proceedings of the National Academy of Sciences · doi:10.1073/pnas.1116564108 · Cited by 2,111
Wireless Power Transfer—An Overview
Zhang, Z., Pang, H., Georgiadis, A., & Cecati, C. (2019) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2018.2835378 · Cited by 1,723
Biomedical applications of soft robotics
Cianchetti, M., Laschi, C., Menciassi, A., & Dario, P. (2018) · Nature Reviews Materials · doi:10.1038/s41578-018-0022-y · Cited by 1,435
Advances in Dielectric Elastomers for Actuators and Artificial Muscles
Brochu, P., & Pei, Q. (2010) · Macromolecular Rapid Communications · doi:10.1002/marc.200900425 · Cited by 1,387
Soft Actuators for Small-Scale Robotics
Hines, L., Petersen, K., Lum, G. Z., & Sitti, M. (2017) · Advanced Materials · doi:10.1002/adma.201603483 · Cited by 1,337
Ferromagnetic soft continuum robots
Kim, Y., Parada, G. A., Liu, S., & Zhao, X. (2019) · Science Robotics · doi:10.1126/scirobotics.aax7329 · Cited by 1,312
Deviations from Ohm's Law in Weak Electrolytes
Onsager, L. (1934) · The Journal of Chemical Physics · doi:10.1063/1.1749541 · Cited by 1,254
Cited by
Flexible Electronics and Devices as Human–Machine Interfaces for Medical Robotics
Heng, W., Solomon, S., & Gao, W. (2022) · Advanced Materials · doi:10.1002/adma.202107902 · Cited by 609
A versatile jellyfish-like robotic platform for effective underwater propulsion and manipulation
Wang, T., Joo, H.-J., Song, S., Hu, W., Keplinger, C., & Sitti, M. (2023) · Science Advances · doi:10.1126/sciadv.adg0292 · Cited by 177
Untethered soft actuators for soft standalone robotics
Jung, Y., Kwon, K., Lee, J., & Ko, S. H. (2024) · Nature Communications · doi:10.1038/s41467-024-47639-0 · Cited by 176
Self-protection soft fluidic robots with rapid large-area self-healing capabilities
Tang, W., Zhong, Y., Xu, H., Qin, K., Guo, X., Hu, Y. H., Zhu, P., Qu, Y., Yan, D., Li, Z., et al. (2023) · Nature Communications · doi:10.1038/s41467-023-42214-5 · Cited by 106
“…15 – 17 , and some are easy to be customized 17 ; however, when embedded into fl uidic robots, their actuation performances are poor, resulting in slow actuation speed 15 – 18 , tiny output force 15 – 18 , limited actuation stroke 18,19 , or dif fi - cult to achieve diversi fi ed design 19 .”
Self-citationPowerful UAV manipulation via bioinspired self-adaptive soft self-contained gripper
Guo, X., Tang, W., Qin, K., Zhong, Y., Xu, H., Qu, Y., Li, Z., Sheng, Q., Gao, Y., Yang, H., et al. (2024) · Science Advances · doi:10.1126/sciadv.adn6642 · Cited by 87
Self-citation
Metadata
- Authors
- Tang, W., Lin, Y., Zhang, C., Liang, Y., Wang, J., Wang, W., Ji, C., Zhou, M., Yang, H., & Zou, J.
- Affiliations
- State Key Laboratory Fluid Power and Mechatronic Systems (CN)
- Shandong University (CN)
- Hangzhou Dianzi University (CN)
- Corresponding author
- Zhang, Chao
- Zou, Jun
- ORCID
- Venue
- Science Advances
- Published
- 2021-08-20
- Volume
- 7
- Issue
- 34
- ISSN
- 2375-2548 (ISSN-L)
- PMC
- PMC8378814
- OpenAlex
- W3194817846
- Cited by
- 74
- References
- 51
- Citations by year
- 2026: 12 · 2025: 19 · 2024: 22 · 2023: 9 · 2022: 11 · 2021: 1
- FWCI
- 3.27
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Science Advances (publishedVersion, cc-by-nc)
- PubMed Central (publishedVersion, cc-by-nc)
- PubMed (publishedVersion)
- Funders
- National Natural Science Foundation of China (51875507, 51890885)
- the Fundamental Research Funds for the Central Universities (2020QNA4003)
- Topics
- Physical Sciences › Engineering › Biomedical Engineering › Soft Robotics and Applications
- Physical Sciences › Materials Science › Electronic, Optical and Magnetic Materials › Dielectric materials and actuators
- Physical Sciences › Engineering › Mechanical Engineering › Advanced Materials and Mechanics
- Keywords
- soft robotics, liquid dielectrics, elastomer deformation, artificial muscles, wearable assistive device, actuation performance
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
How to cite
Cite CoChat for the checks on this page, and the paper for its own findings.
- This page
- CoChat. (2026). Citation check: Self-contained soft electrofluidic actuators. https://app.cochat.ai/papers/10.1126/sciadv.abf8080
- The paper
- Tang, W., Lin, Y., Zhang, C., Liang, Y., Wang, J., Wang, W., Ji, C., Zhou, M., Yang, H., & Zou, J. (2021). Self-contained soft electrofluidic actuators. Science Advances. https://doi.org/10.1126/sciadv.abf8080
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
