

A Single LiDAR-Based Feature Fusion Indoor Localization Algorithm
Open accessThe DOI matches its Crossref record; 39 of the 39 references it cites were found in a registry or an index.
Abstract
In past years, there has been significant progress in the field of indoor robot localization. To precisely recover the position, the robots usually relies on multiple on-board sensors. Nevertheless, this affects the overall system cost and increases computation. In this research work, we considered a light detection and ranging (LiDAR) device as the only sensor for detecting surroundings and propose an efficient indoor localization algorithm. To attenuate the computation effort and preserve localization robustness, a weighted parallel iterative closed point (WP-ICP) with interpolation is presented. As compared to the traditional ICP, the point cloud is first processed to extract corners and line features before applying point registration. Later, points labeled as corners are only matched with the corner candidates. Similarly, points labeled as lines are only matched with the lines candidates. Moreover, their ICP confidence levels are also fused in the algorithm, which make the pose estimation less sensitive to environment uncertainties. The proposed WP-ICP architecture reduces the probability of mismatch and thereby reduces the ICP iterations. Finally, based on given well-constructed indoor layouts, experiment comparisons are carried out under both clean and perturbed environments. It is shown that the proposed method is effective in significantly reducing computation effort and is simultaneously able to preserve localization precision.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures
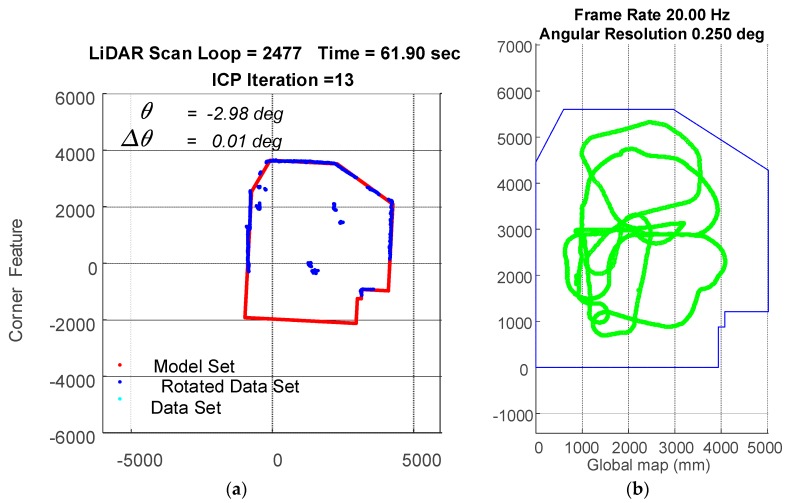
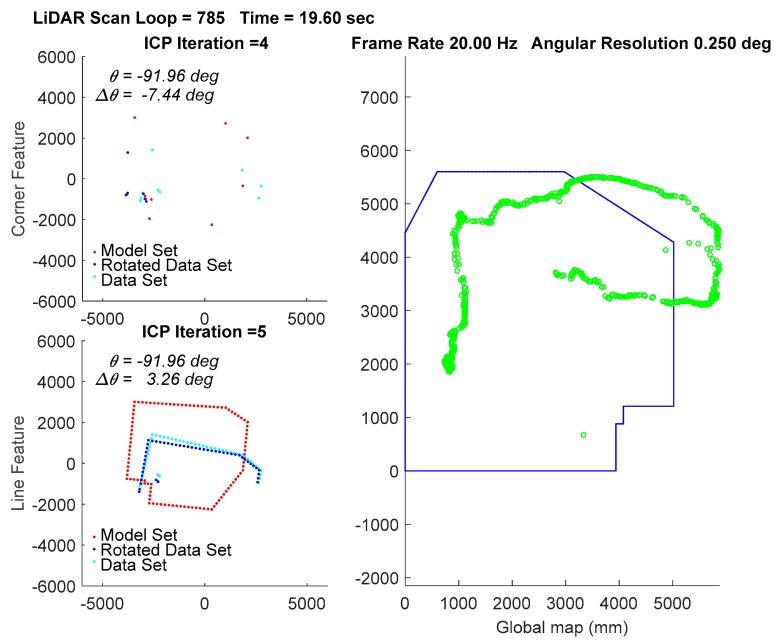
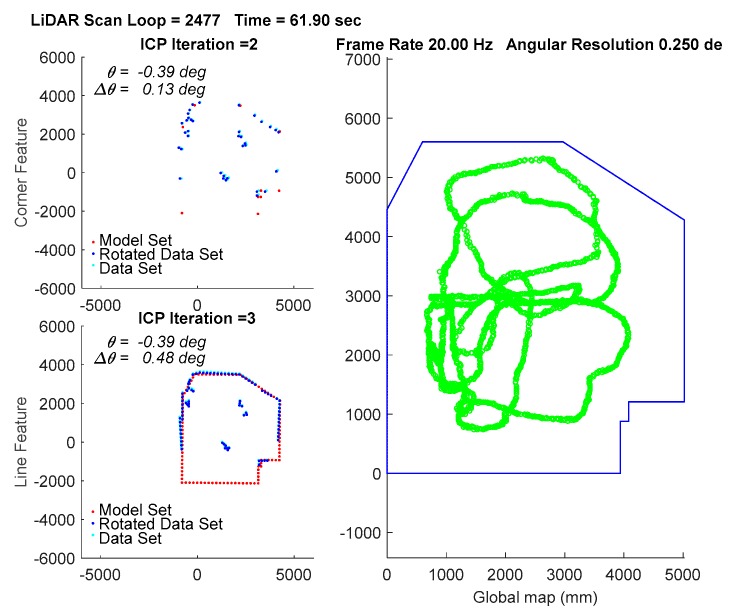
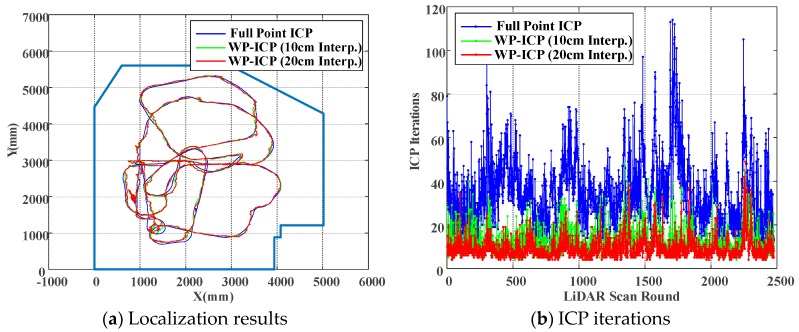
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
A New Approach to Linear Filtering and Prediction Problems
Kalman, R. E. (1960) · Journal of Basic Engineering · doi:10.1115/1.3662552 · Cited by 31,751 · cited 1×
“To obtain precise and high-bandwidth robot pose estimation, the vehicle’s dynamics and traveling status can be further integrated into a Kalman filter [25].”
A method for registration of 3-D shapes
Besl, P. J., & McKay, N. D. (1992) · IEEE Transactions on Pattern Analysis and Machine Intelligence · doi:10.1109/34.121791 · Cited by 18,103
Object recognition from local scale-invariant features
Lowe, D. G. (1999) · Proceedings of the Seventh IEEE International Conference on Computer Vision · doi:10.1109/iccv.1999.790410 · Cited by 16,472
Speeded-Up Robust Features (SURF)
Bay, H., Ess, A., Tuytelaars, T., & Van Gool, L. (2008) · Computer Vision and Image Understanding · doi:10.1016/j.cviu.2007.09.014 · Cited by 13,557 · cited 1×
“Under the condition that the captured images are matched sufficiently, features can be extracted using Scale-Invariant Feature Transform (SIFT) [4] or Speeded Up Robust Features (SURF) [5].”
Efficient variants of the ICP algorithm
Rusinkiewicz, S., & Levoy, M. (2002) · Proceedings Third International Conference on 3-D Digital Imaging and Modeling · doi:10.1109/im.2001.924423 · Cited by 3,945
Method for registration of 3-D shapes:
Besl, P. J., & McKay, N. D. (1992) · SPIE Proceedings · doi:10.1117/12.57955 · Cited by 2,413
The normal distributions transform: a new approach to laser scan matching
Biber, P., & Strasser, W. (2004) · Proceedings 2003 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2003) (Cat. No.03CH37453) · doi:10.1109/iros.2003.1249285 · Cited by 1,554
Guivant, J. E., & Nebot, E. M. (2001) · IEEE Transactions on Robotics and Automation · doi:10.1109/70.938382 · Cited by 772
Robot Pose Estimation in Unknown Environments by Matching 2D Range Scans
Lu, F., & Milios, E. (1997) · Journal of Intelligent and Robotic Systems · doi:10.1023/a:1007957421070 · Cited by 675
An ICP variant using a point-to-line metric
Censi, A. (2008) · 2008 IEEE International Conference on Robotics and Automation · doi:10.1109/robot.2008.4543181 · Cited by 626
Research works printed but not linked: 1
- Duda, R.O., and Hart, P.E. (1973). Pattern Classification and Scene Analysis, John Wiley & Sons.
Cited by
İlçi, V., & Toth, C. K. (2020) · Sensors · doi:10.3390/s20030899 · Cited by 137
Current Algorithms, Communication Methods and Designs for Underwater Swarm Robotics: A Review
Connor, J., Champion, B. T., & Joordens, M. (2020) · IEEE Sensors Journal · doi:10.1109/jsen.2020.3013265 · Cited by 108
Palacín, J., Martínez, D., Clotet, E., Pallejà, T., Burgués, J., Fonollosa, J., Pardo, A., & Marco, S. (2019) · Sensors · doi:10.3390/s19091957 · Cited by 86
An Autonomous Grape-Harvester Robot: Integrated System Architecture
Vrochidou, Ε., Tziridis, K., Nikolaou, A., Kalampokas, Τ., Papakostas, G. A., Pachidis, T. P., Mamalis, S. A., Koundouras, S., & Kaburlasos, V. G. (2021) · Electronics · doi:10.3390/electronics10091056 · Cited by 74
Meng, J., Wan, L. P., Wang, S., Jiang, L., Li, G., Wu, L., & Xie, Y. (2021) · IEEE Transactions on Instrumentation and Measurement · doi:10.1109/tim.2021.3093933 · Cited by 51
Automated reality capture for indoor inspection using BIM and a multi-sensor quadruped robot
Chen, Z., Song, C., Wang, B., Tao, X., Zhang, X., Lin, F., & Cheng, J. C. P. (2024) · Automation in Construction · doi:10.1016/j.autcon.2024.105930 · Cited by 48
Design of a Hybrid Indoor Location System Based on Multi-Sensor Fusion for Robot Navigation
Shi, Y., Zhang, W., Yao, Z., Li, M., Liang, Z., Cao, Z., Zhang, H., & Huang, Q. (2018) · Sensors · doi:10.3390/s18103581 · Cited by 33
A Robust 2D-SLAM Technology With Environmental Variation Adaptability
Chen, L., & Peng, C.-C. (2019) · IEEE Sensors Journal · doi:10.1109/jsen.2019.2931368 · Cited by 32
Self-citationToA Positioning Algorithm for TDoA System Architecture
Chugunov, A. A., Petukhov, N. I., & Kulikov, R. S. (2020) · International Russian Automation Conference (RusAutoCon) · doi:10.1109/rusautocon49822.2020.9208169 · Cited by 32
A Generic Approach toward Indoor Navigation and Pathfinding with Robust Marker Tracking
Khan, D., Ullah, S., & Nabi, S. (2019) · Remote Sensing · doi:10.3390/rs11243052 · Cited by 33
Tripicchio, P., D’Avella, S., & Unetti, M. (2022) · The International Journal of Advanced Manufacturing Technology · doi:10.1007/s00170-022-09018-1 · Cited by 39
An Indoor Positioning Approach Based on Fusion of Cameras and Infrared Sensors
Martín-Gorostiza, E., García-Garrido, M. Á., Pizarro, D., Salido-Monzú, D., & Torres, P. G. (2019) · Sensors · doi:10.3390/s19112519 · Cited by 28
Dai, Y., Lin, Y., Wen, C., Shen, S., Xu, L., Jingyi Yu, A., Ma, Y., & Wang, C. (2022) · IEEE Computer Society Conference on Computer Vision and Pattern Recognition/Proceedings - IEEE Computer Society Conference on Computer Vision and Pattern Recognition/Proceedings · doi:10.1109/cvpr52688.2022.00667 · Cited by 48
Csík, D., Odry, Á., & Šarčević, P. (2023) · Machines · doi:10.3390/machines11020302 · Cited by 30
Advancing indoor positioning systems: innovations, challenges, and applications in mobile robotics
Deshmukh, R. A., Hasamnis, M. A., Kulkarni, M. B., & Bhaiyya, M. L. (2025) · Robotica · doi:10.1017/s0263574725101872 · Cited by 34
Wang, S., Kobayashi, Y., Ravankar, A. A., Ravankar, A. A., & Emaru, T. (2019) · Sensors · doi:10.3390/s19102230 · Cited by 24
Self-citationA CMOS Fully Differential Optoelectronic Receiver for Short-Range LiDAR Sensors
Joo, J.-E., Lee, M.-J., & Park, S. M. (2023) · IEEE Sensors Journal · doi:10.1109/jsen.2023.3236678 · Cited by 19
Kim, Y. H., Choi, M. J., Kim, E. J., & Song, J. W. (2019) · Sensors · doi:10.3390/s19214782 · Cited by 17
Advanced RFID-Robot With Rotating Antennas for Smart Inventory in High-Density Shelving Systems
Motroni, A., D’Avella, S., Buffi, A., Tripicchio, P., Unetti, M., Cecchi, G., & Nepa, P. (2024) · IEEE Journal of Radio Frequency Identification · doi:10.1109/jrfid.2024.3369470 · Cited by 20
Wu, H., & Zaman, M. Q. (2022) · IEEE Access · doi:10.1109/access.2022.3162244 · Cited by 18
Dai, P., Wang, S., Xu, T., Li, M., Gao, F., Xing, J., & Yao, L. (2023) · IEEE Sensors Journal · doi:10.1109/jsen.2023.3327460 · Cited by 15
Bostanci, B., Tekkok, S. C., Soyunmez, M. E., Oğuz-Ekim, P., & Yeganli, F. (2019) · National Conference on Electrical and Electronics Engineering (ELECO) · doi:10.23919/eleco47770.2019.8990648 · Cited by 16
A New Design Identification and Control Based on GA Optimization for An Autonomous Wheelchair
Shamseldin, M. Α., Khaled, E., Youssef, A., Mohamed, D., Ahmed, S., Hesham, A., Elkodama, A., & Badran, M. (2022) · Robotics · doi:10.3390/robotics11050101 · Cited by 15
CNN-Based Fault Detection of Scan Matching for Accurate SLAM in Dynamic Environments
Jeong, H., & Lee, H. (2023) · Sensors · doi:10.3390/s23062940 · Cited by 15
TDOA based localization and its application to the initialization of LiDAR based autonomous robots
Oğuz-Ekim, P. (2020) · Robotics and Autonomous Systems · doi:10.1016/j.robot.2020.103590 · Cited by 14
Paszek, K., & Grzechca, D. E. (2023) · Sensors · doi:10.3390/s23198270 · Cited by 15
Enhanced Drone Navigation in GNSS Denied Environment Using VDM and Hall Effect Sensor
Zahran, S., Moussa, A., & El‐Sheimy, N. (2019) · ISPRS International Journal of Geo-Information · doi:10.3390/ijgi8040169 · Cited by 15
Accurate Ultrasound Indoor Localization Using Spring-Relaxation Technique
Chew, M. T., Alam, F., Legg, M., & Gupta, G. S. (2021) · Electronics · doi:10.3390/electronics10111290 · Cited by 13
An Approach for Opening Doors with a Mobile Robot Using Machine Learning Methods
Mochurad, L., Hladun, Y., Zasoba, Y., & Greguš, M. (2023) · Big Data and Cognitive Computing · doi:10.3390/bdcc7020069 · Cited by 17
Accurate Alignment Inspection System for Low-Resolution Automotive LiDAR
Oh, S., You, J.-H., Eskandarian, A., & Kim, Y. (2021) · IEEE Sensors Journal · doi:10.1109/jsen.2020.3049091 · Cited by 12
Dynamical Analysis of a Navigation Algorithm
Cabezas-Olivenza, M., Zulueta, E., Sánchez-Chica, A., Teso-Fz-Betoño, A., & Fernández‐Gámiz, U. (2021) · Mathematics · doi:10.3390/math9233139 · Cited by 12
Experimental Analysis of Various Blockage Performance for LiDAR Sensor Cleaning Evaluation
Son, S., Lee, W., Jung, H., Lee, J., Kim, C., Lee, H., Cho, S., Jang, J. A., Lee, M., & Ryu, H. (2023) · Sensors · doi:10.3390/s23052752 · Cited by 11
Liu, J., Hasheminasab, S. M., Zhou, T., Manish, R., & Habib, A. F. (2023) · Remote Sensing · doi:10.3390/rs15020504 · Cited by 11
On The Usage of Gaussian Processes for Visible Light Positioning With Real Radiation Patterns
Raes, W., Dhaene, T., & Stevens, N. (2021) · International Symposium on Wireless Communication Systems · doi:10.1109/iswcs49558.2021.9562197 · Cited by 10
Fu, Y., Liu, R., Zhang, H., Liang, G., Rehman, S. U., & Liu, L. (2019) · International Journal of Distributed Sensor Networks · doi:10.1177/1550147719860990 · Cited by 9
Romlay, M. R. M., Ibrahim, A. M., Toha, S. F., Wilde, P. D., & Venkat, I. (2021) · PLoS ONE · doi:10.1371/journal.pone.0256665 · Cited by 8
Real-Time Localization for an AMR Based on RTAB-MAP
Lin, C., Peng, C.-C., & Lu, S.-Y. (2025) · Actuators · doi:10.3390/act14030117 · Cited by 6
Self-citationZhang, Z., Zhou, H., Wang, S., Lv, Y., Zheng, X., & Zeng, L. (2022) · Journal of Physics Conference Series · doi:10.1088/1742-6596/2215/1/012015 · Cited by 6
Multimodal Localization for Embedded Systems: A Survey
Salhi, I., Porêba, M., Piriou, E., Gouet-Brunet, V., & Ojail, M. (2019) · Elsevier eBooks · doi:10.1016/b978-0-12-817358-9.00014-7 · Cited by 13
Ravankar, A. A., Ravankar, A. A., Emaru, T., & Kobayashi, Y. (2020) · SICE Journal of Control Measurement and System Integration · doi:10.9746/jcmsi.13.138 · Cited by 6
Self-citationWang, S., Ravankar, A. A., Ravankar, A. A., Emaru, T., & Kobayashi, Y. (2021) · IEEE/SICE International Symposium on System Integration (SII) · doi:10.1109/ieeeconf49454.2021.9382659 · Cited by 6
Self-citationSingle-Line LiDAR Localization via Contribution Sampling and Map Update Technology
Jiang, X., Yang, D. K., Tian, Z., Liu, G., & Lu, M. (2024) · Sensors · doi:10.3390/s24123927 · Cited by 5
Dai, Y., Wang, Z., Lin, X., Wen, C., Xu, L., Shen, S., Ma, Y., & Wang, C. (2024) · IEEE Transactions on Pattern Analysis and Machine Intelligence · doi:10.1109/tpami.2024.3457229 · Cited by 9
EVALUATION OF LIDAR ODOMETRY AND MAPPING BASED ON REFERENCE LASER SCANNING
Koszyk, J., Łabędź, P., Grzelka, K., Jasińska, A., Pargieła, K., Malczewska, A., Strząbała, K., Michalczak, M., & Ambroziński, Ł. (2023) · The international archives of the photogrammetry, remote sensing and spatial information sciences/International archives of the photogrammetry, remote sensing and spatial information sciences · doi:10.5194/isprs-archives-xlviii-1-w3-2023-79-2023 · Cited by 5
Sensor Modalities and Fusion for Robust Indoor Localisation
Kozłowski, M., Santos‐Rodríguez, R., & Piechocki, R. J. (2019) · ICST Transactions on Ambient Systems · doi:10.4108/eai.12-12-2019.162670 · Cited by 6
Improved ICP Matching Algorithm Based on Laser Radar and IMU
Xu, X., Luo, M., Tan, Z., & Zhang, M. (2018) · IEEE International Conference on Cloud Computing and Intelligence Systems (CCIS) · doi:10.1109/ccis.2018.8691139 · Cited by 4
Machining Learning for 2D-SLAM Object Classification and Recognition
Yu, C.-Y., & Peng, C.-C. (2020) · IEEE International Conference on Consumer Electronics - Taiwan (ICCE-Taiwan) · doi:10.1109/icce-taiwan49838.2020.9258112 · Cited by 4
Self-citationReal-time Interpolation Method For Sparse LiDAR Point Cloud Using RGB Camera
Hasegawa, T., Emaru, T., & Ravankar, A. A. (2021) · IEEE/SICE International Symposium on System Integration (SII) · doi:10.1109/ieeeconf49454.2021.9382760 · Cited by 4
Self-citationAn Uncertainty-driven Analysis for Delayed Mapping SLAM
Dorigoni, D., & Fontanelli, D. (2021) · IEEE International Instrumentation and Measurement Technology Conference · doi:10.1109/i2mtc50364.2021.9459876 · Cited by 4
Vehicle localization using laser scanner
Szaj, W., & Pieniążek, J. (2020) · IEEE International Workshop on Metrology for AeroSpace (MetroAeroSpace) · doi:10.1109/metroaerospace48742.2020.9160100 · Cited by 4
A Low-Power Optoelectronic Receiver IC for Short-Range LiDAR Sensors in 180 nm CMOS
Choi, S., Chon, Y., & Park, S. (2024) · Micromachines · doi:10.3390/mi15091066 · Cited by 4
Multi-Robot Mapping and Navigation Using Topological Features
Ravankar, A. A., Ravankar, A. A., Emaru, T., & Kobayashi, Y. (2019) · International Electronic Conference on Sensors and Applications (ECSA) · doi:10.3390/ecsa-6-06580 · Cited by 3
Self-citationA low cost collision avoidance system based on a ToF camera for SLAM approaches
Romero-Godoy, D., Sánchez-Rodríguez, D., González, A., & Delgado, F. (2022) · Revista Tecnología en Marcha · doi:10.18845/tm.v35i8.6465 · Cited by 3
Liu, H., Luo, S., & Lu, J. (2020) · IET Image Processing · doi:10.1049/iet-ipr.2019.1657 · Cited by 3
Localization System Through 2D LiDAR based Semantic Feature For Indoor Robot
Bae, S.-H., Joo, S.-H., Choi, J.-H., Park, H., & Kuc, T. (2022) · International Conference on Ubiquitous Robots (UR) · doi:10.1109/ur55393.2022.9826250 · Cited by 3
The Design, Fabrication and Preliminary Testing of a Variable Configuration Mobile Robot
Giannoccaro, N. I., & Nishida, T. (2019) · International Journal of Robotics and Automation Technology · doi:10.31875/2409-9694.2019.06.6 · Cited by 3
Chon, Y., Choi, S., & Park, S.-M. (2024) · Photonics · doi:10.3390/photonics11100974 · Cited by 3
A convenient height-filtering-based strategy for multi-source forest LiDAR point cloud registration
Yu, Z., Wang, H., Wu, Y., Zhang, X., Lu, C., Liu, Z., Xu, Y., Ou, G., & Luo, H. (2026) · Smart Agricultural Technology · doi:10.1016/j.atech.2026.101790 · Cited by 2
Zhang, X., Choi, S., Chon, Y., & Park, S. (2024) · Sensors · doi:10.3390/s24113513 · Cited by 2
Joseph, M., Malackowski, H. A., Hanafy, H., Liu, J., DeLoach, Z., Bullock, D. M., & Habib, A. F. (2024) · ISPRS Open Journal of Photogrammetry and Remote Sensing · doi:10.1016/j.ophoto.2024.100073 · Cited by 2
An 8 × 8 CMOS Optoelectronic Readout Array of Short-Range LiDAR Sensors
Chon, Y., Choi, S., Joo, J., & Park, S. M. (2024) · Sensors · doi:10.3390/s24206686 · Cited by 2
Indoor positioning system for warehouse environment: A scoping review
Zhang, X., Tan, Y. C., Taı, V. C., & Hao, Y. (2024) · JOURNAL OF MECHANICAL ENGINEERING AND SCIENCES · doi:10.15282/jmes.18.4.2024.9.0815 · Cited by 4
Improved Localization Algorithm Based on MultiSensor Fusion for Shopping Robots
Zhao, Y., Solihin, M. I., Yang, D., Cai, B., & Liu, C. (2024) · International Symposium on Sensor Technology and Control (ISSTC) · doi:10.1109/isstc63573.2024.10824123 · Cited by 2
3D Visible Light Positioning of an Angle Diverse Receiver based on Track Analysis
Weiss, A. P., Wenzl, F. P., Leiner, C., Lichtenegger, F., & Sommer, C. (2020) · International Conference on Broadband Communications for Next Generation Networks and Multimedia Applications (CoBCom) · doi:10.1109/cobcom49975.2020.9174066 · Cited by 2
Giannoccaro, N. I., & Nishida, T. (2021) · Journal of Automation Mobile Robotics & Intelligent Systems · doi:10.14313/jamris/4-2020/41 · Cited by 2
Object Recognition and Classification of 2D-SLAM using Machine Learning and Deep Learning Techniques
Lin, Y.-F., Yang, L.-J., Yu, C.-Y., Peng, C.-C., & Huang, D. (2020) · International Symposium on Computer, Consumer and Control · doi:10.1109/is3c50286.2020.00129 · Cited by 2
Self-citationLIDAR-BASED INITIAL GLOBAL LOCALIZATION USING IMPERFECT ARCHITECTURAL SKELETON INFORMATION
Luo, J., & Ye, Q. (2022) · The international archives of the photogrammetry, remote sensing and spatial information sciences/International archives of the photogrammetry, remote sensing and spatial information sciences · doi:10.5194/isprs-archives-xliii-b1-2022-241-2022 · Cited by 2
FSM: Correspondenceless scan-matching of panoramic 2D range scans
Filotheou, A., Sergiadis, G. D., & Dimitriou, A. G. (2022) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros47612.2022.9981228 · Cited by 2
Mobile Robot Trajectory Reconstruction with UHF-RFID Synthetic Aperture Localization
Motroni, A., Tavanti, E., & Nepa, P. (2025) · IEEE International Conference on RFID Technology and Applications (RFID-TA) · doi:10.1109/rfid-ta63091.2025.11265910 · Cited by 1
A Study on Efficient LiDAR-based Localization with Initial Pose Estimation
Takayama, Y., Urakubo, T., & Tamaki, H. (2020) · IEEE/SICE International Symposium on System Integration (SII) · doi:10.1109/sii46433.2020.9026193 · Cited by 1
Close-Contact Detection Using a Single Camera for Sports Considering Occlusion
Hasegawa, R., Uchiyama, A., Okura, F., Muramatsu, D., Ogasawara, I., Takahata, H., Nakata, K., & Teruo Higashino, Y. (2022) · IEEE Access · doi:10.1109/access.2022.3146538 · Cited by 1
Song, Y., Choi, Y., Jung, D., Choi, S., & Park, S. (2025) · Sensors · doi:10.3390/s25041040 · Cited by 1
Zwingel, M., Herbert, M., Lieret, M., Schuderer, P., & Franke, J. E. (2020) · Lecture notes in production engineering · doi:10.1007/978-3-662-62138-7_46 · Cited by 1
Implementation of ICP Slam Algorithm on Fire Bird V for Mapping of an Indoor Environment
Shankar, S. I. A., Shivakumar, M. R., & Prakash, K. R. (2021) · Atlantis Highlights in Computer Sciences/Atlantis highlights in computer sciences · doi:10.2991/ahis.k.210913.082 · Cited by 1
Rad, S. Z., Weiss, A. P., Kröpfl, A., & Leitgeb, E. (2022) · International Spring Seminar on Electronics Technology · doi:10.1109/isse54558.2022.9812836 · Cited by 1
Kishinami, H., Itoyama, K., Nishida, K., & Nakadai, K. (2021) · Journal of the Robotics Society of Japan · doi:10.7210/jrsj.39.271
Yamakado, I., Shinohara, T., Uebo, T., & Nakasako, N. (2022) · IEEJ Transactions on Electronics Information and Systems · doi:10.1541/ieejeiss.142.752
Visual Scene Reconstruction based on Echolocation with a Generative Adversarial Network
Kishinami, H., Itoyama, K., Nishida, K., & Nakadai, K. (2022) · Journal of the Robotics Society of Japan · doi:10.7210/jrsj.40.351
Reconstruction of Depth Scenes Based on Echolocation
Kishinami, H., Itoyama, K., Nishida, K., & Nakadai, K. (2023) · IEEE/SICE International Symposium on System Integration (SII) · doi:10.1109/sii55687.2023.10039271
A CAMERA-LIDAR CALIBRATION METHOD ASSISTED BY INDOOR SPATIAL STRUCTURE
Ye, C., Kang, Z., & Guo, X. (2023) · The international archives of the photogrammetry, remote sensing and spatial information sciences/International archives of the photogrammetry, remote sensing and spatial information sciences · doi:10.5194/isprs-archives-xlviii-1-w2-2023-693-2023
Method for robot recognition and localization based on third-person perspective
luo, Z., & Lu, J. (2024) · International Conference on Machine Learning and Computer Application (ICMLCA) · doi:10.1117/12.3028993
Jo, J. H., & Moon, C.-B. (2025) · International Journal of Advanced Robotic Systems · doi:10.1177/17298806251406790 · Cited by 1
Fusion multiphysique pour système de localisation indoor
Bougouffa, A. (2023) · theses.fr (ABES) · doi:10.70675/1bdc4353zbdc0z4842zbfa5ze285f5b49409
Indoor Smartphone Positioning Method via a Single Wall Reflection Using a Parametric Speaker
Luo, X., Nakamura, M., Hashizume, H., & Sugimoto, M. (2026) · IEEE Sensors Journal · doi:10.1109/jsen.2026.3694483
Metadata
- Authors
- Wang, Y.-T., Peng, C.-C., Ravankar, A. A., & Ravankar, A.
- Affiliations
- National Cheng Kung University (TW)
- Hokkaido University (JP)
- Corresponding author
- Peng, Chao-Chung
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2018-04-23
- Volume
- 18
- Issue
- 4
- Pages
- 1294
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC5949039
- OpenAlex
- W2801240241
- Cited by
- 84
- References
- 38
- Citations by year
- 2026: 2 · 2025: 5 · 2024: 12 · 2023: 12 · 2022: 13 · 2021: 13 · 2020: 12 · 2019: 13 · 2018: 2
- FWCI
- 8.14
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- Europe PMC (PubMed Central) (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- Institutional Repositories DataBase (IRDB) (submittedVersion, cc-by)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Hokkaido University Collection of Scholarly and Academic Papers (Hokkaido University) (submittedVersion, cc-by)
- Funders
- Ministry of Science and Technology, Taiwan (MOST107-2218-E006-004, MOST106-2221-E006-138)
- Topics
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Robotics and Sensor-Based Localization
- Physical Sciences › Engineering › Electrical and Electronic Engineering › Indoor and Outdoor Localization Technologies
- Physical Sciences › Earth and Planetary Sciences › Geology › 3D Surveying and Cultural Heritage
- Keywords
- indoor robot localization, LiDAR, feature fusion, point cloud registration, pose estimation, computation reduction, sensor fusion
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
