

The DOI matches its Crossref record; 64 of the 64 references it cites were found in a registry or an index.
A Systematic Review of Perception System and Simulators for Autonomous Vehicles Research
Open accessAbstract
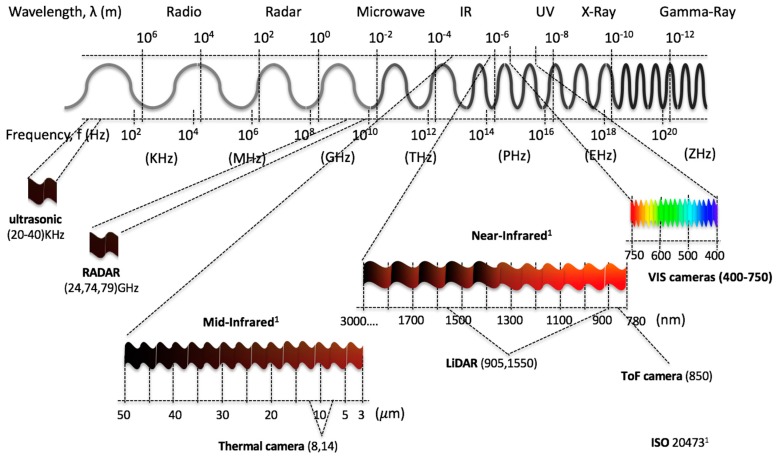
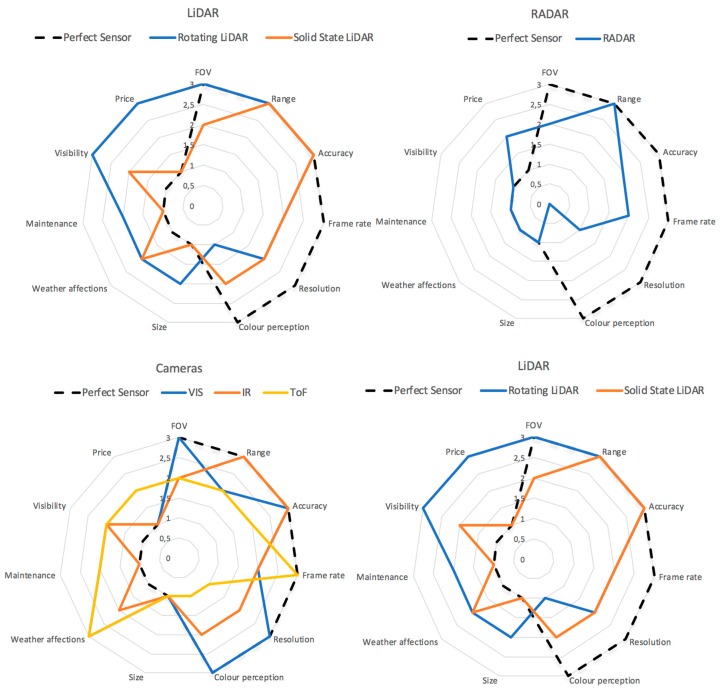
This paper presents a systematic review of the perception systems and simulators for autonomous vehicles (AV). This work has been divided into three parts. In the first part, perception systems are categorized as environment perception systems and positioning estimation systems. The paper presents the physical fundamentals, principle functioning, and electromagnetic spectrum used to operate the most common sensors used in perception systems (ultrasonic, RADAR, LiDAR, cameras, IMU, GNSS, RTK, etc.). Furthermore, their strengths and weaknesses are shown, and the quantification of their features using spider charts will allow proper selection of different sensors depending on 11 features. In the second part, the main elements to be taken into account in the simulation of a perception system of an AV are presented. For this purpose, the paper describes simulators for model-based development, the main game engines that can be used for simulation, simulators from the robotics field, and lastly simulators used specifically for AV. Finally, the current state of regulations that are being applied in different countries around the world on issues concerning the implementation of autonomous vehicles is presented.
Overview
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Integrity signals
Registry
Cites
Statistics
Figures
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“The Global Positioning System (GPS) is the most common GNSS system freely available to be used in any part of the world [111].”
From Sensor-Based Prognostic Health Management of Advanced Driver Assistance System for Autonomous Vehicles: A Recent Survey (2022) · cites this paper as [111]
Experimental — accuracy not yet measuredThe source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“It is mentioned that a pure vision-based system has advantages like affordability and simplicity of implementation.”
From Object Detection in Autonomous Vehicles under Adverse Weather: A Review of Traditional and Deep Learning Approaches (2024) · cites this paper as [48]
Experimental — accuracy not yet measuredThe source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Such simulation not only includes software simulation like CarSim and CARLA. but also includes hybrid realization with hardware-in-the-loop or vehicle-in-the-loop design [67].”
From Trustworthy AI: From Principles to Practices (2023) · cites this paper as [67]
Experimental — accuracy not yet measuredThe cited source says what the claim attributes to it.
In the citing paper
“Such simulation not only includes software simulation like CarSim and CARLA. but also includes hybrid realization with hardware-in-the-loop or vehicle-in-the-loop design [67].”
From Trustworthy AI: From Principles to Practices (2023) · cites this paper as [67]
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Vision meets robotics: The KITTI dataset
Geiger, A., Lenz, P., Stiller, C., & Urtasun, R. (2013) · The International Journal of Robotics Research · doi:10.1177/0278364913491297 · Cited by 9,913
Kalra, N., & Paddock, S. M. (2016) · Transportation Research Part A: Policy and Practice · doi:10.1016/j.tra.2016.09.010 · Cited by 1,221
A Review of Data Fusion Techniques
Castanedo, F. (2013) · The Scientific World Journal · doi:10.1155/2013/704504 · Cited by 1,027
Thermal cameras and applications: A survey
Gade, R., & Moeslund, T. B. (2014) · Machine Vision and Applications · doi:10.1007/s00138-013-0570-5 · Cited by 780
Challenges in autonomous vehicle testing and validation
Koopman, P., & Wagner, M. (2016) · SAE International Journal of Transportation Safety · doi:10.4271/2016-01-0128 · Cited by 675
USARSim: a robot simulator for research and education
Carpin, S., Lewis, M., Wang, J., Balakirsky, S. B., & Scrapper, C. (2007) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/robot.2007.363180 · Cited by 423
Pedestrian Detection at Day/Night Time with Visible and FIR Cameras: A Comparison
González, A., Fang, Z., Socarras, Y., Serrat, J., Vázquez, D., Xu, J., & López, A. M. (2016) · Sensors · doi:10.3390/s16060820 · Cited by 330
Bimbraw, K. (2015) · International Conference on Informatics in Control, Automation and Robotics (ICINCO) · doi:10.5220/0005540501910198 · Cited by 324
Development of Autonomous Car—Part I: Distributed System Architecture and Development Process
Jo, K., Kim, J., Kim, D., Jang, C., & Sunwoo, M. (2014) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2014.2321342 · Cited by 277
Development of advanced driver assistance systems with vehicle hardware-in-the-loop simulations
Gietelink, O. J., Ploeg, J., Schutter, B. D., & Verhaegen, M. (2006) · Vehicle System Dynamics · doi:10.1080/00423110600563338 · Cited by 272
The Transferability Approach: Crossing the Reality Gap in Evolutionary Robotics
Koos, S., Mouret, J.-B., & Doncieux, S. (2012) · IEEE Transactions on Evolutionary Computation · doi:10.1109/tevc.2012.2185849 · Cited by 272
Multispectral Pedestrian Detection using Deep Fusion Convolutional Neural Networks.
Wagner, J., Fischer, V., Herman, M., & Behnke, S. (2016) · The European Symposium on Artificial Neural Networks · Cited by 244
Trainable classifier-fusion schemes: An application to pedestrian detection
Ludwig, O., Delgado, D., Gonçalves, V., & Nunes, U. (2009) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc.2009.5309700 · Cited by 232
Thrun, S. (2010) · Communications of the ACM · doi:10.1145/1721654.1721679 · Cited by 229
On-Road Vehicle Detection and Tracking Using MMW Radar and Monovision Fusion
Wang, X., Xu, L., Sun, H., Xin, J., & Zheng, N. (2016) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2016.2533542 · Cited by 217
In-field High Throughput Phenotyping and Cotton Plant Growth Analysis Using LiDAR
Sun, S., Li, C., Paterson, A. H., Jiang, Y., Xu, R. Y., Robertson, J. S., Snider, J. L., & Chee, P. W. (2018) · Frontiers in Plant Science · doi:10.3389/fpls.2018.00016 · Cited by 215
Sensor Fusion-Based Low-Cost Vehicle Localization System for Complex Urban Environments
Suhr, J. K., Jang, J., Min, D., & Jung, H. G. (2016) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2016.2595618 · Cited by 178
Renn, O., & Benighaus, C. (2012) · Journal of Risk Research · doi:10.1080/13669877.2012.729522 · Cited by 157
Wojtanowski, J., Zygmunt, M., Kaszczuk, M., Mierczyk, Z., & Muzal, M. (2014) · Opto-Electronics Review · doi:10.2478/s11772-014-0190-2 · Cited by 145
Navarro, P., Fernández, C., Borraz, R., & Alonso, D. (2016) · Sensors · doi:10.3390/s17010018 · Cited by 138
Self-citationRadar/Lidar sensor fusion for car-following on highways
Goehring, D., Wang, M., Schnürmacher, M., & Ganjineh, T. (2011) · International Conference on Automation, Robotics and Applications · doi:10.1109/icara.2011.6144918 · Cited by 134
Comparison of EKF and UKF for Spacecraft Localization via Angle Measurements
Giannitrapani, A., Ceccarelli, N., Scortecci, F., & Garulli, A. (2011) · IEEE Transactions on Aerospace and Electronic Systems · doi:10.1109/taes.2011.5705660 · Cited by 119
John, V., Mita, S., Liu, Z., & Qi, B. (2015) · Machine Vision Applications · doi:10.1109/mva.2015.7153177 · Cited by 116
(1995) · Lecture notes in computer science · doi:10.1007/3-540-59496-5 · Cited by 113
Sensor Fusion Methodology for Vehicle Detection
García, F., Martín, D., de la Escalera, A., & Armingol, J. M. (2017) · IEEE Intelligent Transportation Systems Magazine · doi:10.1109/mits.2016.2620398 · Cited by 110
An Analysis of ISO 26262: Machine Learning and Safety in Automotive Software
Salay, R., Queiroz, R., & Czarnecki, K. (2018) · SAE Technical Paper Series · doi:10.4271/2018-01-1075 · Cited by 109
In-Field High-Throughput Phenotyping of Cotton Plant Height Using LiDAR
Sun, S., Li, C., & Paterson, A. H. (2017) · Remote Sensing · doi:10.3390/rs9040377 · Cited by 100
Plummer, A. R. (2006) · Proceedings of the Institution of Mechanical Engineers Part I Journal of Systems and Control Engineering · doi:10.1243/09596518jsce207 · Cited by 95
Bokc, T., Maurer, M., & Färber, G. (2007) · IEEE Intelligent Vehicles Symposium · doi:10.1109/ivs.2007.4290183 · Cited by 92
Kim, H., Liu, B., Goh, C. Y., Lee, S., & Myung, H. (2017) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2017.2673868 · Cited by 88
Vehicle detection based on LiDAR and camera fusion
Zhang, F., Clarke, D., & Knoll, A. (2014) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc.2014.6957925 · Cited by 86
Iwasaki, Y., Misumi, M., & Nakamiya, T. (2013) · Italian National Conference on Sensors · doi:10.3390/s130607756 · Cited by 80
An integrated architecture for autonomous vehicles simulation
Pereira, J. L. F., & Rossetti, R. J. F. (2012) · ACM Symposium on Applied Computing · doi:10.1145/2245276.2245333 · Cited by 77
Camera/Laser/GPS Fusion Method for Vehicle Positioning Under Extended NIS-Based Sensor Validation
Wei, L., Cappelle, C., & Ruichek, Y. (2013) · IEEE Transactions on Instrumentation and Measurement · doi:10.1109/tim.2013.2265476 · Cited by 69
A Generic Solution to Software-in-the-Loop
Demers, S., Gopalakrishnan, P. K., & Kant, L. (2007) · IEEE Military Communications Conference (MILCOM) · doi:10.1109/milcom.2007.4455268 · Cited by 61
Virtual Reality Driving Simulation for Measuring Driver Behavior and Characteristics
Taheri, S. M., Matsushita, K., & Sasaki, M. (2017) · Journal of Transportation Technologies · doi:10.4236/jtts.2017.72009 · Cited by 60
Bechtold, S., & Höfle, B. (2016) · ISPRS annals of the photogrammetry, remote sensing and spatial information sciences · doi:10.5194/isprs-annals-iii-3-161-2016 · Cited by 54
The CAT Vehicle Testbed: A Simulator with Hardware in the Loop for Autonomous Vehicle Applications
Bhadani, R. K., Sprinkle, J. M., & Bunting, M. (2018) · Electronic Proceedings in Theoretical Computer Science · doi:10.4204/eptcs.269.4 · Cited by 54
The Governance of Risks in Ridesharing: A Revelatory Case from Singapore
Li, Y., Taeihagh, A., & de Jong, M. (2018) · Energies · doi:10.3390/en11051277 · Cited by 53
The performance comparison between GPs and BeiDou‐2/compass: A perspective from Asia
Chen, H., Huang, Y., Chiang, K., Yang, M., & Rau, R. (2009) · Journal of the Chinese Institute of Engineers · doi:10.1080/02533839.2009.9671550 · Cited by 52
Cooperative positioning and radar sensor fusion for relative localization of vehicles
Müller, F. D. P., Diaz, E. M., & Rashdan, I. (2016) · IEEE Intelligent Vehicles Symposium · doi:10.1109/ivs.2016.7535520 · Cited by 48
CCD or CMOS Image sensor for photography
Mehta, S., Patel, A., & Mehta, J. (2015) · International Conference on Communications and Signal Processing (ICCSP) · doi:10.1109/iccsp.2015.7322890 · Cited by 45
Hardware-in-the-loop simulation for autonomous driving
Deng, W., Lee, Y. H., & Zhao, A. (2008) · Annual Conference of the IEEE Industrial Electronics Society (IECON) · doi:10.1109/iecon.2008.4758217 · Cited by 45
Forslund, D., & Bjärkefur, J. (2014) · IEEE Intelligent Vehicles Symposium · doi:10.1109/ivs.2014.6856446 · Cited by 44
Melendez-Pastor, C., Ruiz-Gonzalez, R., & Gil, J. (2017) · Expert Systems with Applications · doi:10.1016/j.eswa.2017.03.018 · Cited by 44
An Incremental V-Model Process for Automotive Development
Liu, B., Zhang, H., & Zhu, S. (2016) · Proceedings - Asia Pacific Software Engineering Conference/Proceedings · doi:10.1109/apsec.2016.040 · Cited by 44
Agent-based simulation of autonomous cars
Bösch, P. M., & Ciari, F. (2015) · Proceedings of the ... American Control Conference/Proceedings of the American Control Conference · doi:10.1109/acc.2015.7171123 · Cited by 43
The Evolutionary Truth About Living Fossils
Shear, W. A., & Werth, A. J. (2014) · American Scientist · doi:10.1511/2014.111.434 · Cited by 41
Comparison of Agent-based Simulation Frameworks for Unmanned Aerial Transportation Applications
Mualla, Y., Bai, W., Galland, S., & Nicolle, C. (2018) · Procedia Computer Science · doi:10.1016/j.procs.2018.04.137 · Cited by 41
PaTAVTT: A Hardware-in-the-Loop Scaled Platform for Testing Autonomous Vehicle Trajectory Tracking
Xu, Z., Wang, M., Zhang, F., Jin, S., Zhang, J., & Zhao, X. (2017) · Journal of Advanced Transportation · doi:10.1155/2017/9203251 · Cited by 39
Bechtold, S., & Höfle, B. (2016) · ISPRS annals of the photogrammetry, remote sensing and spatial information sciences · doi:10.5194/isprsannals-iii-3-161-2016 · Cited by 35
Night Vision Pedestrian Detection Using a Forward-Looking Infrared Camera
Sun, H., Wang, C., & Wang, B. (2011) · doi:10.1109/m2rsm.2011.5697384 · Cited by 31
An approach to simulate autonomous vehicles in urban traffic scenarios
Figueiredo, M. C., Rossetti, R. J. F., Braga, R. A. M., & Reis, L. P. (2009) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc.2009.5309524 · Cited by 30
MADRaS : Multi Agent Driving Simulator
Santara, A., Rudra, S., Buridi, S. A., Kaushik, M., Naik, A., Kaul, B., & Ravindran, B. (2021) · Journal of Artificial Intelligence Research · doi:10.1613/jair.1.12531 · Cited by 27
Automated Driving with ROS at BMW
Aeberhard, M., Kühbeck, T., Seidl, B., & al., E. (2015) · ROSCon · doi:10.36288/roscon2015-900192 · Cited by 26
Far infrared pedestrian detection and tracking for night driving
Olmeda, D., de la Escalera, A., & Armingol, J. M. (2010) · Robotica · doi:10.1017/s0263574710000299 · Cited by 25
Cloud Incubator Car: A Reliable Platform for Autonomous Driving
Borraz, R., Navarro, P., Fernández, C., & Alcover, P. M. (2018) · Applied Sciences · doi:10.3390/app8020303 · Cited by 23
Self-citationWoods, J., & Christian, J. A. (2016) · Journal of Imaging · doi:10.3390/jimaging2010005 · Cited by 21
Continuous-discrete filtering using EKF, UKF, and PF
Mallick, M. K., Morelande, M. R., & Mihaylova, L. S. (2012) · Cited by 19
SIMLIDAR – Simulation of LIDAR performance in artificially simulated orchards
Méndez, V., Mogorrón, H. C., Rosell-Polo, J. R., Arnó, J., Sanz, R., & Tarquis, A. M. (2011) · Biosystems Engineering · doi:10.1016/j.biosystemseng.2011.10.010 · Cited by 19
18. Internationales Stuttgarter Symposium
David, C., & Vohrer, S. (2018) · Proceedings · doi:10.1007/978-3-658-21194-3 · Cited by 17
Autonomous driving simulator for educational purposes
Costa, V., Rossetti, R. J. F., & Sousa, A. J. (2016) · Iberian Conference on Information Systems and Technologies (CISTI) · doi:10.1109/cisti.2016.7521461 · Cited by 14
CNN-LIDAR pedestrian classification: combining range and reflectance data
Melotti, G., Asvadi, A., & Premebida, C. (2018) · IEEE International Conference on Vehicular Electronics and Safety (ICVES) · doi:10.1109/icves.2018.8519497 · Cited by 13
Obstacle Detection using a Time of Flight Range Camera
García, A. R., Miller, L., Andrés, C. F., & Navarro, P. (2018) · IEEE International Conference on Vehicular Electronics and Safety (ICVES) · doi:10.1109/icves.2018.8519501 · Cited by 5
Self-citation
Research works printed but not linked: 2
- Council, N.R. (2001). Statistics, Testing, and Defense Acquisition: New Approaches and Methodological Improvements, The National Academies Press.
- Dosovitskiy, A., Ros, G., Codevilla, F., Lopez, A., and Koltun, V. (arXiv, 2017). CARLA: An Open Urban Driving Simulator, arXiv.
Cited by
Sorted by citations
Deep reinforcement learning for autonomous driving: A survey
Kiran, B. R., Sobh, I., Talpaert, V., Mannion, P., Sallab, A. A. A., Yogamani, S., & Perez, P. (2022) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2021.3054625 · Cited by 2,342
Sensor and Sensor Fusion Technology in Autonomous Vehicles: A Review
Yeong, D. J., Velasco-Hernandez, G., Barry, J., & Walsh, J. L. (2021) · Sensors · doi:10.3390/s21062140 · Cited by 1,187
Survey of Deep Reinforcement Learning for Motion Planning of Autonomous Vehicles
Aradi, S. (2020) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2020.3024655 · Cited by 704
Gupta, A., Anpalagan, A., Guan, L., & Khwaja, A. S. (2021) · Array · doi:10.1016/j.array.2021.100057 · Cited by 609
Trustworthy AI: From Principles to Practices
Li, B., Qi, P., Liu, B., Di, S., Liu, J., Pei, J., Yi, J., & Zhou, B. (2023) · ACM Computing Surveys · doi:10.1145/3555803 · Cited by 612
Metadata
- Authors
- Rosique, F., Navarro, P. J., Fernández, C., & Padilla, A.
- Affiliations
- Universidad Politécnica de Cartagena (ES)
- Corresponding author
- Rosique, Francisca
- Navarro, Pedro J.
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2019-02-05
- Volume
- 19
- Issue
- 3
- Pages
- 648
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC6387009
- OpenAlex
- W2912493354
- Cited by
- 469
- References
- 63
- Citations by year
- 2026: 34 · 2025: 49 · 2024: 80 · 2023: 96 · 2022: 71 · 2021: 74 · 2020: 47 · 2019: 17
- FWCI
- 5.47
- Type
- journal article
- Language
- en
- Open access
- gold
- dx.doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- Europe PMC (PubMed Central) (publishedVersion, other-oa)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Digital Repository (Polytechnic University of Cartagena) (submittedVersion, cc-by-nc-nd)
- Funders
- Dirección General de Tráfico (SPIP2017-02286)
- Ministerio de Economía y Competitividad (BFU2017-88300-C2-2-R)
- Fundación Séneca (19895/GERM/15)
- Topics
- Physical Sciences › Engineering › Automotive Engineering › Autonomous Vehicle Technology and Safety
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Robotics and Sensor-Based Localization
- Physical Sciences › Engineering › Automotive Engineering › Vehicle Dynamics and Control Systems
- Keywords
- autonomous vehicles, perception systems, vehicle simulator, sensor comparison, ultrasonic sensors, radar, LiDAR, camera, inertial measurement unit, GNSS, RTK, game engines, model-driven engineering, autonomous vehicle regulation
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
