

Large-Area Soft e-Skin: The Challenges Beyond Sensor Designs
Open accessThe DOI matches its Crossref record; 181 of the 185 references it cites were found in a registry or an index.
Abstract
Sensory feedback from touch is critical for many tasks carried out by robots and humans, such as grasping objects or identifying materials. Electronic skin (e-skin) is a crucial technology for these purposes. Artificial tactile skin that can play the roles of human skin remains a distant possibility because of hard issues in resilience, manufacturing, mechanics, sensorics, electronics, energetics, information processing, and transport. Taken together, these issues make it difficult to bestow robots, or prosthetic devices, with effective tactile skins. Nonetheless, progress over the past few years in relation with the above issues has been encouraging, and we have achieved close to providing some of the abilities of biological skin with the advent of deformable sensors and flexible electronics. The naive imitation of skin morphology and sensing an impoverished set of mechanical and thermal quantities are not sufficient. There is a need to find more efficient ways to extract tactile information from mechanical contact than those previously available. Renewed interest in neuromorphic tactile skin is expected to bring some fresh ideas in this field. This article reviews these new developments, particularly related to the handling of tactile data, energy autonomy, and large-area manufacturing. The challenges in relation with these advances for tactile sensing and haptics in robotics and prosthetics are discussed along with potential solutions.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures

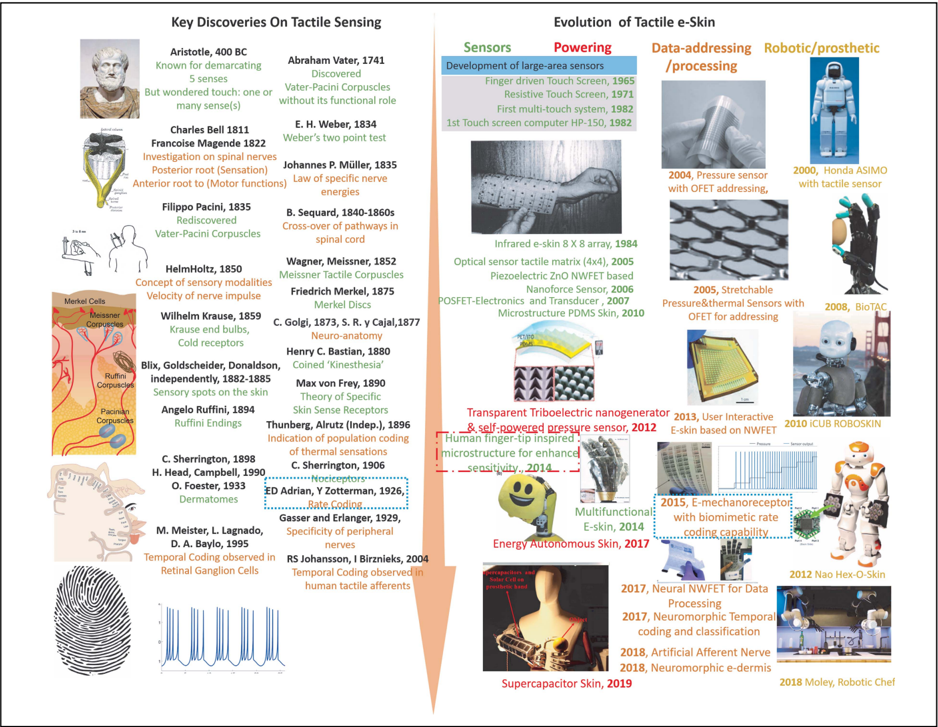

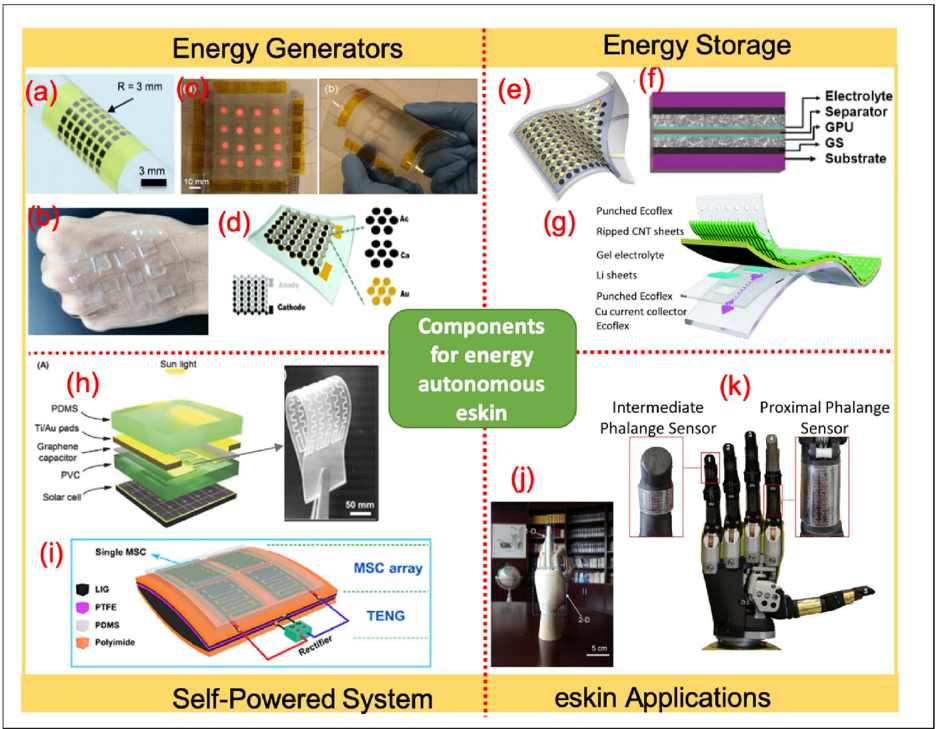

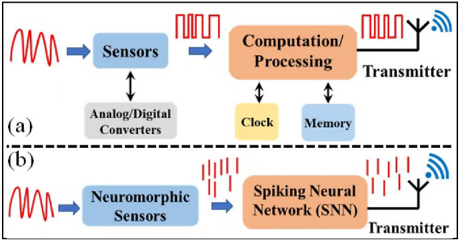


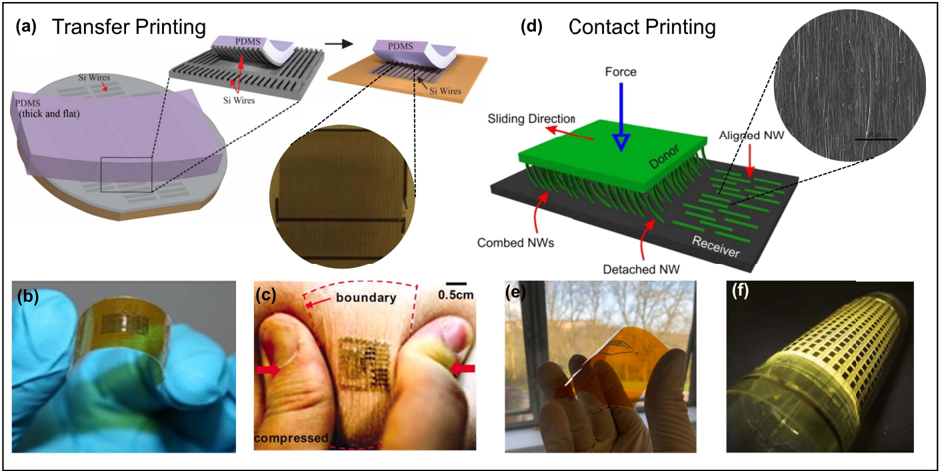





Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“In particular, when e-skin tactile sensing communicates harmful external stimuli to the user, soft robotics can utilize its flexibility and high degree of freedom to efficiently move away and adapt to the scenario.[19,36]”
From Flexible Electronics and Devices as Human–Machine Interfaces for Medical Robotics (2022) · cites this paper as [36]
Experimental — accuracy not yet measured
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Kim, D.-H., Lu, N., Ma, R., Kim, Y.-S., Kim, R.-H., Wang, S., Wu, J., Won, S. M., Tao, H., Islam, A., et al. (2011) · Science · doi:10.1126/science.1206157 · Cited by 4,836 · cited 1×
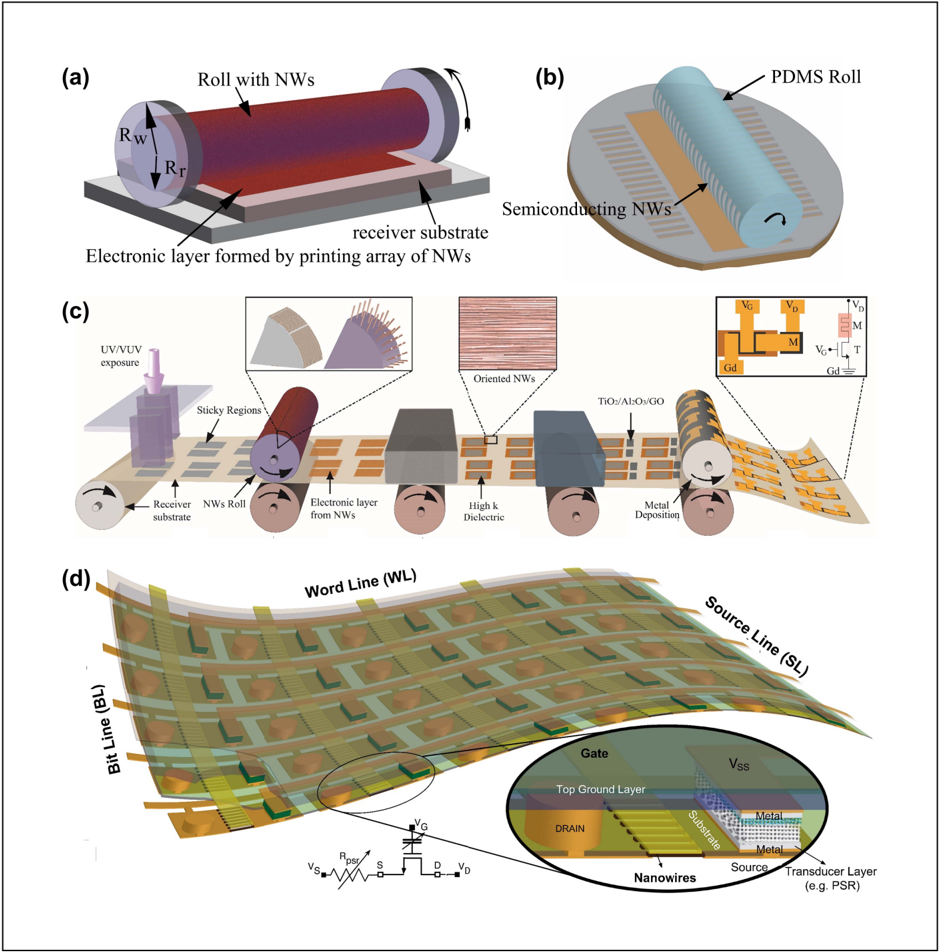
“The transfer printing of multiple types of materials opens interesting avenues for hybrid integrated systems, which is an ideal testbed for e-skin [30], [148], [160].”
Nanoscale Memristor Device as Synapse in Neuromorphic Systems
Jo, S. H., Chang, T., Ebong, I., Bhadviya, B. B., Mazumder, P., & Lu, W. (2010) · Nano Letters · doi:10.1021/nl904092h · Cited by 4,174 · cited 1×
“…hardware neuromorphic architecture implementations reported in the literature are based on devices such as memristor [90], spin logic [91], [92], memristor [93], neuron MOSFET [88], [94], analog circuit-based neurons [95], field-programmable gate array (FPGA) [75], and software-programmed NNs [96].”
WIDROW, B., & HOFF, M. E. (1960) · doi:10.21236/ad0241531 · Cited by 4,009
Memristive devices for computing
Yang, J. J., Strukov, D. B., & Stewart, D. R. (2013) · Nature Nanotechnology · doi:10.1038/nnano.2012.240 · Cited by 3,885 · cited 1×
“Recently, two-terminal memristive devices have gained attention as the state of their internal resistance could indicate the history of the voltage across and/or current through them [97]–[99].”
Highly sensitive flexible pressure sensors with microstructured rubber dielectric layers
Mannsfeld, S. C. B., Tee, B. C.-K., Stoltenberg, R. M., Chen, C. V. H.-H., Barman, S., Muir, B. V. O., Sokolov, A. N., Reese, C., & Bao, Z. (2010) · Nature Materials · doi:10.1038/nmat2834 · Cited by 3,291 · cited 2×
“[39] S.”
Skin-like pressure and strain sensors based on transparent elastic films of carbon nanotubes
Lipomi, D. J., Vosgueritchian, M., Tee, B. C.-K., Hellstrom, S. L., Lee, J. A., Fox, C. H., & Bao, Z. (2011) · Nature Nanotechnology · doi:10.1038/nnano.2011.184 · Cited by 3,188 · cited 2×
“The transfer printing approach has also been used for nonsilicon material such as carbon-based low-dimensional material [graphene and carbon nanotube (CNT)] [153]–[155], transition metal dichalcogenide monolayer (MoS2, WS2, etc.”
An ultra-lightweight design for imperceptible plastic electronics
Kaltenbrunner, M., Sekitani, T., Reeder, J., Yokota, T., Kuribara, K., Tokuhara, T., Drack, M., Schwödiauer, R., Graz, I., Bauer-Gogonea, S., et al. (2013) · Nature · doi:10.1038/nature12314 · Cited by 2,485 · cited 1×
“[173] M.”
Multiplexed electrical detection of cancer markers with nanowire sensor arrays
Zheng, G., Patolsky, F., Cui, Y., Wang, W. U., & Lieber, C. M. (2005) · Nature Biotechnology · doi:10.1038/nbt1138 · Cited by 2,436
Hammock, M. L., Chortos, A., Tee, B. C. ‐., Tok, J. B. ‐., & Bao, Z. (2013) · Advanced Materials · doi:10.1002/adma.201302240 · Cited by 2,396 · cited 4×
“There have been other surveys that discussed various types of tactile sensors and some of the issues related to the effective utilization of tactile sensing [9]–[11].”
InfluentialInkjet Printing—Process and Its Applications
Singh, M., Haverinen, H. M., Dhagat, P., & Jabbour, G. E. (2010) · Advanced Materials · doi:10.1002/adma.200901141 · Cited by 2,375
Research works printed but not linked: 4
- 70. A. C. W. Wong, D. McDonagh, O. Omeni, C. Nunn, 2030 PROCEEDINGS OF THE IEEE | Vol. 107, No. 10, October 2019
- 12. S. Standring, Gray's Anatomy e-Book: The Anatomical Basis of Clinical Practice. Amsterdam, The Netherlands: Elsevier Health Sciences, 2015.
- 13. R. S. Dahiya, G. Metta, M. Valle, A. Adami, and L. Lorenzelli, "Piezoelectric oxide semiconductor field effect transistor touch sensing devices," Appl. Phys. Lett., vol. 95, no. 3, 2009, Art. no. 034105. · DOI · Paper page
- 18. R. S. Dahiya and M. Gori, "Probing with and into fingerprints," J. Neurophysiol., vol. 104, no. 1, pp. 1-3, 2010.
Cited by
Items 101–200 of 309
Toward all flexible sensing systems for next-generation wearables
Liu, F., & Lorenzelli, L. (2024) · Wearable electronics. · doi:10.1016/j.wees.2024.07.003 · Cited by 40
Self-citationA flexible chip with embedded intelligence
Liu, F., Dahiya, A. S., & Dahiya, R. (2020) · Nature Electronics · doi:10.1038/s41928-020-0446-4 · Cited by 30
Self-citationBio‐Inspired Large‐Area Soft Sensing Skins to Measure UAV Wing Deformation in Flight
Shin, H., Ott, Z., Beuken, L. G., Ranganathan, B. N., Humbert, J. S., & Bergbreiter, S. (2021) · Advanced Functional Materials · doi:10.1002/adfm.202100679 · Cited by 31
Christou, A., Liu, F., & Dahiya, R. (2021) · Microsystems & Nanoengineering · doi:10.1038/s41378-021-00314-6 · Cited by 32
Self-citationLuo, S., Lepora, N. F., Yuan, W., Althoefer, K. A., Cheng, G., & Dahiya, R. (2025) · IEEE Transactions on Robotics · doi:10.1109/tro.2025.3608686 · Cited by 67
Self-citationTouch Modality Classification Using Recurrent Neural Networks
Alameh, M., Abbass, Y., Ibrahim, A., Moser, G., & Valle, M. (2021) · IEEE Sensors Journal · doi:10.1109/jsen.2021.3055565 · Cited by 32
High-performance p-channel transistors on flexible substrate using direct roll transfer stamping
Zumeit, A., Dahiya, A. S., Christou, A., & Dahiya, R. (2021) · Japanese Journal of Applied Physics · doi:10.35848/1347-4065/ac40ab · Cited by 30
Self-citationAgar-based soft tactile transducer with embedded optical fiber specklegram sensor
Fujiwara, E., & Rosa, L. O. (2022) · Results in Optics · doi:10.1016/j.rio.2022.100345 · Cited by 33
Adaptive Optimal Measurement Algorithm for ERT-Based Large-Area Tactile Sensors
Park, K., Lee, H., Kuchenbecker, K. J., & Kim, J. (2021) · IEEE/ASME Transactions on Mechatronics · doi:10.1109/tmech.2021.3063414 · Cited by 30
On‐Skin Stimulation Devices for Haptic Feedback and Human–Machine Interfaces
Guo, W., Hu, Y., Yin, Z., & Wu, H. (2021) · Advanced Materials Technologies · doi:10.1002/admt.202100452 · Cited by 35
A novel MXene-based high-performance flexible pressure sensor for detection of human motion
Zhang, Z., Zhang, Q., Zhang, H., Li, B., Zang, J., Zhao, X., Zhao, X., & Xue, C. (2023) · Smart Materials and Structures · doi:10.1088/1361-665x/accee9 · Cited by 30
MnOx-Electrodeposited Fabric-Based Stretchable Supercapacitors with Intrinsic Strain Sensing
Pullanchiyodan, A., Manjakkal, L., Ntagios, M., & Dahiya, R. (2021) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.1c12526 · Cited by 28
Self-citationA Flexible, Large-Scale Sensing Array with Low-Power In-Sensor Intelligence
Xu, Z., Zhang, F., Xie, E., Hou, C., Yin, L., Liu, H., Yin, M., Yin, L., Liu, X., & Huang, Y. (2024) · Research · doi:10.34133/research.0497 · Cited by 30
See to touch: Learning tactile dexterity through visual incentives
Guzey, I., Dai, Y., Evans, B., Chintala, S., & Pinto, L. (2024) · 2024 IEEE International Conference on Robotics and Automation (ICRA) · doi:10.1109/icra57147.2024.10611407 · Cited by 26
Next generation legged robot locomotion: A review on control techniques
Kotha, S. S., Akter, N., Abhi, S. H., Das, S. K., Islam, M. R., Ali, M. F., Ahamed, M. H., Islam, M. M., Sarker, S. K., Badal, F. R., et al. (2024) · Heliyon · doi:10.1016/j.heliyon.2024.e37237 · Cited by 49
3D Touch Surface for Interactive Pseudo‐Holographic Displays
Christou, A., Gao, Y., Navaraj, W. T., Nassar, H., & Dahiya, R. (2020) · Advanced Intelligent Systems · doi:10.1002/aisy.202000126 · Cited by 26
Self-citationDeep Active Cross-Modal Visuo-Tactile Transfer Learning for Robotic Object Recognition
Murali, P. K., Wang, C., Lee, D., Dahiya, R., & Kaboli, M. (2022) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2022.3191408 · Cited by 32
Self-citationDotView: A Low-Cost Compact Tactile Sensor for Pressure, Shear, and Torsion Estimation
Zheng, H., Jin, Y., Wang, H., & Zhao, P. (2023) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2022.3233784 · Cited by 26
Polydimethylsiloxane as polymeric protective coating for fabrication of ultra-thin chips
Gupta, S., Vilouras, A., & Dahiya, R. (2019) · Microelectronic Engineering · doi:10.1016/j.mee.2019.111157 · Cited by 28
Self-citationPrinted Interconnects for Heterogeneous Systems Integration on Flexible Substrates
Dahiya, A. S., Christou, A., Ma, S., & Dahiya, R. (2024) · Advanced Materials Technologies · doi:10.1002/admt.202401213 · Cited by 29
Self-citationAn Atlas for the Inkjet Printing of Large-Area Tactile Sensors
Baldini, G., Albini, A., Maiolino, P., & Cannata, G. (2022) · Sensors · doi:10.3390/s22062332 · Cited by 25
Küçükdeğer, E., Tong, Y., Singh, M., Zhang, J., Harding, L. K., Salado, A., Ellingson, S. W., & Johnson, B. N. (2021) · Flexible and Printed Electronics · doi:10.1088/2058-8585/ac28f1 · Cited by 25
Recent progress on supercapacitive performance of agrowaste fibers: a review
Subramaniam, T., Krishnan, S. G., Ansari, M. N. M., Hamid, N. A., & Khalid, M. (2022) · Critical reviews in solid state and materials sciences/CRC critical reviews in solid state and materials sciences · doi:10.1080/10408436.2022.2052797 · Cited by 23
Neto, J., Dahiya, A. S., Zumeit, A., Christou, A., Ma, S., & Dahiya, R. (2023) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.2c20569 · Cited by 25
Self-citationSelf‐Powered Multimodal Sensing Using Energy‐Generating Solar Skin for Robotics and Smart Wearables
Chirila, R., Dahiya, A. S., Schyns, P. G., & Dahiya, R. (2024) · Advanced Intelligent Systems · doi:10.1002/aisy.202300824 · Cited by 22
Self-citationFlexible Strain Sensor with NFC Tag for Food Packaging
Escobedo, P., Bhattacharjee, M., Nikbakhtnasrabadi, F., & Dahiya, R. (2020) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps49123.2020.9239568 · Cited by 22
Self-citationIntelligent sensory systems toward soft robotics
Luo, Z., Cheng, W., Zhao, T., & Xiang, N. (2024) · Applied Materials Today · doi:10.1016/j.apmt.2024.102122 · Cited by 29
Kumaresan, Y., Ozioko, O., & Dahiya, R. (2020) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps49123.2020.9239583 · Cited by 20
Self-citationHealing and monitoring of chronic wounds: advances in wearable technologies
Hosseini, E. S., Bhattacharjee, M., Manjakkal, L., & Dahiya, R. (2021) · Elsevier eBooks · doi:10.1016/b978-0-12-818914-6.00014-4 · Cited by 24
Self-citationPseudo‐Hologram with Aerohaptic Feedback for Interactive Volumetric Displays
Christou, A., Chirila, R., & Dahiya, R. (2021) · Advanced Intelligent Systems · doi:10.1002/aisy.202100090 · Cited by 24
Self-citationRobotSweater: Scalable, Generalizable, and Customizable Machine-Knitted Tactile Skins for Robots
Si, Z., Yu, T. C., Morozov, K., McCann, J., & Yuan, W. (2023) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra48891.2023.10161321 · Cited by 36
Printing semiconductor-based devices and circuits for flexible electronic skin
Dahiya, A. S., Zumeit, A., Christou, A., Loch, A. S., Purushothaman, B., Skabara, P. J., & Dahiya, R. (2024) · Applied Physics Reviews · doi:10.1063/5.0217297 · Cited by 21
Self-citationA study on a broadband photodetector based on hybrid 2D copper oxide/reduced graphene oxide
Ngo, D. A., Nguyen, N. M., Tran, C. K., Tran, T. T. V., Tran, N. H. T., Bui, T. T. T., Duy, L. T., & Dang, V. Q. (2024) · Nanoscale Advances · doi:10.1039/d3na00796k · Cited by 21
Leather-based printed tactile sensor array for robotic interactive skin
Zhang, B., Meng, W., Cheng, G., Zhao, F., Tang, T., Gong, Y., Lin, J., He, G., Yuan, J., Peng, Z., et al. (2024) · Nano Energy · doi:10.1016/j.nanoen.2024.110379 · Cited by 19
Metal Coated Fabric Based Asymmetric Supercapacitor for Wearable Applications
Pullanchiyodan, A., Manjakkal, L., & Dahiya, R. (2021) · IEEE Sensors Journal · doi:10.1109/jsen.2021.3058894 · Cited by 18
Self-citationAlN Ultra-Thin Chips Based Flexible Piezoelectric Tactile Sensors
Kumaresan, Y., Ma, S., Shakthivel, D., & Dahiya, R. (2021) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps51544.2021.9469763 · Cited by 19
Self-citationAn ultra-thin transparent multi-functional sensor based on silk hydrogel for health monitoring
Qiu, Y. F., Wang, Y.-L., Tang, W., Wu, T., Huang, P., Qian, Y. X., Xu, L. J., & Zhang, X. (2022) · Journal of Micromechanics and Microengineering · doi:10.1088/1361-6439/ac7b0c · Cited by 17
FlexiCores: low footprint, high yield, field reprogrammable flexible microprocessors
Bleier, N., Lee, C., Rodríguez, F. J., Sou, A., White, S., & Kumar, R. (2022) · Proceedings - International Symposium on Computer Architecture/Proceedings · doi:10.1145/3470496.3527410 · Cited by 28
3D Printed Robotic Hand with Embedded Touch Sensors
Ntagios, M., Escobedo, P., & Dahiya, R. (2020) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps49123.2020.9239587 · Cited by 16
Self-citationKim, H., Choi, S.-D., Lee, B., Seo, J., Lee, S., Yoon, J., & Hong, Y. (2022) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.2c16929 · Cited by 15
Wang, Y., Luo, Z., Zheng, Z., Ye, X., Xue, G., Qian, Y., & Chen, L. (2023) · Small · doi:10.1002/smll.202309498 · Cited by 15
Large-Area 3D Printable Soft Electronic Skin for Biomedical Applications
Roy, A. C., Kumar, N., Subramanya, S. B., Gupta, A. S., Kumar, A., Bid, A., & Venkataraman, V. (2022) · ACS Biomaterials Science & Engineering · doi:10.1021/acsbiomaterials.2c00241 · Cited by 17
Leslie, O., Bulens, D. C., Ulloa, P. M., & Redmond, S. J. (2023) · IEEE Sensors Journal · doi:10.1109/jsen.2023.3293967 · Cited by 14
Pamphilis, L. D., Ma, S., Dahiya, A. S., Christou, A., & Dahiya, R. (2024) · ACS Applied Materials & Interfaces · doi:10.1021/acsami.4c07172 · Cited by 14
Self-citationUltra-Thin Chips With ISFET Array for Continuous Monitoring of Body Fluids Ph
Baghini, M. S., Vilouras, A., & Dahiya, R. (2021) · IEEE Transactions on Biomedical Circuits and Systems · doi:10.1109/tbcas.2022.3141553 · Cited by 13
Self-citationda Costa, A. C. P. R., Filosa, M., Soares, A. B., & Oddo, C. M. (2025) · Nature Machine Intelligence · doi:10.1038/s42256-025-01076-w · Cited by 13
AI-enabled flexible electronic systems via near-sensor and in-sensor computing
Xu, Z., Xie, E., Hou, C., Bai, Y., He, W., Liu, X., Zhang, F., & Huang, Y. (2026) · npj Flexible Electronics · doi:10.1038/s41528-026-00544-6 · Cited by 16
Triboelectric encoders for accurate and durable wearable motion sensing
Wang, T., Li, C., Gao, Z., Wang, Z., Min, G., Wang, W. K., Shang, Y., & Tang, W. (2024) · Device · doi:10.1016/j.device.2024.100525 · Cited by 12
A wide range self-powered flexible pressure sensor based on triboelectric nanogenerator
Min, G., Dahiya, A. S., Mulvihill, D. M., & Dahiya, R. (2021) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps51544.2021.9469759 · Cited by 12
Self-citationPredictive Learning of Error Recovery with a Sensorized Passivity‐Based Soft Anthropomorphic Hand
Gilday, K., Thuruthel, T. G., & Iida, F. (2023) · Advanced Intelligent Systems · doi:10.1002/aisy.202200390 · Cited by 17
Yuan, S., Tian, Y., Li, Y., Li, S., Fu, L., Li, T., & Zhang, T. (2024) · Journal of Materials Chemistry C · doi:10.1039/d3tc04104b · Cited by 11
Yang, M. J., Chung, H., Kim, Y., Park, K., & Kim, J. (2024) · IEEE Transactions on Robotics · doi:10.1109/tro.2024.3502204 · Cited by 13
Uniform Deposition of Particles in Large Scale by Drying of Binary Droplets
Jiang, Z., Tao, L., Yang, X., Doi, M., Xu, Y., & Man, X. (2025) · Small · doi:10.1002/smll.202501549 · Cited by 11
A Large Area Robotic Skin with Sparsely Embedded Microphones for Human-Robot Tactile Communication
Yang, M. J., Park, K., & Kim, J. (2021) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra48506.2021.9561898 · Cited by 12
Robust Detection of Absence of Slip in Robot Hands and Feet
Massalim, Y., Kappassov, Z., Varol, H. A., & Hayward, V. (2021) · IEEE Sensors Journal · doi:10.1109/jsen.2021.3127501 · Cited by 11
Triboelectric Contact Localization Electronics: A Systematic Review
Xu, W. K., Ren, Q., Li, J., Xu, J., Bai, G., Zhu, C., & Li, W. (2024) · Sensors · doi:10.3390/s24020449 · Cited by 11
Morath, H. P. E., An, X., Jobst, M., Cui, M., Wagner, J., Mayr, C., & Ellinger, F. (2024) · IEEE Access · doi:10.1109/access.2024.3478850 · Cited by 12
Electrical Impedance Tomography Based Finger-Shaped Soft Artificial Skin
Huang, Y., & Thuruthel, T. G. (2025) · IEEE Robotics and Automation Letters · doi:10.1109/lra.2025.3557297 · Cited by 10
Self‐Adaptive, Untethered Soft Gripper System for Efficient Agricultural Harvesting
Zhao, Y., Zhao, W., Song, M., Jin, Y., Liu, Z., Islam, S., Liu, X., & Cao, C. C. (2025) · Journal of Field Robotics · doi:10.1002/rob.70013 · Cited by 15
Touch in Human Social Robot Interaction: Systematic Literature Review with PRISMA Method
Tsirka, C., Velentza, A.-M., & Fachantidis, N. (2025) · International Journal of Social Robotics · doi:10.1007/s12369-025-01319-1 · Cited by 10
Soft Sensors for Electronic Skin
Dahiya, A. S., Kumaresan, Y., Ozioko, O., Ntagios, M., & Dahiya, R. (2021) · Elsevier eBooks · doi:10.1016/b978-0-12-822548-6.00069-8 · Cited by 12
Self-citationShared visuo-tactile interactive perception for robust object pose estimation
Murali, P. K., Porr, B., & Kaboli, M. (2024) · The International Journal of Robotics Research · doi:10.1177/02783649241301443 · Cited by 19
Multi-gate neuron-like transistors based on ensembles of aligned nanowires on flexible substrates
Neto, J., Dahiya, A. S., & Dahiya, R. (2025) · Nano Convergence · doi:10.1186/s40580-024-00472-z · Cited by 13
Self-citationNanowires-Based Stretchable Strain Sensor for Wearable Applications
Shakthivel, D., Nair, N. M., & Dahiya, R. (2023) · IEEE Sensors Letters · doi:10.1109/lsens.2023.3281429 · Cited by 10
Self-citationAn Active Strategy for Safe Human–Robot Interaction Based on Visual–Tactile Perception
Xu, C., Zhou, Y., He, B., Wang, Z., Zhang, C., Sang, H., & Liu, H. (2023) · IEEE Systems Journal · doi:10.1109/jsyst.2023.3317328 · Cited by 10
A Non-Array Type Cut to Shape Soft Slip Detection Sensor Applicable to Arbitrary Surface
Kim, S. J., Lee, S. H., Moon, H., Choi, H. R., & Koo, J. C. (2020) · Sensors · doi:10.3390/s20216185 · Cited by 11
Glycine-based Flexible Biocompatible Piezoelectric Pressure Sensor for Healthcare Applications
Hosseini, E. S., Manjakkal, L., Shakthivel, D., & Dahiya, R. (2020) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps49123.2020.9239575 · Cited by 9
Self-citation3D Printed Capacitive Pressure Sensing Sole for Anthropomorphic Robots
Ntagios, M., Dervin, S., & Dahiya, R. (2021) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps51544.2021.9469839 · Cited by 9
Self-citationShao, C., Hirano, H., Miyaguchi, H., Nomoto, M., Muroyama, M., & Tanaka, S. (2020) · IEEE Sensors Journal · doi:10.1109/jsen.2020.2991259 · Cited by 9
Soft Sensing Skins for Arbitrary Objects: An Automatic Framework
Groß, S., Hidalgo-Carvajal, D., Breimann, S., Stein, N., Ganguly, A., Naceri, A., & Haddadin, S. (2023) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra48891.2023.10161344 · Cited by 12
Ultra-Thin Chips with Current-Mode ISFET Array for Continuous Monitoring of Body Fluids pH
Vilouras, A., & Dahiya, R. (2021) · IEEE International Symposium on Circuits and Systems proceedings · doi:10.1109/iscas51556.2021.9401616 · Cited by 8
Self-citationHighly Sensitive Flexible Capacitive Pressure Sensor with ZnO NW interlayers
Ma, S., Kumaresan, Y., Ozioko, O., & Dahiya, R. (2021) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps51544.2021.9469704 · Cited by 8
Self-citationZahertar, S., Tao, R., Wang, H., Torun, H., Canyelles-Pericas, P., Liu, Y., Vernon, J., Ng, W. P., Binns, R., Fu, Y., et al. (2022) · IEEE Sensors Journal · doi:10.1109/jsen.2022.3160282 · Cited by 8
Memon, A. W., Malengier, B., Torre, P. V., & Langenhove, L. V. (2023) · Sensors · doi:10.3390/s23218946 · Cited by 6
High Resolution, Large Area Vision-Based Tactile Sensing Based on a Novel Piezoluminescent Skin
Jiang, R., Fu, L., Li, Y., & Godaba, H. (2025) · IEEE Transactions on Robotics · doi:10.1109/tro.2025.3552327 · Cited by 7
Tu, X., Zhao, Q., Liu, Z., Li, D., Huang, T., Chen, G., Chen, Z., & Luo, W. (2025) · IEEE Sensors Journal · doi:10.1109/jsen.2025.3572787 · Cited by 7
Cha, L., Groß, S., Mao, S., Braun, T., Haddadin, S., & He, L. (2025) · IEEE International Conference on Soft Robotics (RoboSoft) · doi:10.1109/robosoft63089.2025.11020898 · Cited by 7
Gao, T., Jia, S., Wang, J., Cai, Y., Zhang, H., Jiang, H., Huang, Z., & Qu, J. (2022) · Composites Science and Technology · doi:10.1016/j.compscitech.2022.109733 · Cited by 7
Chen, H., Yang, X., Ma, G., Wang, Y., & Wang, X. (2024) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra57147.2024.10610215 · Cited by 7
Biodegradable Amino acid-based Pressure Sensor
Hosseini, E. S., & Dahiya, R. (2020) · Proceedings of IEEE Sensors/Proceedings of IEEE Sensors ... · doi:10.1109/sensors47125.2020.9278878 · Cited by 7
Self-citationLin, Y.-W., Efimovskaya, A., & Shkel, A. M. (2021) · Journal of Microelectromechanical Systems · doi:10.1109/jmems.2021.3109034 · Cited by 7
Murali, P. K., Dahiya, R., & Kaboli, M. (2022) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps53764.2022.9781598 · Cited by 7
Self-citationSkinCell: A Modular Tactile Sensor Patch for Physical Human–Robot Interaction
Zhang, R., Lin, J.-T., Olowo, O. O., Goulet, B., Harris, B. T., & Popa, D. O. (2022) · IEEE Sensors Journal · doi:10.1109/jsen.2022.3223320 · Cited by 7
Zhou, Y., Luo, Y., Yan, Z., Jin, Y., Jiang, S., Wang, Z., & He, B. (2024) · IEEE Sensors Journal · doi:10.1109/jsen.2024.3486921 · Cited by 6
Arita, H. (2023) · Advanced Robotics · doi:10.1080/01691864.2023.2239320 · Cited by 6
Toward soft robotic inspection for aircraft: An overview and perspective
Groo, L., Juhl, A. T., & Baldwin, L. A. (2024) · MRS Communications · doi:10.1557/s43579-024-00586-9 · Cited by 7
Advances in flexible ionic thermal sensors: present and perspectives
Zhao, Z., Shen, Y. H., Hu, R., & Xu, D. (2024) · Nanoscale · doi:10.1039/d4nr03423f · Cited by 6
Wearable Medical Devices: Application Status and Prospects
Wang, X., Gao, Y., Yuan, Y., Wang, Y., Liu, A., Jia, S., & Yang, W. (2025) · Micromachines · doi:10.3390/mi16040394 · Cited by 6
Li, F., Akiyama, Y., Wan, X., Okamoto, S., & Yamada, Y. (2021) · IEEE Access · doi:10.1109/access.2021.3138890 · Cited by 6
Artificial fast-adapting mechanoreceptor based on carbon nanotube percolating network
Bounakoff, C., Hayward, V., Genest, J., Michaud, F., & Beauvais, J. (2022) · Scientific Reports · doi:10.1038/s41598-021-04483-2 · Cited by 6
Real-Time Pressure Estimation and Localisation with Optical Tomography-inspired Soft Skin Sensors
Dawood, A. B., Denoun, B., & Althoefer, K. A. (2022) · IEEE International Conference on Soft Robotics (RoboSoft) · doi:10.1109/robosoft54090.2022.9762066 · Cited by 6
Design and Characterisation of a Soft Barometric Sensing Skin for Robotic Manipulation
Gilday, K., Relandeau, L., & Fumiya Iida, A. (2022) · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · doi:10.1109/iros47612.2022.9981855 · Cited by 6
Tactile sensory response prediction and design using virtual tests
Wang, Z.-P., Yao, H., See, H. H., Yang, W., Tee, B. C. K., & Liu, Z. (2023) · Sensors and Actuators A Physical · doi:10.1016/j.sna.2023.114571 · Cited by 6
Slepyan, A., & Thakor, N. V. (2020) · IEEE/RAS-EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob) · doi:10.1109/biorob49111.2020.9224353 · Cited by 6
Stretchable Systems: Materials, Technologies and Applications
Kumaresan, Y., Yogeswaran, N., Occhipinti, L. G., & Dahiya, R. (2021) · Cambridge University Press eBooks · doi:10.1017/9781108882330 · Cited by 5
Self-citationNanowire-Based Si-CMOS Devices
Mishra, R. K., Mishra, V., & Mishra, S. N. (2024) · Springer tracts in electrical and electronics engineering · doi:10.1007/978-981-97-4623-1_2 · Cited by 5
Wireless Powered Passive Resonant-Based Omnidirectional Sensing System in Human Cooperative Robots
Kumar, V., Parajuli, S., Awasthi, S., Sharma, V., Ranade, G., Gupta, A. K., & Thundat, T. G. (2024) · IEEE Sensors Letters · doi:10.1109/lsens.2024.3511348 · Cited by 5
Flexible Strain Sensor based on Printed LC Tank on Electrospun Piezoelectric Nanofibers
Nikbakhtnasrabadi, F., Hosseini, E. S., & Dahiya, R. (2021) · IEEE International Conference on Flexible and Printable Sensors and Systems (FLEPS) · doi:10.1109/fleps51544.2021.9469866 · Cited by 5
Self-citationTouch Classification on Robotic Skin using Multimodal Tactile Sensing Modules
Yang, M. J., Cho, J., Chung, H., Park, K., & Kim, J. (2023) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/icra48891.2023.10160400 · Cited by 6
Evaluation of a Finger Dummy with a Built-in Sensor System for Safety Assessment
Li, F. (2024) · IEEE/SICE International Symposium on System Integration (SII) · doi:10.1109/sii58957.2024.10417308 · Cited by 5
Metadata
- Authors
- Dahiya, R., Yogeswaran, N., Liu, F., Manjakkal, L., Burdet, E., Hayward, V., & Jörntell, H.
- Affiliations
- University of Glasgow (GB)
- Imperial College London (GB)
- Institute of Intelligent Systems and Robotics, Sorbonne University, Paris, France
- Lund University (SE)
- Venue
- Proceedings of the IEEE
- Published
- 2019-10
- Volume
- 107
- Issue
- 10
- Pages
- 2016-2033
- ISSN
- 0018-9219 (ISSN-L)
- 1558-2256
- OpenAlex
- W2977568232
- Cited by
- 309
- References
- 185
- Citations by year
- 2026: 25 · 2025: 26 · 2024: 48 · 2023: 37 · 2022: 50 · 2021: 64 · 2020: 55 · 2019: 4
- FWCI
- 15.27
- Type
- journal article
- Language
- en
- Open access
- hybrid
- doi.org
- Locations
- Proceedings of the IEEE (publishedVersion, cc-by)
- ENLIGHTEN (Jurnal Bimbingan dan Konseling Islam) (acceptedVersion, cc-by-sa)
- HAL (submittedVersion, other-oa)
- HAL (submittedVersion)
- Edinburgh Napier Research Repository (Edinburgh Napier University) (submittedVersion, other-oa)
- Funders
- Engineering and Physical Sciences Research Council (EP/M002527/1, EP/R029644/1)
- H2020 Future and Emerging Technologies (H2020-FETOPEN-2018-829186)
- Topics
- Physical Sciences › Engineering › Biomedical Engineering › Advanced Sensor and Energy Harvesting Materials
- Physical Sciences › Engineering › Biomedical Engineering › Soft Robotics and Applications
- Life Sciences › Neuroscience › Cognitive Neuroscience › Tactile and Sensory Interactions
- Keywords
- electronic skin, soft robotics, tactile sensing, haptics, large-area manufacturing, energy self-sufficiency, flexible electronics, prosthetics
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
