

Learning-Based Motion-Intention Prediction for End-Point Control of Upper-Limb-Assistive Robots
Open accessThe DOI matches its Crossref record; 44 of the 44 references it cites were found in a registry or an index.
Abstract
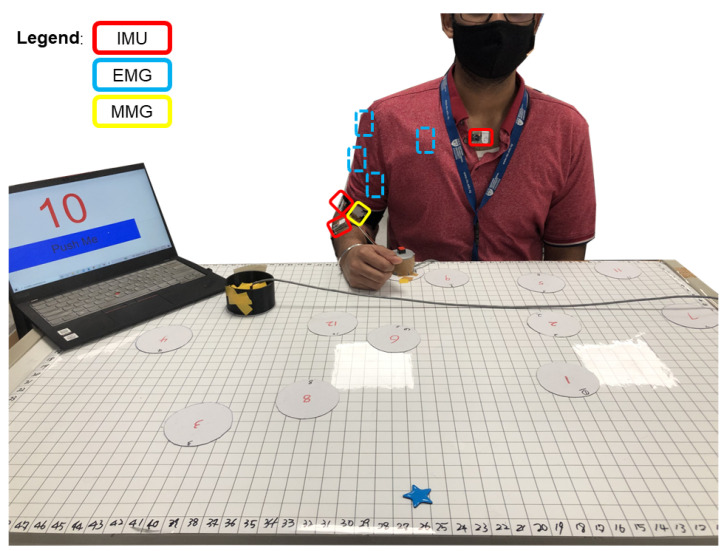
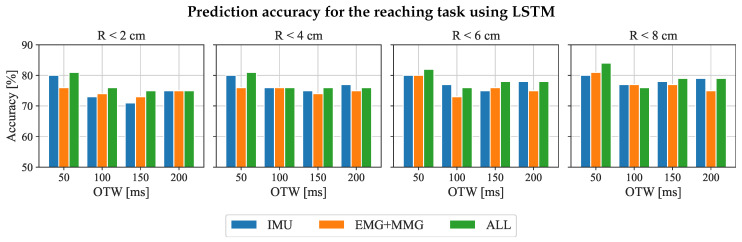
The lack of intuitive and active human–robot interaction makes it difficult to use upper-limb-assistive devices. In this paper, we propose a novel learning-based controller that intuitively uses onset motion to predict the desired end-point position for an assistive robot. A multi-modal sensing system comprising inertial measurement units (IMUs), electromyographic (EMG) sensors, and mechanomyography (MMG) sensors was implemented. This system was used to acquire kinematic and physiological signals during reaching and placing tasks performed by five healthy subjects. The onset motion data of each motion trial were extracted to input into traditional regression models and deep learning models for training and testing. The models can predict the position of the hand in planar space, which is the reference position for low-level position controllers. The results show that using IMU sensor with the proposed prediction model is sufficient for motion intention detection, which can provide almost the same prediction performance compared with adding EMG or MMG. Additionally, recurrent neural network (RNN)-based models can predict target positions over a short onset time window for reaching motions and are suitable for predicting targets over a longer horizon for placing tasks. This study’s detailed analysis can improve the usability of the assistive/rehabilitation robots.
Overview
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Integrity signals
Registry
Cites
Statistics
Figures




Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Free: it reads the open-access text and checks the first 5 claims that cite a source we can check. Create a free account to check every claim.
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Quinlan, J. R. (1986) · Machine Learning · doi:10.1007/bf00116251 · Cited by 21,439 · cited 1×
“Tree-based regression models enable one to build a tree-like structure for predicting the output [39].”
BackgroundDevelopment of recommendations for SEMG sensors and sensor placement procedures
Hermens, H. J., Freriks, B., Disselhorst-Klug, C., & Rau, G. (2000) · Journal of Electromyography and Kinesiology · doi:10.1016/s1050-6411(00)00027-4 · Cited by 7,213 · cited 1×
“Four EMG sensors (Delsys Trigno) were placed on the muscle belly of the biceps brachii (BB), triceps brachii (TB), anterior deltoid (AD), and pectoralis major (PM) following the SENIAM guidelines [33].”
MethodFeature reduction and selection for EMG signal classification
Phinyomark, A., Phukpattaranont, P., & Limsakul, C. (2012) · Expert Systems with Applications · doi:10.1016/j.eswa.2012.01.102 · Cited by 1,542
Upper-Limb Powered Exoskeleton Design
Perry, J. C., Rosen, J., & Burns, S. (2007) · IEEE/ASME Transactions on Mechatronics · doi:10.1109/tmech.2007.901934 · Cited by 1,023 · cited 1×
“Assistive robots such as exoskeletons [3] and intelligent prostheses [4] are designed to assist patients in daily activities and help to improve their quality of life [5].”
BackgroundActivity, participation, and quality of life 6 months poststroke
Mayo, N. E., Wood-Dauphinee, S., Côté, R., Durcan, L., & Carlton, J. (2002) · Archives of Physical Medicine and Rehabilitation · doi:10.1053/apmr.2002.33984 · Cited by 837 · cited 4×
“However, the common limitation of the mentioned studies is that prediction is limited to a single joint, which does not correspond to the full movement of the upper limb in ADLs.”
BackgroundInfluentialTSFEL: Time Series Feature Extraction Library
Barandas, M., Folgado, D., Fernandes, L., Santos, S., Abreu, M., Bota, P., Liu, H., Schultz, T., & Gamboa, H. (2020) · SoftwareX · doi:10.1016/j.softx.2020.100456 · Cited by 525 · cited 1×
“Hence, we want to approach more types of input features (such as from the time series feature extraction library [36]) to compare the performances of alternatives.”
Control of upper limb prostheses: terminology and proportional myoelectric control-a review
Fougner, A., Stavdahl, Ø., Kyberd, P. J., Losier, Y. G., & Parker, P. A. (2012) · IEEE Transactions on Neural Systems and Rehabilitation Engineering · doi:10.1109/tnsre.2012.2196711 · Cited by 495 · cited 1×
“They mainly measure the electrical activity of muscles, known as EMG signals [13], or the mechanical response of muscles, known as MMG signals [14].”
BackgroundTime series forecasting using artificial neural networks methodologies: A systematic review
Tealab, A. (2018) · Future Computing and Informatics Journal · doi:10.1016/j.fcij.2018.10.003 · Cited by 489
Bi, L., Feleke, A. >., & Guan, C. (2019) · Biomedical Signal Processing and Control · doi:10.1016/j.bspc.2019.02.011 · Cited by 418
Intention-Based EMG Control for Powered Exoskeletons
Lenzi, T., De Rossi, S. M. M., Vitiello, N., & Carrozza, M. C. (2012) · IEEE Transactions on Biomedical Engineering · doi:10.1109/tbme.2012.2198821 · Cited by 400
Research works printed but not linked: 2
- Johannes M.S. Bigelow J.D. Burck J.M. Harshbarger S.D. Kozlowski M.V. Van Doren T. An overview of the developmental process for the modular prosthetic limb Johns Hopkins APL Tech. Dig. 2011 30 207 216
- Tilley A.R. Henry Dreyfuss Associates. The Measure of Man and Woman: Human Factors in Design John Wiley & Sons Hoboken, NJ, USA 2001
Cited by
Lobo, P. L. S., Morais, P., Murray, P., & Vilaça, J. L. (2024) · Sensors · doi:10.3390/s24247973 · Cited by 53
Robotic-Assisted Rehabilitation for Post-Stroke Shoulder Pain: A Systematic Review
Gnasso, R., Palermi, S., Picone, A., Tarantino, D., Fusco, G., Messina, M. M., & Sirico, F. (2023) · Sensors · doi:10.3390/s23198239 · Cited by 26
“Moreover, these new technologies have already been tested for the rehabilitation of the shoulder, indicating how this complex articulation can benefit from such a new approach [8–10].”
BackgroundEMG feature extraction and muscle selection for continuous upper limb movement regression
Quesada, L., Verdel, D., Bruneau, O., Berret, B., Amorim, M., & Vignais, N. (2024) · Biomedical Signal Processing and Control · doi:10.1016/j.bspc.2024.107323 · Cited by 21
Learning Human-Arm Reaching Motion Using a Wearable Device in Human–Robot Collaboration
Kahanowich, N. D., & Sintov, A. (2024) · IEEE Access · doi:10.1109/access.2024.3365661 · Cited by 15
“In a work more related to ours, two IMU’s were combined with EMG and Mechanomyography (MMG) to predict future targets among several discrete ones [42].”
MethodChen, S., Peng, C., Yang, B., Lin, J., Zhou, L., Jiang, Z., Liu, Z., Liu, Y., & Tang, L. (2026) · npj Artificial Intelligence · doi:10.1038/s44387-026-00083-5 · Cited by 9
Metadata
- Authors
- Yang, S., Garg, N. P., Gao, R., Yuan, M., Noronha, B., Ang, W. T., & Accoto, D.
- Affiliations
- Nanyang Technological University (SG)
- KU Leuven (BE)
- Corresponding author
- Yang, Sibo
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2023-03-10
- Volume
- 23
- Issue
- 6
- Pages
- 2998
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC10056111
- OpenAlex
- W4323851676
- Cited by
- 20
- References
- 44
- Citations by year
- 2026: 5 · 2025: 3 · 2024: 5 · 2023: 7
- FWCI
- 1.58
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- Lirias (submittedVersion, cc-by)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- DR-NTU (Nanyang Technological University) (submittedVersion, cc-by)
- Funders
- “Intelligent Human–robot interface for upper limb wearable robots” (SERC1922500046)
- Topics
- Physical Sciences › Engineering › Biomedical Engineering › Prosthetics and Rehabilitation Robotics
- Physical Sciences › Engineering › Biomedical Engineering › Muscle activation and electromyography studies
- Health Sciences › Medicine › Rehabilitation › Stroke Rehabilitation and Recovery
- Keywords
- endpoint control, inertial measurement unit, electromyography, mechanomyography, multimodal sensing, recurrent neural networks, human-robot interaction, rehabilitation robots
- MeSH terms
- Electromyography, Humans, Motion, Robotics, Intention, Upper Extremity
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
How to cite
Cite CoChat for the checks on this page, and the paper for its own findings.
- This page
- CoChat. (2026). Citation check: Learning-Based Motion-Intention Prediction for End-Point Control of Upper-Limb-Assistive Robots. https://app.cochat.ai/papers/10.3390/s23062998
- The paper
- Yang, S., Garg, N. P., Gao, R., Yuan, M., Noronha, B., Ang, W. T., & Accoto, D. (2023). Learning-Based Motion-Intention Prediction for End-Point Control of Upper-Limb-Assistive Robots. Sensors. https://doi.org/10.3390/s23062998
Data sources
Bibliographic data: Semantic Scholar, OpenAlex, Crossref.
Contains information from the Semantic Scholar Academic Graph Datasets, made available under the ODC Attribution License (ODC-BY 1.0).
Semantic Scholar’s data is described in: Kinney, R., et al. (2023). The Semantic Scholar Open Data Platform. arXiv:2301.10140.
