

The DOI matches its Crossref record; 64 of the 64 references it cites were found in a registry or an index.
A Systematic Review of Perception System and Simulators for Autonomous Vehicles Research
Open accessAbstract
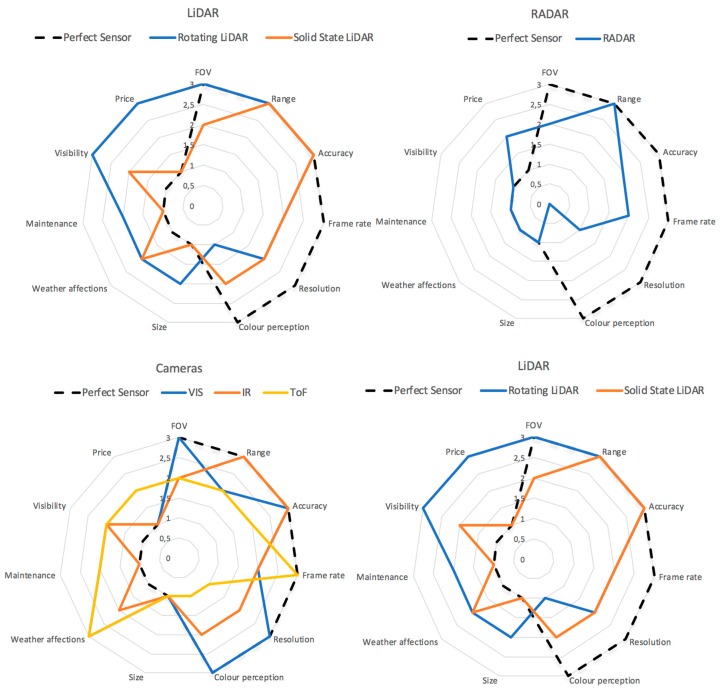
This paper presents a systematic review of the perception systems and simulators for autonomous vehicles (AV). This work has been divided into three parts. In the first part, perception systems are categorized as environment perception systems and positioning estimation systems. The paper presents the physical fundamentals, principle functioning, and electromagnetic spectrum used to operate the most common sensors used in perception systems (ultrasonic, RADAR, LiDAR, cameras, IMU, GNSS, RTK, etc.). Furthermore, their strengths and weaknesses are shown, and the quantification of their features using spider charts will allow proper selection of different sensors depending on 11 features. In the second part, the main elements to be taken into account in the simulation of a perception system of an AV are presented. For this purpose, the paper describes simulators for model-based development, the main game engines that can be used for simulation, simulators from the robotics field, and lastly simulators used specifically for AV. Finally, the current state of regulations that are being applied in different countries around the world on issues concerning the implementation of autonomous vehicles is presented.
Overview
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Integrity signals
Registry
Cites
Statistics
Figures
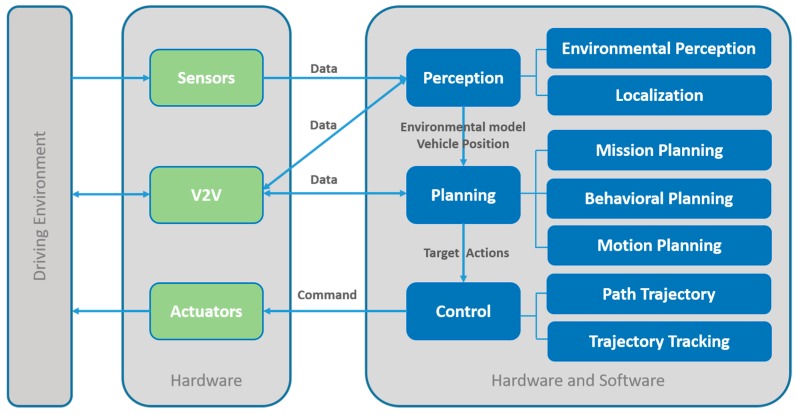
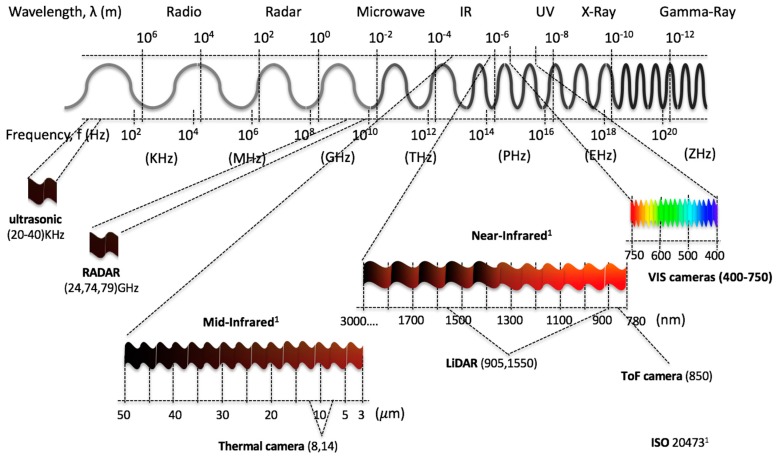
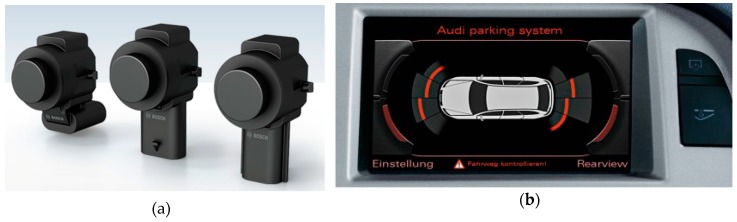
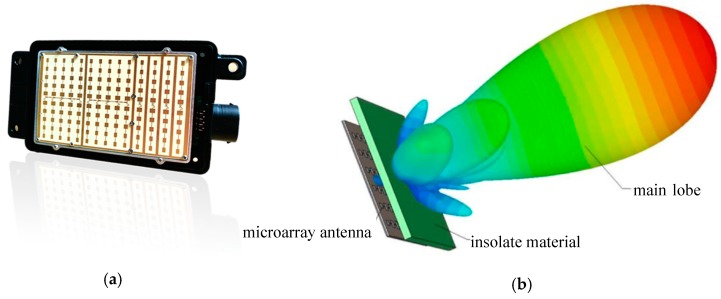
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“The Global Positioning System (GPS) is the most common GNSS system freely available to be used in any part of the world [111].”
From Sensor-Based Prognostic Health Management of Advanced Driver Assistance System for Autonomous Vehicles: A Recent Survey (2022) · cites this paper as [111]
Experimental — accuracy not yet measuredThe source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“It is mentioned that a pure vision-based system has advantages like affordability and simplicity of implementation.”
From Object Detection in Autonomous Vehicles under Adverse Weather: A Review of Traditional and Deep Learning Approaches (2024) · cites this paper as [48]
Experimental — accuracy not yet measuredThe source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Such simulation not only includes software simulation like CarSim and CARLA. but also includes hybrid realization with hardware-in-the-loop or vehicle-in-the-loop design [67].”
From Trustworthy AI: From Principles to Practices (2023) · cites this paper as [67]
Experimental — accuracy not yet measuredThe cited source says what the claim attributes to it.
In the citing paper
“Such simulation not only includes software simulation like CarSim and CARLA. but also includes hybrid realization with hardware-in-the-loop or vehicle-in-the-loop design [67].”
From Trustworthy AI: From Principles to Practices (2023) · cites this paper as [67]
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Vision meets robotics: The KITTI dataset
Geiger, A., Lenz, P., Stiller, C., & Urtasun, R. (2013) · The International Journal of Robotics Research · doi:10.1177/0278364913491297 · Cited by 9,913
Kalra, N., & Paddock, S. M. (2016) · Transportation Research Part A: Policy and Practice · doi:10.1016/j.tra.2016.09.010 · Cited by 1,221
A Review of Data Fusion Techniques
Castanedo, F. (2013) · The Scientific World Journal · doi:10.1155/2013/704504 · Cited by 1,027
Thermal cameras and applications: A survey
Gade, R., & Moeslund, T. B. (2014) · Machine Vision and Applications · doi:10.1007/s00138-013-0570-5 · Cited by 780
Challenges in autonomous vehicle testing and validation
Koopman, P., & Wagner, M. (2016) · SAE International Journal of Transportation Safety · doi:10.4271/2016-01-0128 · Cited by 675
USARSim: a robot simulator for research and education
Carpin, S., Lewis, M., Wang, J., Balakirsky, S. B., & Scrapper, C. (2007) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/robot.2007.363180 · Cited by 423
Pedestrian Detection at Day/Night Time with Visible and FIR Cameras: A Comparison
González, A., Fang, Z., Socarras, Y., Serrat, J., Vázquez, D., Xu, J., & López, A. M. (2016) · Sensors · doi:10.3390/s16060820 · Cited by 330
Bimbraw, K. (2015) · International Conference on Informatics in Control, Automation and Robotics (ICINCO) · doi:10.5220/0005540501910198 · Cited by 324
Development of Autonomous Car—Part I: Distributed System Architecture and Development Process
Jo, K., Kim, J., Kim, D., Jang, C., & Sunwoo, M. (2014) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2014.2321342 · Cited by 277
Development of advanced driver assistance systems with vehicle hardware-in-the-loop simulations
Gietelink, O. J., Ploeg, J., Schutter, B. D., & Verhaegen, M. (2006) · Vehicle System Dynamics · doi:10.1080/00423110600563338 · Cited by 272
Research works printed but not linked: 2
- Council, N.R. (2001). Statistics, Testing, and Defense Acquisition: New Approaches and Methodological Improvements, The National Academies Press.
- Dosovitskiy, A., Ros, G., Codevilla, F., Lopez, A., and Koltun, V. (arXiv, 2017). CARLA: An Open Urban Driving Simulator, arXiv.
Cited by
Sorted by citations
Items 201–300 of 469
Shawki, M., & Darweesh, M. S. (2020) · doi:10.1109/icm50269.2020.9331802 · Cited by 7
Validation of scenario-based virtual safety testing using low-cost sensor-based instrumented vehicle
Hong, C. J., Onn, L. K., Aparow, V. R., Amer, N. H., Peter, C. S. P., & Magaswaran, K. (2023) · JOURNAL OF MECHANICAL ENGINEERING AND SCIENCES · doi:10.15282/jmes.17.2.2023.10.0754 · Cited by 7
Investigating the Energetics of Electric Vehicles, based on Real Measurements
Tollner, D., & Zöldy, M. (2024) · Acta Polytechnica Hungarica · doi:10.12700/aph.21.7.2024.7.14 · Cited by 7
Maaiveld, T. M., Nyegaard, D. D. N., de Reus, N. M., Schadd, M. P. D., & Kuijper, F. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-71397-2_7 · Cited by 7
Burghardt, T. E., & Pashkevich, A. (2022) · Sustainable civil infrastructures · doi:10.1007/978-3-030-79801-7_49 · Cited by 7
Fuzzy Fusion of Stereo Vision, Odometer, and GPS for Tracking Land Vehicles
Villaseñor-Aguilar, M. J., Peralta-López, J. E., Lázaro-Mata, D., García-Alcalá, C. E., Padilla-Medina, J. A., Pérez-Pinal, F. J., Vázquez-López, J. A., & Gutiérrez, A. I. B. (2022) · Mathematics · doi:10.3390/math10122052 · Cited by 7
Performance of Autonomous Vehicles in Mixed Traffic under different Demand Conditions
Azam, M., Hassan, S. A., Puan, O. C., Azhari, S., & Faiz, R. U. (2022) · International Journal of Automotive and Mechanical Engineering · doi:10.15282/ijame.19.4.2022.02.0776 · Cited by 7
Compensating for Sensing Failures via Delegation in Human–AI Hybrid Systems
Fuchs, A., Passarella, A., & Conti, M. (2023) · Sensors · doi:10.3390/s23073409 · Cited by 7
Araghi, F. M., Rabinwoitz, A., Ang, C. C., Sharma, S., Kadav, P., Meyer, R. T., Bradley, T. H., & Asher, Z. D. (2023) · Springer eBooks · doi:10.1007/978-3-031-28016-0_27 · Cited by 7
A Review of Key Technologies for Environment Sensing in Driverless Vehicles
Huo, Y., & Zhang, C. (2024) · World Electric Vehicle Journal · doi:10.3390/wevj15070290 · Cited by 7
Xu, Z., Zheng, N., Fang, Y., & Vu, H. L. (2025) · Transportation Research Part C: Emerging Technologies · doi:10.1016/j.trc.2025.105367 · Cited by 6
Synthetic versus real: an analysis of critical scenarios for autonomous vehicle testing
Song, Q., Bensoussan, A., & Mousavi, M. R. (2025) · Automated Software Engineering · doi:10.1007/s10515-025-00499-4 · Cited by 6
Siddiqui, M. A. S., Rabbi, M. S., Islam, M. J., & Ahmed, R. U. (2025) · Journal of Advanced Transportation · doi:10.1155/atr/9995539 · Cited by 7
Testing the Fault-Tolerance of Multi-sensor Fusion Perception in Autonomous Driving Systems
Tian, H., Ding, W., Han, X., Wu, G., Guo, A., Zhang, J., Chen, W., Wei, J., & Zhang, T. (2025) · Proceedings of the ACM on software engineering. · doi:10.1145/3728910 · Cited by 8
Probabilistic context integration‐based aircraft behaviour intention classification at airport ramps
Lee, S., & Seo, S. (2022) · IET Intelligent Transport Systems · doi:10.1049/itr2.12167 · Cited by 6
SLAV-Sim: A Framework for Self-Learning Autonomous Vehicle Simulation
Crewe, J., Humnabadkar, A., Liu, Y., Ahmed, A. A., & Behera, A. (2023) · Sensors · doi:10.3390/s23208649 · Cited by 6
A Systematic Mapping of Autonomous Vehicle Prototypes: Trends and Opportunities
da Silva, E. L. R., Soares, F., de Souza, W. J., & de Freitas, H. C. (2024) · IEEE Transactions on Intelligent Vehicles · doi:10.1109/tiv.2024.3387394 · Cited by 6
Real-time path planning for autonomous vehicle off-road driving
Ramirez-Robles, E., Starostenko, O., & Alarcon‐Aquino, V. (2024) · PeerJ Computer Science · doi:10.7717/peerj-cs.2209 · Cited by 8
The Vulnerability-Adaptive Protection Paradigm
Wan, Z., Gan, Y., Bo, Y., Liu, S., Raychowdhury, A., & Zhu, Y. (2024) · Communications of the ACM · doi:10.1145/3647638 · Cited by 6
Effects of Dust and Moisture Surface Contaminants on Automotive Radar Sensor Frequencies
Kang, J., Oskar, H., Vanäs, K., Eidevåg, T., Nilsson, E., & Friel, R. J. (2025) · Sensors · doi:10.3390/s25072192 · Cited by 6
Ma, Y., Pan, X., Xiong, L., Xing, X., Bulut, S., & Chen, J. (2020) · COTA International Conference of Transportation Professionals (CICTP) · doi:10.1061/9780784483053.087 · Cited by 6
Towards Sensor Data Abstraction of Autonomous Vehicle Perception Systems
Reichert, H., Lang, L. F., Rösch, K., Bogdoll, D., Doll, K., Sick, B., Reuss, H.-C., Stiller, C., & Zöllner, J. M. (2021) · IEEE International Smart Cities Conference (ISC2) · doi:10.1109/isc253183.2021.9562912 · Cited by 6
Review of exteroceptive sensors for autonomous driving
Yahyaei, M., Seifert, G., Hempen, T., & Huber, W. (2022) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc55140.2022.9922379 · Cited by 6
HIL simulation of a self-stabilizing monorail vehicle
Griese, M., Mousavi, S. D., & Schulte, T. (2022) · Annual Conference of the IEEE Industrial Electronics Society (IECON) · doi:10.1109/iecon49645.2022.9968495 · Cited by 6
Kowol, P., Nowak, P., Banaś, W., Bagier, P., & Sciuto, G. L. (2023) · Journal of Intelligent & Robotic Systems · doi:10.1007/s10846-023-01824-3 · Cited by 6
Rojas, J. F., Kadav, P., Brown, N. E., Meyer, R., Bradley, T. H., & Asher, Z. D. (2023) · SAE technical papers on CD-ROM/SAE technical paper series · doi:10.4271/2023-01-0576 · Cited by 6
Schüβler, C., Hoffmann, M., Wirth, V., Eskofier, B., Weyrich, T., Stamminger, M., & Vossiek, M. (2023) · IEEE Radar Conference (RadarConf) · doi:10.1109/radarconf2351548.2023.10149641 · Cited by 6
Impact-aware Maneuver Decision with Enhanced Perception for Autonomous Vehicle
Liu, S., Xia, Y., Xu, C., Xie, J., Su, H., & Zheng, K. (2023) · IEEE International Conference on Data Engineering (ICDE) · doi:10.1109/icde55515.2023.00250 · Cited by 7
An Effective GNSS/PDR Fusion Positioning Algorithm on Smartphones for Challenging Scenarios
Zhang, J., Yu, B., Ge, Y., Gao, J., & Sheng, C. (2024) · Sensors · doi:10.3390/s24051452 · Cited by 8
Dual-Cockpit Human and Hardware-in-the-Loop Test Bench for Autonomous Vehicle Development
Garikapati, D., Liu, Y., Brown, M., Littlehale, T., Yamamoto, H., & Bao, C. (2024) · IEEE Transactions on Intelligent Vehicles · doi:10.1109/tiv.2024.3401086 · Cited by 6
Chatoux, H., Richard, N., Lecellier, F., & Fernández-Maloigne, C. (2019) · Journal of the Optical Society of America A · doi:10.1364/josaa.36.00c154 · Cited by 6
A Novel Asynchronous UWB Positioning System for Autonomous Trucks in an Automated Container Terminal
Wang, M., Zhou, A., Chen, X., Shen, Y., & Li, Z. (2020) · SAE International Journal of Advances and Current Practices in Mobility · doi:10.4271/2020-01-1026 · Cited by 6
Virtual Risk Assessment for the Deployment of Autonomous Shuttles
Weissensteiner, P., Stettinger, G., Tieber, K., & Rehrl, K. (2021) · Transportation Research Record Journal of the Transportation Research Board · doi:10.1177/03611981211025520 · Cited by 6
Modeling and State Estimation of Autonomous Vehicles in Signalized Intersections
Emamifar, M., & Ghoreishi, S. F. (2023) · ASCE International Conference on Transportation and Development (ICTD) · doi:10.1061/9780784484876.002 · Cited by 6
Modeling Sensing and Perception Errors towards Robust Decision Making in Autonomous VehiclesPreprint
Piazzoni, A., Cherian, J., Slavík, M., & Dauwels, J. (2020) · arXiv (Cornell University) · Cited by 6
Path planning methods for autonomous vehicles at intersections: A review
Vinayak, A., Zakaria, M. A., Younus, M., Peeie, M. H. B., & Ishak, M. I. (2025) · Multimodal Transportation · doi:10.1016/j.multra.2025.100286 · Cited by 5
VSim-AV: A Virtual Simulation Platform for Autonomous Vehicles
Meftah, L. H., & Braham, R. (2022) · Lecture notes in networks and systems · doi:10.1007/978-3-030-96308-8_35 · Cited by 5
Lane clearance approach for emergency vehicles in highways network
Khatri, A., & Mathi, S. (2022) · PLoS ONE · doi:10.1371/journal.pone.0276988 · Cited by 5
Modeling, Simulation, and Visualization of Agricultural and Field Robotic Systems
Steward, B. L., Tekeste, M. Z., Gai, J., & Tang, L. X. (2021) · Agriculture automation and control · doi:10.1007/978-3-030-70400-1_12 · Cited by 5
Kotov, D. (2022) · Applied Aspects of Information Technology · doi:10.15276/aait.05.2022.2 · Cited by 13
Otonom araç tasarımı için gerçek zamanlı benzetim ortamı mimarisi
Özçevik, Y., Solmaz, Ö., Baysal, E., & Ökten, M. (2023) · Gazi Üniversitesi Mühendislik-Mimarlık Fakültesi Dergisi · doi:10.17341/gazimmfd.1030482 · Cited by 5
Long term utilisation effect on vehicle battery performance
Tollner, D., & Zöldy, M. (2022) · IEEE International Conference on Cognitive Mobility (CogMob) · doi:10.1109/cogmob55547.2022.10118087 · Cited by 5
Pradeep, A., Bakoev, M., & Akhroljonova, N. (2023) · International Conference on Electronics, Computers and Artificial Intelligence (ECAI) · doi:10.1109/ecai58194.2023.10194188 · Cited by 5
An Empirically Grounded Path Forward for Scenario-Based Testing of Autonomous Driving Systems
Song, Q., Engström, E., & Runeson, P. (2024) · ACM Joint European Software Engineering Conference and Symposium on the Foundations of Software Engineering (ESEC/FSE) · doi:10.1145/3663529.3663843 · Cited by 5
On Perception Safety Requirements and Multi Sensor Systems for Automated Driving Systems
Cassel, A., Bergenhem, C., Christensen, O. M., Heyn, H.-M., Leadersson-Olsson, S., Majdandzic, M., Sun, P., Thorsen, A. C., & Tryggvesson, J. (2020) · SAE International Journal of Advances and Current Practices in Mobility · doi:10.4271/2020-01-0101 · Cited by 5
Redundant Multi-Object Detection for Autonomous Vehicles in Structured Environments
Feraco, S., Bonfitto, A., Amati, N., & Tonoli, A. (2021) · Communications - Scientific letters of the University of Zilina · doi:10.26552/com.c.2022.1.c1-c17 · Cited by 5
ARTSeg: Employing Attention for Thermal Images Semantic Segmentation
Munir, F., Azam, S., Fatima, U., & Jeon, M. (2022) · Lecture notes in computer science · doi:10.1007/978-3-031-02375-0_27 · Cited by 5
Digital Twin for Simulation and Evaluation of Assistive Navigation Systems
Diamantis, D. E., Kalozoumis, P. G., & Iakovidis, D. K. (2022) · Studies in systems, decision and control · doi:10.1007/978-3-030-96802-1_8 · Cited by 5
Ma, Z., VanDerPloeg, B., Bara, C.-P., Huang, Y., Kim, E.-I., Gervits, F., Marge, M., & Chai, J. Y. (2022) · Findings of the Association for Computational Linguistics: EMNLP (Findings of EMNLP) · doi:10.18653/v1/2022.findings-emnlp.354 · Cited by 6
GLADAS: Gesture Learning for Advanced Driver Assistance SystemsPreprint
Shaotran, E., Cruz, J. J., & Reddi, V. J. (2019) · arXiv (Cornell University) · doi:10.48550/arxiv.1910.04695 · Cited by 6
İlçi, V., Yavuz, M., ŞİŞMAN, Y., Par, K., & Peker, A. U. (2024) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2024.3408309 · Cited by 4
Antenna Placement in Compressive Sensing Radar using Binary Optimization
Hamida, A., Saif, M., Li, J., & Valaee, S. (2024) · IEEE Sensor Array and Multichannel Signal Processing Workshop (SAM) · doi:10.1109/sam60225.2024.10636555 · Cited by 4
Efficient Vision Transformers for Autonomous Off-Road Perception Systems
Faykus, M. H., Pickeral, A., Marquez, E., Smith, M. C., & Calhoun, J. C. (2024) · Journal of Computer and Communications · doi:10.4236/jcc.2024.129011 · Cited by 4
Optimized Right-Turn Pedestrian Collision Avoidance System Using Intersection LiDAR
Park, S., & Kee, S.-C. (2024) · World Electric Vehicle Journal · doi:10.3390/wevj15100452 · Cited by 4
Padhiary, M., Roy, P., & Kumar, K. (2025) · Recent Progress in Science and Engineering · doi:10.21926/rpse.2502006 · Cited by 4
Aloui, K. (2025) · Engineering Perspective · doi:10.64808/engineeringperspective.1760896 · Cited by 4
Comparative study of Automotive Sensor technologies used for Unmanned Driving
Rana, K., & Kaur, P. (2021) · International Conference on Computation, Automation and Knowledge Management (ICCAKM) · doi:10.1109/iccakm50778.2021.9357731 · Cited by 5
Identification of fog Particle Size Distribution by a radiative transfer equation inversion
Krayem, A., Bernardin, F., & Arnaud Münch, A. (2024) · Journal of Quantitative Spectroscopy and Radiative Transfer · doi:10.1016/j.jqsrt.2024.108923 · Cited by 4
The use of artificial intelligence in driver-in-the-loop simulation: a literature review (2023)
Dias, C., & Júnior, J. L. (2023) · Australian Journal of Mechanical Engineering · doi:10.1080/14484846.2023.2259709 · Cited by 4
Chelouati, M., Boussif, A., Beugin, J., & Koursi, E. M. E. (2023) · IEEE Access · doi:10.1109/access.2023.3347500 · Cited by 4
Abohassan, M., & El‐Basyouny, K. (2024) · Sensors · doi:10.3390/s24020452 · Cited by 4
Simulating sensor noise model for real-time testing in a virtual underwater environment
Deng, J., Filisetti, A., Lim, H. S., Kim, D. Y., & Al‐Hourani, A. (2024) · IEEE Annual Congress on Artificial Intelligence of Things (AIoT) · doi:10.1109/aiot63253.2024.00051 · Cited by 4
A Design Method for Road Vehicles with Autonomous Driving Control
Mao, C., He, Y., & Agelin‐Chaab, M. (2024) · Actuators · doi:10.3390/act13110427 · Cited by 4
A Survey of Simulation Tools for Cooperative Positioning in Autonomous Vehicles
Silva, I., da Silva, H. D. M., Botelho, F., & Pendão, C. (2024) · IEEE Access · doi:10.1109/access.2024.3508473 · Cited by 4
Peng, P., Geng, K., Yin, G., Lu, Y., Zhuang, W., & Liu, S. (2021) · Chinese Journal of Mechanical Engineering · doi:10.1186/s10033-021-00602-2 · Cited by 4
Aleksandrova, M. P., Dobrikov, G. H., Pathan, H. M., Sartale, S. D., & Videkov, V. H. (2021) · Materials Today Proceedings · doi:10.1016/j.matpr.2021.10.117 · Cited by 4
UAV-based Scenario Builder and Physical Testing platform for Autonomous Vehicles
Chilkunda, A., Nakama, S., Chilkunda, V., Pedro, D., Matos-Carvalho, J. P., & Campos, L. M. (2023) · Conference on Cloud and Internet of Things (CIoT) · doi:10.1109/ciot57267.2023.10084885 · Cited by 4
A ROS-Based Autonomous Vehicle Testbed for the Internet of Vehicles
Sarantinoudis, N., Tsinarakis, G. J., Doitsidis, L., Chatzichristofis, S. A., & Arampatzis, G. (2023) · International Conference on Distributed Computing in Smart Systems and the Internet of Things (DCOSS-IoT) · doi:10.1109/dcoss-iot58021.2023.00114 · Cited by 4
A systematic review of hardware technologies for small-scale self-driving cars
Caleffi, F., Rodrigues, L. D. S., Stamboroski, J. D. S., Rorig, B. V., Santos, M. M. C. D., Zuchetto, V., & Raguzzoni, Í. B. (2023) · Ciência e Natura · doi:10.5902/2179460x84071 · Cited by 4
Security challenges in autonomous vehicles: a case study of Camera and LiDAR sensors
Ghliss, M., Kechiche, L., & Chabir, K. (2024) · International Conference on Advanced Technologies for Signal and Image Processing · doi:10.1109/atsip62566.2024.10638971 · Cited by 5
Nobis, F., Brunhuber, F., Janssen, S., Betz, J., & Lienkamp, M. (2020) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc45102.2020.9294625 · Cited by 4
Modeling artificial agents’ actions in context – a deontic cognitive event ontology
Vacura, M. (2020) · Applied Ontology · doi:10.3233/ao-200236 · Cited by 4
Guia, J. M. D., Duraisamy, N., Opina, G., Tripathi, A., & Devaraj, M. (2022) · IEEE International Conference on Humanoid, Nanotechnology, Information Technology, Communication and Control, Environment, and Management (HNICEM) · doi:10.1109/hnicem57413.2022.10109513 · Cited by 4
Wang, D., Ding, S., Abdel-Aty, M. A., Barbour, N., Wang, Z., & Zheng, O. (2023) · Research Square · doi:10.21203/rs.3.rs-2824465/v1 · Cited by 4
Keshyagol, K., & Kulkarni, S. (2025) · Discover Sustainability · doi:10.1007/s43621-025-02310-6 · Cited by 3
Tami, M. A., Hasasneh, A., Ashqar, H. I., & Elhenawy, M. M. Z. (2026) · Safety Science · doi:10.1016/j.ssci.2026.107115 · Cited by 3
Conflict Judgment and Safety Assessment at Unsignalized Intersections Based on Machine Vision
Wang, Y., Wang, L., Zhu, R., Xu, Y., Jiang, G., & Ma, X. (2023) · Journal of Advanced Transportation · doi:10.1155/2023/6465225 · Cited by 3
A New Autonomous Navigation System of a Mobile Robot Using Supervised Learning
Abdouni, J., Jarou, T., Waga, A., koudia, Y. E., Idrissi, S. E., & Loumiti, S. (2023) · Studies in computational intelligence · doi:10.1007/978-3-031-37454-8_9 · Cited by 3
Simulation based Closed Loop Scenario Fuzzing for Safety Critical ADAS Applications
Agarkar, A. S., Gandhiraj, R., Panda, M., & Srivastava, S. (2023) · IEEE India Conference · doi:10.1109/indicon59947.2023.10440801 · Cited by 3
Simulating the Effects of Sensor Failures on Autonomous Vehicles for Safety Evaluation
Matos, F., Duraes, J. A., & Cunha, J. C. (2025) · Informatics · doi:10.3390/informatics12030094 · Cited by 3
A Unified Generative Framework for Realistic LiDAR Simulation in Autonomous Driving Systems
Haghighi, H., Wang, Y., Dianati, M., Debattista, K., & Donzella, V. (2025) · IEEE Sensors Journal · doi:10.1109/jsen.2025.3642208 · Cited by 3
Holen, M., Knausgård, K. M., & Goodwin, M. (2022) · Communications in computer and information science · doi:10.1007/978-3-031-10525-8_29 · Cited by 3
Hariz, F., Bouslimani, Y., & Ghribi, M. (2023) · IEEE Journal on Miniaturization for Air and Space Systems · doi:10.1109/jmass.2023.3240892 · Cited by 3
Autonomous Eco-Driving Evaluation of an Electric Vehicle on a Chassis Dynamometer
Motallebiaraghi, F., Rabinowitz, A. I., Rojas, J. F., Kadav, P., MILLER, D. A., Bradley, T. H., Meyer, R., & Asher, Z. D. (2023) · SAE technical papers on CD-ROM/SAE technical paper series · doi:10.4271/2023-01-0715 · Cited by 3
HIL Simulation of the Positioning Control for an Automated Driving Monorail Vehicle
Hanselle, R., Griese, M., Rasche, R., & Schulte, T. (2023) · IEEE International Conference on Industrial Informatics (INDIN) · doi:10.1109/indin51400.2023.10218259 · Cited by 3
Araújo, T. O., Netto, M. L., & Justo, J. F. (2023) · International Conference on Models and Technologies for Intelligent Transportation Systems (MT-ITS) · doi:10.1109/mt-its56129.2023.10241376 · Cited by 3
Cross-Scenario Maneuver Decision with Adaptive Perception for Autonomous Driving
Fu, Y., Liu, S., Xia, Y., Guo, F., & Zheng, K. (2023) · ACM International Conference on Information and Knowledge Management (CIKM) · doi:10.1145/3583780.3614831 · Cited by 3
Han, J.-Y., Park, J.-H., Kim, H.-J., & Lee, S. (2023) · Electronics · doi:10.3390/electronics12214505 · Cited by 3
Hybrid MPC and Spline-Based Controller for Lane Change Maneuvers in Autonomous Vehicles
Abdeselam, N., Gutiérrez-Moreno, R., López-Guillén, E., Barea, R., Montiel-Marín, S., & Bergasa, L. M. (2023) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc57777.2023.10421790 · Cited by 3
Song, Q., Anderberg, R., Olsson, H., & Runeson, P. (2024) · International Symposium on Software Engineering for Adaptive and Self-Managing Systems (SEAMS) · doi:10.1145/3643915.3644098 · Cited by 3
Li, Z., Meng, Q., Shen, Z., Wang, L., Li, L., & Jia, H. (2024) · Remote Sensing · doi:10.3390/rs16122176 · Cited by 5
EI-Drive: A Platform for Cooperative Perception With Realistic Communication Models
Zhou, H., Xie, E., Shao, W., Gao, D., Dong, M., & Zhang, J. (2025) · IEEE Internet of Things Journal · doi:10.1109/jiot.2025.3552554 · Cited by 3
Frame Rate Optimization in Traffic Sign Detection
Pratama, J. H., Handoko, H., & Yohanes, B. W. (2019) · International Conference on Cybernetics and Intelligent System (ICORIS) · doi:10.1109/icoris.2019.8874911 · Cited by 3
Analysis and Comparison of Datasets by Leveraging Data Distributions in Latent Spaces
Stage, H., Ries, L., Langner, J., Otten, S., & Sax, E. (2022) · Springer eBooks · doi:10.1007/978-3-031-01233-4_3 · Cited by 3
Elouaret, T., Colomer, S., de Melo, F., Cuperlier, N., Romain, O., Kessal, L., & Zuckerman, S. (2023) · Sensors · doi:10.3390/s23104631 · Cited by 3
Data Association between Perception and V2V Communication Sensors
Cantas, M. R., Chand, A., Zhang, H., Surnilla, G., & Güvenç, L. (2023) · SAE technical papers on CD-ROM/SAE technical paper series · doi:10.4271/2023-01-0856 · Cited by 3
Design and analysis of human assisting electric all-terrain vehicle
Jose, N., Nandakumar, N., Rajeev, R., Musthafa, M., & Harikrishnan, C. (2021) · AIP conference proceedings · doi:10.1063/5.0049970 · Cited by 3
Fouling and Cleaning of Transparent, Functional Coatings for Autonomous Vehicle Sensors
Peczonczyk, S. L., Misovski, T., Seubert, C., Peters, C. R., & Nichols, M. (2022) · SAE International Journal of Connected and Automated Vehicles · doi:10.4271/12-05-03-0018 · Cited by 3
AutoSCOOP: Automated Road-Side Sensor Coverage Optimization for Robotic Vehicles on Proving Grounds
Hermann, D. J., Martínez, C. M., Sayer, F., Hinz, G., & Knoll, A. (2022) · IEEE International Conference on Industrial Cyber-Physical Systems (ICPS) · doi:10.1109/icps51978.2022.9816927 · Cited by 3
Meltebrink, C., Komesker, M., Kelsch, C., König, D., Jenz, M., Strotdresch, M., Wegmann, B., Weltzien, C., & Ruckelshausen, A. (2022) · Sensors · doi:10.3390/s22155745 · Cited by 3
Metadata
- Authors
- Rosique, F., Navarro, P. J., Fernández, C., & Padilla, A.
- Affiliations
- Universidad Politécnica de Cartagena (ES)
- Corresponding author
- Rosique, Francisca
- Navarro, Pedro J.
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2019-02-05
- Volume
- 19
- Issue
- 3
- Pages
- 648
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC6387009
- OpenAlex
- W2912493354
- Cited by
- 469
- References
- 63
- Citations by year
- 2026: 34 · 2025: 49 · 2024: 80 · 2023: 96 · 2022: 71 · 2021: 74 · 2020: 47 · 2019: 17
- FWCI
- 5.47
- Type
- journal article
- Language
- en
- Open access
- gold
- dx.doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- Europe PMC (PubMed Central) (publishedVersion, other-oa)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Digital Repository (Polytechnic University of Cartagena) (submittedVersion, cc-by-nc-nd)
- Funders
- Dirección General de Tráfico (SPIP2017-02286)
- Ministerio de Economía y Competitividad (BFU2017-88300-C2-2-R)
- Fundación Séneca (19895/GERM/15)
- Topics
- Physical Sciences › Engineering › Automotive Engineering › Autonomous Vehicle Technology and Safety
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Robotics and Sensor-Based Localization
- Physical Sciences › Engineering › Automotive Engineering › Vehicle Dynamics and Control Systems
- Keywords
- autonomous vehicles, perception systems, vehicle simulator, sensor comparison, ultrasonic sensors, radar, LiDAR, camera, inertial measurement unit, GNSS, RTK, game engines, model-driven engineering, autonomous vehicle regulation
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
