

The DOI matches its Crossref record; 64 of the 64 references it cites were found in a registry or an index.
A Systematic Review of Perception System and Simulators for Autonomous Vehicles Research
Open accessAbstract
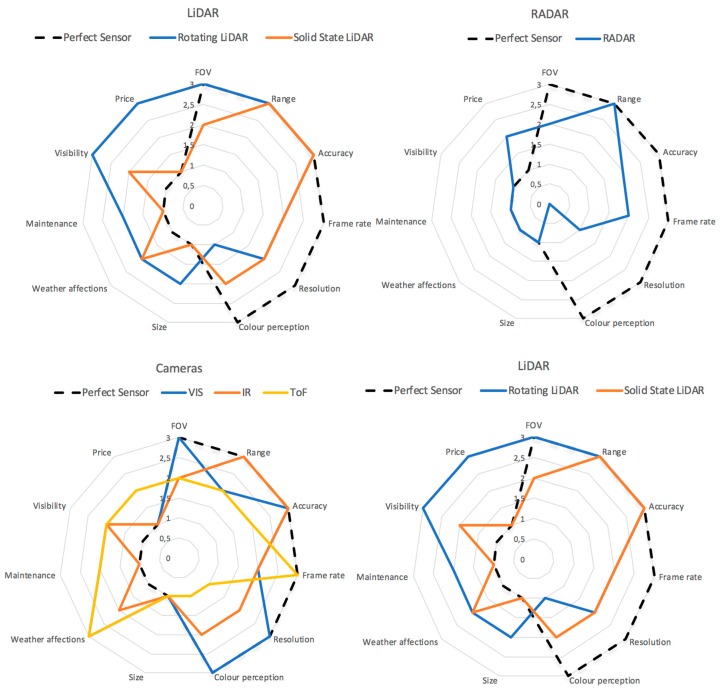
This paper presents a systematic review of the perception systems and simulators for autonomous vehicles (AV). This work has been divided into three parts. In the first part, perception systems are categorized as environment perception systems and positioning estimation systems. The paper presents the physical fundamentals, principle functioning, and electromagnetic spectrum used to operate the most common sensors used in perception systems (ultrasonic, RADAR, LiDAR, cameras, IMU, GNSS, RTK, etc.). Furthermore, their strengths and weaknesses are shown, and the quantification of their features using spider charts will allow proper selection of different sensors depending on 11 features. In the second part, the main elements to be taken into account in the simulation of a perception system of an AV are presented. For this purpose, the paper describes simulators for model-based development, the main game engines that can be used for simulation, simulators from the robotics field, and lastly simulators used specifically for AV. Finally, the current state of regulations that are being applied in different countries around the world on issues concerning the implementation of autonomous vehicles is presented.
Overview
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Integrity signals
Registry
Cites
Statistics
Figures
Verification
Claims the paper makes
The claims and statistics of this paper haven’t been checked yet.
Run the check — free, no account needed. It reads the open-access text and checks the sources it cites.
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“The Global Positioning System (GPS) is the most common GNSS system freely available to be used in any part of the world [111].”
From Sensor-Based Prognostic Health Management of Advanced Driver Assistance System for Autonomous Vehicles: A Recent Survey (2022) · cites this paper as [111]
Experimental — accuracy not yet measuredThe source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“It is mentioned that a pure vision-based system has advantages like affordability and simplicity of implementation.”
From Object Detection in Autonomous Vehicles under Adverse Weather: A Review of Traditional and Deep Learning Approaches (2024) · cites this paper as [48]
Experimental — accuracy not yet measuredThe source backs part of the claim, not all of it — or backs it for a different population, condition or comparison.
In the citing paper
“Such simulation not only includes software simulation like CarSim and CARLA. but also includes hybrid realization with hardware-in-the-loop or vehicle-in-the-loop design [67].”
From Trustworthy AI: From Principles to Practices (2023) · cites this paper as [67]
Experimental — accuracy not yet measuredThe cited source says what the claim attributes to it.
In the citing paper
“Such simulation not only includes software simulation like CarSim and CARLA. but also includes hybrid realization with hardware-in-the-loop or vehicle-in-the-loop design [67].”
From Trustworthy AI: From Principles to Practices (2023) · cites this paper as [67]
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
The self-check needs the paper’s full text.
Citations
Cites
Vision meets robotics: The KITTI dataset
Geiger, A., Lenz, P., Stiller, C., & Urtasun, R. (2013) · The International Journal of Robotics Research · doi:10.1177/0278364913491297 · Cited by 9,913
Kalra, N., & Paddock, S. M. (2016) · Transportation Research Part A: Policy and Practice · doi:10.1016/j.tra.2016.09.010 · Cited by 1,221
A Review of Data Fusion Techniques
Castanedo, F. (2013) · The Scientific World Journal · doi:10.1155/2013/704504 · Cited by 1,027
Thermal cameras and applications: A survey
Gade, R., & Moeslund, T. B. (2014) · Machine Vision and Applications · doi:10.1007/s00138-013-0570-5 · Cited by 780
Challenges in autonomous vehicle testing and validation
Koopman, P., & Wagner, M. (2016) · SAE International Journal of Transportation Safety · doi:10.4271/2016-01-0128 · Cited by 675
USARSim: a robot simulator for research and education
Carpin, S., Lewis, M., Wang, J., Balakirsky, S. B., & Scrapper, C. (2007) · Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · doi:10.1109/robot.2007.363180 · Cited by 423
Pedestrian Detection at Day/Night Time with Visible and FIR Cameras: A Comparison
González, A., Fang, Z., Socarras, Y., Serrat, J., Vázquez, D., Xu, J., & López, A. M. (2016) · Sensors · doi:10.3390/s16060820 · Cited by 330
Bimbraw, K. (2015) · International Conference on Informatics in Control, Automation and Robotics (ICINCO) · doi:10.5220/0005540501910198 · Cited by 324
Development of Autonomous Car—Part I: Distributed System Architecture and Development Process
Jo, K., Kim, J., Kim, D., Jang, C., & Sunwoo, M. (2014) · IEEE Transactions on Industrial Electronics · doi:10.1109/tie.2014.2321342 · Cited by 277
Development of advanced driver assistance systems with vehicle hardware-in-the-loop simulations
Gietelink, O. J., Ploeg, J., Schutter, B. D., & Verhaegen, M. (2006) · Vehicle System Dynamics · doi:10.1080/00423110600563338 · Cited by 272
Research works printed but not linked: 2
- Council, N.R. (2001). Statistics, Testing, and Defense Acquisition: New Approaches and Methodological Improvements, The National Academies Press.
- Dosovitskiy, A., Ros, G., Codevilla, F., Lopez, A., and Koltun, V. (arXiv, 2017). CARLA: An Open Urban Driving Simulator, arXiv.
Cited by
Sorted by citations
Items 301–400 of 469
Anoop, B. N., Abhilash, S. K., Nookala, V. M., Prita, S., & Raghavendra, S. (2025) · IEEE Access · doi:10.1109/access.2025.3583341 · Cited by 2
Hamida, A., Saif, M., Li, J., & Valaee, S. (2025) · IEEE Transactions on Antennas and Propagation · doi:10.1109/tap.2025.3618461 · Cited by 2
Renatus, K., Rabe, M. D., Bäker, B., Waschulzik, T., & Schories, K. (2026) · Transportation Engineering · doi:10.1016/j.treng.2026.100421 · Cited by 2
Sarkandi, G., & Alecsandru, C. (2026) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2026.3670714 · Cited by 2
Development of Low-cost Forward Collision Warning and Avoidance System for Electric Microcar
Shaik, A., Devunuri, S., Ramarao, M. V., & Babu, B. H. (2024) · International Conference on Computational Intelligence for Green and Sustainable Technologies (ICCIGST) · doi:10.1109/iccigst60741.2024.10717551 · Cited by 2
Al-Turki, M., Ratrout, N. T., & Alsghan, I. (2023) · Istrazivanja i projektovanja za privredu · doi:10.5937/jaes0-39994 · Cited by 3
Djoko‐Kouam, M., & Fougères, A.-J. (2023) · Automation Control and Intelligent Systems · doi:10.11648/j.acis.20231102.12 · Cited by 2
Investigating collision patterns to support autonomous driving safety
Lee, C. K. H., Leung, E. K. H., Tse, Y. K., & Tsao, Y. (2023) · Enterprise Information Systems · doi:10.1080/17517575.2023.2243460 · Cited by 2
Srinivasan, S., Rajegowda, R., & Udhayakumar, E. (2023) · IntechOpen eBooks · doi:10.5772/intechopen.1003683 · Cited by 2
Kamal, M., Muhamad, M., Sudianto, Y., Fauzan, M. A., Anggito, Y., Yasin, W., & Hermawan, H. (2024) · Jurnal Sisfokom (Sistem Informasi dan Komputer) · doi:10.32736/sisfokom.v13i1.1987 · Cited by 2
Prospective study on challenges faced in a perception system
Rolen, L. R., Bhat, S. J., & Santhosh, K. V. (2024) · Cogent Engineering · doi:10.1080/23311916.2024.2353498 · Cited by 4
Tangible Narrative - An Intelligent Cockpit Design Methodology for Designers to Experience
Li, M., Zhao, D., Yang, Z., & Wang, T. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-60913-8_10 · Cited by 2
Machine Learning Security of Connected Autonomous Vehicles: A Systems Perspective
Ellis, W., Belguith, S., & Tryfonas, T. (2024) · IEEE International Conference on Industrial Technology (ICIT) · doi:10.1109/icit58233.2024.10540922 · Cited by 2
Geometric Fidelity Requirements for Meshes in Automotive Lidar Simulation
Goodin, C. T., Moore, M. N., Carruth, D. W., Aspin, Z. S., & Kaniarz, J. (2024) · Virtual Worlds · doi:10.3390/virtualworlds3030014 · Cited by 2
Digital Twin Modeling for Machine Vision Testing in Autonomous Systems
Bruzzone, A. G., Massei, M., Gotelli, M., Ferrari, R., Paoli, A. D., Giovannetti, A., & Nguyen, V. P. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-71397-2_14 · Cited by 2
Learning to drive as humans do: Reinforcement learning for autonomous navigation
Ge, L., Xiaoguang, Z., & Yongcong, W. (2024) · International Journal of Advanced Robotic Systems · doi:10.1177/17298806241278910 · Cited by 2
Real-Time State Estimation and Security in Autonomous Vehicles Using Particle Filters
Ghliss, M., Kechiche, L., & Chabir, K. (2024) · IEEE International Multi-Conference on Smart Systems & Green Process (IMC-SSGP) · doi:10.1109/imc-ssgp63352.2024.10919655 · Cited by 2
da Silva, E. L. R., & de Freitas, H. C. (2025) · International Conference on Consumer Electronics · doi:10.1109/icce63647.2025.10929988 · Cited by 2
Haghighi, H. F., Wang, X., Jing, H., & Dianati, M. (2025) · IEEE Transactions on Intelligent Vehicles · doi:10.1109/tiv.2025.3624111 · Cited by 5
Simulation-Based Testing to Improve Safety of Autonomous Robots
Sartori, L. V. (2019) · IEEE International Symposium on Software Reliability Engineering Workshops (ISSREW) · doi:10.1109/issrew.2019.00053 · Cited by 2
A Comparison about the Reflectivity of Different Materials with Active Sensors
Lubanco, D. L. S., Kaineder, G., Scherhäufl, M., Schlechter, T., & Salmen, D. (2020) · International Conference on Robotics and Automation Engineering (ICRAE) · doi:10.1109/icrae50850.2020.9310883 · Cited by 2
Maneuver Classification for Road Vehicles with Constrained Filtering Techniques
Törő, O., Bécsi, T., Aradi, S., Kolat, M., & Gáspár, P. (2020) · IFAC-PapersOnLine · doi:10.1016/j.ifacol.2020.12.2375 · Cited by 2
Self-driving cars find their way in the world
McCormick, C. (2019) · Physics Today · doi:10.1063/pt.3.4256 · Cited by 2
Wang, Y., Li, K., Yin, L., & Chen, H. (2019) · Chinese Automation Congress · doi:10.1109/cac48633.2019.8997170 · Cited by 2
Novel Deep Level Image State Ensemble Enhancement Method for M87 Imaging
Taylor, T. R., Chao, C., & Chiou, J.-S. (2020) · Applied Sciences · doi:10.3390/app10113952 · Cited by 2
Modulare Validierung simulierter Sensorsysteme für interagierende Digitale Zwillinge
Thieling, J., & Roßmann, J. (2021) · Springer eBooks · doi:10.1007/978-3-658-32266-3_12 · Cited by 2
Micro-motion Target Classification Based on FMCW Radar Using Extended Residual Neural Network
Le, H. H., Doan, V., Phong, L. D., Huynh‐The, T., & Hoang, V. (2021) · Lecture notes of the Institute for Computer Sciences, Social Informatics and Telecommunications Engineering · doi:10.1007/978-3-030-77424-0_9 · Cited by 2
Range Estimation in Frequency-Selective Propagation Environment for Terahertz Automotive Radar
Tabrikian, J., & Bilik, I. (2022) · IEEE Sensor Array and Multichannel Signal Processing Workshop (SAM) · doi:10.1109/sam53842.2022.9827896 · Cited by 2
Review and Assessment of Excavator Operations Using RAMSIS Ergonomic Engineering Software
Mansfeld, A., Luebke, A., & Duffy, V. G. (2022) · Lecture notes in computer science · doi:10.1007/978-3-031-21704-3_18 · Cited by 2
Research on Sensor Optimization Technology of Driverless Vehicle
Song, Z. G., & Deng, H. (2023) · Frontiers in Computing and Intelligent Systems · doi:10.54097/fcis.v4i2.10370 · Cited by 2
Integrated Camera and Radar Tracking using Multi-Model Cubature Kalman Filter
Bhuvana, V. P., & Huemer, M. (2019) · IEEE Global Conference on Signal and Information Processing · doi:10.1109/globalsip45357.2019.8969484 · Cited by 2
A review of automated vehicle systems
Siroki, S., Nyerges, Á., & Tihanyi, V. (2019) · IEEE International Conference and Workshop Óbuda on Electrical and Power Engineering (CANDO-EPE) · doi:10.1109/cando-epe47959.2019.9111005 · Cited by 2
An Advanced System‐Level Testing for Roadside Multimodal Sensing and Processing in IoV
Wang, Y., Wang, J., Bao, X., Yu, B., & Ge, Y. (2022) · Wireless Communications and Mobile Computing · doi:10.1155/2022/7975523 · Cited by 2
A sensor modelling framework for autonomous systems
Khatry, R., & Thompson, A. (2021) · doi:10.47120/npl.ms29 · Cited by 2
A Theoretical Framework for Autonomous Vehicles: A Sustainability PerspectivePreprint
Chota, E., & Bruce, F. N. O. (2023) · SSRN Electronic Journal · doi:10.2139/ssrn.4462429 · Cited by 3
Next-gen Urban Buses: Autonomy and Connectivity
Hsu, T.-M. (2024) · doi:10.4271/epr2024019 · Cited by 2
Yang, J., Zhao, Y., & Zhao, J. (2021) · doi:10.1109/iccs52645.2021.9697126 · Cited by 1
Development of combined simulation device for vehicle lateral acceleration and yaw
Sun, F., Li, K., Chen, G., Guo, D., Kang, J., & Ren, C. (2024) · Proceedings of the Institution of Mechanical Engineers Part D Journal of Automobile Engineering · doi:10.1177/09544070231221177 · Cited by 1
Li, M., Zhou, M., Chen, Q., Song, H., & Dong, H. (2024) · Youth Academic Annual Conference of Chinese Association of Automation (YAC) · doi:10.1109/yac63405.2024.10598690 · Cited by 1
Survey on Sensing, Modelling and Reasoning Aspects in Military Autonomous Systems
Kalff, E., Maaiveld, T. M., Schadd, M. P. D., Voogd, J. M., & Weyland, L. F. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-71397-2_17 · Cited by 1
Adelsberg, G., Chandra, R., Dugar, A., Jain, P., Suresh, S., Lee, B., Cho, A., & Powell, T. (2024) · IEEE MIT Undergraduate Research Technology Conference (URTC) · doi:10.1109/urtc65039.2024.10937641 · Cited by 1
Malakar, P., Mandal, N., Saad, M., & Mukhopadhyay, A. (2025) · IGI Global eBooks · doi:10.4018/979-8-3373-6385-1.ch008 · Cited by 1
Towards Credible Simulators: A Validation Methodology for Safety-Critical Virtual Testing
Avula, R. R., Mohamad, M., Sangchoolie, B., & Damschen, M. (2025) · Lecture notes in computer science · doi:10.1007/978-3-032-02018-5_12 · Cited by 1
Benchmarking domain adaptation for LiDAR-based 3D object detection in autonomous driving
Balım, M. A., Hanilçi, C., & Acır, N. (2025) · Signal Image and Video Processing · doi:10.1007/s11760-025-04580-z · Cited by 1
Mortlock, T., Chen, L., Smereka, J. M., Khargonekar, P. P., & Faruque, M. A. A. (2025) · IEEE Transactions on Intelligent Transportation Systems · doi:10.1109/tits.2025.3612873 · Cited by 2
Tasnim, S., Mostafa, A. M., Morshed, A., Shaiyaz, N., Dipto, S. M., Aloteibi, S., Moni, M. A., Alam, M. G. R., & Alam, M. A. (2025) · Scientific Reports · doi:10.1038/s41598-025-08675-y · Cited by 1
Ryu, H. S., Ju, U., & Wallraven, C. (2025) · IEEE Transactions on Visualization and Computer Graphics · doi:10.1109/tvcg.2025.3616811 · Cited by 2
Animal Interaction with Autonomous Mobility Systems: Designing for Multi-Species Coexistence
Tran, T. T. M., Yu, X., Hoggenmüeller, M., Parker, C., Schmitt, P., Berrío, J. S., Worrall, S., & Tomitsch, M. (2025) · International Conference on Automotive User Interfaces and Interactive Vehicular Applications (AutomotiveUI) · doi:10.1145/3744333.3747834 · Cited by 1
Alazzani, M. (2025) · Cyber Security in Networking Conference (CSNet) · doi:10.1109/csnet67572.2025.11288204 · Cited by 1
Wang, M., Wang, C., Aleksandrov, M., Sisi Zlatanova, B., & Brilakis, I. (2026) · Journal of Building Engineering · doi:10.1016/j.jobe.2026.115252 · Cited by 1
Wang, W., & Fun, T. S. (2026) · Future Internet · doi:10.3390/fi18060319 · Cited by 1
Oh, Y., Jang, S., Yoon, I., Park, B., & Moon, B. (2026) · Sensors · doi:10.3390/s26123941 · Cited by 1
Exploring the Feasibility of Autonomous Vehicle Sensor Suites for Roadway Lighting Evaluation
Golkarfard, A., Kluger, R., & Hasanitabaar, F. (2026) · ASCE International Conference on Transportation and Development (ICTD) · doi:10.1061/9780784487013.034 · Cited by 1
Interactive Simulation Program for Autonomous Vehicles
Pozna, C. R., & Antonya, C. (2021) · The Eurasia Proceedings of Science Technology Engineering and Mathematics · doi:10.55549/epstem.1052211 · Cited by 1
Autonomous Driving Technical Characteristics
Iclodean, C. D., Varga, B. O., & Cordoș, N. (2022) · Green energy and technology · doi:10.1007/978-3-031-14678-7_2 · Cited by 1
Kettelgerdes, M., & Elger, G. (2022) · IEEE International Conference on Digital Twins and Parallel Intelligence (DTPI) · doi:10.1109/dtpi55838.2022.9998918 · Cited by 1
Navarro, P., Rosique, F., Fernández, C., & Miller, L. (2023) · Elsevier eBooks · doi:10.1016/b978-0-323-98339-6.00009-9 · Cited by 1
Self-citationPurwaningsih, S., & Fardela, R. (2022) · Jurnal Penelitian Fisika dan Aplikasinya (JPFA) · doi:10.26740/jpfa.v12n1.p1-13 · Cited by 1
Machine Learning Analysis of Autonomous Vehicle Sensors Under Extreme Conditions in Alaska
Park, J., Quach, N. V., Kim, Y., Cheng, R.-H., Jenco, M., Yin, C., Lee, A. K., & Won, Y. (2023) · Journal of Electronic Packaging · doi:10.1115/1.4063486 · Cited by 1
Self- Driving With Deep Reinforcement ( Survey )
Abdalameer, H. S., & Al-Shammary, A. A. (2022) · Journal of Al-Qadisiyah for Computer Science and Mathematics · doi:10.29304/jqcm.2022.14.3.982 · Cited by 1
Automating the Parking Process: A Study on Motion Planning Techniques for Autonomous Vehicles
Elshennawy, S. M., Mohamed, O., Mostafa, T. A., Nagui, S., Magdy, M., Radwan, M., Montasser, S., & Elganzory, R. (2023) · International Conference on Intelligent Computing and Information Systems (ICICIS) · doi:10.1109/icicis58388.2023.10391144 · Cited by 1
SAVME: Efficient Safety Validation for Autonomous Systems Using Meta-Learning
Schlichting, M. R., Boord, N. V., Corso, A., & Kochenderfer, M. J. (2023) · IEEE International Conference on Intelligent Transportation Systems (ITSC) · doi:10.1109/itsc57777.2023.10420845 · Cited by 1
Aderoba, O. A., Omonigho, E. I., Mpofu, K., Ajisegiri, E., Adediran, A. A., & Ogundokun, R. O. (2024) · International Conference on Science, Engineering and Business for Driving Sustainable Development Goals (SEB4SDG) · doi:10.1109/seb4sdg60871.2024.10629782 · Cited by 1
Architecture of the Computer-Aided Design Toolchain for the Highly-Automated Vehicles
Sviatov, K. V. (2024) · International Russian Automation Conference (RusAutoCon) · doi:10.1109/rusautocon61949.2024.10694645 · Cited by 1
Time of Flight Camera Calibration and Obstacle Detection Application for an Autonomous Vehicle
Miller, L., García, A. R., Navarro, P., Andrés, C. F., & Borraz, R. (2019) · Advances in intelligent systems and computing · doi:10.1007/978-3-030-30604-5_25 · Cited by 1
Self-citationBauer, M. P., Ngo, A., & Resch, M. (2020) · Asia-Pacific Conference on Intelligent Robot Systems (ACIRS) · doi:10.1109/acirs49895.2020.9162620 · Cited by 1
Analysis of microphone use for perception of autonomous vehicles
Siwek, P. (2021) · International Conference on Methods and Models in Automation and Robotics · doi:10.1109/mmar49549.2021.9528431 · Cited by 1
Redenius, J., Belau, S., Irmer, D., Middelberg, R., Spiekermann, S., Bußmann, C., Sellschopp, T., Ruckelshausen, A., & Hertzberg, J. (2019) · VDI Verlag eBooks · doi:10.51202/9783181023617-173 · Cited by 1
A study on Autonomous Vehicles’ Driving Behavior Based on Open Road Test Data
Han, X., Shao, M., Sun, L., & Yuan, Y. (2023) · International Conference on Transportation Information and Safety · doi:10.1109/ictis60134.2023.10243959 · Cited by 1
Perception Sensors for Road Applications
Jiménez, F. (2019) · Sensors · doi:10.3390/s19235294 · Cited by 1
Unsettled Topics Concerning Coating Detection by LiDAR in Autonomous Vehicles
Magnusson, C. P. (2021) · doi:10.4271/epr2021002 · Cited by 1
Microscopic Simulation Analysis of Connected and Autonomous Cars and Trucks at a Freeway Merge Area
Semnarshad, M. (2021) · Cited by 1
Rosique, F., Navarro, P., Fernández, C., Miller, L., & Villagrá, J. (2023) · Elsevier eBooks · doi:10.1016/b978-0-323-98339-6.00006-3 · Cited by 1
Self-citationCritical Scenario Identification for Realistic Testing of Autonomous Driving SystemsPreprint
Song, Q., Tan, K., Runeson, P., & Persson, S. (2023) · Research Square · doi:10.21203/rs.3.rs-1280095/v2 · Cited by 1
Perception System Architecture for Self-Driving Vehicles: A Cyber- Physical Systems FrameworkPreprint
Babaei, P., Riahinia, N., Omid Mahdi Ebadati, E., & Azimi, A. (2023) · Research Square · doi:10.21203/rs.3.rs-3777591/v1 · Cited by 2
Decision Making in Paths of Autonomous Underwater VehiclesPreprint
Ibem, U. U., & Nwaoha, T. C. (2024) · Preprints.org · doi:10.20944/preprints202408.1835.v1
Dávid, B. (2019) · IEEE International Symposium on Computational Intelligence and Informatics (CINTI) · doi:10.1109/cinti-macro49179.2019.9105222
PC-Based Simulation Environment for the Engine Control Optimiser Hardware-in-the-Loop Testing
Sawulski, J., & Ławryńczuk, M. (2020) · Advances in intelligent systems and computing · doi:10.1007/978-3-030-50936-1_108
Development of Point-cloud Processing Algorithm for Self-Driving Challenges
Unger, M., Horváth, E., & Kőrös, P. (2020) · IEEE International Conference on Intelligent Engineering Systems (INES) · doi:10.1109/ines49302.2020.9147201
Autonomous Car with Optimized Dynamic Range using Machine Learning: A Review
Krishnan, A. (2020) · International Journal for Research in Applied Science and Engineering Technology · doi:10.22214/ijraset.2020.31041
Channel Boosting Feature Ensemble for Radar-based Object DetectionPreprint
Azam, S., Munir, F., & Jeon, M. (2021) · arXiv (Cornell University) · doi:10.48550/arxiv.2101.03531
Preliminary Sensors Selection for Reconfigurable Continuous Track Robot Obstacle Detection
Valme, D., Kudelina, K., & Rassõlkin, A. (2021) · IEEE Open Conference of Electrical, Electronic and Information Sciences (eStream) · doi:10.1109/estream53087.2021.9431394
Sherry, L., Baldo, J., Berlin, B., & Snisarevska, O. (2021) · AIAA AVIATION Forum · doi:10.2514/6.2021-2779
Portable Optical Sensors for the Detection of Agricultural and Environmental Contaminants
Zubler, A. V. (2021) · UA Campus Repository (The University of Arizona)
Active Reinforcement Learning over MDPsPreprint
Yang, Q., Yang, P., & Tang, K. (2021) · arXiv (Cornell University) · doi:10.48550/arxiv.2108.02323
Method and Algorithm for Estimating the Maximum Total Error of an Automotive LiDAR
Romanova, M., & Mamchenko, M. (2021) · Journal of Physics Conference Series · doi:10.1088/1742-6596/2096/1/012179
The Fourth Industrial Revolution and its Contribution to Urban Growth
Emara, M. (2021) · Scientific Journal of King Faisal University Basic and Applied Sciences · doi:10.37575/b/eng/210076
Partial State Feedback Based Adaptive Control for Lateral Vehicle Motion with Sensor Failures
Liu, J., Wen, L., Jiang, B., & Dong, M. (2021) · CAA Symposium on Fault Detection, Supervision and Safety for Technical Processes (SAFEPROCESS) · doi:10.1109/safeprocess52771.2021.9693718
Preliminary Design on Modular Electrical Autonomous Vehicle
Phongphaitoonsin, K., Tangtortan, T., Samrittivanicha, T., & Aphiratsakun, N. (2022) · International Electrical Engineering Congress (iEECON) · doi:10.1109/ieecon53204.2022.9741643
Sinz, W., Angrosch, B., Gächter, J., Putsche, B., Rogic, B., & Bernsteiner, S. (2022) · SAE technical papers on CD-ROM/SAE technical paper series · doi:10.4271/2022-01-0102
Automated Driving Safety Framework through Security Architecture - Survey
Geetha, K. (2022) · Journal of Trends in Computer Science and Smart Technology · doi:10.36548/jtcsst.2022.2.001
Iclodean, C. D., Varga, B. O., & Cordoș, N. (2022) · Green energy and technology · doi:10.1007/978-3-031-14678-7_3
Building 3D Perception Model Around Moving Vehicle Using Laser and Vision Information
Jafri, S. R. U. N., Azim, N. A., Qazi, E., Iqbal, S., Siddiqui, Z., & Shamim, S. (2022) · International Bhurban Conference on Applied Sciences and Technology (IBCAST) · doi:10.1109/ibcast54850.2022.9990291
Radar point cloud synchronization and simulation method under multi-condition constraints
Liu, X., Chai, L., Shangguan, W., Cai, B., Peng, J., & Nie, M. (2022) · China Automation Congress (CAC) · doi:10.1109/cac57257.2022.10055761
An intelligent multi-sensor cooperative perception framework for situational awareness enhancement
Zhao, Q., Li, Y., Liu, H., Blasch, E., Pham, K. D., & Chen, G. (2023) · Sensors and Systems for Space Applications · doi:10.1117/12.2665078
Operationalizing digital twins in agriculture with machine learning
Pylianidis, C. (2023) · doi:10.18174/591164
Map and Its Impact on the Functional Safety of Automated Driving Vehicles
Pai, V. N., Barosan, I., & Saberi, A. K. (2023) · Journal of Software Engineering for Autonomous Systems · doi:10.55060/j.jseas.230925.001
Enhancing the quality of gauge images captured in haze and smoke scenes through deep learning
Ramírez-Agudelo, O. H., Shewatkar, A. N., Milana, E., Aydin, R. C., & Franke, K. (2023) · SPIE Applications of Machine Learning · doi:10.1117/12.2679809
A Review on Intensified ANPR Technology to Identify the Vehicles Involved in Smuggling
Harshini, S., Kanimozhi, P., & kuma, D. T. A. (2023) · Irish Interdisciplinary Journal of Science & Research · doi:10.46759/iijsr.2023.7404
Metadata
- Authors
- Rosique, F., Navarro, P. J., Fernández, C., & Padilla, A.
- Affiliations
- Universidad Politécnica de Cartagena (ES)
- Corresponding author
- Rosique, Francisca
- Navarro, Pedro J.
- Venue
- Sensors
- Publisher
- MDPI AG
- Published
- 2019-02-05
- Volume
- 19
- Issue
- 3
- Pages
- 648
- ISSN
- 1424-8220 (ISSN-L)
- PMC
- PMC6387009
- OpenAlex
- W2912493354
- Cited by
- 469
- References
- 63
- Citations by year
- 2026: 34 · 2025: 49 · 2024: 80 · 2023: 96 · 2022: 71 · 2021: 74 · 2020: 47 · 2019: 17
- FWCI
- 5.47
- Type
- journal article
- Language
- en
- Open access
- gold
- dx.doi.org
- Licence
- Locations
- Sensors (publishedVersion, cc-by)
- Europe PMC (PubMed Central) (publishedVersion, other-oa)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- Digital Repository (Polytechnic University of Cartagena) (submittedVersion, cc-by-nc-nd)
- Funders
- Dirección General de Tráfico (SPIP2017-02286)
- Ministerio de Economía y Competitividad (BFU2017-88300-C2-2-R)
- Fundación Séneca (19895/GERM/15)
- Topics
- Physical Sciences › Engineering › Automotive Engineering › Autonomous Vehicle Technology and Safety
- Physical Sciences › Computer Science › Computer Vision and Pattern Recognition › Robotics and Sensor-Based Localization
- Physical Sciences › Engineering › Automotive Engineering › Vehicle Dynamics and Control Systems
- Keywords
- autonomous vehicles, perception systems, vehicle simulator, sensor comparison, ultrasonic sensors, radar, LiDAR, camera, inertial measurement unit, GNSS, RTK, game engines, model-driven engineering, autonomous vehicle regulation
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
