

The DOI matches its Crossref record; 45 of the 46 references it cites were found in a registry or an index; none of the 40 sources its claims cite is checked for support yet.
Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion
Open accessAbstract
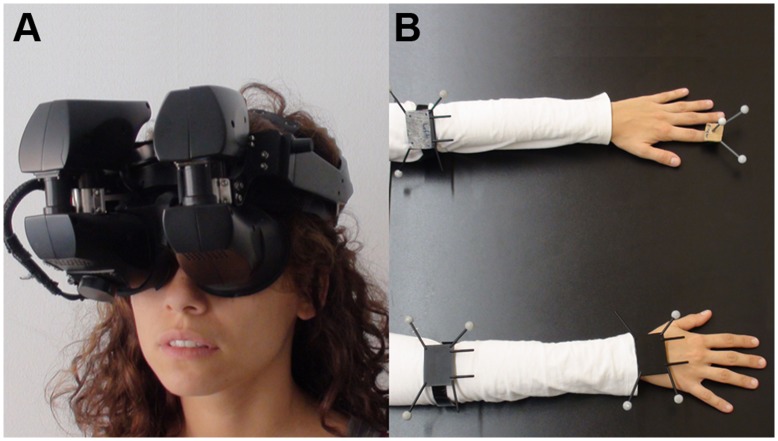
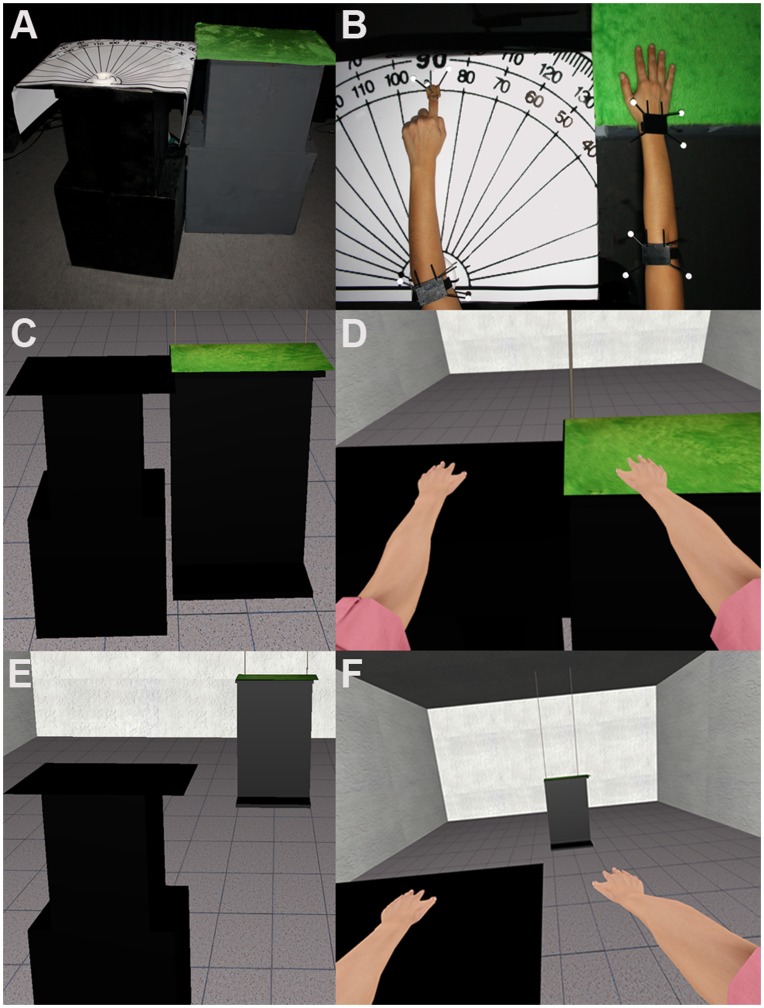
Recent studies have shown that a fake body part can be incorporated into human body representation through synchronous multisensory stimulation on the fake and corresponding real body part - the most famous example being the Rubber Hand Illusion. However, the extent to which gross asymmetries in the fake body can be assimilated remains unknown. Participants experienced, through a head-tracked stereo head-mounted display a virtual body coincident with their real body. There were 5 conditions in a between-groups experiment, with 10 participants per condition. In all conditions there was visuo-motor congruence between the real and virtual dominant arm. In an Incongruent condition (I), where the virtual arm length was equal to the real length, there was visuo-tactile incongruence. In four Congruent conditions there was visuo-tactile congruence, but the virtual arm lengths were either equal to (C1), double (C2), triple (C3) or quadruple (C4) the real ones. Questionnaire scores and defensive withdrawal movements in response to a threat showed that the overall level of ownership was high in both C1 and I, and there was no significant difference between these conditions. Additionally, participants experienced ownership over the virtual arm up to three times the length of the real one, and less strongly at four times the length. The illusion did decline, however, with the length of the virtual arm. In the C2-C4 conditions although a measure of proprioceptive drift positively correlated with virtual arm length, there was no correlation between the drift and ownership of the virtual arm, suggesting different underlying mechanisms between ownership and drift. Overall, these findings extend and enrich previous results that multisensory and sensorimotor information can reconstruct our perception of the body shape, size and symmetry even when this is not consistent with normal body proportions.
Overview
AI snapshot
Written from the paper’s full text.
TL;DR
In an immersive virtual reality between-groups experiment, participants experienced ownership over a virtual arm elongated up to three times the real arm length, with the illusion declining at four times. Ownership and proprioceptive drift appeared to depend on different underlying mechanisms.
Key findings
- With no elongation, ownership was high in both congruent (C1) and visuo-tactile incongruent (I) conditions: Q3 median was 4/5 in both, P = 1.0000, while touch-referral Q1/Q2 were significantly higher in C1 (P = 0.0009 and P = 0.0001).
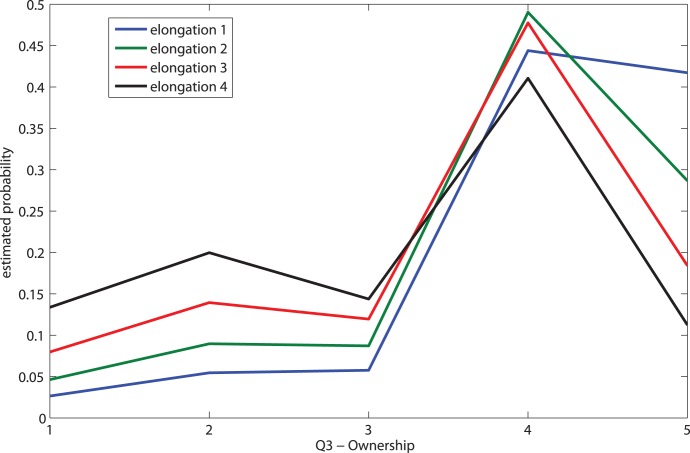
- Ownership declined with virtual arm elongation: ordered logistic regression of Q3 on elongation had a negative coefficient, P = 0.032; estimated probabilities of Q3 ≥ 4 were 0.86, 0.78, 0.66, and 0.52 for elongations 1–4, leaving about a 50% chance of high ownership at four times real length.
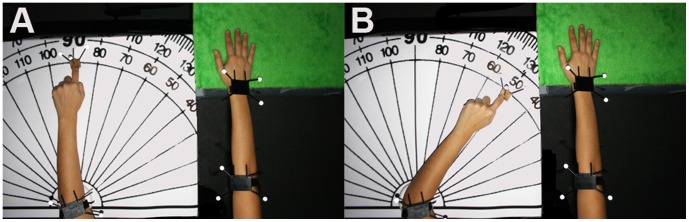
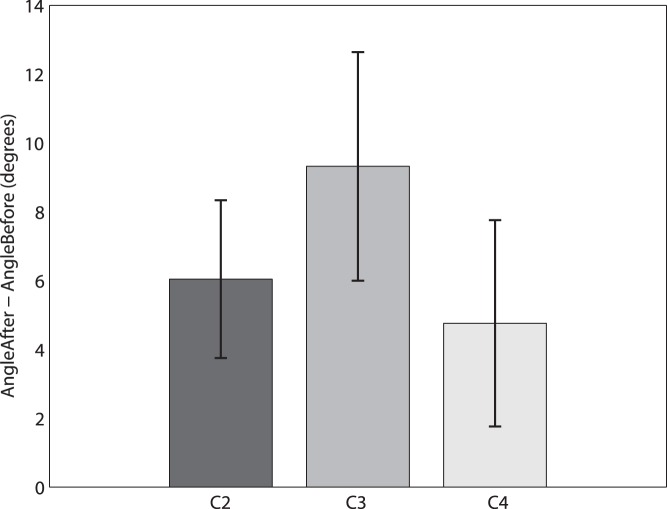
- Proprioceptive drift was positively associated with elongation (Spearman P = 0.03) and significant in C2 (P = 0.037) and C3 (P = 0.012) but not C4 (P = 0.169); drift did not correlate with ownership, and path analysis suggested different mechanisms.
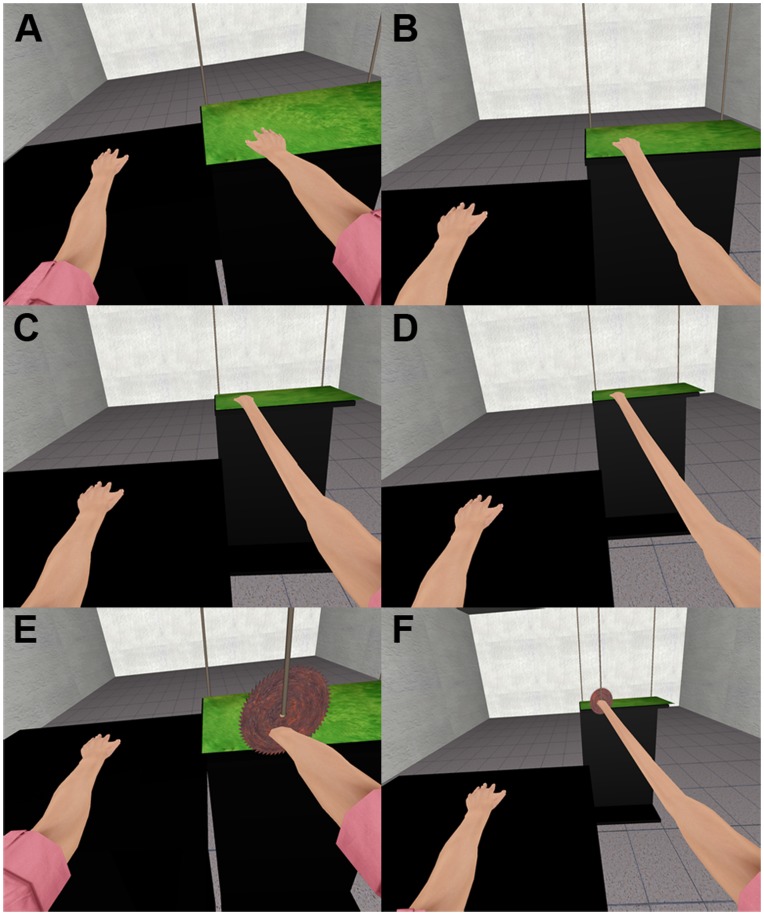
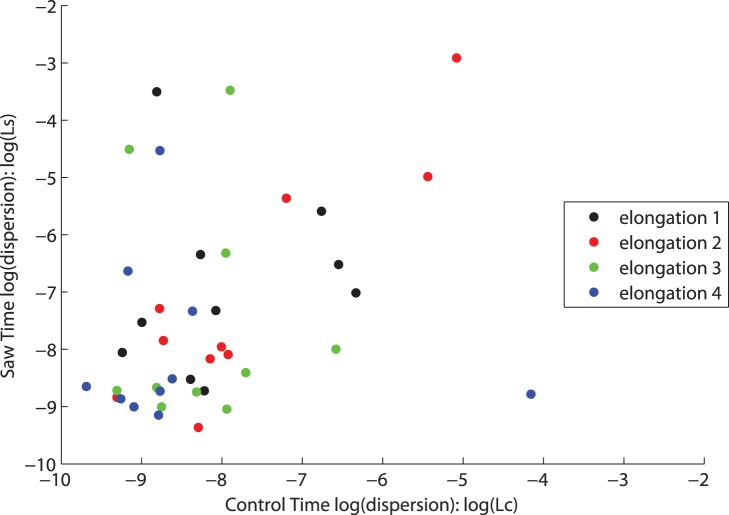
- Defensive withdrawal movements to a falling virtual saw were greater during Saw Time than Control Time overall (combined P = 0.017), and hand movement dispersion was positively related to ownership and to feeling harmed.
Methods
- Fifty participants were assigned to 5 between-groups conditions (n = 10 each): Incongruent (I) and Congruent C1–C4, where the virtual dominant arm was 1, 2, 3, or 4 times the real arm length; mean real arm length was 53 ± 3 cm, giving average C2/C3/C4 lengths of 106, 159, and 212 cm.
- Participants wore a stereo head-mounted display and saw a first-person virtual body; all conditions had visuo-motor congruence, while visuo-tactile congruence was present in C1–C4 but not I. Elongation occurred over 2 minutes while participants touched a physical box.
- Measures included a 7-item questionnaire (1–5 scale), proprioceptive drift via angle estimation before and after elongation for C2–C4, and hand-tracking dispersion before and during the virtual saw threat; analyses used nonparametric tests, ordered logistic regression, robust regression, and path analysis.
Limitations
- The paper states that defensive movements were small because participants were instructed to remain motionless, creating competition between staying still and avoiding the saw; the data likely reflect motor initiation rather than full execution for some participants.
- The paper states that in C4 the virtual hand was far from the body and visual precision/quality were poorer, and that spatial distance or limits on limb representation may contribute to the illusion decline; it also notes that richer multisensory stimulation may be needed for greater distortions.
- Evident from the text: each condition had only 10 participants, drift was not measured in C1 or I, and path analysis treated ordinal questionnaire variables as interval-scale, which the paper acknowledges is not strictly justified.
Model-written summary. Check it against the paper before relying on it.
Integrity signals
Registry
Cites
Statistics
Figures
Verification
Claims the paper makes
66 Own result · 29 Not checked yet · 26 Own interpretation · 4 No basis given
The paper states this without a source or data behind it here, so there is nothing to check it against. The quote shows it is in the paper.
In the paper
“In this paper we show that it is possible to quite dramatically alter body representation, by inducing an ownership illusion over one very long arm in a situation where the entire body has been replaced by a virtual body seen from a first person perspective position (1PP).”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
hedgeddirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Table 3 gives the means and standard errors for and from which it is clear that there is no difference in the amount of hand movement between congruent and incongruent conditions.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Comparison of Congruent and Incongruent Conditions with No Elongation
boosted- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“and is significantly greater for C1 and C2”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
In the paper
“The regression fit is shown in Table 6, supporting the notion of a negative relationship between the virtual arm length and the hand movement dispersion.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
What the sources say
- Not checked yetcites [27] PW Holland, 1977, Robust regression using iteratively reweighted least-squares., Communications in Statistics-Theory and Methods source
hedgedcorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“We now show that the dispersion in Saw Time declines with elongation, taking into account the dispersion during the Control Time.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Moreover, the evidence suggests that there is still about a 50–50 chance of an arm up to four times the real length being subjectively incorporated”
- Also stated in: § The Effect of Elongation · hedged
“Nevertheless from Figure 5 the probability of a score of at least 4 at elongation 4 is estimated as about 50%.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
hedgedcorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
- Also stated in: § The Effect of Elongation · hedged
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The referral of touch questions Q1 and Q2 result in significantly higher responses in the congruent compared to the incongruent condition”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Comparison of Congruent and Incongruent Conditions with No Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, it did not prove possible to find a fit with normally distributed residual errors.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
hedged- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The dispersion of the hand positions as measured by tracking (Eq. 1) was greater during the Saw Time than in the Control time under all elongation conditions except C4, as shown in Table 5”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“there is no correlation of the angular drift with any of the questionnaire responses.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
- It may state two separate claims as one. 29
- Probably not a substantial claim. 17
- The quote only partly states this claim. 2
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The estimated probabilities of the score being at least 4 are 0.86, 0.78, 0.66 and 0.52 respectively.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
hedgedcorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The median of these 30 angle estimates is 45.6°, and the median of the corresponding 30 standard errors is 0.76° with interquartile range 0.59°.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plainn = 30- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The only other response that shows a trend is Q7 (the feeling of being harmed) where the median is greater in the congruent condition”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Comparison of Congruent and Incongruent Conditions with No Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“For elongation 1 to 3 there are always at least 7 out of 10 participants with scores of at least 4. This declines to 4 out of 10 for elongation 4.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaincorrelationaln = 10- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The (two-sided) significance levels are for C2 P = 0.037, for C3 P = 0.012, and for C4 P = 0.169.”
- Also stated in: § The Effect of Elongation · plain
“AngleAfter is significantly greater than AngleBefore for C2 (P = 0.04) and C3 (P = 0.01) but not for C4 (P = 0.17), Wilcoxon matched-pairs signed-rank tests.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
- Also stated in: § The Effect of Elongation · plain
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, there is no difference in median scores for the ownership question, and the median scores are both high (4 out of a maximum of 5).”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Comparison of Congruent and Incongruent Conditions with No Elongation
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“and a defensive withdrawal movement evoked by a threat to the virtual arm near the distant hand position.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
The quote only partly states this claim.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Questionnaire scores and defensive withdrawal movements in response to a threat showed that the overall level of ownership was high in both C1 and I, and there was no significant difference between these conditions.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Abstract
plainn = 10- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, the mean Saw Time dispersion is greater than the mean Control Time dispersion for each group I and C1 separately (bearing in mind that the significance levels are two-tailed) and for the two groups combined.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Comparison of Congruent and Incongruent Conditions with No Elongation
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, responses to Q1 and Q2 about touch referral were significantly different between the two conditions C1 and I showing that the participants had perceived the mismatch between seen and felt touch in I.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Regression analysis revealed that withdrawal movements were positively correlated with Q3 and Q7, validating the use of withdrawal movements to address ownership.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
The paper states this without a source or data behind it here, so there is nothing to check it against. The quote shows it is in the paper.
In the paper
“And indeed, all participants in the conditions with the long virtual arm perceived an elongation of the dominant virtual limb and not a distortion of visual space in the depth axis.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“A regression of on , ownership and shows a positive slope for ownership (P = 0.0058) but no significant effects for the other two variables.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“However, a robust regression of on ownership and results in a highly significant positive slope for both variables (P<0.0005 in both cases).”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“It is positively related both to Q3 (ownership) and Q7 (harmed).”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Additionally, proprioceptive drifts and the difference in the dispersion of movement data were significant in C2 and C3 but not in C4.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Dropping the two non-significant terms results in a significant positive slope for ownership (P<0.01), but does not resolve the problem of the non-normality of the residual errors.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Questionnaire scores for ownership were high in condition C2 and C3 and less in C4.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
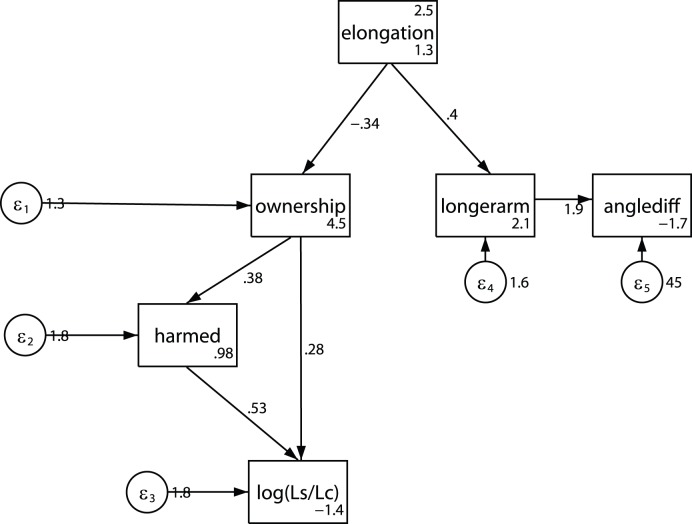
“However, at virtual arm length equal to the real one the fitted value of ownership is 4 and at quadruple the size the value is 3.3.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Putting It All Together
plainn = 40- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“These sensations were reported in questionnaire results and observed through participants’ motor defensive reactions in response to a threat towards the virtual hand.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The case of harmed is more straightforward – there is a positive linear regression slope of on harmed (P<0.0001) with the residual errors satisfying normality (Shapiro Wilks P = 0.272)”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: unclear — It is unclear whether the paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A result the paper reports from its own data — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“The same was also true for withdrawal movements and elongation.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
The quote only partly states this claim.
The paper states this without a source or data behind it here, so there is nothing to check it against. The quote shows it is in the paper.
In the paper
“Here, during the elongation phase, each image of the virtual arm was different from the previous one inducing the sensations of having an arm that continuously extended but still moved synchronously with the real one and received congruent and synchronous tactile feedback in relation to a box that would not be reachable in reality.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
In the paper
“Furthermore, it has been proposed that the artificial body part should obey various morphological, anatomical and postural constraints (for a review see [6]) including the necessity for human body part resemblance.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [6] M Tsakiris, 2010, My body in the brain: a neurocognitive model of body-ownership., Neuropsychologia source
hedged- Asserted: fails — The authors may not put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The authors may not put it forward as true. The paper’s conclusions may not depend on it. It may state two separate claims as one.
In the paper
“Moreover, a recent study showed that it is possible to induce the illusion of having a very small or giant body using synchronous visuo-tacile stimulation on the visible dummy body seen from first person perspective and the unseen real body [20].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [20] B van der Hoort, 2011, Being Barbie: the size of one’s own body determines the perceived size of the world., PLoS One source
hedgeddirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim.
None of the sources cited for this claim have been checked yet.
In the paper
“Under this illusory perception, participants when asked to localize their real hand they are more likely to point closer to the rubber hand after the stimulation compared to before [7], [9].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
hedgedconditional- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
In the paper
“In [8] the RHI was induced using a fake hand 91 cm beyond the real one, although with a lesser intensity compared to when using a normal sized fake arm.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [8] KC Armel, 2003, Projecting sensations to external objects: evidence from skin conductance response., Proceedings of the Royal Society of London Series B-Biological Sciences source
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it. It may state two separate claims as one.
In the paper
“The difference between the participants’ estimations before and after the stimulation is called ‘proprioceptive drift’ and it is widely considered as a behavioral correlate of the ownership illusion, although a recent study [10] challenged the idea that there is a common underlying mechanism that connects drift with the subjective illusion of ownership.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [10] M Rohde, 2011, The Rubber Hand Illusion: Feeling of Ownership and Proprioceptive Drift Do Not Go Hand in Hand., PLoS ONE source
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it. It may state two separate claims as one.
None of the sources cited for this claim have been checked yet.
In the paper
“However, the extent to which gross asymmetries in the fake body can be assimilated remains unknown.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Abstract
What the sources say
- Not checked yetcites [8] KC Armel, 2003, Projecting sensations to external objects: evidence from skin conductance response., Proceedings of the Royal Society of London Series B-Biological Sciences source
- Not checked yetcites [22] F Pavani, 2007, The role of hand size in the fake-hand illusion paradigm., Perception source
- Not checked yetcites [23] M Schaefer, 2007, Morphing the body: illusory feeling of an elongated arm affects somatosensory homunculus., Neuroimage source
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim.
In the paper
“Additionally it has been shown that it is possible to generate an illusion of ownership of a rubber hand that was 3 cm larger than the real hand [22].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [22] F Pavani, 2007, The role of hand size in the fake-hand illusion paradigm., Perception source
hedgeddirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
In the paper
“Similar methods were used to give normal sized men the illusion of ownership over a very fat virtual body, again seen from a first person perspective and with synchronous visuo-tactile and visuo-motor stimulation [21].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [21] JM Normand, 2011, Multisensory stimulation can induce an illusion of larger belly size in immersive virtual reality., PLoS One source
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
In the paper
“It has been proposed that body ownership results from combining two types of knowledge: prior information that is innate or gained from the life experience (e.g. the appearance of our own body), and current multisensory information [6].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [6] M Tsakiris, 2010, My body in the brain: a neurocognitive model of body-ownership., Neuropsychologia source
hedgeddirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim.
None of the sources cited for this claim have been checked yet.
In the paper
“Generally the induction of ownership illusions requires multisensory stimulation with the same spatiotemporal pattern on the real and fake body part [7], [14].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim.
In the paper
“However, the illusion of having a very long nose can be produced without such kinesthetic illusions. This occurs when a finger of a blindfold subject (S0) is manipulated by the experimenter to tap the nose of another subject (S1) who is sitting in front facing away from S0 while the experimenter simultaneously taps the nose of S0 [19].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [19] VS Ramachandran, 1998, The perception of phantom limbs. The D. O. Hebb lecture., Brain 121 (Pt source
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
In the paper
“Also simultaneous vibration on the biceps and triceps muscle tendons can induce the perception of a shrunken arm [18].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [18] MR Longo, 2009, Contraction of body representation induced by proprioceptive conflict., Current Biology source
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
A conclusion the paper draws from its own results — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“It is clear that the probability is high for ownership to be scored at the highest level for equal length, but still at triple length the probability remains high, and only shows a decline at quadruple length.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
boostedcorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
In the paper
“Furthermore, it has been found that just seeing an artificial limb 20 cm longer and connected to the body could result in topographic reorganization of the primary somatosensory cortex [23].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Introduction
What the sources say
- Not checked yetcites [23] M Schaefer, 2007, Morphing the body: illusory feeling of an elongated arm affects somatosensory homunculus., Neuroimage source
hedgedconditional- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
A conclusion the paper draws from its own results — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“These findings revealed that the body representation is flexible and that it is possible to feel ownership towards a transformed and very asymmetric body that contradicts all the notions one has about the human body.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plain- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
None of the sources cited for this claim have been checked yet.
In the paper
“Secondly, neurophysiological studies on monkeys (for a review, see [34]) and behavioral studies in humans e.g. [35] have shown that the brain encodes personal space (i.e. the space occupied by our body) differently from the peripersonal space”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
What the sources say
- Not checked yetcites [34] M Graziano, 2002, How the brain represents the body: insights from neurophysiology and psychology; Hommel WPaB, editor: Oxford: Oxford University Press).
- Not checked yetcites [35] PW Halligan, 2003, Spatial cognition: evidence from visual neglect., Trends in Cognitive Sciences source
boostedcorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
In the paper
“For example, in the study of [8] the intensity of the RHI was smaller when a distant fake arm was used (+91 cm) compared to a normal size fake arm as indicated by the questionnaire responses but not from skin conductance responses.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
What the sources say
- Not checked yetcites [8] KC Armel, 2003, Projecting sensations to external objects: evidence from skin conductance response., Proceedings of the Royal Society of London Series B-Biological Sciences source
hedgeddirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
In the paper
“and is thought to serve as a safety zone for the body, adapted to the body shape [41].”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
What the sources say
- Not checked yetcites [41] MS Graziano, 2006, Parieto-frontal interactions, personal space, and defensive behavior., Neuropsychologia source
hedged- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim.
A conclusion the paper draws from its own results — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“Proprioceptive drifts were found to be affected by elongation but only through the sensation that the real arm feels longer and not through ownership.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
A conclusion the paper draws from its own results — it cites no other source for it, so there is none to check. The quote shows it is in the paper.
In the paper
“These findings imply that the visual space was re-encoded in the virtual hand reference frames with a recalibration of the body segmental and postural configuration and a consequent update of the personal and peripersonal space under the perception of having a very long arm.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: passes — The paper’s conclusions depend on it.
- Based: passes — The paper gives a reason why it holds.
It may state two separate claims as one.
In the paper
“Rapid changes in the primary somatosensory cortex (SI) due to visual exposure to a long artificial arm were found in the study of [23]”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
What the sources say
- Not checked yetcites [23] M Schaefer, 2007, Morphing the body: illusory feeling of an elongated arm affects somatosensory homunculus., Neuroimage source
plaindirect- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
In the paper
“More interestingly, this modulation was significantly and positively correlated with the magnitude of the subjects’ sensations of having a long arm.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
What the sources say
- Not checked yetcites [23] M Schaefer, 2007, Morphing the body: illusory feeling of an elongated arm affects somatosensory homunculus., Neuroimage source
plaincorrelational- Asserted: passes — The authors put it forward as true.
- Checkable: passes — It can be checked against evidence.
- Load-bearing: fails — The paper’s conclusions may not depend on it.
- Based: passes — The paper gives a reason why it holds.
Probably not a substantial claim. The paper’s conclusions may not depend on it.
The authors state this as an assumption.
The angular drift is 0 at elongation 1 (when the arm is at the same length as the true arm there would be no angular displacement within random error).
“Although we did not measure angular drift in condition C1 (no elongation but with congruence) we assume that the angular drift is 0 at elongation 1 - that is, when the arm is at the same length as the true arm there would be no angular displacement within random error.”
The authors state this as an assumption.
The questionnaire variables can be treated as if they are on an interval scale for the path analysis.
“For this purpose we treat all of the questionnaire variables as if on an interval scale.”
Claims other papers make about this one
Each is checked against this paper’s own text: does it say what the citing paper says it does?
The cited source says what the claim attributes to it.
In the citing paper
“This illusion persists through radical transformations such as extensive elongation of the arm [51] or change in the virtual hand position [52] with respect to the real one.”
From Changing bodies changes minds: Owning another body affects social cognition (2015) · cites this paper as [51]
Self-check
Percentages, sums and reported differences re-computed from the paper’s own numbers.
Each contradiction between two passages listed here was confirmed by an independent check.
Rated major: it would touch a result — a value a result rests on, reported and recomputed p-values on opposite sides of the significance level, two passages that conflict with no sign which is right, or a cited work retracted before this paper was published.
In the paper
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
“and is significantly greater for C1 and C2, and significantly greater for all elongation conditions combined.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
“| C1 | .000580±.000198 | .00398±.00292 | 0.09 | | C2 | .00129±.000681 | .00681±.00533 | 0.07 |”
Rated major: it would touch a result — a value a result rests on, reported and recomputed p-values on opposite sides of the significance level, two passages that conflict with no sign which is right, or a cited work retracted before this paper was published.
In the paper
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Discussion
“Additionally, proprioceptive drifts and the difference in the dispersion of movement data were significant in C2 and C3 but not in C4.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
“| C3 | .000366±.000120 | .00449±.00312 | 0.72 |”
Rated minor: it would not touch a result — a value no result rests on, a p-value that stays on the same side of the significance level, or a conflict that is clerical, resolved elsewhere in the paper, or outside its own findings.
In the paper
“However, at virtual arm length equal to the real one the fitted value of ownership is 4 and at quadruple the size the value is 3.3.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Putting It All Together
Reported 3.3 · recomputed 3.125
Rated minor: it would not touch a result — a value no result rests on, a p-value that stays on the same side of the significance level, or a conflict that is clerical, resolved elsewhere in the paper, or outside its own findings.
In the paper
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > The Effect of Elongation
“AngleDiff = AngleAfter - AngleBefore.”
§ Extending Body Space in Immersive Virtual Reality: A Very Long Arm Illusion > Results > Putting It All Together
“The variable longerarm is the response on Q6, and anglediff is AngleBefore-AngleAfter.”
Citations
Cites
Rubber hands ‘feel’ touch that eyes see
Botvinick, M., & Cohen, J. (1998) · Nature · doi:10.1038/35784 · Cited by 4,410
Philosophical conceptions of the self: implications for cognitive science.
Gallagher, S. (2000) · Trends in Cognitive Sciences · doi:10.1016/s1364-6613(99)01417-5 · Cited by 2,881
Robust regression using iteratively reweighted least-squares.
Holland, P. W., & Welsch, R. E. (1977) · Communications in Statistics - Theory and Methods · doi:10.1080/03610927708827533 · Cited by 2,115
Assessing proportionality in the proportional odds model for ordinal logistic regression.
Brant, R. (1990) · Biometrics · doi:10.2307/2532457 · Cited by 1,864
The rubber hand illusion revisited: visuotactile integration and self-attribution
Tsakiris, M., & Haggard, P. (2005) · Journal of Experimental Psychology: Human Perception and Performance · doi:10.1037/0096-1523.31.1.80 · Cited by 1,328
Maravita, A., & Iriki, A. (2004) · Trends in Cognitive Sciences · doi:10.1016/j.tics.2003.12.008 · Cited by 1,214
The perception of phantom limbs. The D. O. Hebb lecture
Ramachandran, V. (1998) · Brain · doi:10.1093/brain/121.9.1603 · Cited by 1,100
First person experience of body transfer in virtual reality
Slater, M., Spanlang, B., Sanchez-Vives, M. V., & Blanke, O. (2010) · PLoS ONE · doi:10.1371/journal.pone.0010564 · Cited by 1,090
Self-citationMy body in the brain: A neurocognitive model of body-ownership.
Tsakiris, M. (2010) · Neuropsychologia · doi:10.1016/j.neuropsychologia.2009.09.034 · Cited by 1,069
If I were you: Perceptual illusion of body swapping
Petkova, V. I., & Ehrsson, H. H. (2008) · PLoS ONE · doi:10.1371/journal.pone.0003832 · Cited by 953
Research works printed but not linked: 1
- M Graziano, 2002, How the brain represents the body: insights from neurophysiology and psychology; Hommel WPaB, editor: Oxford: Oxford University Press).
Cited by
Sorted by citations
Items 301–400 of 499
The rubber hand illusion is influenced by self-recognition
O’Dowd, A., & Newell, F. N. (2020) · Neuroscience Letters · doi:10.1016/j.neulet.2020.134756 · Cited by 6
Stretch your reach: Studying Self-Avatar and Controller Misalignment in Virtual Reality Interaction
Pontón, J. L., Keshavarz, R., Beacco, A., & Pelechano, N. (2024) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3613904.3642268 · Cited by 5
Pervasive virtuality in digital entertainment applications and its quality requirements
Valente, L., Feijó, B., Ribeiro, A., & Clua, E. (2018) · Entertainment Computing · doi:10.1016/j.entcom.2018.02.006 · Cited by 5
An Initial Investigation into Stereotypical Influences on Implicit Racial Bias and Embodied Avatars
Maloney, D., & Robb, A. C. (2019) · IEEE Conference on Virtual Reality and 3D User Interfaces (VR) · doi:10.1109/vr.2019.8798122 · Cited by 5
Hypnotic suggestion versus sensory modulation of bodily awareness
Apelian, C., Terhune, D. B., & de Vignemont, F. (2023) · PLoS ONE · doi:10.1371/journal.pone.0291493 · Cited by 6
A unique way to increase presence of mobility impaired users — Increasing confidence in balance
Guo, R., Samaraweera, G., & Quarles, J. P. (2014) · IEEE Conference on Virtual Reality and 3D User Interfaces (VR) · doi:10.1109/vr.2014.6802059 · Cited by 5
The Effects of Avatars on Presence in Virtual Environments for Persons with Mobility Impairments
Guo, R., Samaraweera, G., & Quarles, J. P. (2014) · Eurographics · doi:10.2312/ve.20141357 · Cited by 6
What Is It Like to Be a Virtual Bat?
Andreasen, A., Nilsson, N. C., Zovnercuka, J., Geronazzo, M., & Serafin, S. (2019) · Lecture notes of the Institute for Computer Sciences, Social Informatics and Telecommunications Engineering · doi:10.1007/978-3-030-06134-0_57 · Cited by 5
Memory-related perceptual illusions directly affect physical activity in humans
Cuperus, A. A., Disco, R. T., Sligte, I. G., van der Kuil, M. N. A., Evers, A. W. M., & van der Ham, I. J. M. (2019) · PLoS ONE · doi:10.1371/journal.pone.0216988 · Cited by 6
What you see isn't necessarily what you get
Volkmann, T., Wessel, D., Caliebe, T. O., & Jochems, N. (2020) · Mensch und Computer (MuC) · doi:10.1145/3404983.3405590 · Cited by 5
Body illusions for mental health: a systematic reviewPreprint
Matamala-Gomez, M., Maselli, A., Malighetti, C., Realdon, O., Mantovani, F., & Riva, G. (2020) · PsyArXiv (OSF Preprints) · doi:10.31234/osf.io/mk69x · Cited by 5
RemapVR: An Immersive Authoring Tool for Rapid Prototyping of Remapped Interaction in VR
Luo, T., Wu, T., Jiang, C., Duan, X., Lv, J., Li, N., Fan, Y., Han, T., & Tian, F. (2025) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3706598.3714201 · Cited by 4
Szczotka, J., & Wierzchoń, M. (2022) · Psychopathology · doi:10.1159/000526869 · Cited by 6
From child-peer similarity in imitative behavior to matched peer-mediated interventions in autism
Xavier, J., Johnson, S., & Cohen, D. (2023) · Frontiers in Psychology · doi:10.3389/fpsyg.2023.1173627 · Cited by 4
Embodying a self-avatar with a larger leg: its impacts on motor control and dynamic stability
Vallageas, V., Aïssaoui, R., Willaert, I., & Labbé, D. R. (2024) · IEEE Transactions on Visualization and Computer Graphics · doi:10.1109/tvcg.2024.3372084 · Cited by 6
Towards Full Body Co-Embodiment of Human and Non-Human Avatars in Virtual Reality
Podkosova, I., & Brument, H. (2024) · IEEE Conference on Virtual Reality and 3D User Interfaces Abstracts and Workshops (VRW) · doi:10.1109/vrw62533.2024.00084 · Cited by 4
Bound by Experience: Updating the Body Representation When Using Virtual Objects
Eck, J., & Pfister, R. (2024) · Human Factors The Journal of the Human Factors and Ergonomics Society · doi:10.1177/00187208241258315 · Cited by 5
Sense of Agency during Encoding Predicts Subjective Reliving
Meyer, N. H., Gauthier, B., Potheegadoo, J., Boscheron, J., Franc, E., Lance, F., & Blanke, O. (2024) · eNeuro · doi:10.1523/eneuro.0256-24.2024 · Cited by 5
Electrophysiological Correlates for the Detection of Haptic Illusions
Weiß, Y., Schmidt, A., & Villa, S. (2025) · IEEE Transactions on Haptics · doi:10.1109/toh.2025.3578076 · Cited by 4
Study of self-avatar's influence on motor skills training in immersive virtual environments
Ricca, A., Chellali, A., & Otmane, S. (2018) · Virtual Reality International Conference · doi:10.1145/3234253.3234304 · Cited by 4
Spatial Asynchronous Visuo-Tactile Stimuli Influence Ownership of Virtual Wings
Andreasen, A., Nilsson, N. C., & Serafin, S. (2018) · IEEE Conference on Virtual Reality and 3D User Interfaces (VR) · doi:10.1109/vr.2018.8446569 · Cited by 4
More Plausible Models of Body Ownership Could Benefit Virtual Reality Applications
Schubert, M., & Endres, D. (2021) · Computers · doi:10.3390/computers10090108 · Cited by 5
Kostopoulos, C. (2024) · Media and Communication · doi:10.17645/mac.8687 · Cited by 6
Bishop, C., Esteves, A., & Mcgregor, I. P. (2017) · INTERNATIONAL CONFERENCE ON MULTIMODAL INTERACTION · doi:10.1145/3136755.3136781 · Cited by 4
Emotional Avatars: The Interplay between Affect and Ownership of a Virtual BodyPreprint
Mottelson, A., & Hornbæk, K. (2020) · arXiv (Cornell University) · doi:10.48550/arxiv.2001.05780 · Cited by 7
Towards an Avatar Customization System for Semi-realistic Ethnically-diverse Virtual Reality Avatars
Lambert, N., & Lakier, M. (2024) · ACM Symposium on Virtual Reality Software and Technology (VRST) · doi:10.1145/3641825.3689497 · Cited by 3
Jang, H., & Lee, J. (2025) · IEEE Transactions on Visualization and Computer Graphics · doi:10.1109/tvcg.2025.3549532 · Cited by 7
Iarygina, O., Hornbæk, K., & Mottelson, A. (2025) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3706598.3713506 · Cited by 3
Sanchez, D. R., McVeigh-Schultz, J. R., Isbister, K., Tran, M., Martinez, K., Dost, M., Osborne, A., Diaz, D., Farillas, P., Lang, T., et al. (2024) · Virtual Worlds · doi:10.3390/virtualworlds3040023 · Cited by 3
Does Hand Size Matter? The Effect of Avatar Hand Size on Non-verbal Communication in Virtual Reality
Henry, J., Canales, R., Stolarski, C., Adkins, A., Venkatakrishnan, R., Venkatakrishnan, R., & Jörg, S. (2025) · IEEE Transactions on Visualization and Computer Graphics · doi:10.1109/tvcg.2025.3549894 · Cited by 3
Spatial Asynchronous Visuo-Tactile Stimuli Influence Ownership of Virtual Wings
Andreasen, A., Nilsson, N. C., & Serafin, S. (2019) · Lecture notes of the Institute for Computer Sciences, Social Informatics and Telecommunications Engineering · doi:10.1007/978-3-030-06134-0_39 · Cited by 3
Mourelatos, A., Nathanael, D., Gkikas, K., & Psarakis, L. (2018) · Advances in intelligent systems and computing · doi:10.1007/978-3-319-96077-7_19 · Cited by 3
Effects of Human Synchronous Hand Movements in Eliciting a Sense of Agency and Ownership
Hao, Q., Ora, H., Ogawa, K., Amano, S.-I., & Miyake, Y. (2020) · Scientific Reports · doi:10.1038/s41598-020-59014-2 · Cited by 3
Technological Interventions for Eating and Weight Disorders
Gutiérrez‐Maldonado, J., & Riva, G. (2021) · Elsevier eBooks · doi:10.1016/b978-0-12-818697-8.00057-1 · Cited by 3
Rescaling perceptual hand maps by visual‐tactile recalibration
Fuchs, X., & Heed, T. (2024) · European Journal of Neuroscience · doi:10.1111/ejn.16571 · Cited by 3
Evaluating user perception toward physics-adapted avatar in remote heterogeneous spaces
Kim, T., Kim, H., Lee, J., & Lee, S. (2025) · Computers & Graphics · doi:10.1016/j.cag.2025.104185 · Cited by 3
Investigation into Natural Gestures Using EMG for "SuperNatural" Interaction in VR
Eghtebas, C., Weber, S., & Klinker, G. (2018) · ACM Symposium on User Interface Software and Technology (UIST) · doi:10.1145/3266037.3266115 · Cited by 3
Factors and Influences of Body Ownership Over Virtual Hands
Ogawa, N., Narumi, T., & Hirose, M. (2017) · Lecture notes in computer science · doi:10.1007/978-3-319-58521-5_46 · Cited by 3
Asai, Y., Enomoto, R., Ueda, Y., Iwai, D., & Sato, K. (2019) · IEEJ Transactions on Electronics Information and Systems · doi:10.1541/ieejeiss.139.662 · Cited by 3
Body Representation and Neuroprosthetics
Hagura, N., & Haggard, P. (2014) · Springer eBooks · doi:10.1007/978-4-431-55037-2_10 · Cited by 3
de Vignemont, F. (2020) · doi:10.1093/oxfordhb/9780198749677.013.4 · Cited by 3
Owens, E. A., & Duncan, R. O. (2025) · Frontiers in Human Neuroscience · doi:10.3389/fnhum.2025.1468947 · Cited by 3
“A False Reality”? A Micro-phenomenology of Avatars in VR
Hu, X., Dalsgaard, T.-S., & Hornbæk, K. (2025) · Lecture notes in computer science · doi:10.1007/978-3-031-93861-0_5 · Cited by 2
Cao, R., Liang, Z., Zhang, C., Cunningham, A., Walsh, J. A., & Cao, R. (2025) · IEEE Transactions on Visualization and Computer Graphics · doi:10.1109/tvcg.2025.3616832 · Cited by 2
Xiong, P., Ouyang, J., Wu, Z., Zhang, Y., Li, X., Chen, G., Wang, Y., & Fan, M. (2025) · Proceedings of the ACM on Interactive Mobile Wearable and Ubiquitous Technologies · doi:10.1145/3770642 · Cited by 2
Deng, D., Bujić, M., & Hamari, J. (2025) · ACM Symposium on Virtual Reality Software and Technology (VRST) · doi:10.1145/3756884.3766029 · Cited by 2
Movement Qualities of the Augmented Body in XR: Insights from Dance Practitioners
Akbas, S., Kuşçu, K., Eskenazi, T., & Yantaç, A. E. (2026) · Augmented Humans International Conference (AHs) · doi:10.1145/3795011.3795016 · Cited by 2
Choudhary, Z. D. (2021) · IEEE International Symposium on Mixed and Augmented Reality Adjunct (ISMAR-Adjunct) · doi:10.1109/ismar-adjunct54149.2021.00109 · Cited by 2
Mori, K., Ando, M., Otsu, K., & Izumi, T. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-61041-7_5 · Cited by 2
The Potential and Challenges of Virtual Reality as an Adjunctive Treatment of Depression Patients
Kim, J., & Kim, Y. (2024) · Advances in experimental medicine and biology · doi:10.1007/978-981-97-4402-2_15 · Cited by 3
Sakurada, K., Kondo, R., Nakamura, F., Fukuoka, M., Kitazaki, M., & Sugimoto, M. (2022) · Augmented Humans International Conference (AHs) · doi:10.1145/3519391.3522754 · Cited by 2
Dong, M. (2016) · DigitalCommons - Kennesaw State University (Kennesaw State University) · Cited by 2
Yamashita, S., Ishida, R., Takahashi, A., Wu, H.-H., Mitake, H., & Hasegawa, S. (2018) · Virtual Reality International Conference · doi:10.1145/3234253.3234310 · Cited by 2
Affects of Perceived-Actions within Virtual Environments on User Behavior on the Outside
Hameed, A., & Perkis, A. (2020) · International Conference on Quality of Multimedia Experience (QoMEX) · doi:10.1109/qomex48832.2020.9123099 · Cited by 2
Mori, K., Ando, M., Otsu, K., & Izumi, T. (2023) · Lecture notes in computer science · doi:10.1007/978-3-031-35634-6_19 · Cited by 2
Effects of Mirror Therapy on Motor Imagery Elicited ERD/S: An EEG Study on Healthy Subjects
Jarmolowska, J., Miladinović, A., Valvason, E., Busan, P., Ajčević, M., Battaglini, P. P., & Accardo, A. (2020) · World Congress on Medical Physics and Biomedical Engineering, September 7 - 12, 2009, Munich, Germany · doi:10.1007/978-3-030-64610-3_51 · Cited by 2
Editorial: Embodying Tool Use: From Cognition to Neurorehabilitation
Galli, G., Çakmak, Y. Ö., Babič, J., & Pazzaglia, M. (2020) · Frontiers in Human Neuroscience · doi:10.3389/fnhum.2020.585670 · Cited by 2
Sciortino, P., & Kayser, C. (2021) · bioRxiv (Cold Spring Harbor Laboratory) · doi:10.1101/2021.01.15.426770 · Cited by 2
Oka, T., Goto, T., Kimura, N., Sakurai, S., Nojima, T., & Hirota, K. (2021) · Lecture notes in computer science · doi:10.1007/978-3-030-78321-1_24 · Cited by 1
When you were old: Exploring a Virtual Reality Older Adults Experience Simulation System
Liu, Z., Ding, D., Zheng, Y., Li, Z., & Xiong, R. Q. (2023) · Conference proceedings/Conference proceedings - IEEE International Conference on Systems, Man, and Cybernetics · doi:10.1109/smc53992.2023.10394378 · Cited by 1
Jeune, F. L., D’Alonzo, M., Piombino, V., Noccaro, A., Formica, D., & Pino, G. D. (2024) · eNeuro · doi:10.1523/eneuro.0244-23.2024 · Cited by 1
Sense of Presence and the Illusion of Self-scaling in Virtual Learning Environments
Wu, L., Chen, K., Peterson, M., & Delgado, C. (2024) · Lecture notes in computer science · doi:10.1007/978-3-031-76815-6_14 · Cited by 1
The Effect of Child and Adult Avatars on Spatial Perception in Urban-Scale Virtual Environment
Lee, J., Chen, Y., Gillies, M. F. P., & Pan, X. (2025) · IEEE International Conference on Artificial Intelligence and eXtended and Virtual Reality (AIxVR) · doi:10.1109/aixvr63409.2025.00012 · Cited by 1
Zhao, Y., Lindeman, R. W., & Piumsomboon, T. (2025) · IEEE Conference on Virtual Reality and 3D User Interfaces (VR) · doi:10.1109/vr59515.2025.00057 · Cited by 1
DobbyEar: Inducing Body Illusion of Ear Deformation with Haptic Retargeting
Shi, H., & Je, S. (2025) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3706598.3714110 · Cited by 1
One Human Many Bots: What are the Costs to Embodying Multiple Avatars During Teleoperations?
Fabritius, P. S., Bullinger, A. C., & Chuang, L. L. (2025) · Lecture notes in computer science · doi:10.1007/978-3-031-92980-9_14 · Cited by 1
Jeanne, R., Dupraz, L., Bourgin, J., Hot, P., Sonia Pellissier, A., & Kibleur, A. (2025) · Scientific Reports · doi:10.1038/s41598-025-22694-9 · Cited by 1
Embodying an avatar with a dissimilar appearance enhances insight problem solving
Lo, S.-Y., & Hsu, L.-J. (2025) · Scientific Reports · doi:10.1038/s41598-025-31146-3 · Cited by 1
Fukumoto, S., Mitsuno, S., Nakayama, K., Durrani, I. A., Hoshimure, K., Kodani, N., Itatani, R., Li, B., Ban, M., & Mahzoon, H. (2025) · International Conference on Human-Agent Interaction (HAI) · doi:10.1145/3765766.3765879 · Cited by 1
Children's Embodiment of Non‐Human Virtual Hand Forms
Dewe, H., Brenton, H., Castelow, I., Grimshaw, E., Gillies, M. F. P., & Cowie, D. A. (2026) · Developmental Science · doi:10.1111/desc.70131 · Cited by 1
Esteves, D., & Vourvopoulos, A. (2026) · Frontiers in Systems Neuroscience · doi:10.3389/fnsys.2026.1756407 · Cited by 1
D'Adamo, A., Srinivasan, K., Vidal, L. T., de la Prida, D., Azpicueta-Ruiz, L. A., Väljamäe, A., & Tajadura‐Jiménez, A. (2026) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3772318.3793153 · Cited by 1
Haynes, A., Vidal, L. T., Lindegren, A., Zhou, R., Ortega, A. G., Park, J. Y., Brynskov, A., Johnson, H., & Höök, K. (2026) · CHI Conference on Human Factors in Computing Systems · doi:10.1145/3772318.3791749 · Cited by 1
Reflective Embodiment through Avatar Abstraction: Insights from Movement Practitioners
Akbas, S., Kuşçu, K., Eskenazi, T., & Yantaç, A. E. (2026) · International Conference on Movement and Computing (MOCO) · doi:10.1145/3802842.3802857 · Cited by 1
Verbe, J., Gautier, R. H., Latinus, M., Bonnet‐Brilhault, F., & Briend, F. (2026) · Human Nature · doi:10.1007/s12110-026-09526-z · Cited by 1
Palmer, M., Pink, S., & Smith, J. E. (2023) · Virtual reality technologies for health and clinical applications · doi:10.1007/978-1-0716-3371-7_10 · Cited by 1
Tano, S., Kakei, Y., Hashiyama, T., Ichino, J., & Iwata, M. (2015) · IEEE International Conference on Multimedia & Expo Workshops (ICMEW) · doi:10.1109/icmew.2015.7169762 · Cited by 1
Effects of tracking scale on user performance in virtual reality games
Burgh, B., & Johnsen, K. (2017) · IEEE Workshop on Everyday Virtual Reality (WEVR) · doi:10.1109/wevr.2017.7957712 · Cited by 1
User interface design of an immersive virtual reality environment to electricians training
Tanaka, E. H., Paludo, J. A., Domingues, L. R., Cordeiro, C. S., Giraldi, O., Cascone, M. H., Gadbem, E. V., & Euflasino, A. (2015) · Brazilian Symposium on Human Factors in Computing Systems (IHC) · doi:10.1145/3148456.3148492 · Cited by 1
Manipulating The Body Representation: Assessment Of A Novel Platform
Lejeune, F., D’Alonzo, M., Noccaro, A., Raiano, L., Formica, D., & Pino, G. D. (2020) · Annual International Conference of the IEEE Engineering in Medicine and Biology Society (EMBC) · doi:10.1109/embc44109.2020.9176659 · Cited by 1
A Deep CNN Model for Inferring 3D Human Body Shapes Using Front and Side Images
de la Campa, E. Á., & Spanlang, B. (2021) · International Conference on 3D Body Scanning Technologies (3DBST) · doi:10.15221/21.32 · Cited by 1
Giroux, M., Barra, J., Graff, C., & Guerraz, M. (2021) · SHS Web of Conferences · doi:10.1051/shsconf/202113002001 · Cited by 1
Thöne-Otto, A. I. T., & Chojecki, P. (2022) · Gesundheit. Politik - Gesellschaft - Wirtschaft · doi:10.1007/978-3-658-34027-8_30 · Cited by 1
Adventures beyond anthropocentrism in virtual reality art
Bédard, P. (2022) · AN-ICON Studies in Environmental Images · doi:10.54103/ai/18458 · Cited by 1
Torromino, G. (2024) · Integrated science · doi:10.1007/978-3-031-58363-6_12 · Cited by 1
McGowin, G., & Fiore, S. M. (2025) · Proceedings. · doi:10.22318/icls2025.180060 · Cited by 1
Technology for the Active Senior
Couceiro, M. S., & Dias, G. (2017) · SpringerBriefs in well-being and quality of life research · doi:10.1007/978-3-319-52063-6_4 · Cited by 1
An Experience-Centered Framework for Designing Non-Task-Oriented Embodied Interaction Environments
Malinverni, L., & Schaper, M.-M. (2018) · Multimodal Technologies and Interaction · doi:10.3390/mti2020022 · Cited by 1
Scientific and Technical Prospects
Baillard, C., Guillotel, P., Lécuyer, A., Lotte, F., Mollet, N., Normand, J., & Seydoux, G. (2018) · Wiley eBooks · doi:10.1002/9781119341031.ch5 · Cited by 1
Self-citationCritchley, H., Botan, V., & Ward, J. (2020) · bioRxiv (Cold Spring Harbor Laboratory) · doi:10.1101/2020.07.24.219287 · Cited by 1
Matamala-Gomez, M., Brivio, E., Chirico, A., Malighetti, C., Realdon, O., Serino, S., Dakanalis, A., Corno, G., Polli, N., Cacciatore, C., et al. (2020) · doi:10.31234/osf.io/b38ym · Cited by 1
Multisensory Integration and Proprioceptive Drift During Resizing IllusionsPreprint
Hansford, K. J., Baker, D. H., McKenzie, K. J., & Preston, C. (2023) · doi:10.31234/osf.io/n56ha · Cited by 1
Botella, C., Baños, R., García‐Palacios, A., & Quero, S. (2015) · Wiley eBooks · doi:10.1002/9781394259229.ch21 · Cited by 1
The Defensive Role of the Peripersonal Space in Social ContextsPreprint
Mustile, M., Borghi, A. M., Tommaso, D. D., & Wykowska, A. (2024) · doi:10.31234/osf.io/rbdgc · Cited by 1
When VR meets reality – how live concerts could be enhanced by 21st-century opera glasses
Esteves, A. (2017) · doi:10.64628/ab.sd7uhvcun · Cited by 1
Fribourg, R. (2020) · theses.fr (ABES) · doi:10.70675/7cdf8293zc276z4be5z91f5z2d40df1d6d69 · Cited by 1
Friedman, D. A., & Guger, C. (2014) · PRESENCE Virtual and Augmented Reality · doi:10.1162/pres_e_00199
Andrews, S., Vincent, J. B., & McCormick, J. (2015) · ACM Symposium on Spatial User Interaction (SUI) · doi:10.1145/2788940.2788952 · Cited by 1
Palmer, M. (2015) · Creativity and Cognition · doi:10.1145/2757226.2757379
Voluntary self-tapping induces self-localization shift
Furukawa, M., Minamizawa, K., & Tachi, S. (2014) · IEEE RO-MAN · doi:10.1109/roman.2014.6926395
Metadata
- Authors
- Kilteni, K., Normand, J.-M., Sanchez-Vives, M. V., & Slater, M.
- Affiliations
- Universitat de Barcelona (ES)
- Consorci Institut D'Investigacions Biomediques August Pi I Sunyer (ES)
- Institució Catalana de Recerca i Estudis Avançats (ES)
- Corresponding author
- Slater, Mel
- Venue
- PLoS ONE
- Publisher
- Public Library of Science (PLoS)
- Published
- 2012-07-19
- Volume
- 7
- Issue
- 7
- Pages
- e40867
- ISSN
- 1932-6203 (ISSN-L)
- PMC
- PMC3400672
- OpenAlex
- W1965428772
- Semantic Scholar
- a6eb124caa6aafcd6bda8c6e524711b90aad993a
- Cited by
- 499
- References
- 46
- Citations by year
- 2026: 26 · 2025: 41 · 2024: 43 · 2023: 32 · 2022: 47 · 2021: 51 · 2020: 64 · 2019: 35 · 2018: 37 · 2017: 31 · 2016: 26 · 2015: 25 · 2014: 26 · 2013: 15
- FWCI
- 38.86
- Type
- journal article
- Language
- en
- Open access
- gold
- doi.org
- Locations
- PLoS ONE (publishedVersion, cc-by)
- Europe PMC (PubMed Central) (publishedVersion, cc-by)
- PubMed Central (publishedVersion, cc-by)
- PubMed (publishedVersion)
- RECERCAT (Consorci de Serveis Universitaris de Catalunya) (publishedVersion, other-oa)
- RePEc: Research Papers in Economics (submittedVersion)
- Dipòsit Digital de la Universitat de Barcelona (Universitat de Barcelona) (submittedVersion, cc-by)
- DOAJ (DOAJ: Directory of Open Access Journals) (submittedVersion, cc-by-sa)
- UCL Discovery (University College London) (submittedVersion)
- Figshare (submittedVersion, cc-by)
- Funders
- FP7 Ideas: European Research Council (227985)
- Topics
- Physical Sciences › Computer Science › Human-Computer Interaction › Virtual Reality Applications and Impacts
- Social Sciences › Psychology › Experimental and Cognitive Psychology › Multisensory perception and integration
- Social Sciences › Arts and Humanities › Philosophy › Free Will and Agency
- Keywords
- body ownership, multisensory integration, proprioception, rubber hand illusion, body image, body size perception, immersive virtual reality
About these checks
Registry, retraction, Cites and statistics results are computed, not judged, with one exception: a printed reference that no index lists is read once by a model before it counts as a citation error. Claims are extracted by a model and kept only when their quote appears verbatim in the text; each cited source is then checked, with a model’s help, for whether it says what the claim relies on. Those verdicts can be wrong — read the claim’s quote and the cited source before relying on one.
A language model drew the claims from the paper on 2026-10-09, under version 3 of the claim definition (model deepseek-v4.1-flash, prompt extract-v3).
A second model labelled each claim on 2026-10-09 (model jev-1.13-20260917, definition revision gold-guideline-v0.2).
Statistics and arithmetic are recomputed, not judged.
Confidence bands are shown only for fields calibrated on our annotated test set. None is calibrated yet, so no band is shown.
What counts as a claim ›How we measure confidence ›How we check this ›
Are you an author, or do you see a problem with this page? Request a review
